Related Experiment Video
Updated: Jul 7, 2026
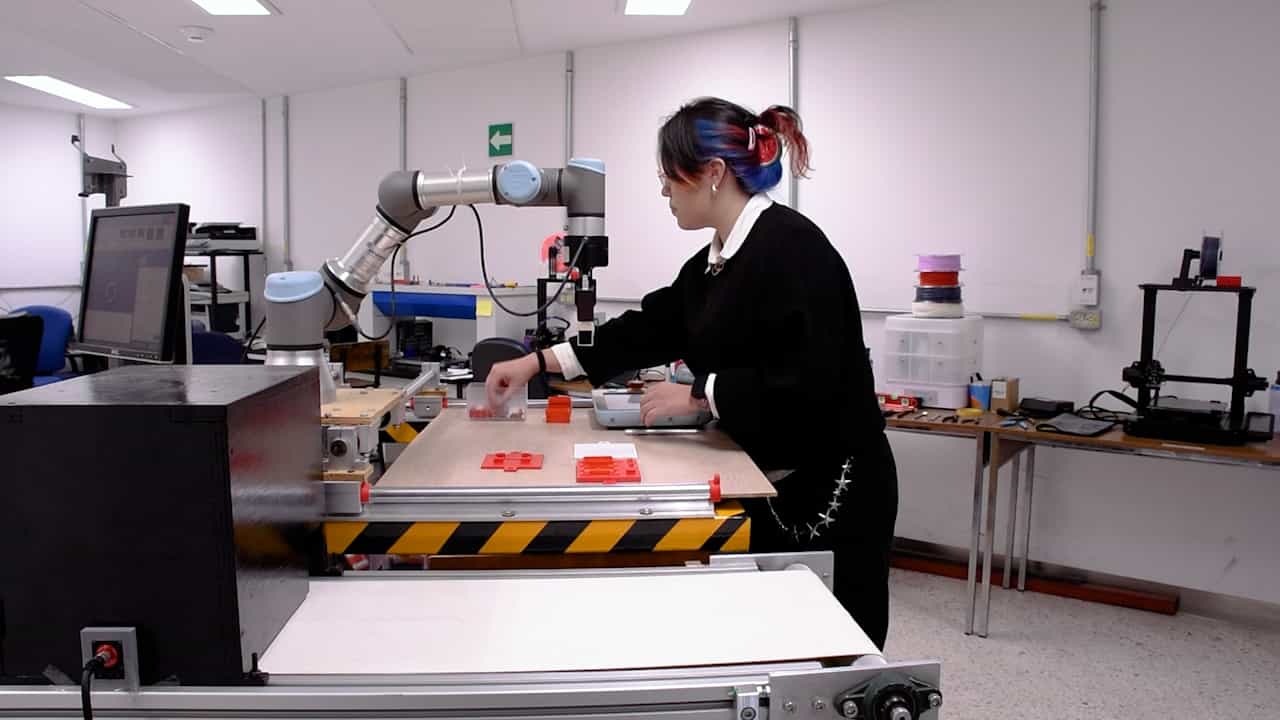

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Implementation of self-organizing neural networks for visuo-motor control of an industrial robot
1Dept. of Comput. Sci., Bielefeld Univ.

Abstract:
The implementation of two neural network algorithms for visuo-motor control of an industrial robot (Puma 562) is reported. The first algorithm uses a vector quantization technique, the ;neural-gas' network, together with an error correction scheme based on a Widrow-Hoff-type learning rule. The second algorithm employs an extended self-organizing feature map algorithm. Based on visual information provided by two cameras, the robot learns to position its end effector without an external teacher. Within only 3000 training steps, the robot-camera system is capable of reducing the positioning error of the robot's end effector to approximately 0.1% of the linear dimension of the work space. By employing adaptive feedback the robot succeeds in compensating not only slow calibration drifts, but also sudden changes in its geometry. Hardware aspects of the robot-camera system are discussed.


Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:18
Neural Control of Respiration
Respiratory Centers in the Brainstem
Two primary areas comprise the respiratory center: the medullary respiratory center in the medulla oblongata and the pontine respiratory group in the pons. The...