View generation for three-dimensional scenes from video sequences
Related Experiment Video
Updated: Jul 7, 2026
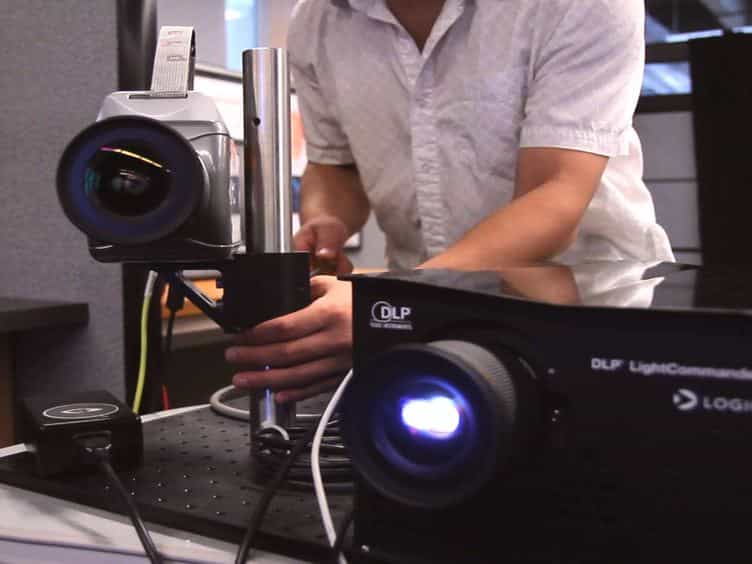
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013

Abstract:
This paper focuses on the representation and view generation of three-dimensional (3-D) scenes. In contrast to existing methods that construct a full 3-D model or those that exploit geometric invariants, our representation consists of dense depth maps at several preselected viewpoints from an image sequence. Furthermore, instead of using multiple calibrated stationary cameras or range scanners, we derive our depth maps from image sequences captured by an uncalibrated camera with only approximately known motion. We propose an adaptive matching algorithm that assigns various confidence levels to different regions in the depth maps. Nonuniform bicubic spline interpolation is then used to fill in low confidence regions in the depth maps. Once the depth maps are computed at preselected viewpoints, the intensity and depth at these locations are used to reconstruct arbitrary views of the 3-D scene. Specifically, the depth maps are regarded as vertices of a deformable 2-D mesh, which are transformed in 3-D, projected to 2-D, and rendered to generate the desired view. Experimental results are presented to verify our approach.

Related Concept Videos
 01:28
Cylinders in Three-Dimensional Space
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:20
Divergence Theorem in 3D Space
 01:30
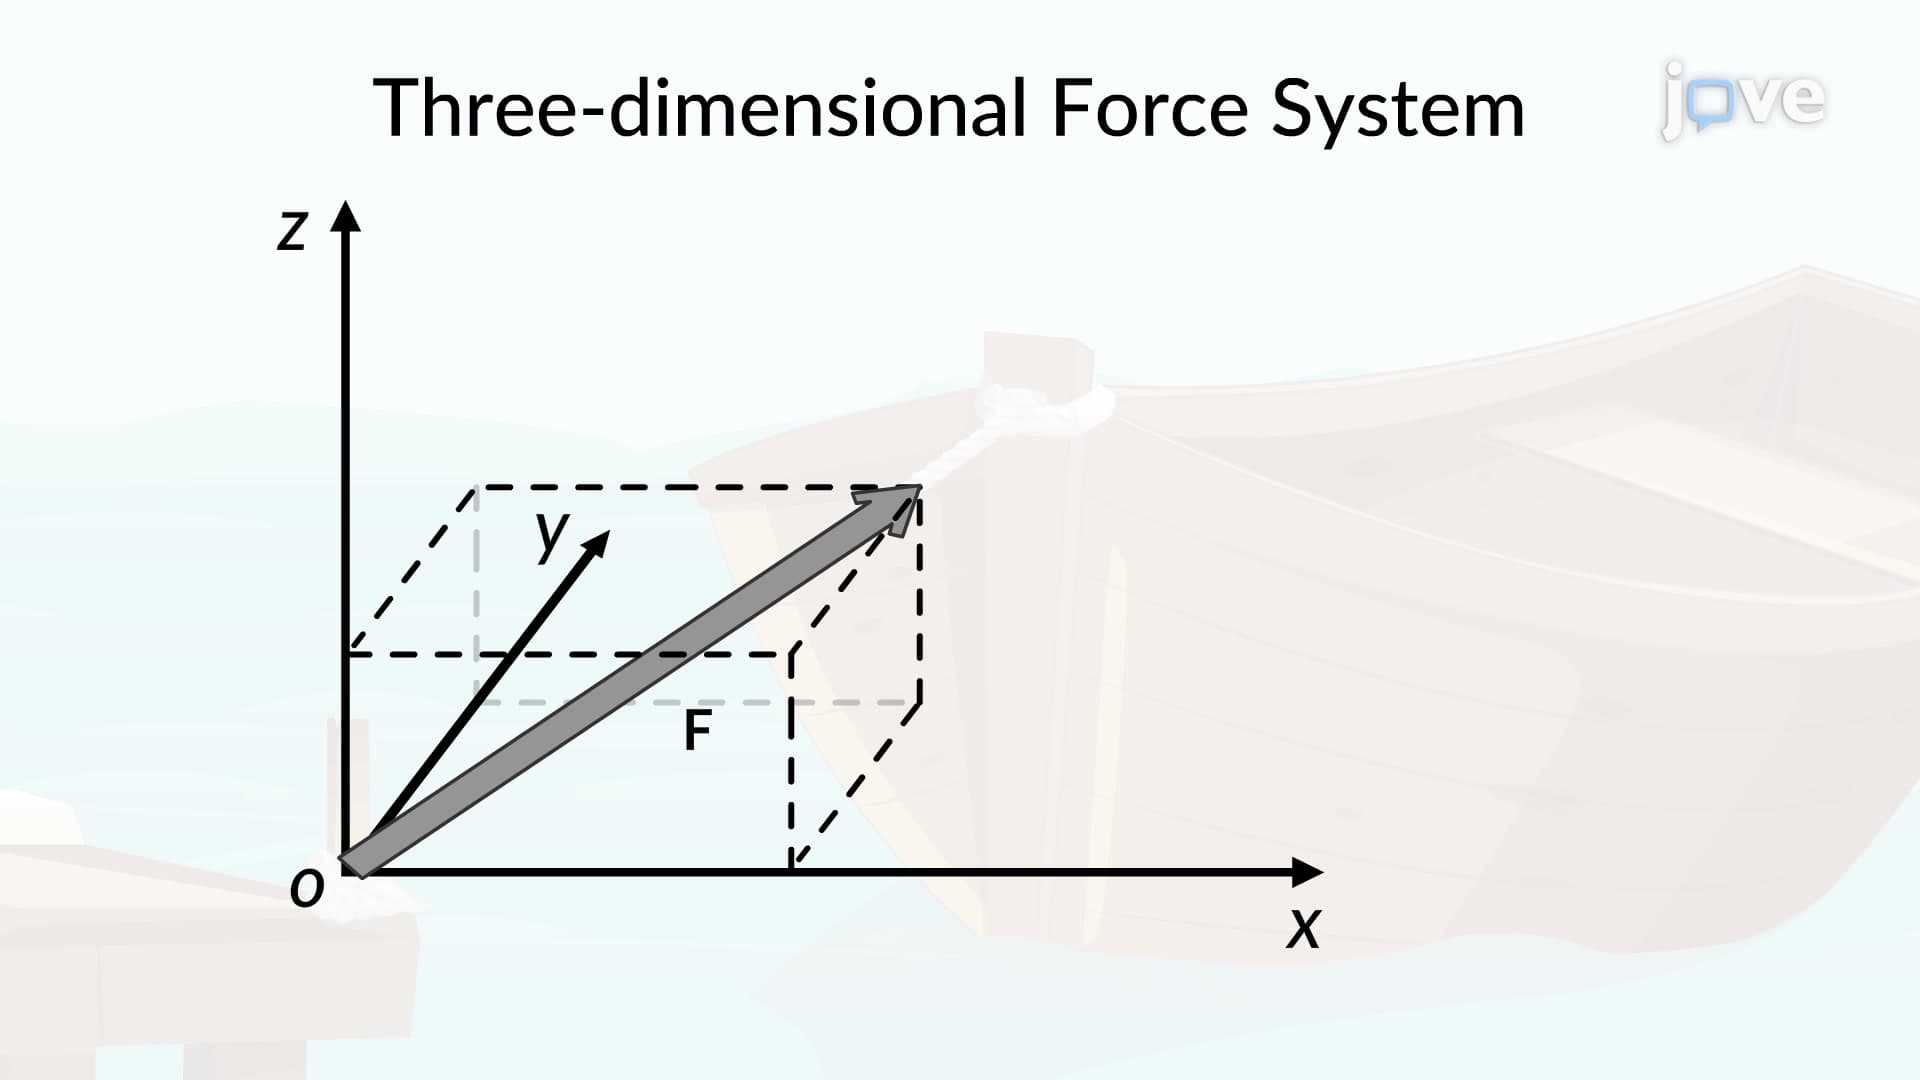
Three-Dimensional Force System
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...