Nonlinear filtering of multivariate images under robust error criterion
Related Experiment Video
Updated: Jul 7, 2026
14:58
Optical Scatter Microscopy Based on Two-Dimensional Gabor Filters
Published on: June 2, 2010
1Dept. of Electr. Eng., Oulu Univ.

Abstract:
A class of nonlinear filters for multivariate data is introduced. A robust error criterion is minimized. Approximate algorithms for computing the filter output are developed. A polynomial signal model is used in applications where the signal amplitude has to be retained with high fidelity. Simulated data and RGB color image data are used in experiments.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:11
Residuals and Least-Squares Property
The vertical distance between the actual value of y and the estimated value of y. In other words, it measures the vertical distance between the actual data point and the predicted point on the line
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:21
Linear Approximation in Time Domain
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
Linearization and Approximation
Linearization is a mathematical technique used to approximate complex, nonlinear functions with simpler linear models in the vicinity of a chosen reference point. The method is based on the idea that, although a function may be difficult to evaluate exactly, its behavior near a specific input value can often be closely approximated by the tangent line at that point. This approach is particularly useful when small deviations from a known value are involved.Consider the square root function, for...
 01:19
Routh-Hurwitz Criterion II
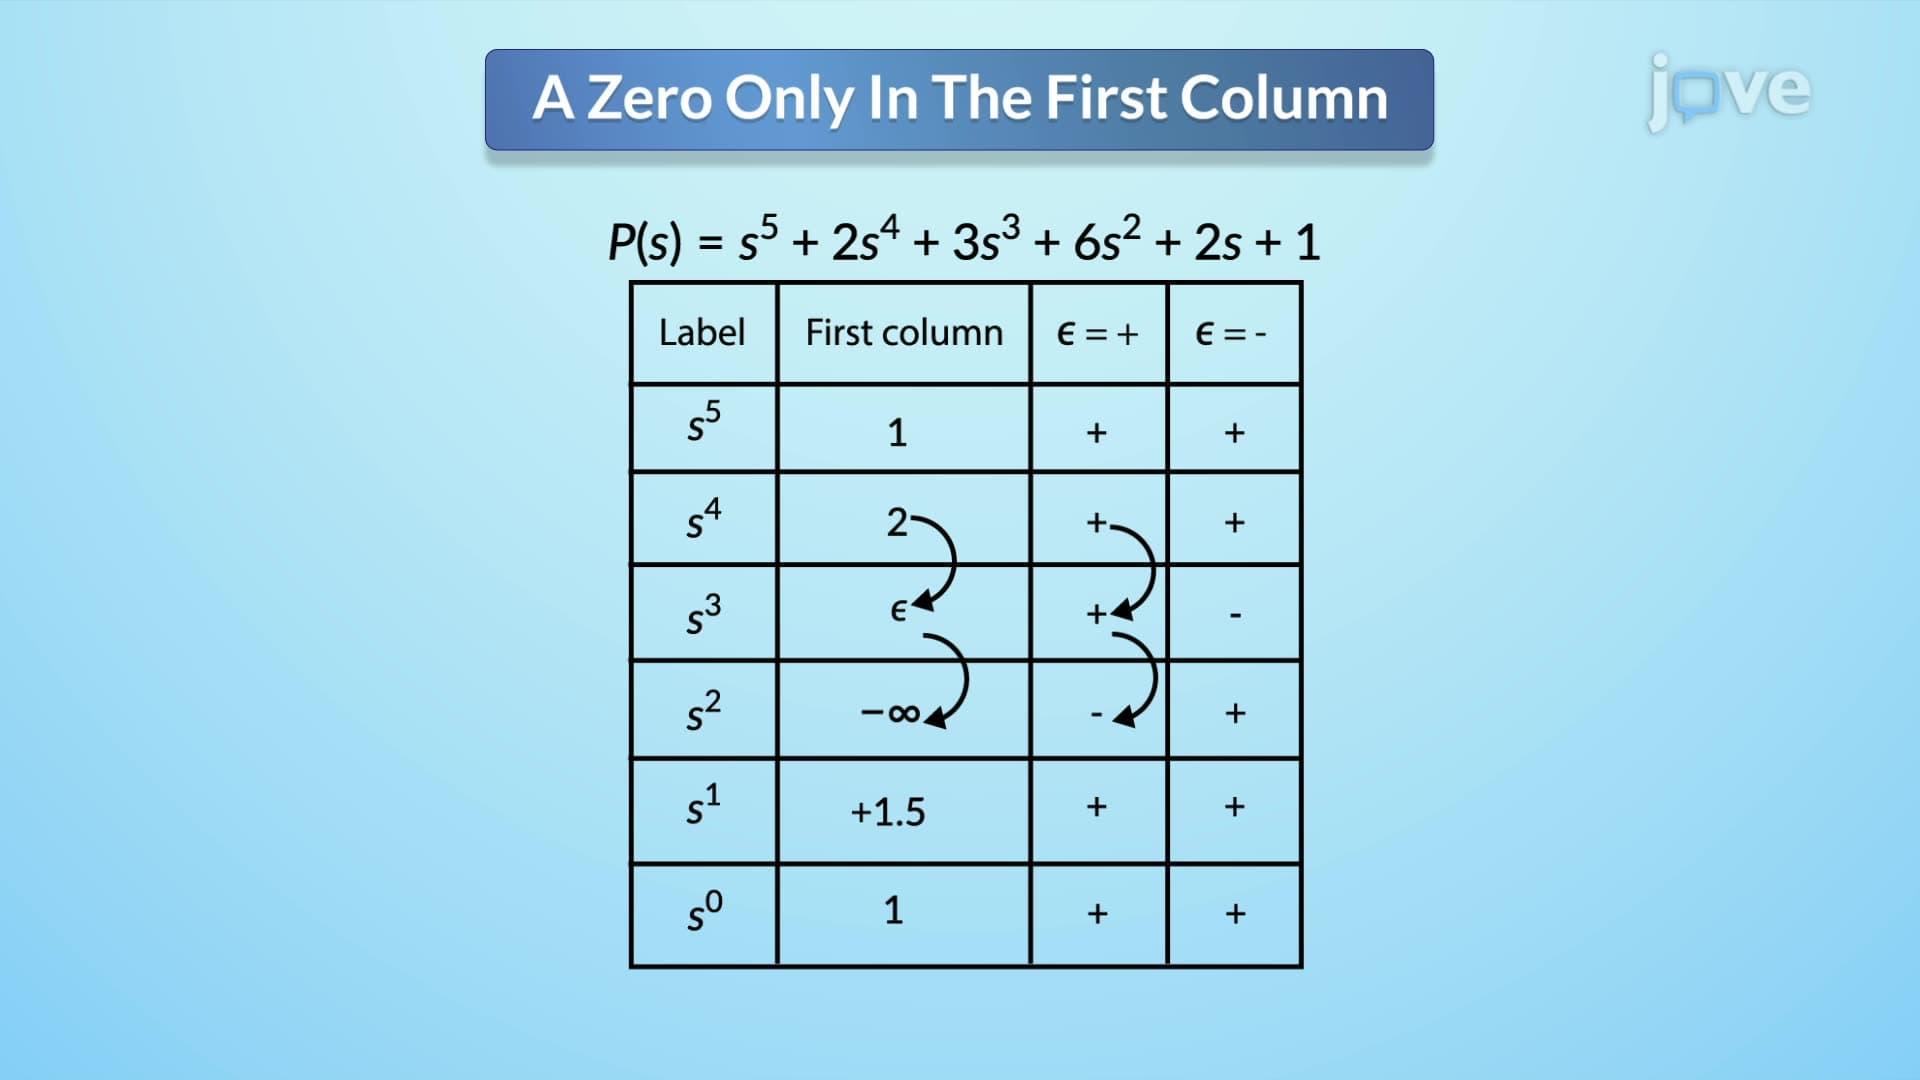
In the application of the Routh-Hurwitz criterion, two specific scenarios can arise that complicate stability analysis.
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first column of the Routh...
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first column of the Routh...
 01:23
Linear Approximations
For a differentiable function of two variables, linear approximation estimates values near a known point by replacing the curved surface with its tangent plane. Consider the function\begin{equation*}f(x,y)=x^2+3y^2\end{equation*}near the point (2, 1). The exact value at this point is f(2, 1) = 22 + 3(1)2 = 4 + 3 = 7.The linear approximation of f(x, y)) near (a, b) is\begin{equation*}L(x,y)=f(a,b)+f_x(a,b)(x-a)+f_y(a,b)(y-b)\end{equation*}First, compute the partial derivatives: fx(x, y) = 2x and...