Feedback design for the control of a dynamic multitasking system: dissociating outcome feedback from control feedback
Related Experiment Video
Updated: Jul 2, 2026
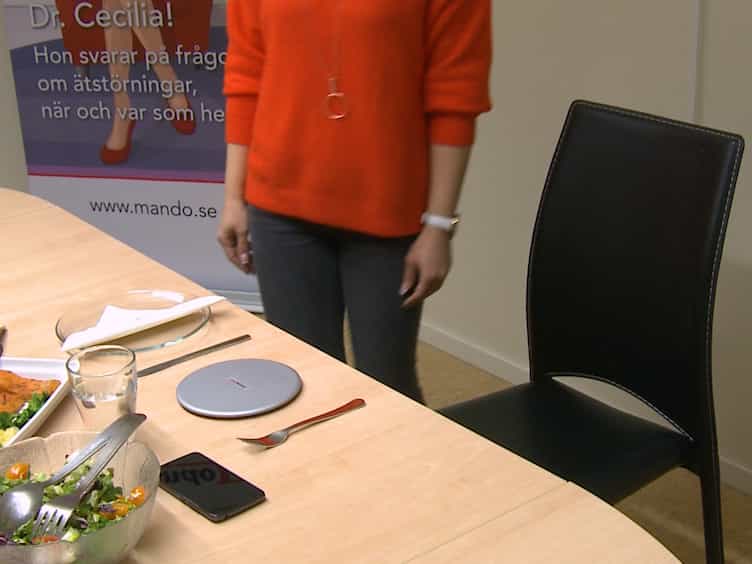
Control of Eating Behavior Using a Novel Feedback System
Published on: May 8, 2018
Hansjörg Neth1, Sangeet S Khemlani, Wayne D Gray
1Cognitive Science Department, Rensselaer Polytechnic Institute, Troy, NY 12180, USA. nethh@rpi.edu

Objective:
We distinguish outcome feedback from control feedback to show that suboptimal performance in a dynamic multitasking system may be caused by limits inherent to the information provided rather than human resource limits.
Background:
Tardast is a paradigm for investigating human multitasking behavior, complex system management, and supervisory control. Prior research attributed the suboptimal performance of Tardast operators to poor strategic task management.
Methods:
We varied the nature of performance feedback in the Tardast paradigm to compare continuous, cumulative feedback (global feedback) on performance outcome with feedback limited to the most recent system state (local feedback).
Results:
Participants in both conditions improved with practice, but those with local feedback performed better than those with global feedback. An eye gaze analysis showed increased visual attention directed toward the feedback display in the local feedback condition.
Conclusion:
Predicting performance in the control of a dynamic multitasking system requires understanding the interactions between embodied cognition, the task being performed, and characteristics of performance feedback. In the current case, at least part of what had been diagnosed as a deficit caused by limited cognitive resources has been shown to be data limited.
Application:
Perfect outcome feedback can provide inadequate control feedback. Instances of suboptimal performance can be alleviated by better feedback design that takes into account the temporal dynamics of the human-system interaction.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:10
Control Systems
At the heart...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...