Related Experiment Video
Updated: Jun 26, 2026


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Evaluation of obstetric gestures: an approach based on the curvature of quaternions

Abstract:
This paper presents a method to evaluate a gesture carried out by a resident obstetrician by comparing it to a gesture carried out by an expert obstetrician. The studied gesture is the forceps blade placement. Resident paths were recorded on a childbirth simulator while placing forceps blades instrumented with six degrees of freedom sensors. The path is characterized by the positions and the orientations. In this paper we particularly focus on the orientations. Forceps orientations are expressed in the quaternion unit space and the curvature of quaternion path is compared by correlation to a reference defined by an expert. Residents have been trained on a simulator and their gestures are evaluated by comparing their orientation path curvatures to reference path curvatures. Quantitative results confirm the qualitative analysis, residents become more similar to the reference while training on simulator.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:25
Curvature and Its Interpretation
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:27
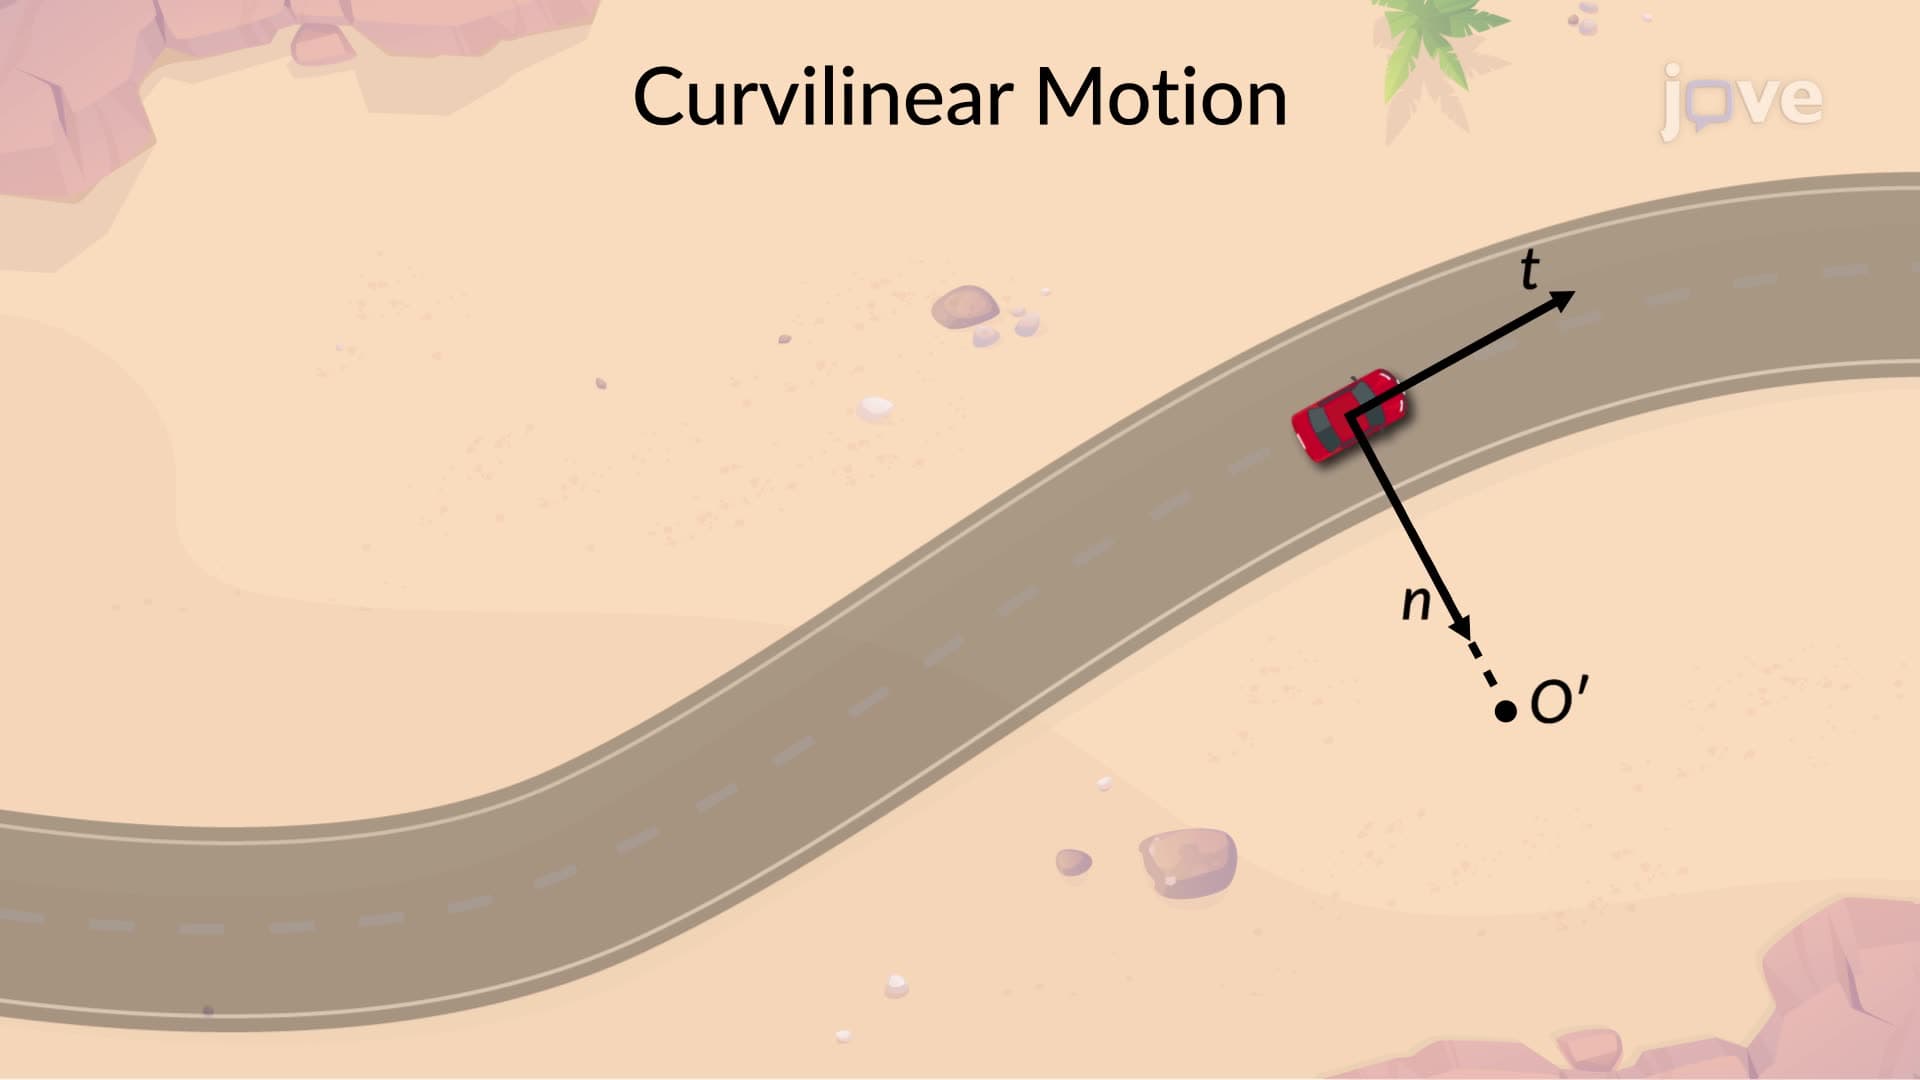
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:27
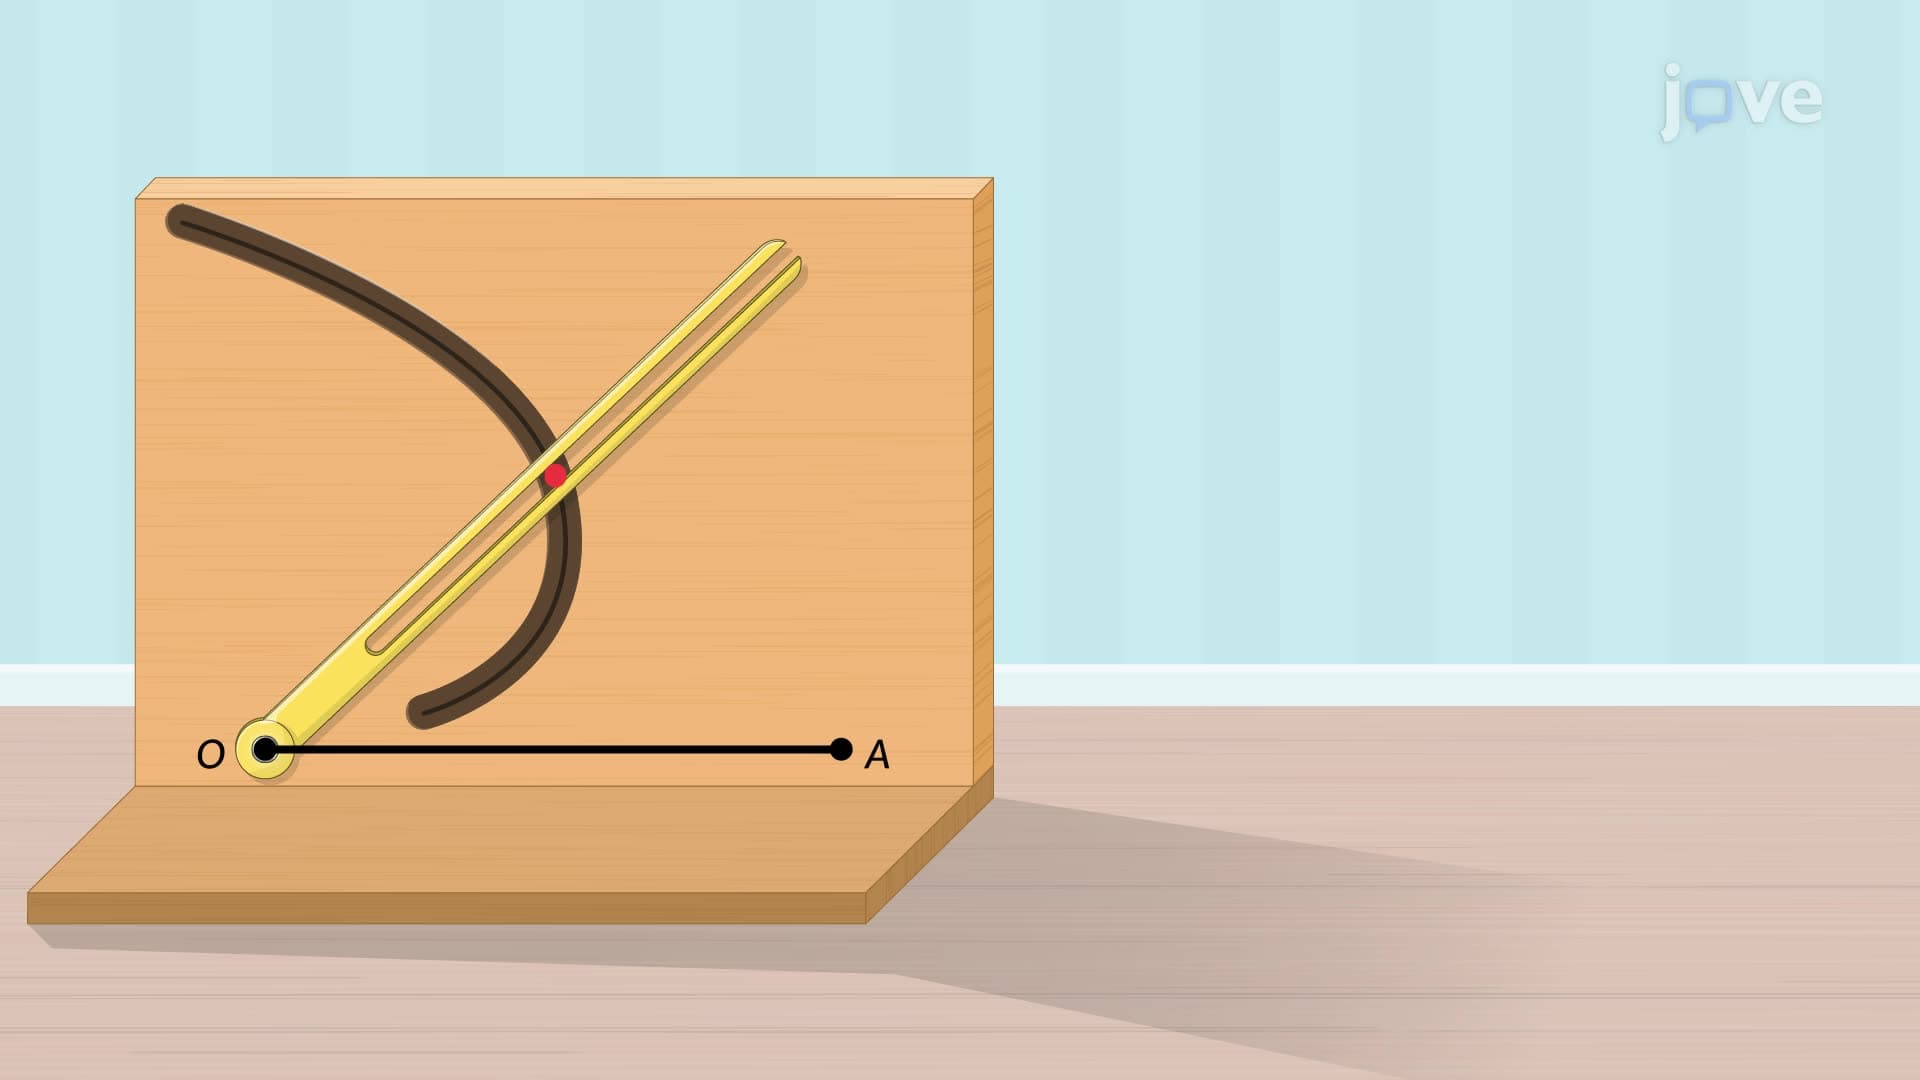
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...