Related Experiment Video
Updated: Jun 23, 2026
Online Virtual Reality Networked Control Laboratory Applied in Control Engineering Education
Published on: February 23, 2024
Modeling and control of a pneumatically actuated inverted pendulum
Tihomir Zilić1, Danijel Pavković, Davor Zorc
1Department of Robotics and Automation of Manufacturing Systems, Faculty of Mechanical Engineering and Naval Architecture, University of Zagreb, Zagreb, Croatia. tihomir.zilic@fsb.hr

Abstract:
This paper presents the results of modeling of an inverted pendulum system driven by a linear pneumatic motor and equipped with relatively low-cost potentiometer-based position measurement system. Based on the nonlinear model of the overall pendulum system, which also includes notable friction effects, a linearized model is derived. The linearized model is used as a basis for the design of state feedback controller based on LQ and LQG optimization procedures. The linear state feedback controllers are augmented by a compensator of nonlinear friction effects whose design is based on the results of experimental identification of an appropriate static friction model. The proposed pendulum controller structures have been verified by means of computer simulations and experimentally on the experimental setup of a pneumatically actuated inverted pendulum.

Related Concept Videos
 01:06
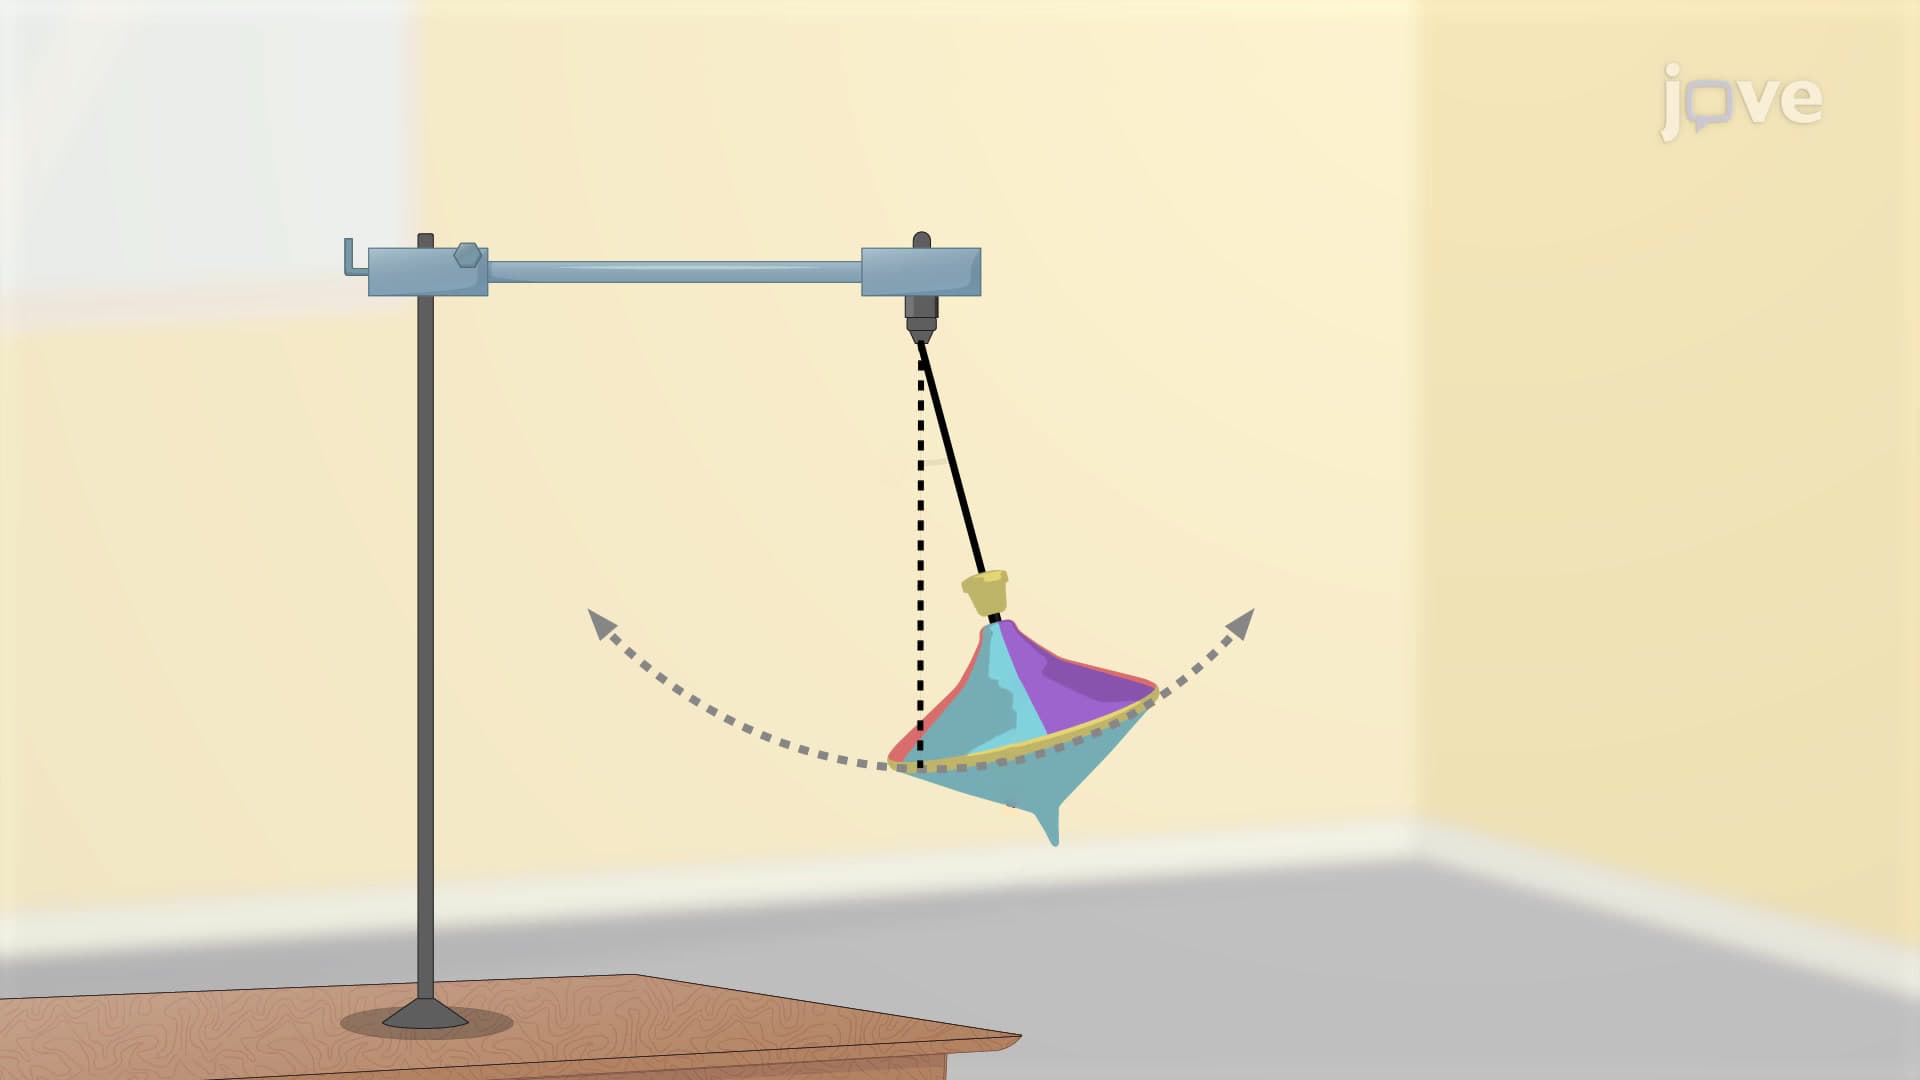
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it describes the mass...
 01:10
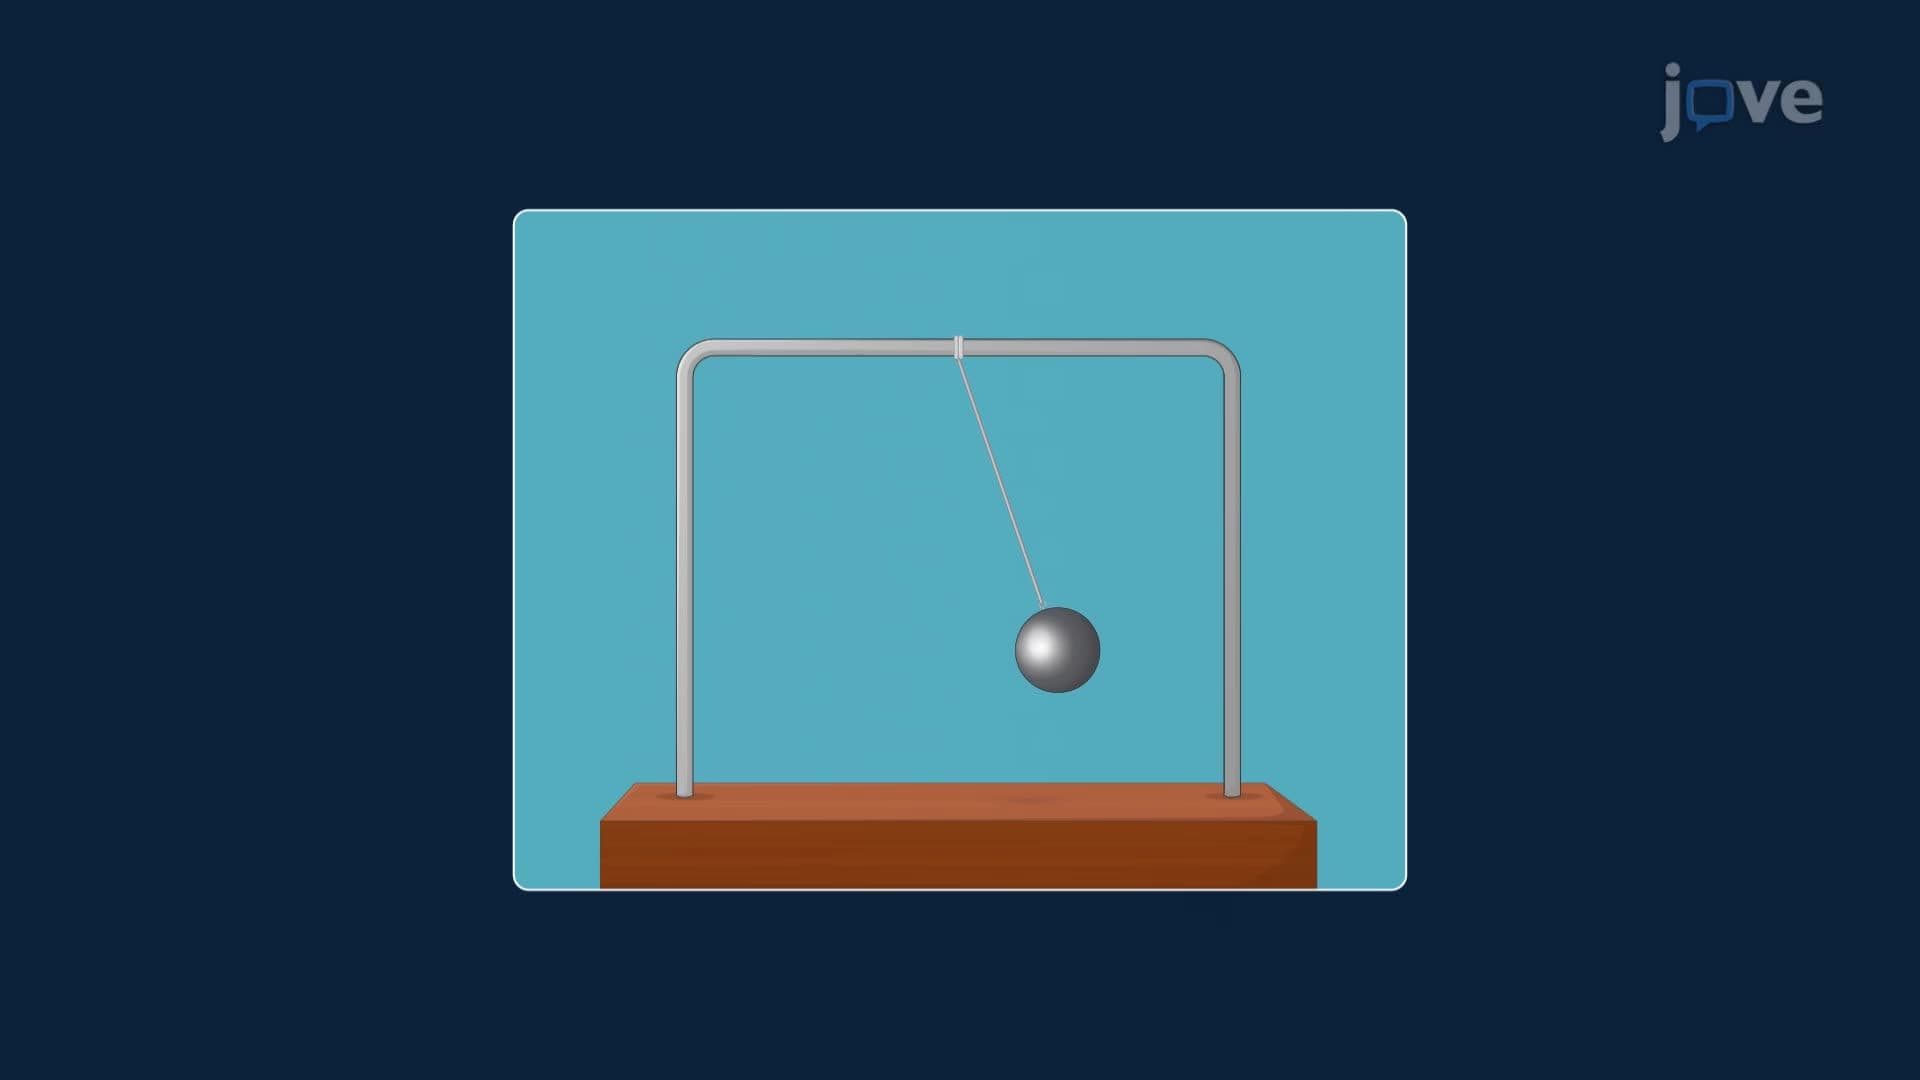
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:09
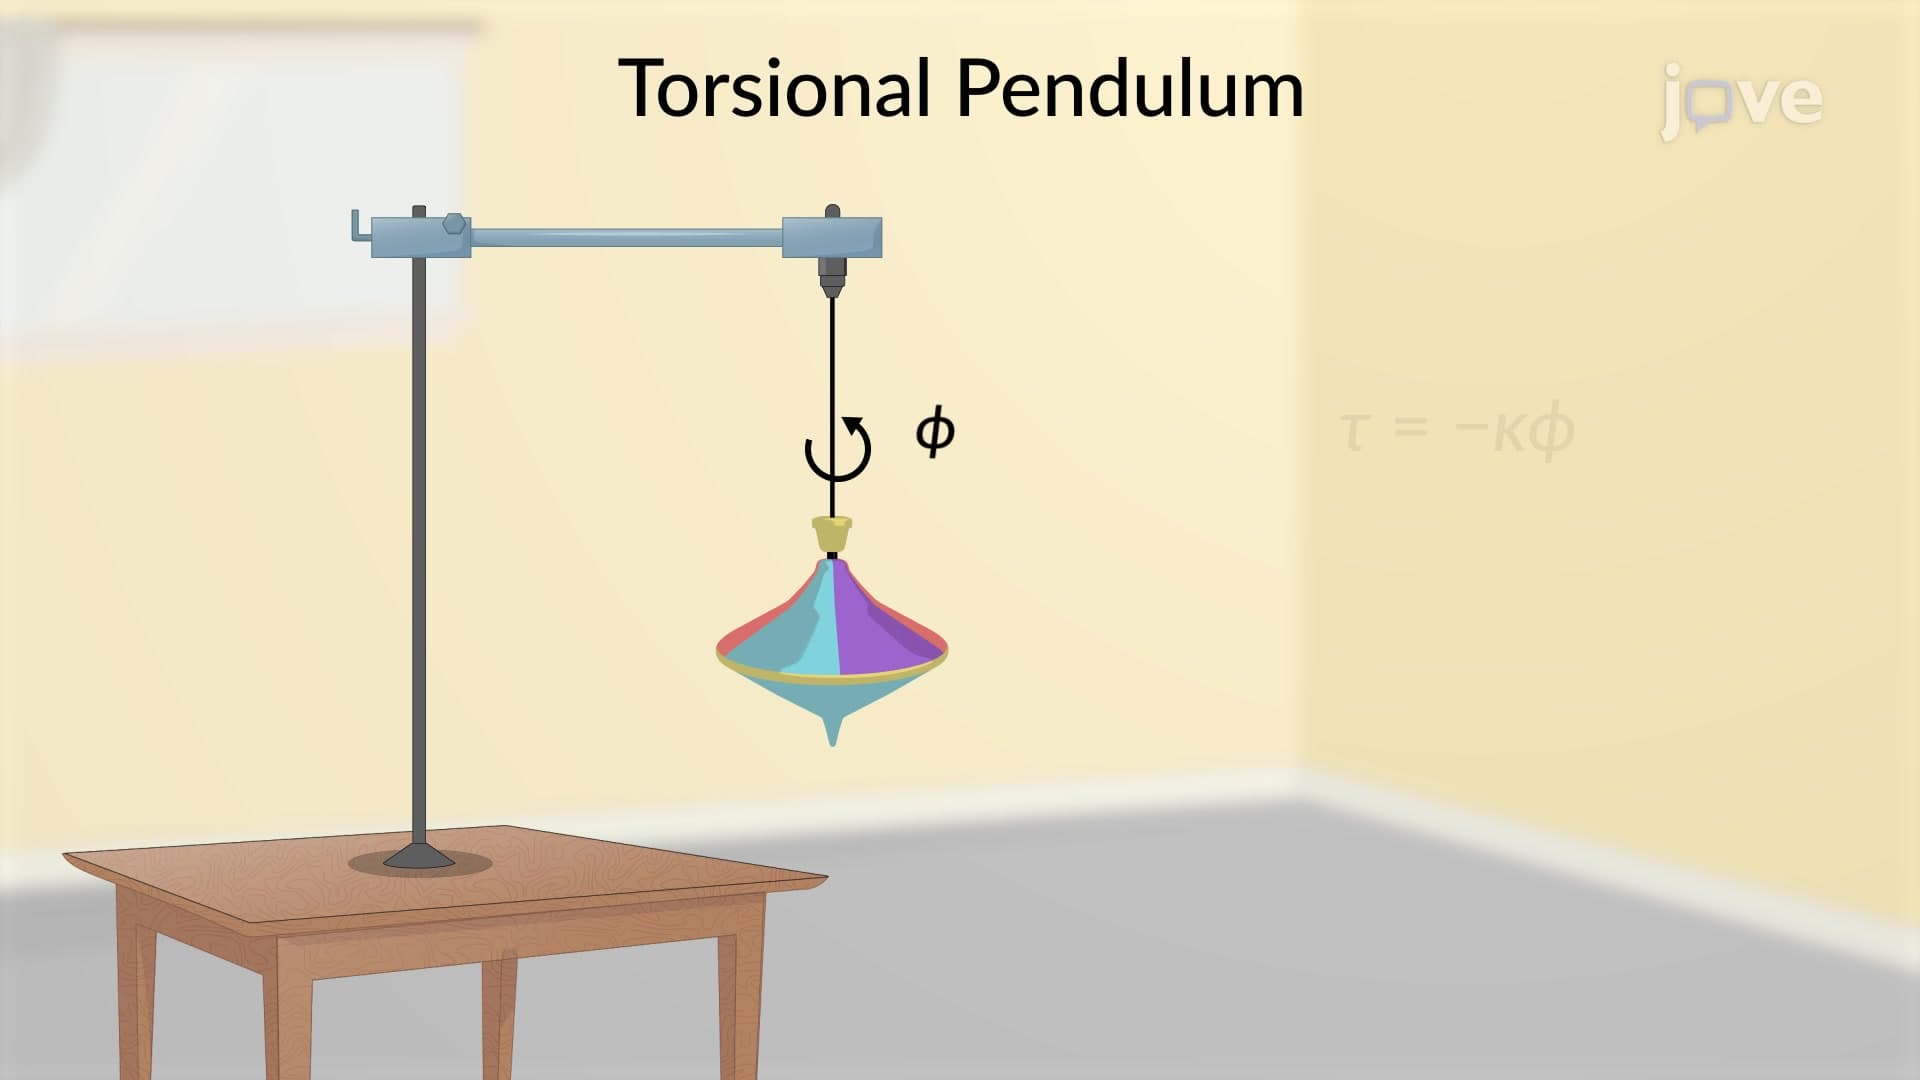
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played by the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:27
Real-World Applications of Power Series
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...