Related Experiment Video
Updated: Jun 22, 2026
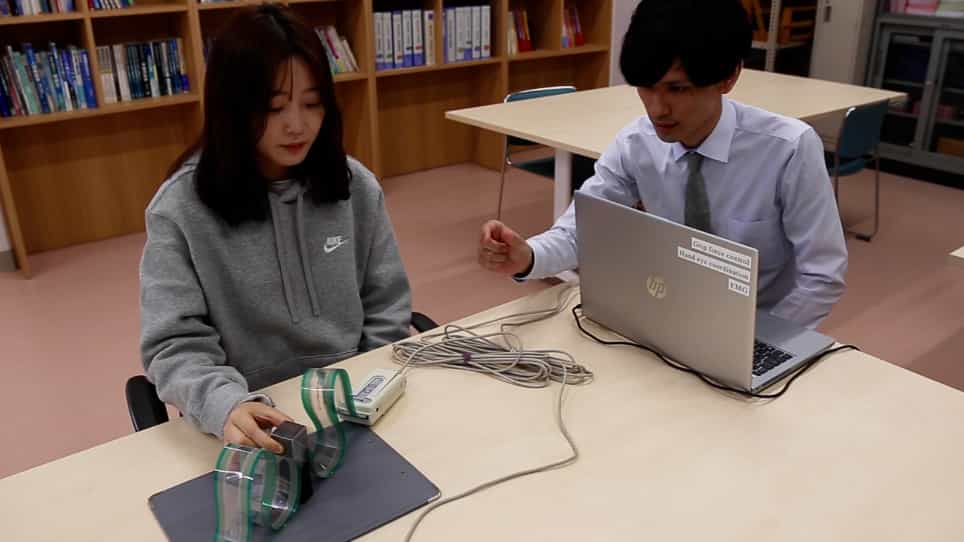

Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Prehension synergies: a study of digit force adjustments to the continuously varied load force exerted on a partially
Jason Friedman1, Mark L Latash, Vladimir M Zatsiorsky
1Department of Kinesiology, The Pennsylvania State University, 39 Recreation Building, University Park, PA 16802, USA. jason.friedman@psu.edu

Abstract:
We examined how the digit forces adjust when a load force acting on a hand-held object continuously varies. The subjects were required to hold the handle still while a linearly increasing and then decreasing force was applied to the handle. The handle was constrained, such that it could only move up and down, and rotate about a horizontal axis. In addition, the moment arm of the thumb tangential force was 1.5 times the moment arm of the virtual finger (VF, an imagined finger with the mechanical action equal to that of the four fingers) force. Unlike the situation when there are equal moment arms, the experimental setup forced the subjects to choose between (a) sharing equally the increase in load force between the thumb and VF but generating a moment of tangential force, which had to be compensated by negatively co-varying the moment due to normal forces, or (b) sharing unequally the load force increase between the thumb and VF but preventing generation of a moment of tangential forces. We found that different subjects tended to use one of these two strategies. These findings suggest that the selection by the CNS of prehension synergies at the VF-thumb level with respect to the moment of force is non-obligatory and reflects individual subject preferences. This unequal sharing of the load by the tangential forces, in contrast to the previously observed equal sharing, suggests that the invariant feature of prehension may be a correlated increase in tangential forces rather than an equal increase.


Related Concept Videos
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:19
Machines
A free-body diagram of the...
 01:30
Machines: Problem Solving II