Related Experiment Video
Updated: Jun 19, 2026
07:42

Rapid Repetition Rate Fluctuation Measurement of Soliton Crystals in a Microresonator
Published on: December 15, 2021
Transmission control of dark solitons by means of nonlinear gain
Optics Letters
|October 28, 2009

Abstract:
Transmission control of dark solitons against various perturbations is possible by use of amplifiers with nonlinear gain. Stable propagation of gray and/or black solitons is achieved even in the presence of the Raman effect and mutual interactions between neighboring dark solitons.
Related Concept Videos
 01:26
Transmission-Line Differential Equations
Transmission lines are essential components of electrical power systems. They are characterized by the distributed nature of resistance (R), inductance (L), and capacitance (C) per unit length. To analyze these lines, differential equations are employed to model the variations in voltage and current along the line.
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from the...
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from the...
 01:26
Linear Approximation in Frequency Domain
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
State Space to Transfer Function
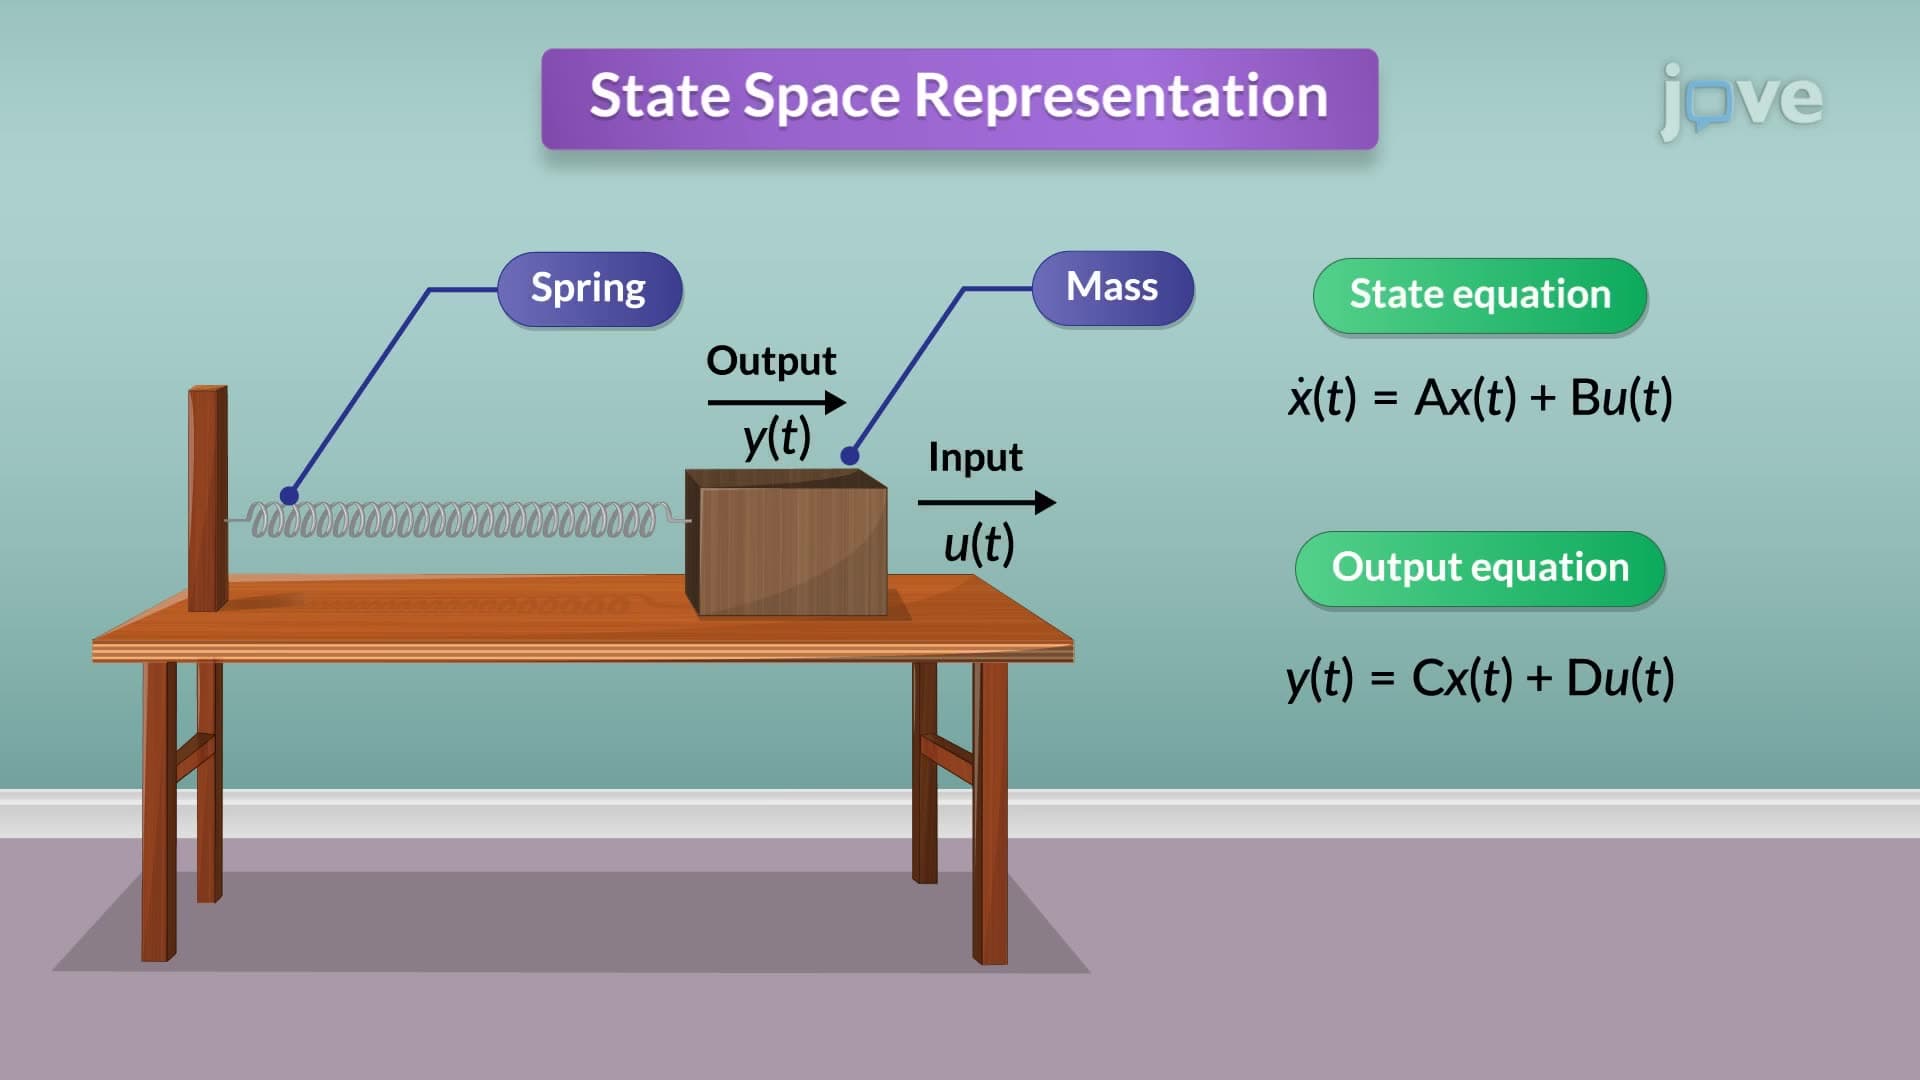
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
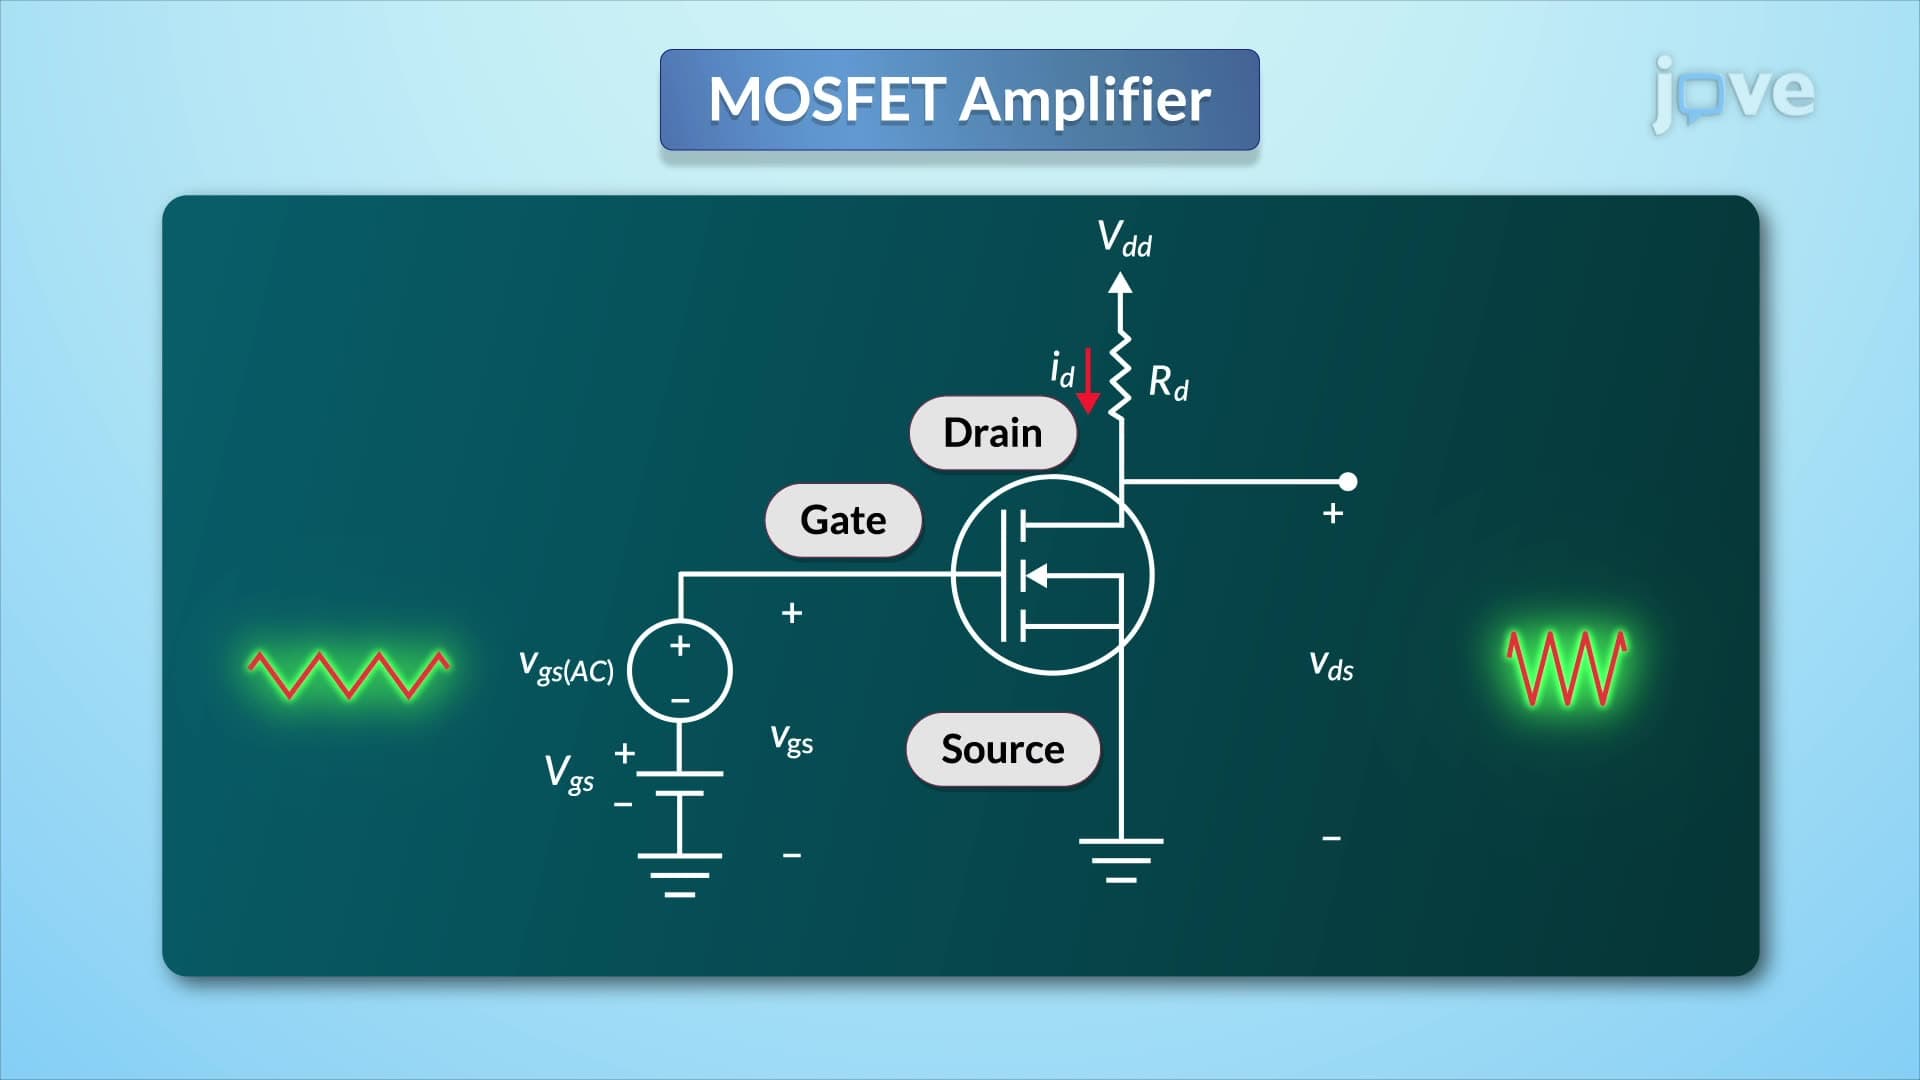
Small-Signal Analysis of MOSFET Amplifiers
In small-signal analysis, a MOSFET transistor amplifier acts as a linear amplifier when operating in its saturation region. The gate-to-source voltage (VGS) of the MOSFET is the sum of the DC biasing voltage and the small time-varying input signal. This combination sets up the operating point and modulates the drain current (ID) that flows from the drain to the source. When a small AC signal is superimposed on the DC bias voltage at the gate, the instantaneous drain current comprises three...
 01:21
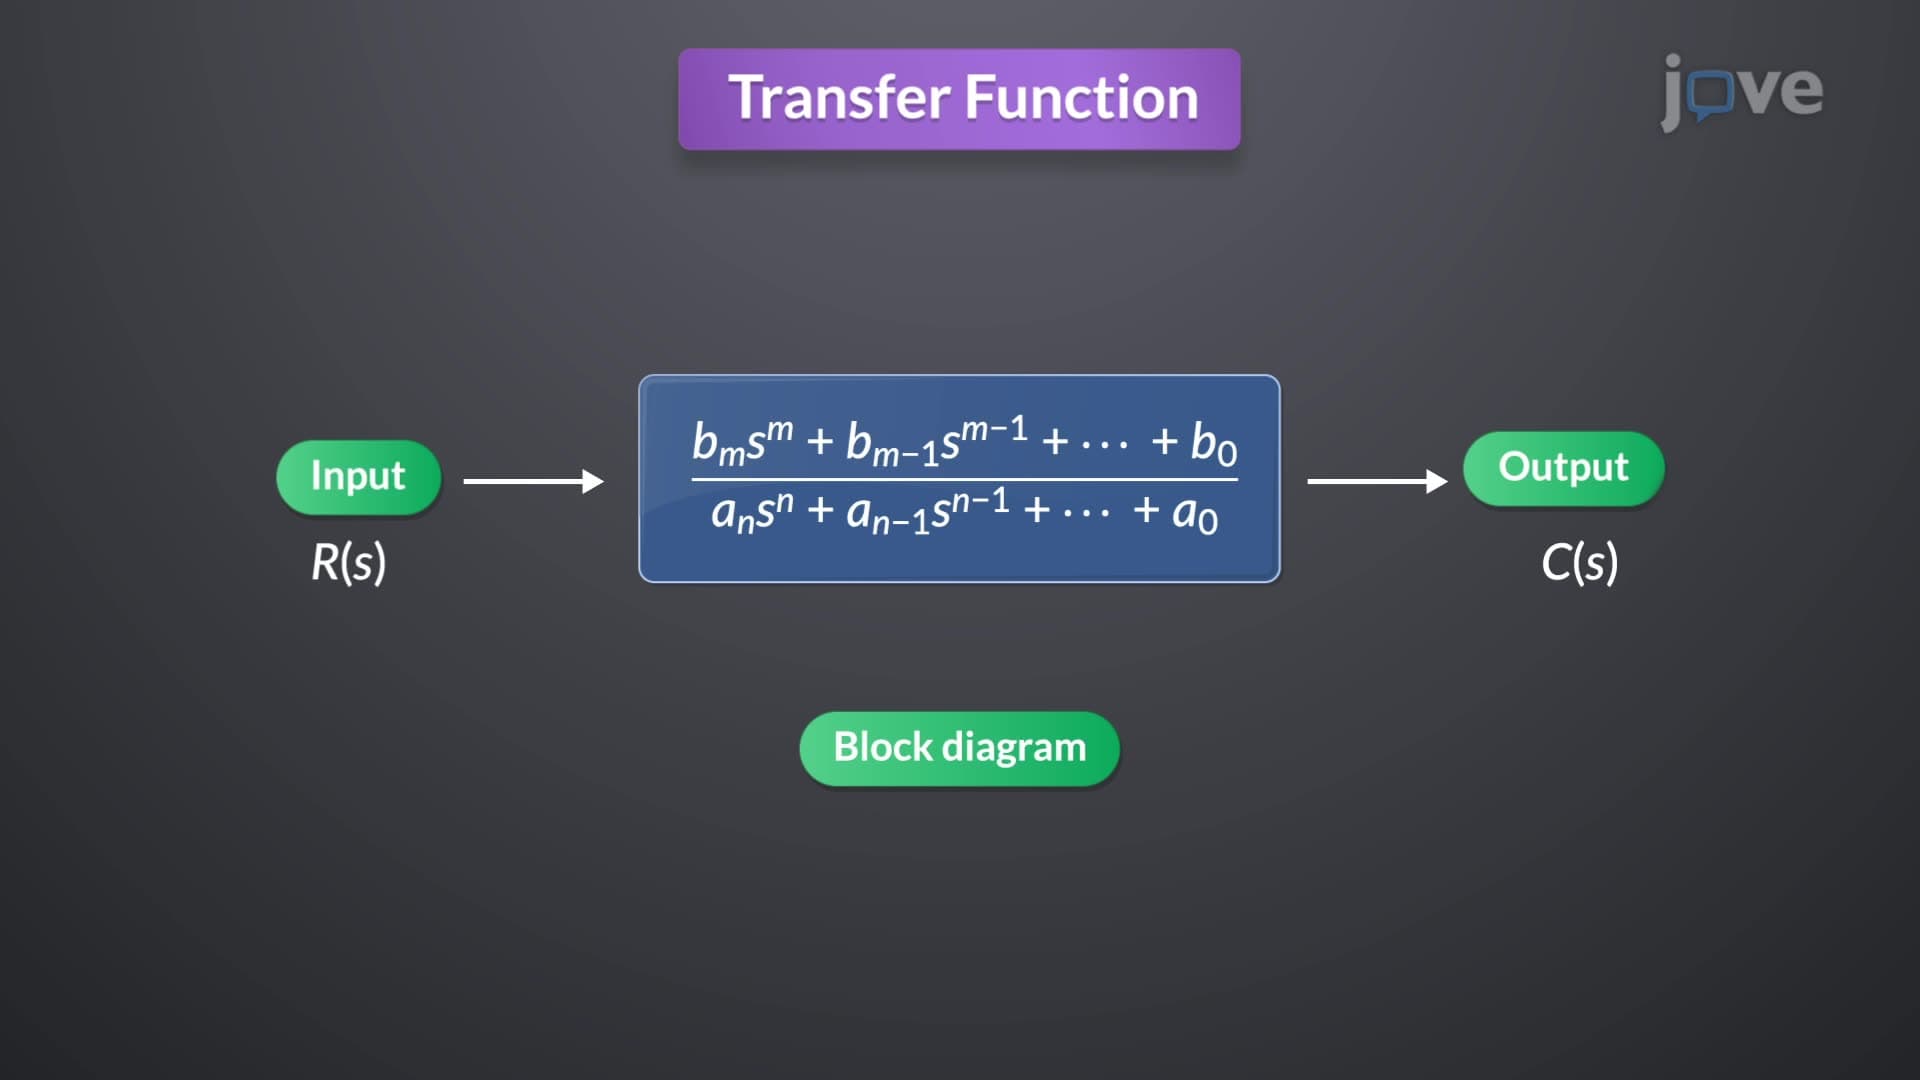
Transfer Function in Control Systems
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:23
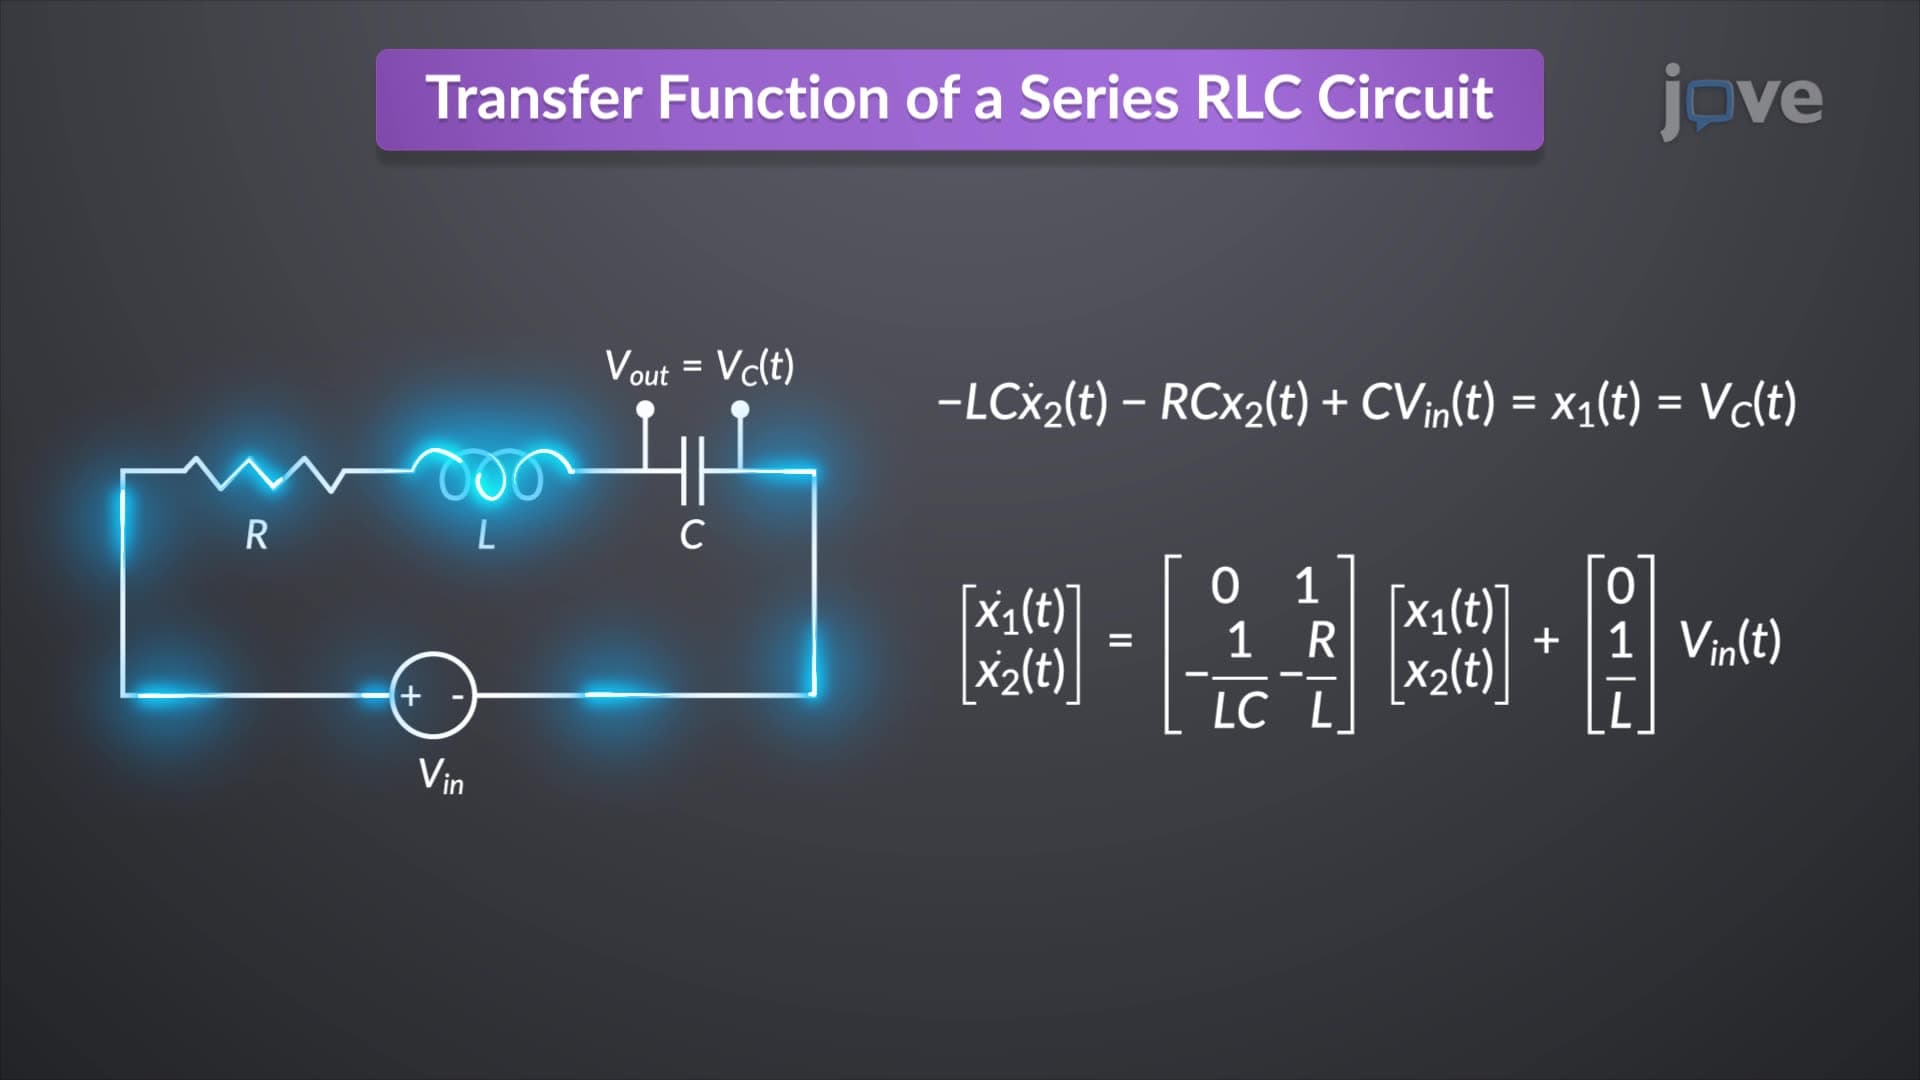
Transfer Function to State Space
State-space representation is a powerful tool for simulating physical systems on digital computers, necessitating the conversion of the transfer function into state-space form. Consider an nth-order linear differential equation with constant coefficients, like those encountered in an RLC circuit. The state variables are selected as the output and its n−1 derivatives. Differentiating these variables and substituting them back into the original equation produces the state equations.
In an RLC...
In an RLC...