Related Experiment Video
Updated: Jun 19, 2026
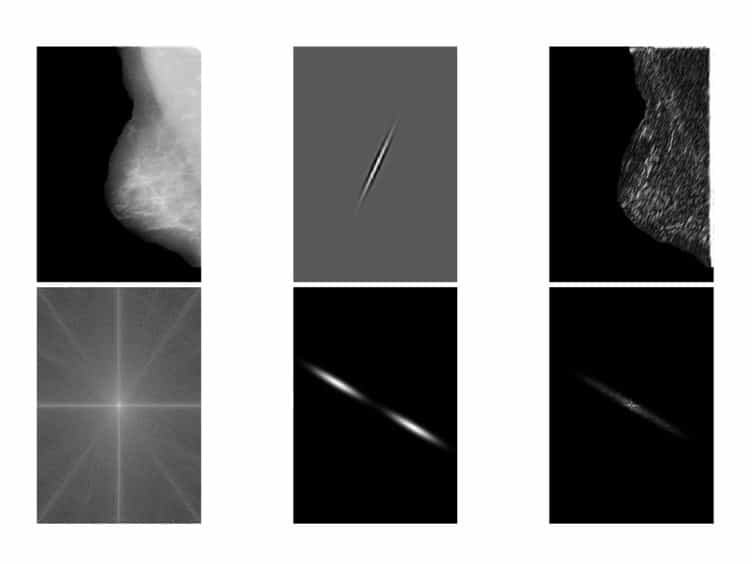
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Optimal average path of the instantaneous helical axis in planar motions with one functional degree of freedom
Alvaro Page1, Jose A Galvez, Helios de Rosario
1Instituto de Biomecánica de Valencia, Universidad Politécnica de Valencia Edificio 9C, Camino de Vera s/n, 46022 Valencia, Spain.

Abstract:
This paper presents a model for determining the path of the instantaneous helical axis (IHA) that optimally represents human planar motions with one functional degree of freedom (fDOF). A human movement is said to have one fDOF when all degrees of freedom (DOFs) are coordinated such that all the kinematic variables can be expressed, across movement repetitions, as functions of only one independent DOF, except for a small natural intercycle variability quantified as lower than a prespecified value. The concept of fDOF allows taking into account that, due to motor coordination, human movements are executed in a repeatable manner. Our method uses the measurement of several repetitions of a given movement to obtain the optimal average IHA path. The starting point is a change of variables, from time to a joint position magnitude (generally an angle). In this way, instead of operating with the time-dependent single-valued trajectory of the successive cycles, our model permits the representation of any motion variable (e.g. positions and their time derivatives) as a cloud of points dependent on the joint angle. This allows the averaging to be performed over the displacements and their derivatives before determining the mean IHA path. We thus avoid the nonlinear magnification of errors and variability inherent in the IHA computation. Moreover, the IHA path can be considered as a geometric attribute of the joint and the type of motion, rather than of each single movement execution. An experiment was performed that show the accuracy and usefulness of the method.
Related Concept Videos
 01:26
Rotational Motion about a Fixed Axis
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:27
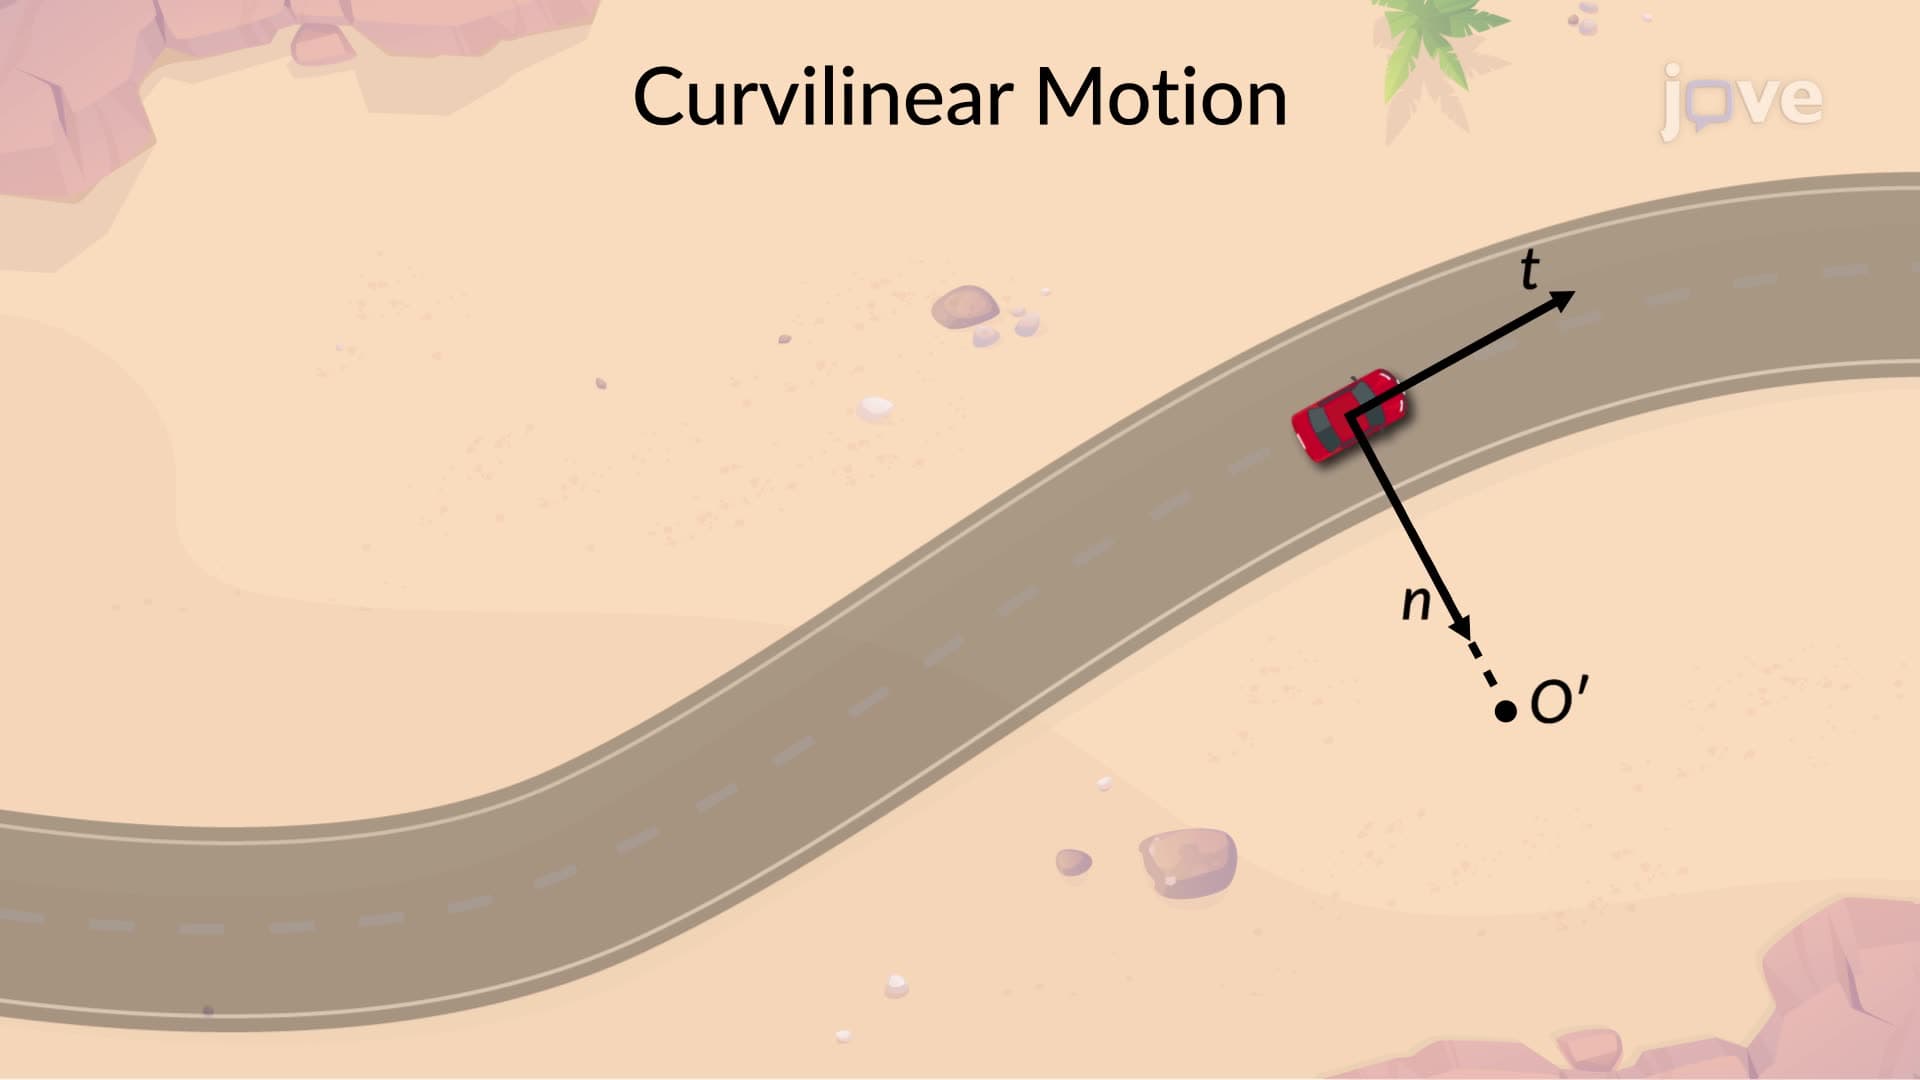
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:17
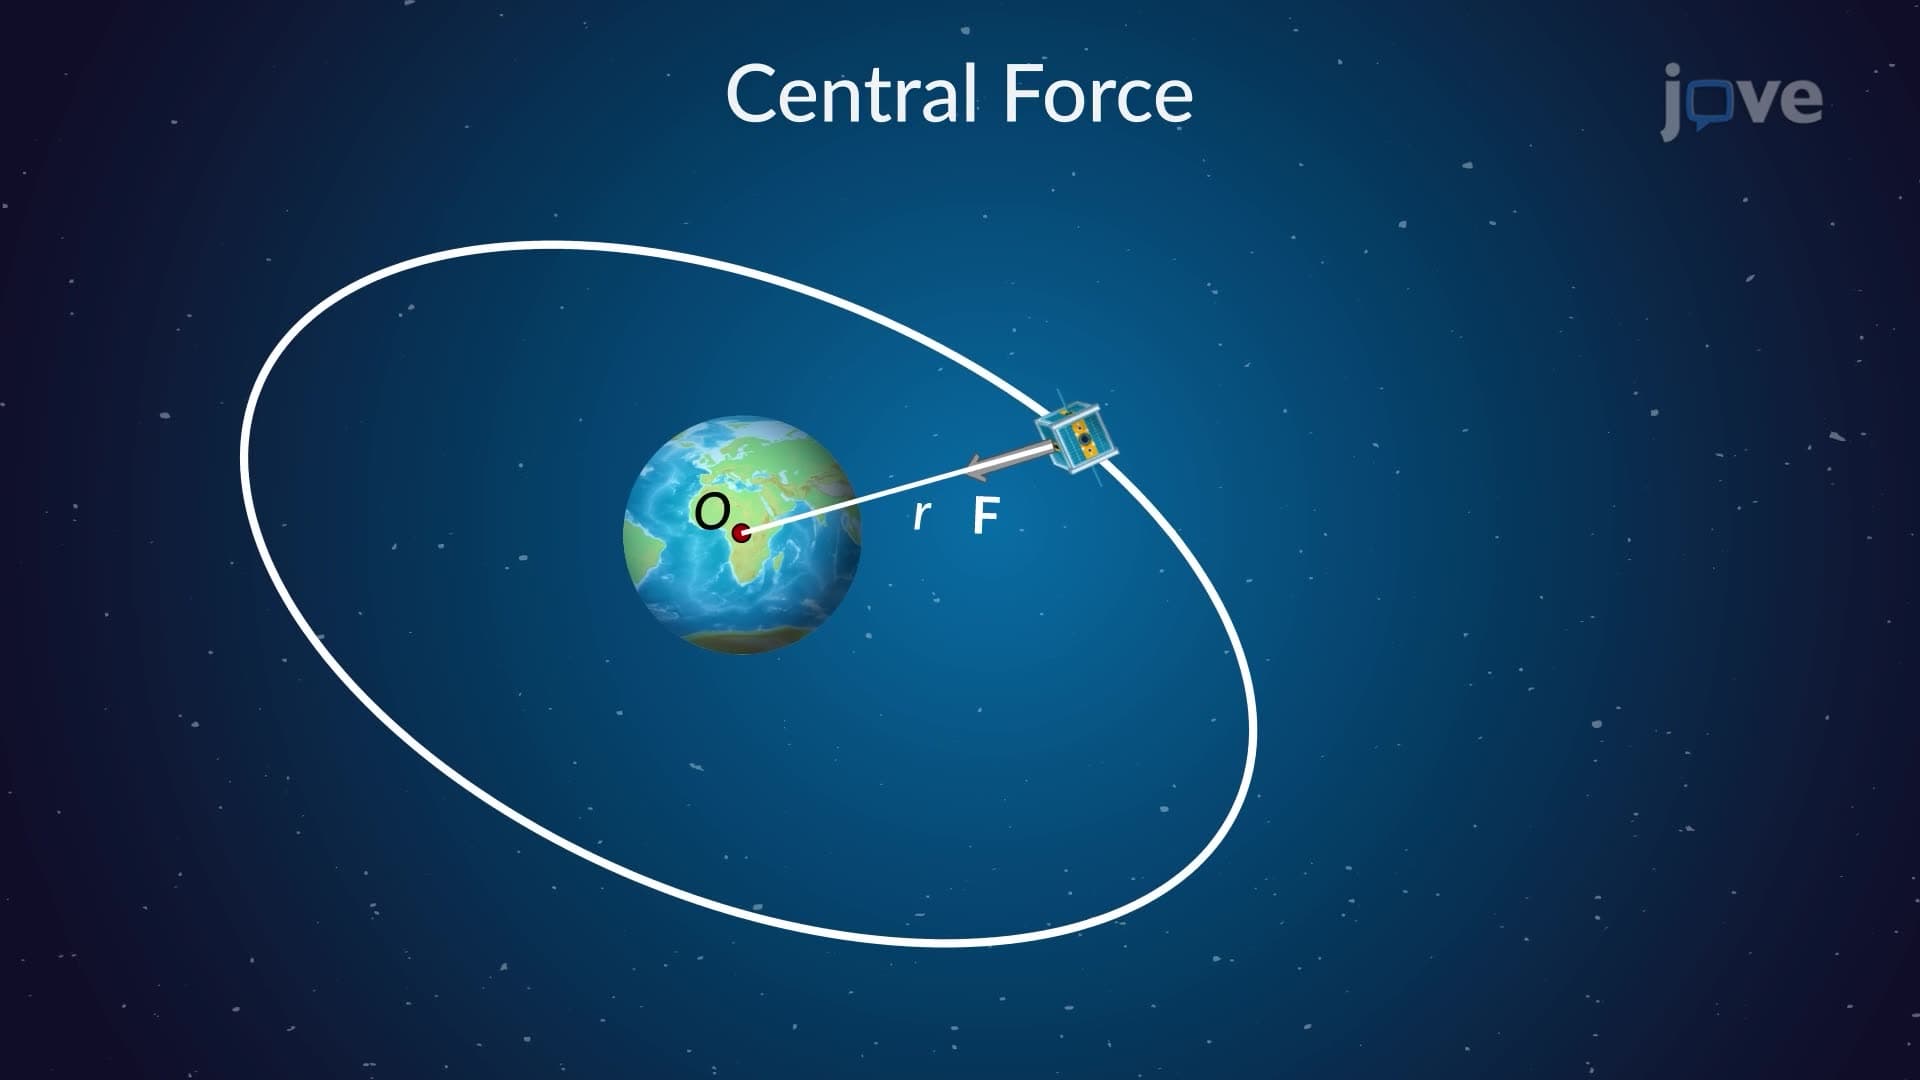
Central-Force Motion
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...