Related Experiment Video
Updated: Jun 10, 2026
Frame-by-Frame Video Analysis of Idiosyncratic Reach-to-Grasp Movements in Humans
Published on: January 15, 2018
Bimanual grasp planning reflects changing rather than fixed constraint dominance
Robrecht P R D van der Wel1, David A Rosenbaum
1Donders Institute for Brain, Cognition, and Behaviour, Radboud University Nijmegen, Nijmegen, The Netherlands. r.vanderwel@donders.ru.nl

Abstract:
We studied whether motor-control constraints for grasping objects that are moved to new positions reflect a rigid constraint hierarchy or a flexible constraint hierarchy. In two experiments, we asked participants to move two plungers from the same start locations to different target locations (both high, both low, or one high and one low). We found that participants grasped the plungers symmetrically and at heights that ensured comfortable or easy-to-control end postures when the plungers had the same target heights, but these grasp tendencies were reduced when the plungers had different target heights. In addition, when the plungers had different mass distributions, participants behaved in ways that suggested still-different emphases of the relevant grasp constraints. When the plungers had different mass distributions, participants sacrificed bimanual symmetry for end-state comfort. The results suggest that bimanual grasp planning relies on a flexible rather than static hierarchy. Different constraints take on different degrees of importance depending on the nature of the task and on the level of task experience. The results have implications for the understanding of perceptual-motor skill learning. It may be that one mechanism underlying such learning is changing the priorities of task constraints.
More Related Videos

Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:26
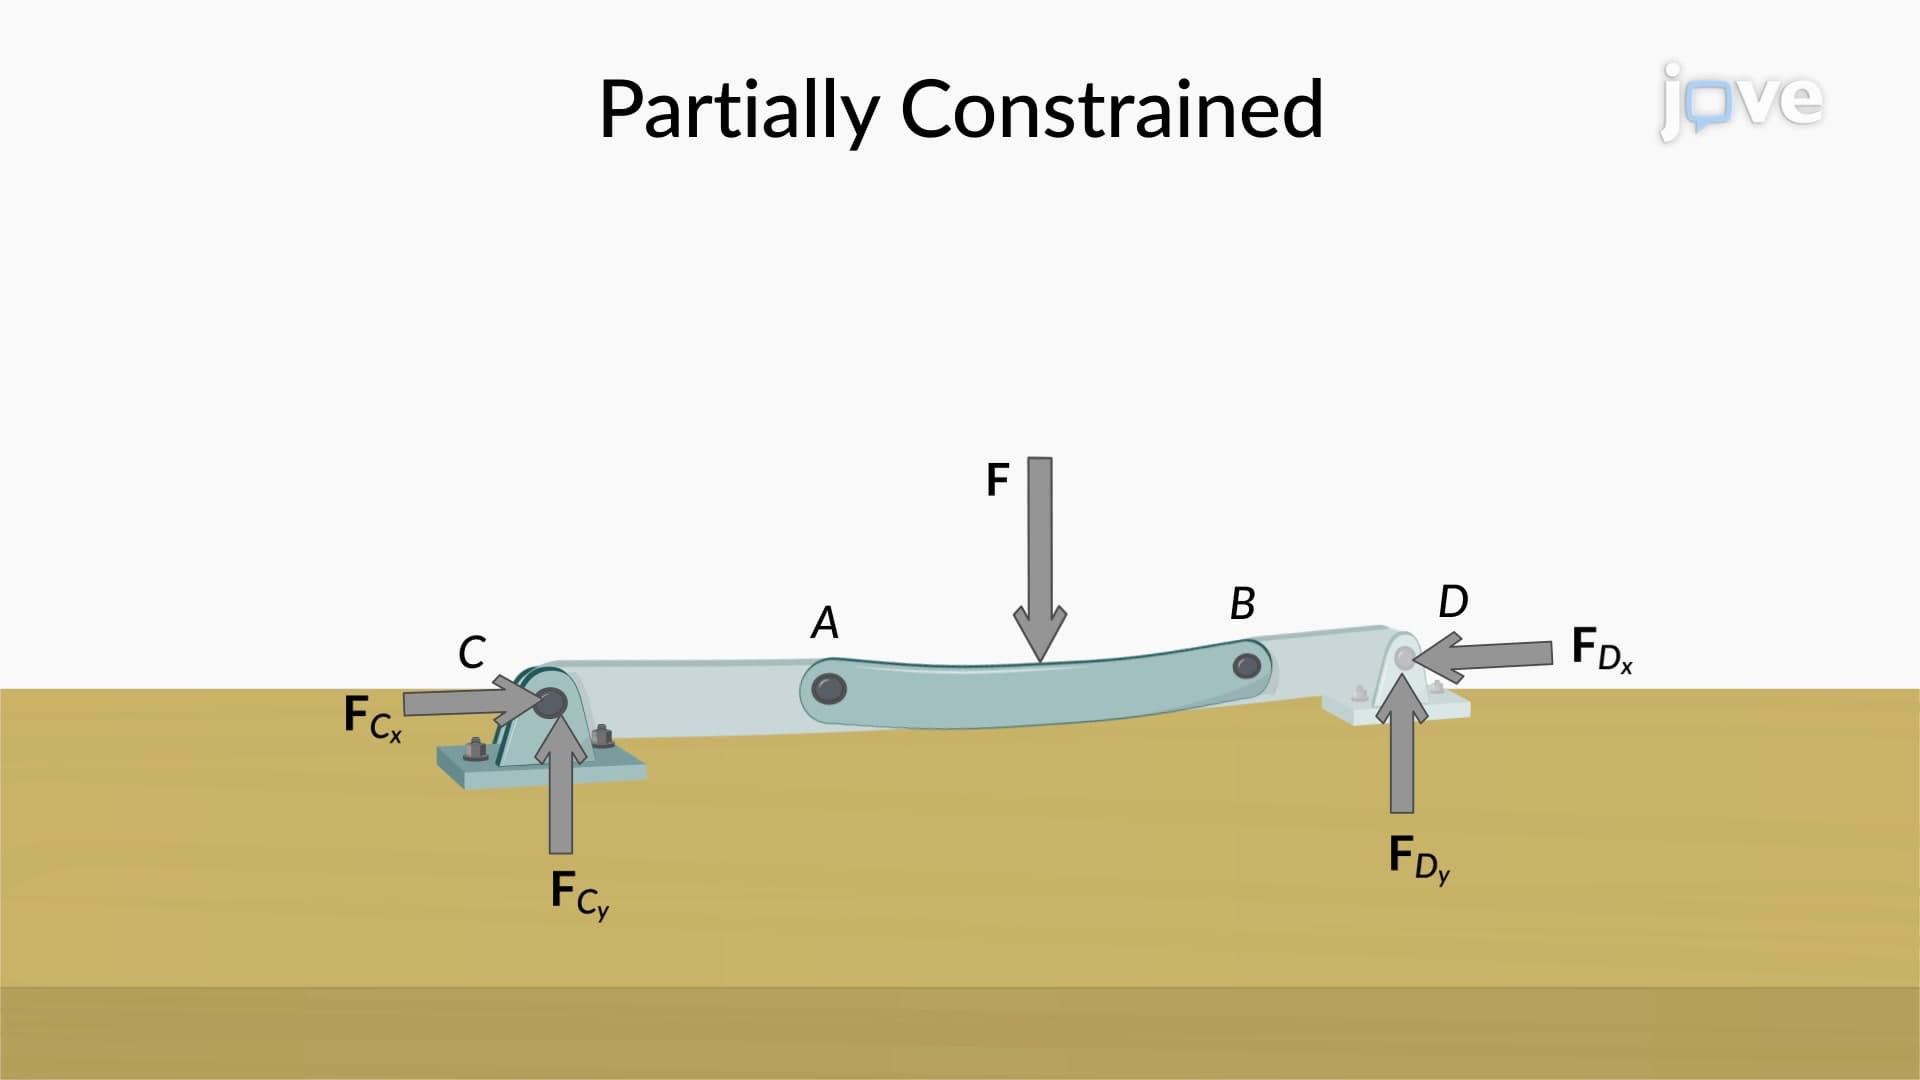
Constraints and Statical Determinacy
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:42
Schemas
 01:14
Plastic Deformations