Related Experiment Video
Updated: Jun 5, 2026
AMEBaS: Automatic Midline Extraction and Background Subtraction of Ratiometric Fluorescence Time-Lapses of Polarized Single Cells
Published on: June 23, 2023
ViBe: a universal background subtraction algorithm for video sequences
Olivier Barnich1, Marc Van Droogenbroeck
1EVS Broadcast Equipment, Liege Science Park, B-4102 Seraing, Belgium. olivier.barnich@gmail.com

Abstract:
This paper presents a technique for motion detection that incorporates several innovative mechanisms. For example, our proposed technique stores, for each pixel, a set of values taken in the past at the same location or in the neighborhood. It then compares this set to the current pixel value in order to determine whether that pixel belongs to the background, and adapts the model by choosing randomly which values to substitute from the background model. This approach differs from those based upon the classical belief that the oldest values should be replaced first. Finally, when the pixel is found to be part of the background, its value is propagated into the background model of a neighboring pixel. We describe our method in full details (including pseudo-code and the parameter values used) and compare it to other background subtraction techniques. Efficiency figures show that our method outperforms recent and proven state-of-the-art methods in terms of both computation speed and detection rate. We also analyze the performance of a downscaled version of our algorithm to the absolute minimum of one comparison and one byte of memory per pixel. It appears that even such a simplified version of our algorithm performs better than mainstream techniques.
Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:20
Deconvolution
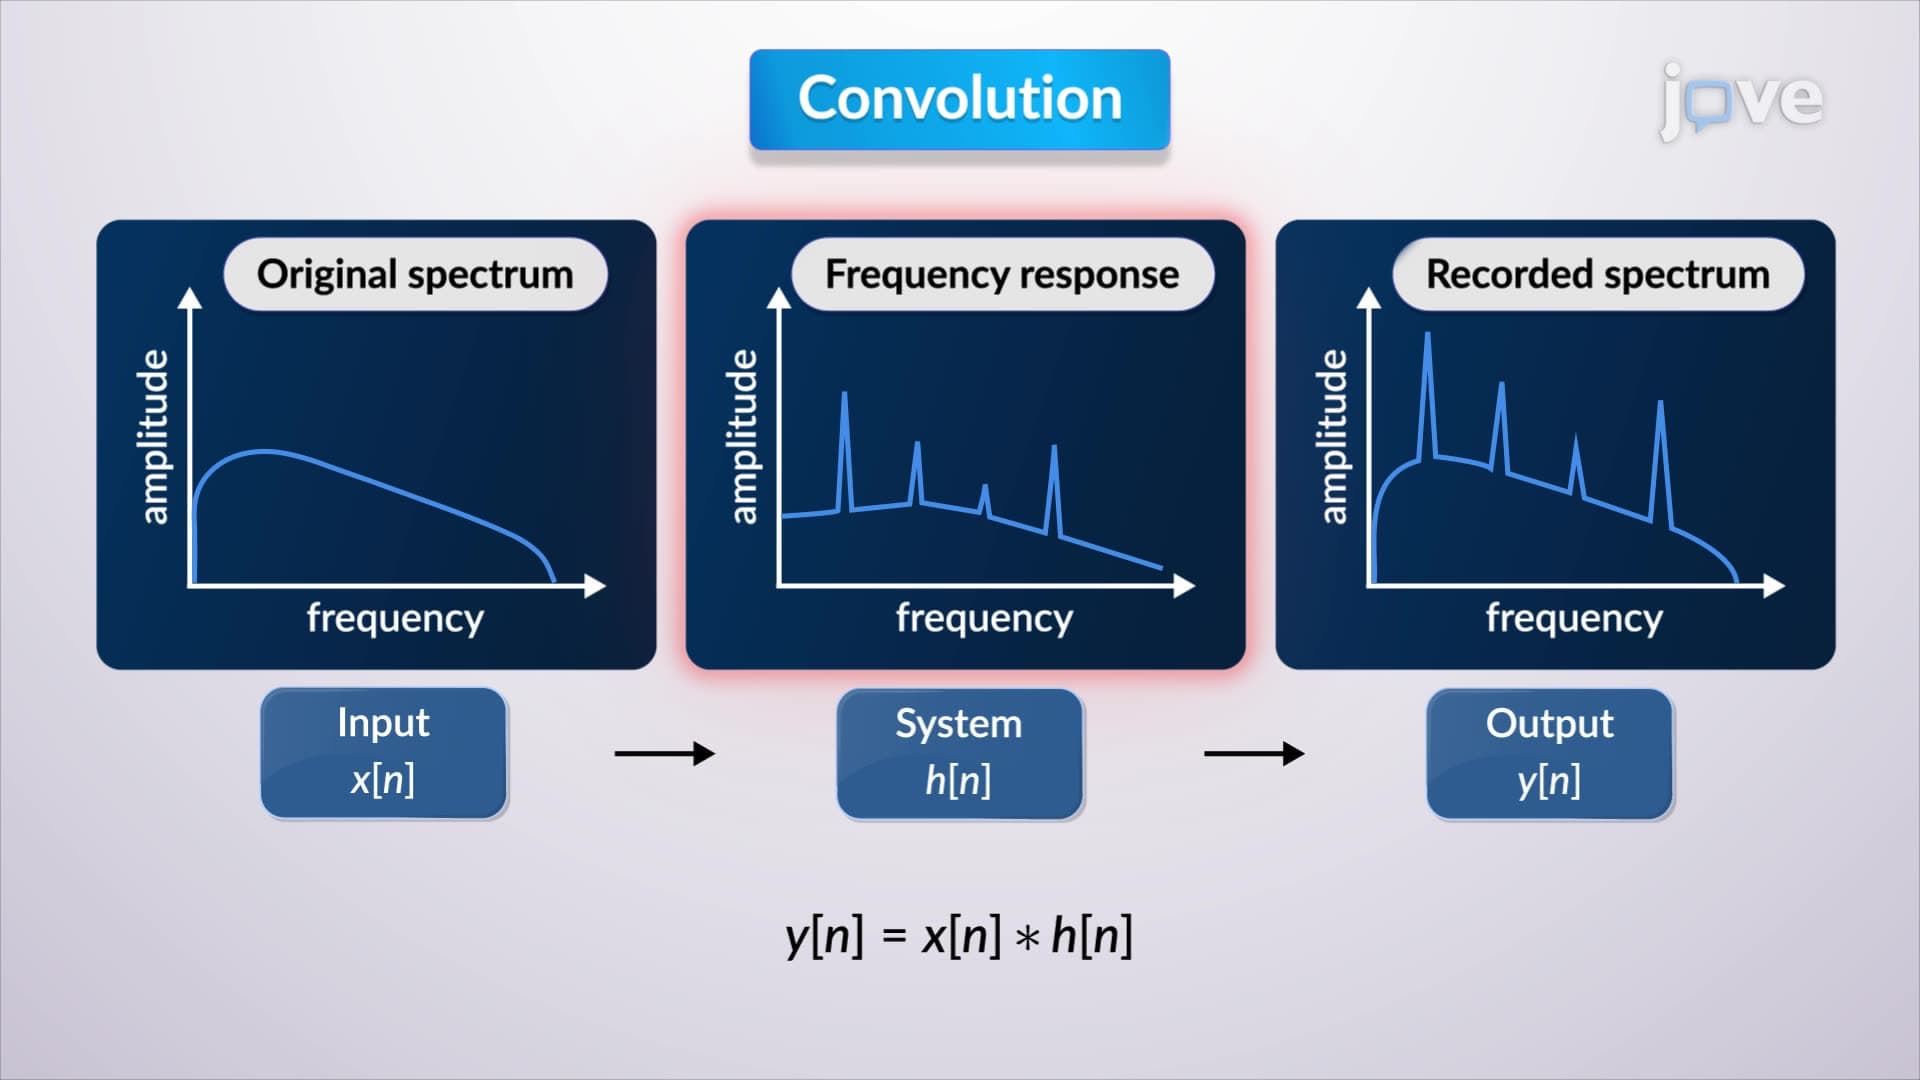
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:10
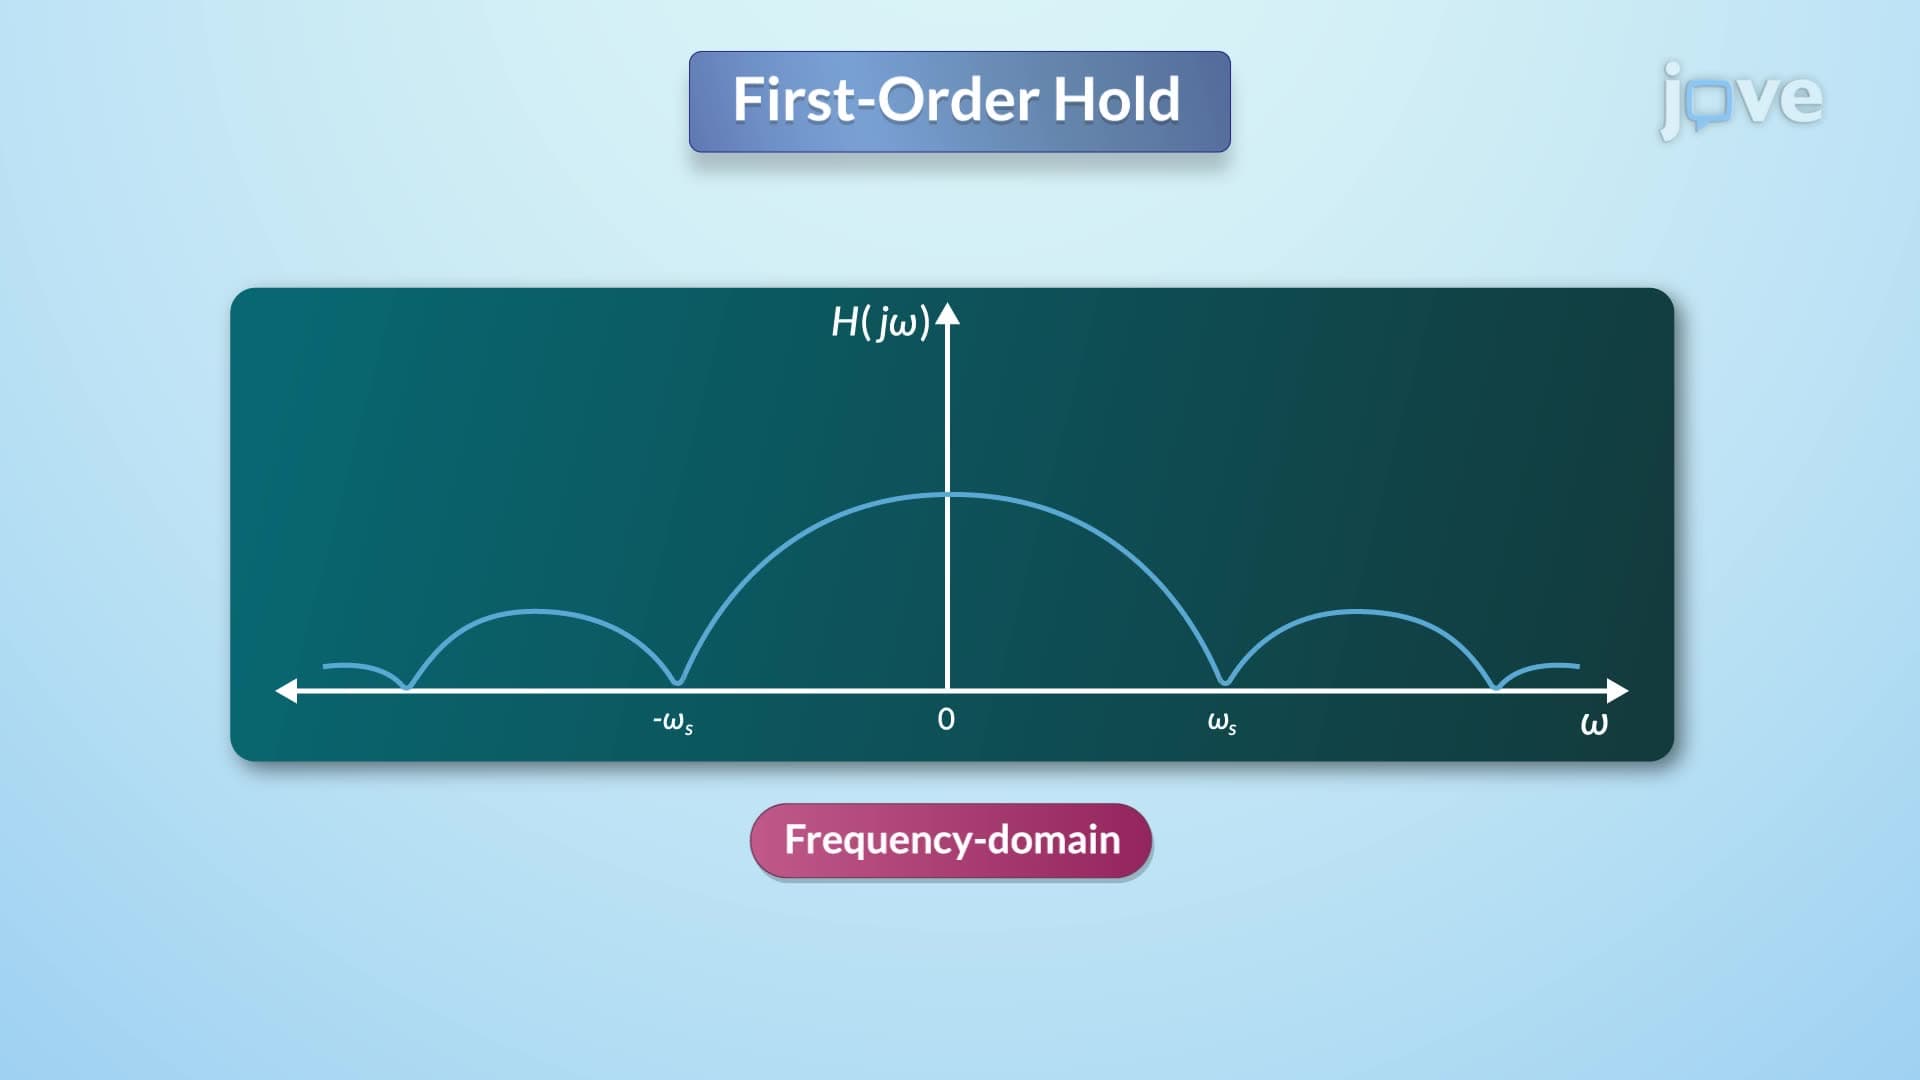
Reconstruction of Signal using Interpolation