Related Experiment Video
Updated: May 31, 2026
Biomechanical Analysis Methods to Assess Professional Badminton Players' Lunge Performance
Published on: June 11, 2019
Time to stability differences between male and female dancers after landing from a jump on flat and inclined floors
Evangelos Pappas1, Ian Kremenic, Marijeanne Liederbach
1Division of Physical Therapy, Long Island University, Brooklyn, New York 11201, USA. evangelos.pappas@liu.edu

Objective:
To determine the effect of gender and inclined floor on time to stability (TTS) after landing from a vertical jump.
Design:
This study used a repeated measures design with male and female professional dancers landing on a flat and 4 inclined floors. A repeated measures univariate analysis of variance (gender × floor) was performed on TTS in the anterior-posterior and medial-lateral directions.
Setting:
Biomechanics laboratory.
Participants:
Twenty-three female and 13 male professional dancers.
Independent Variables:
Gender and floor inclination (flat, posterior, anterior, lateral, and medial).
Main Outcome Measures:
Time to stability in the anterior-posterior and medial-lateral directions after landing from a vertical jump.
Results:
Female dancers exhibited longer TTS in both directions (P ≤ 0.05). Floor inclination or the interaction of gender × floor did not have an effect on TTS (P > 0.3).
Conclusions:
Female dancers exhibited longer TTS after landing from a vertical jump compared with their male counterparts. This balance difference may be a factor related to the higher rate of ankle sprain among female dancers. Additionally, professional dancers exhibited similar TTS when landing on flat and inclined floors.
More Related Videos
 07:52
Evaluating Postural Control and Lower-extremity Muscle Activation in Individuals with Chronic Ankle Instability
Published on: September 18, 2020
 10:08
Effects of a Novel Neuromuscular Training Intervention on Jump, Sprint, and Change of Direction in Adult Female Soccer Players
Published on: June 10, 2025
Related Concept Videos
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:20
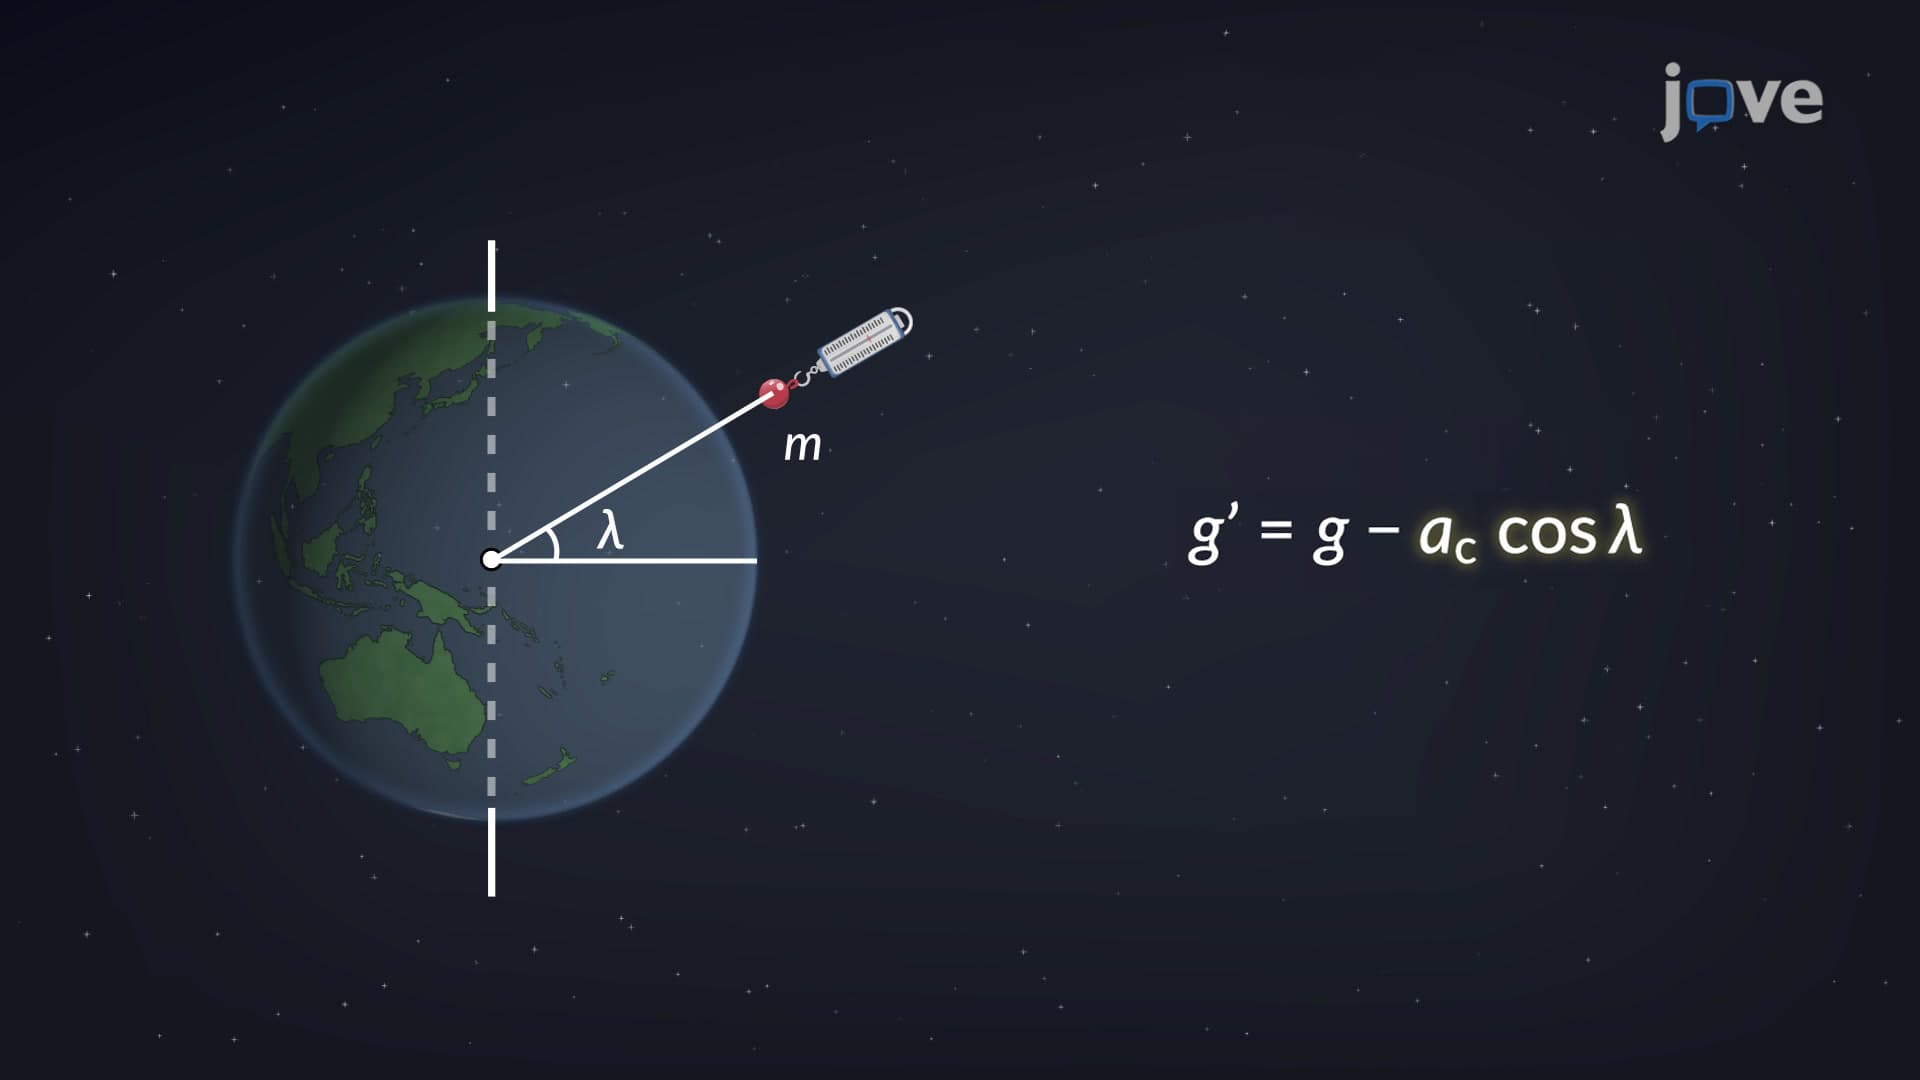
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's angular speed. Since the...
 01:05
Static Equilibrium - I
 00:49
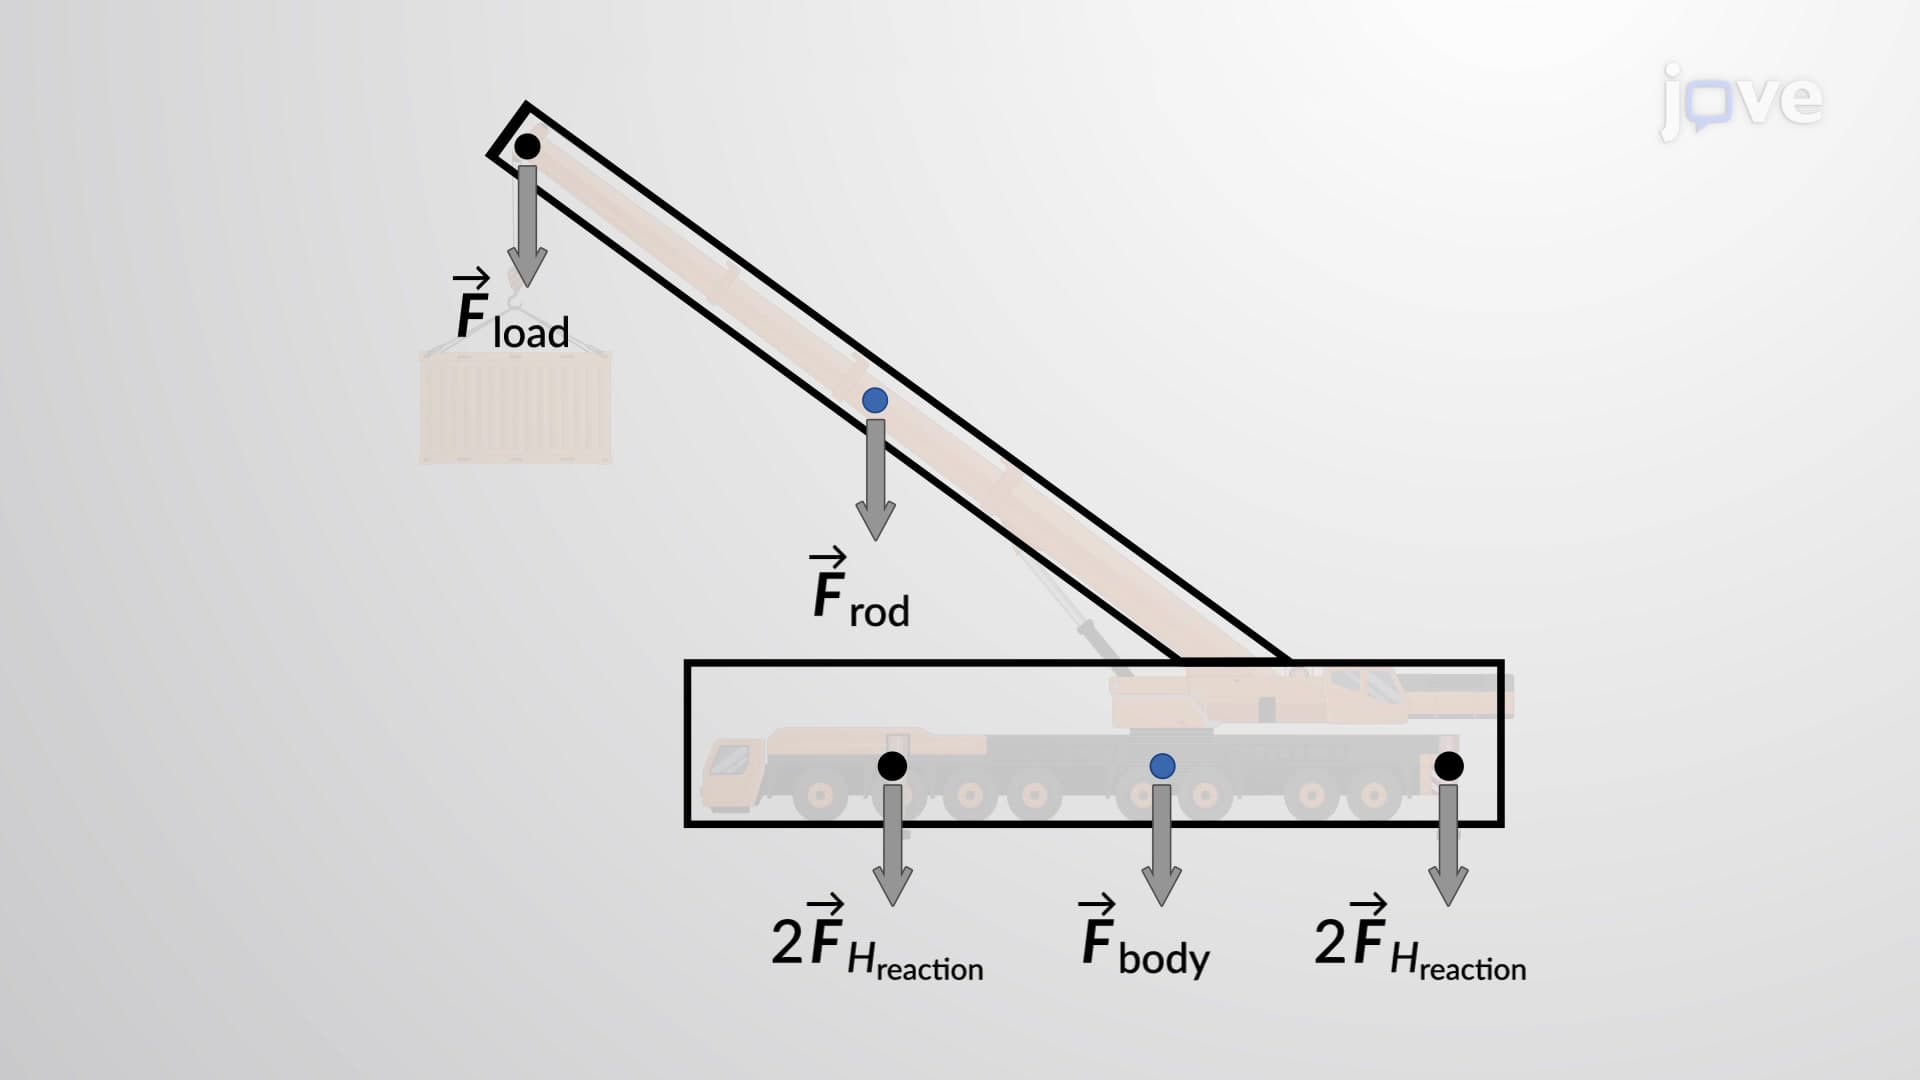
Rigid Body Equilibrium Problems - I
 01:07
Static Equilibrium - II