Partial stabilization of uncertain nonlinear systems
Related Experiment Video
Updated: May 27, 2026
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
1School of Electrical and Electronic Engineering, Shiraz University of Technology, Modares Blvd., P.O. Box 71555/313, Shiraz, Iran. binazadeh@sutech.ac.ir

Abstract:
In this paper, the problem of robust partial stabilization is considered and two approaches for partial stabilization of uncertain nonlinear systems are presented. In these approaches, the nonlinear dynamical system is divided into two subsystems, which are called the first and the second subsystems. This division is done based on the required stability properties of the system's states. The reduced input vector (the vector that includes components of the input vector appearing in the first subsystem) is designed to asymptotically stabilize the first subsystem. In the first approach, a new partial stabilization technique, based on the first order sliding mode control idea is proposed. In the proposed method, hereafter called the partial sliding mode, a sliding surface is designed such that restricting the motion on this surface guarantees the stability of only the first part of the system's state. In the second approach, a Lyapunov-based controller is proposed for partial stabilization and then an additional feedback control is designed so that the overall feedback law guarantees a robust manner in the presence of uncertainties.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:16
Statically Indeterminate Problem Solving
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:28
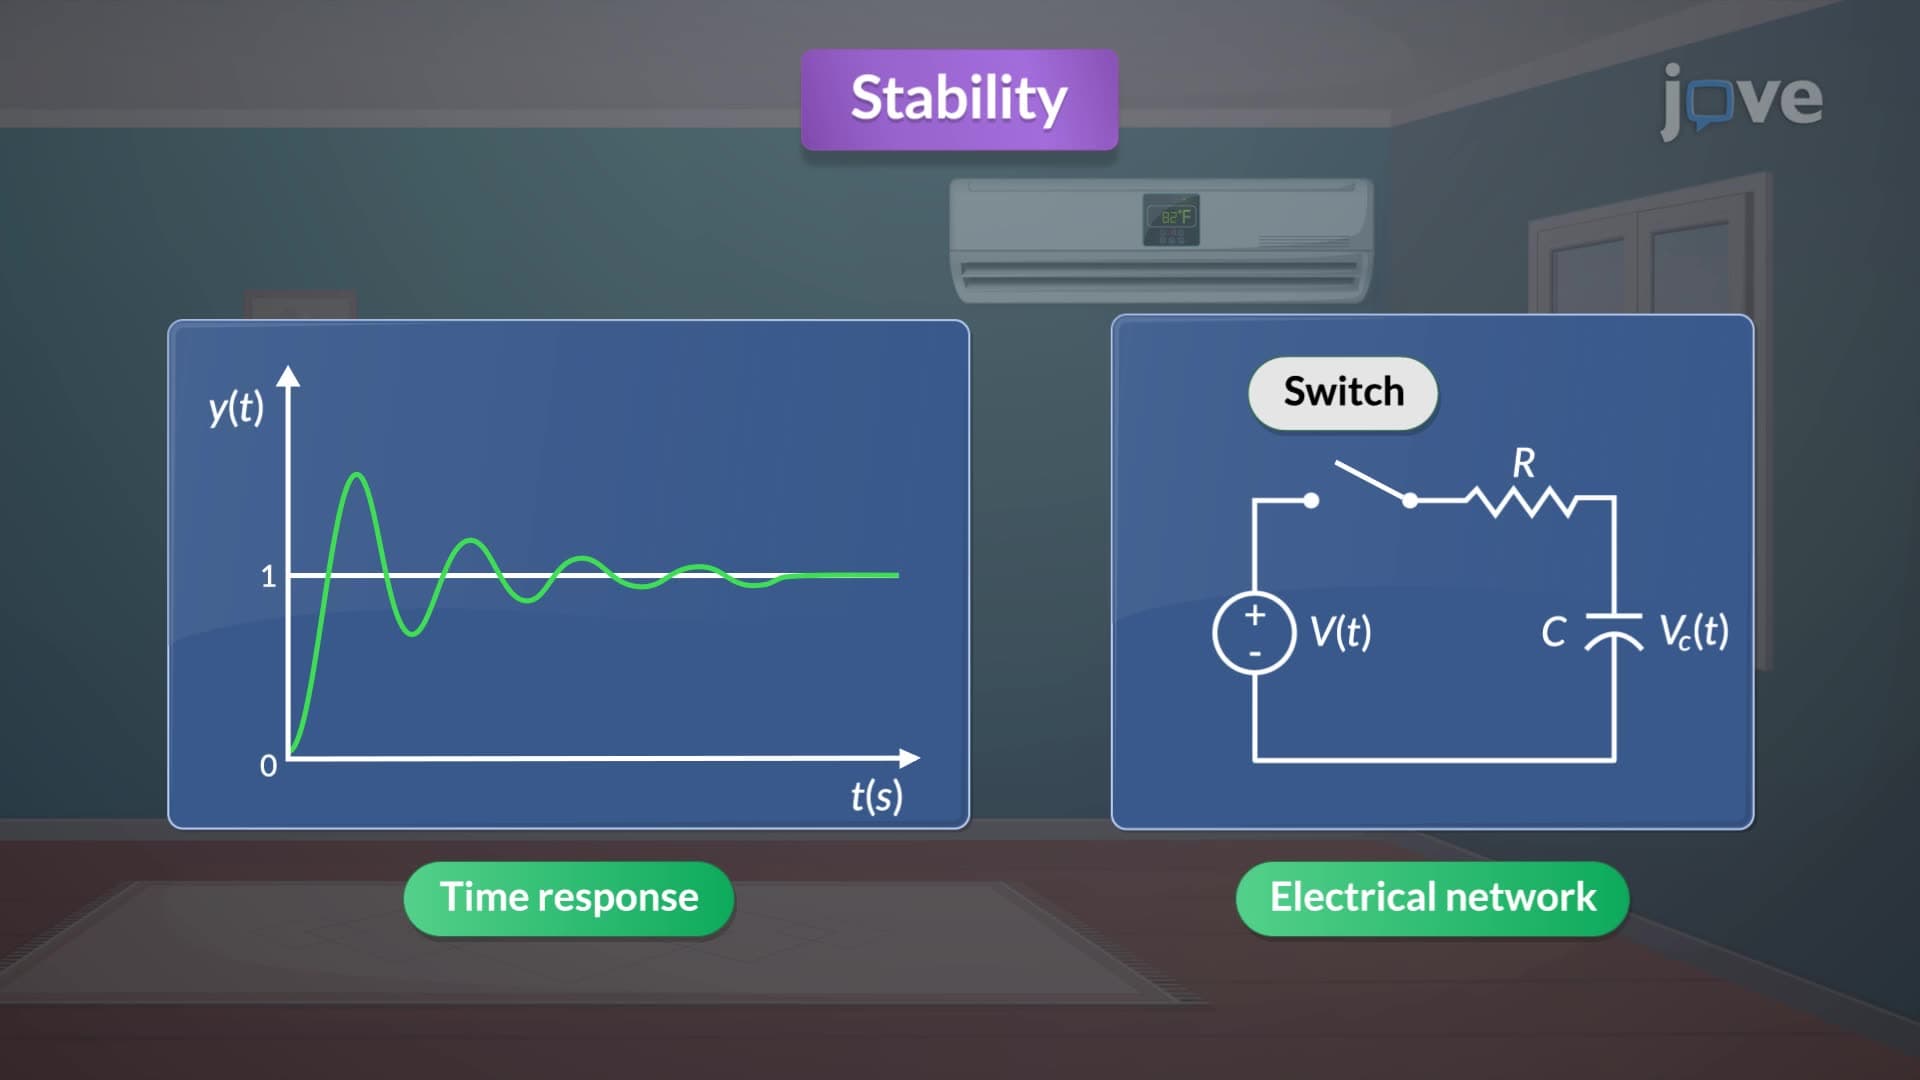
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.