Related Experiment Video
Updated: May 24, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Adaptive optimal control without weight transport
Lakshminarayan V Chinta1, Douglas B Tweed
1Department of Physiology, University of Toronto, Toronto, Ontario M5S 1A8, Canada. lakshminarayan.chinta@utoronto.ca

Abstract:
Many neural control systems are at least roughly optimized, but how is optimal control learned? There are algorithms for this purpose, but in their current forms, they are not suited for biological neural networks because they rely on a type of communication that is not available in the brain, namely, weight transport-transmitting the strengths, or "weights," of individual synapses to other synapses and neurons. Here we show how optimal control can be learned without weight transport. Our method involves a set of simple mechanisms that can compensate for the absence of weight transport in the brain and so may be useful for neural computation generally.
Related Concept Videos
 01:28
Load-frequency control
 01:10
Control Systems
At the heart...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:14
Conservation of Mass in Moving, Nondeforming Control Volume
In the context of a detention basin, the conservation of mass states that the total mass of water entering the basin must equal the mass leaving the basin plus any accumulation of...
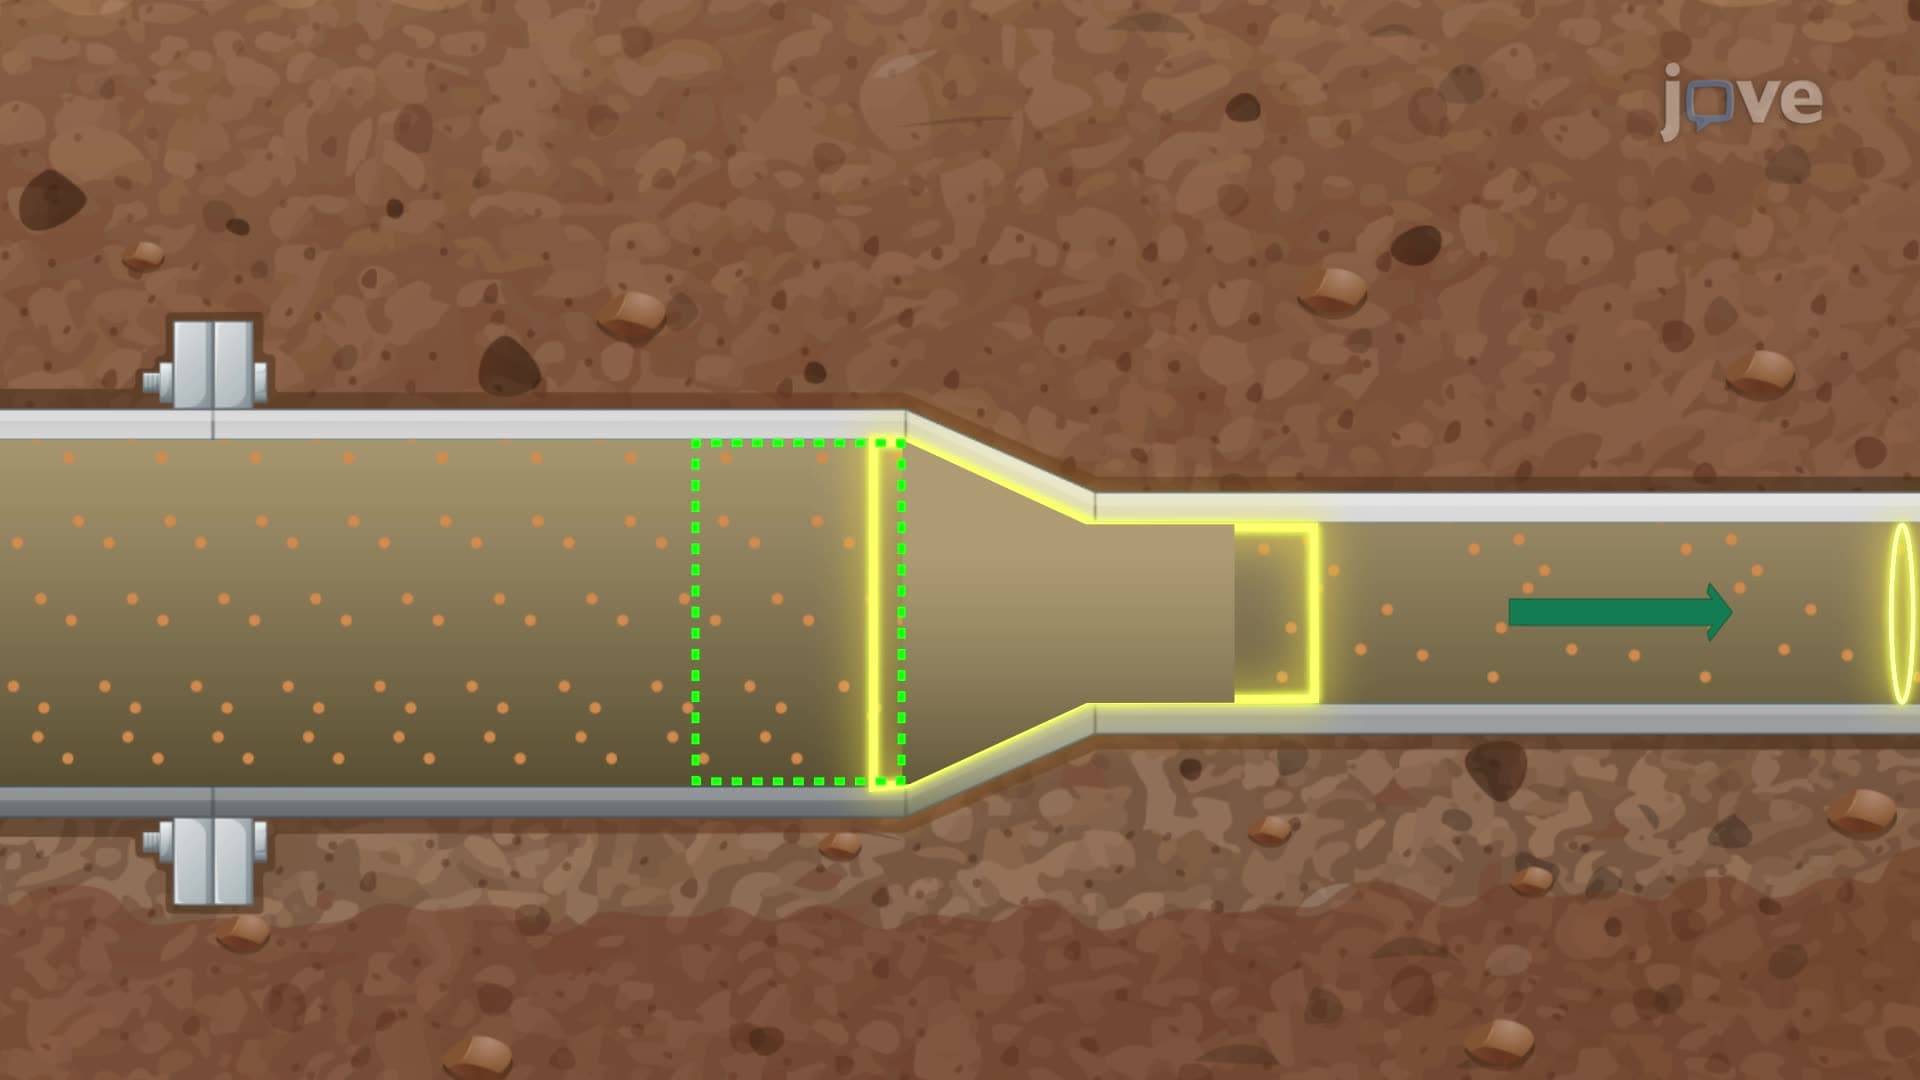 01:07
Conservation of Mass in Fixed, Nondeforming Control Volume
In the case of a sewer pipe, which can be modeled...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...