Related Experiment Video
Updated: May 19, 2026

Surgical Swine Model of Chronic Cardiac Ischemia Treated by Off-Pump Coronary Artery Bypass Graft Surgery
Published on: March 27, 2018
History and current status of robotic totally endoscopic coronary artery bypass
Jeffrey D Lee1, Mukta Srivastava, Johannes Bonatti
1Division of Cardiac Surgery, Department of Surgery, University of Maryland School of Medicine, Baltimore, MD, USA. jlee@smail.umaryland.edu

Abstract:
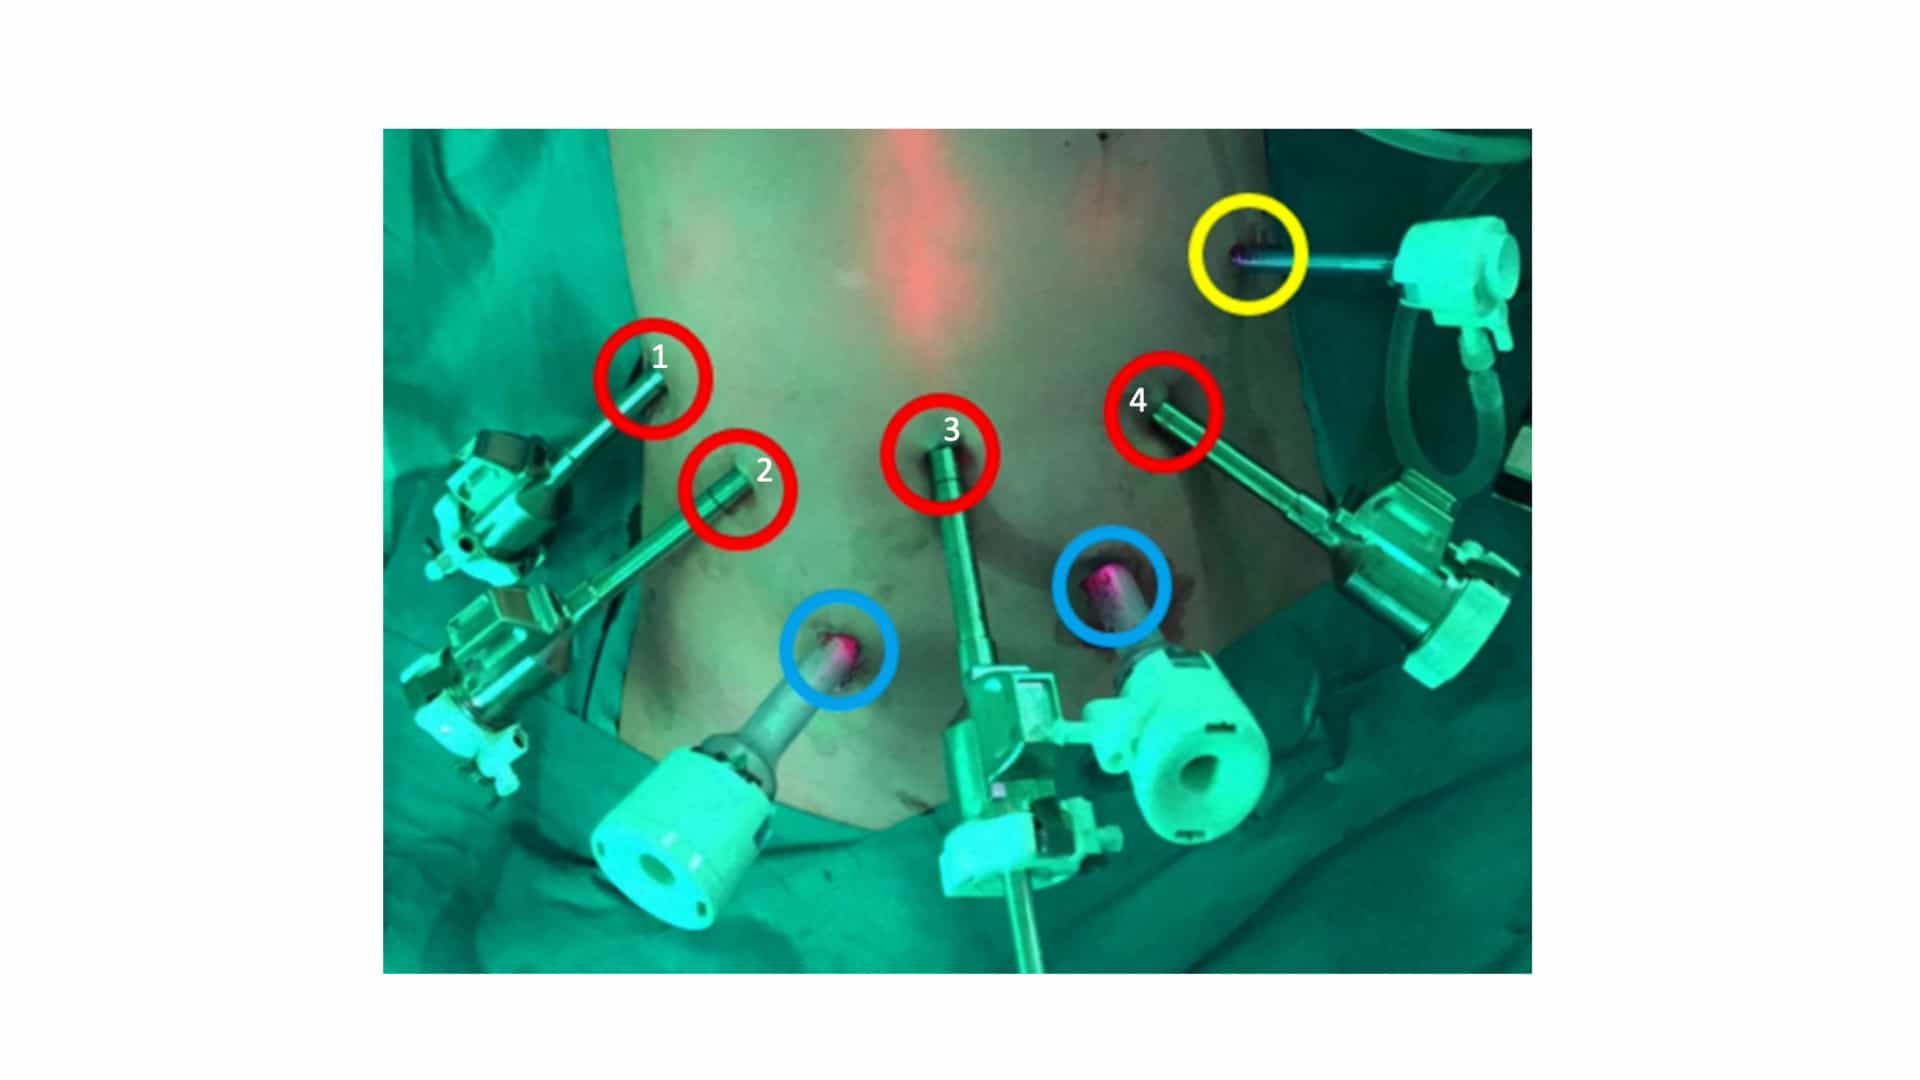
Robotic totally endoscopic coronary artery bypass (TECAB) is a minimally invasive endoscopic surgical approach using the daVinci robotic telemanipulation system to perform coronary artery bypass grafting on the arrested or beating heart. It is a procedure that can be a useful alternative to the classic open procedure performed through sternotomy. After extensive modeling in cadavers, the first clinical case was performed in June 1998 placing a left internal thoracic artery graft (LITA) to the left anterior descending artery completely robotically on the arrested heart. During the early and late 2000s, international groups have adopted this evolving technology, which has included iterations such as beating-heart TECAB, use of bilateral ITA grafting and radial artery grafting, as well as 3- and 4-vessel TECAB. TECAB is combined with percutaneous coronary intervention in hybrid procedures. Despite increasing complexity of endoscopic coronary bypass surgery, conversion rates to open bypass surgery have dropped significantly and operative times have decreased. Published major morbidities and mortality rates in arrested-and beating-heart TECAB have been cumulatively in the 0-2% range and are considered well within the expected range for these highly complex surgical procedures. Long-term survival and freedom from major adverse events also meet the standards of open bypass surgery.