Related Experiment Video
Updated: May 17, 2026
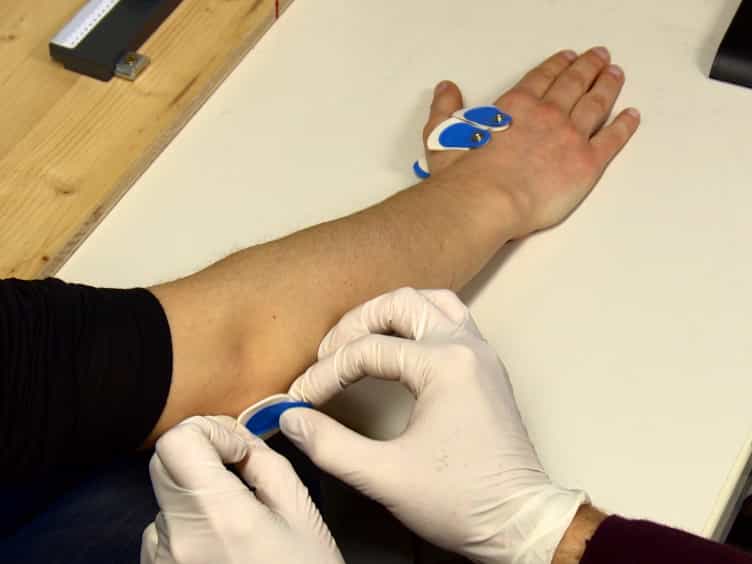

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Forces and moments generated by the human arm: variability and control
Y Xu1, A V Terekhov, M L Latash
1Department of Kinesiology, The Pennsylvania State University, University Park, PA 16802, USA. yangxu@psu.edu

Abstract:
This is an exploratory study of the accurate endpoint force vector production by the human arm in isometric conditions. We formulated three common-sense hypotheses and falsified them in the experiment. The subjects (n = 10) exerted static forces on the handle in eight directions in a horizontal plane for 25 s. The forces were of 4 magnitude levels (10, 20, 30 and 40 % of individual maximal voluntary contractions). The torsion moment on the handle (grasp moment) was not specified in the instruction. The two force components and the grasp moment were recorded, and the shoulder, elbow, and wrist joint torques were computed. The following main facts were observed: (a) While the grasp moment was not prescribed by the instruction, it was always produced. The moment magnitude and direction depended on the instructed force magnitude and direction. (b) The within-trial angular variability of the exerted force vector (angular precision) did not depend on the target force magnitude (a small negative correlation was observed). (c) Across the target force directions, the variability of the exerted force magnitude and directional variability exhibited opposite trends: In the directions where the variability of force magnitude was maximal, the directional variability was minimal and vice versa. (d) The time profiles of joint torques in the trials were always positively correlated, even for the force directions where flexion torque was produced at one joint and extension torque was produced at the other joint. (e) The correlations between the grasp moment and the wrist torque were negative across the tasks and positive within the individual trials. (f) In static serial kinematic chains, the pattern of the joint torques distribution could not be explained by an optimization cost function additive with respect to the torques. Plans for several future experiments have been suggested.

Related Concept Videos
 01:20
Principle of Moments
The moment is calculated by multiplying the magnitude of the force by the perpendicular distance from the point of application to the point about...
 01:31
Muscles that Move the Arm
The pectoralis major has two origins. Its clavicular head originates on the medial half of the clavicle. In contrast, the sternocostal head originates on the costal cartilages of ribs 1-6, the sternum, and the aponeurosis of the external oblique of the...
 01:27
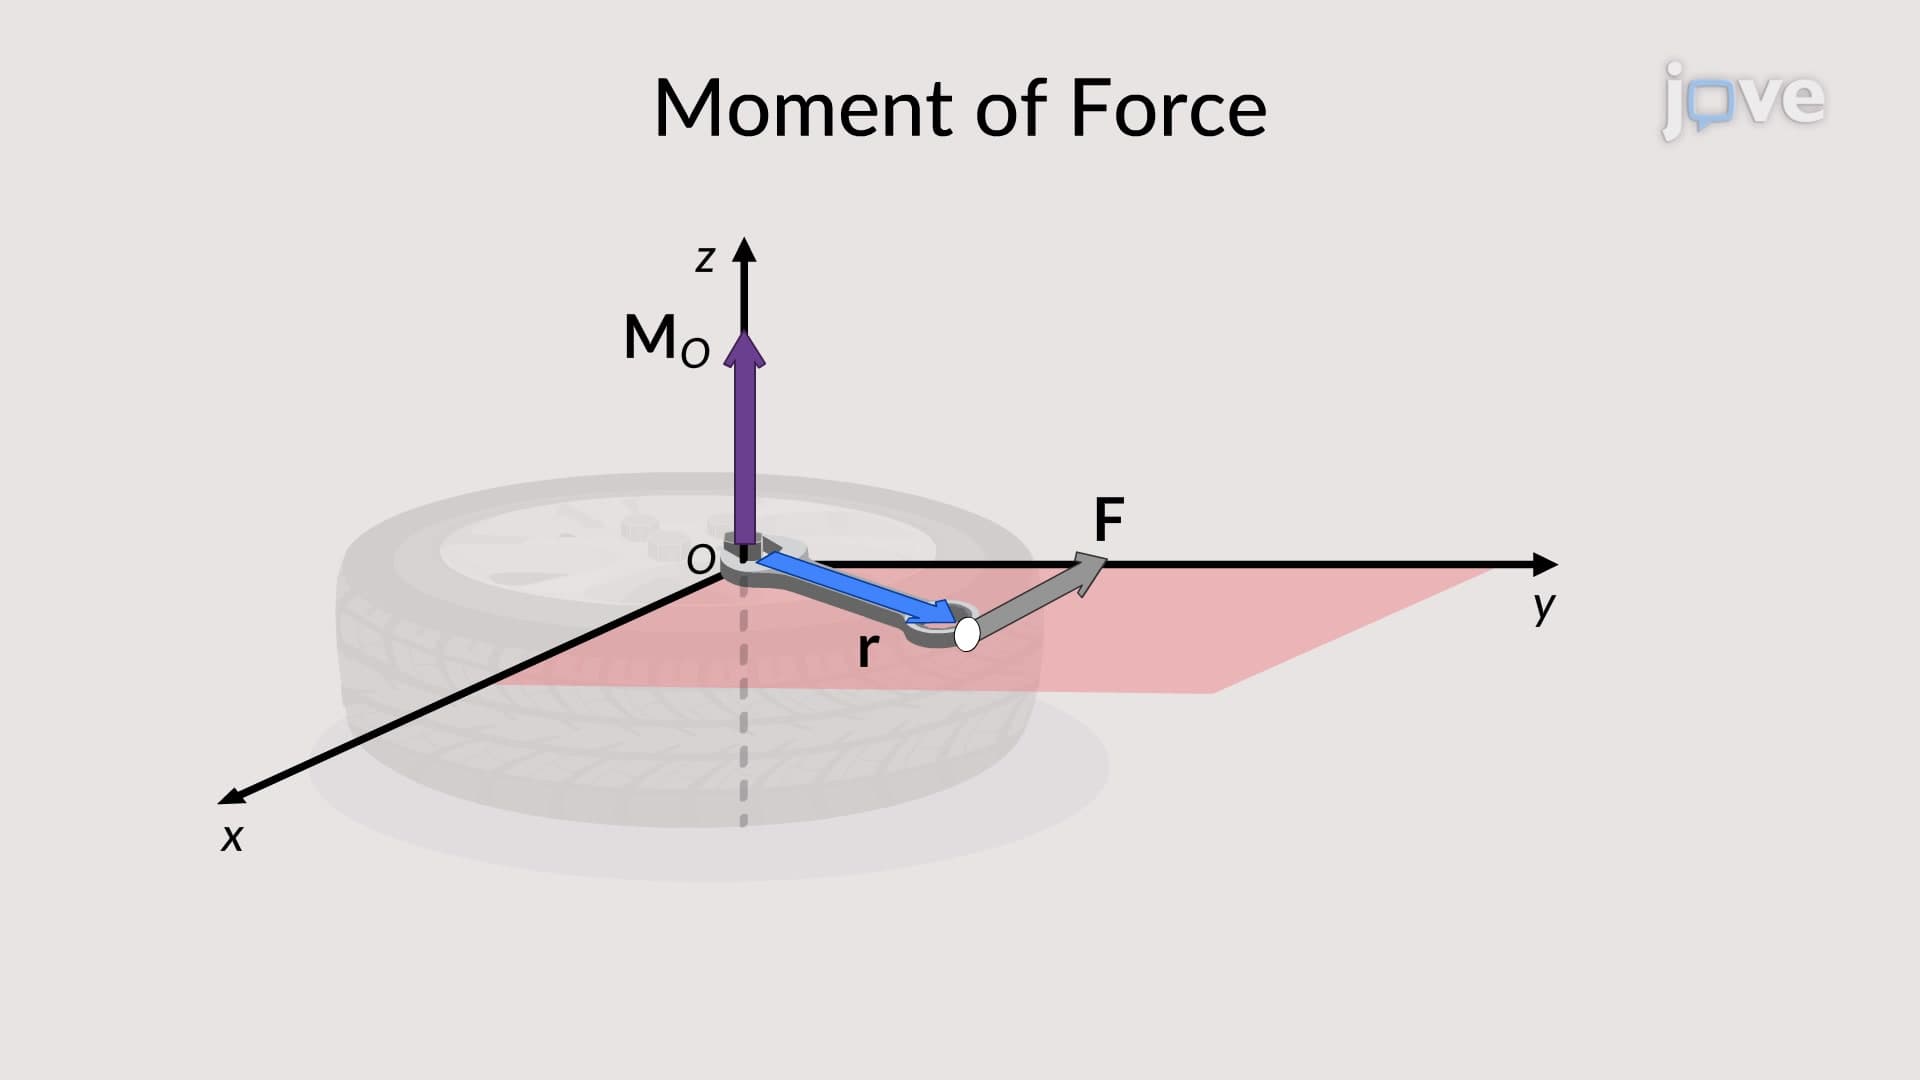
Moment of a Force: Vector Formulation
The vector formulation of the moment of force is the cross-product of the position and force vectors. The...
 01:10
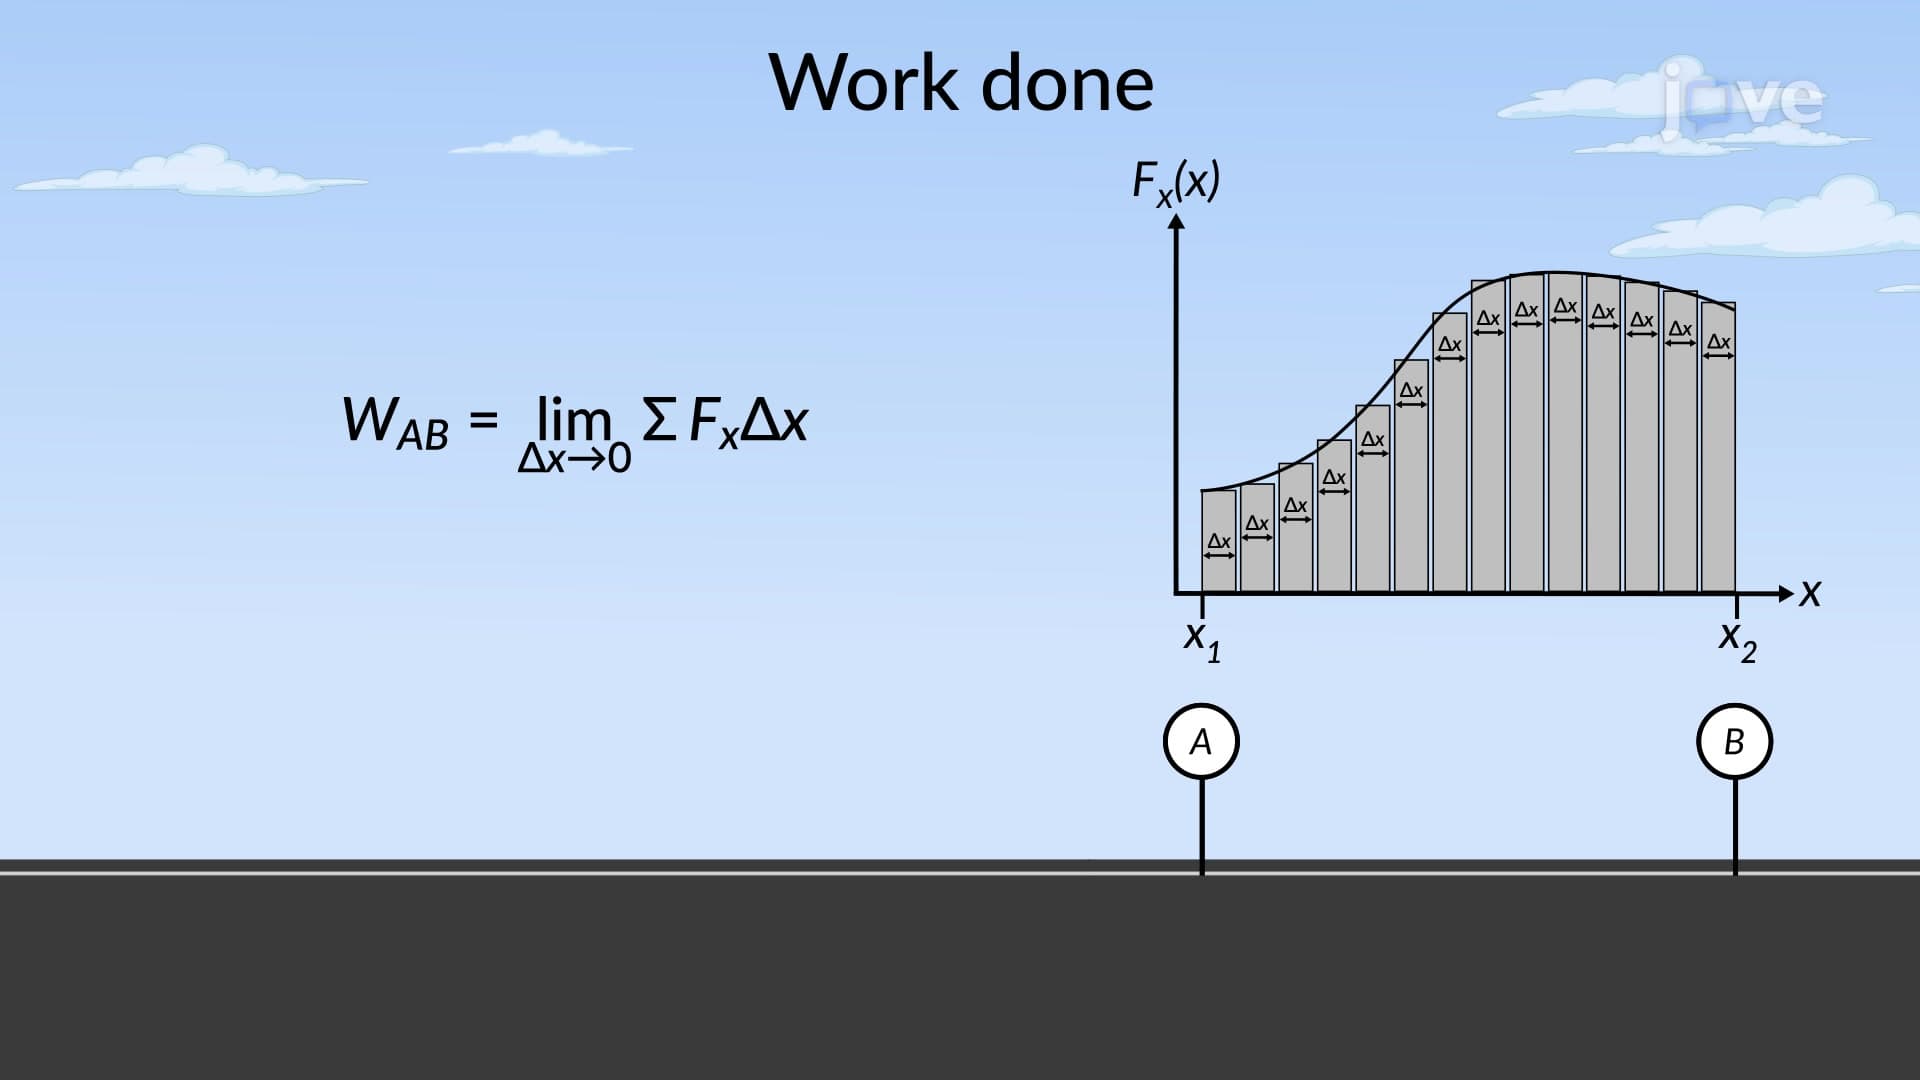
Work and Energy for Variable Forces
 01:18
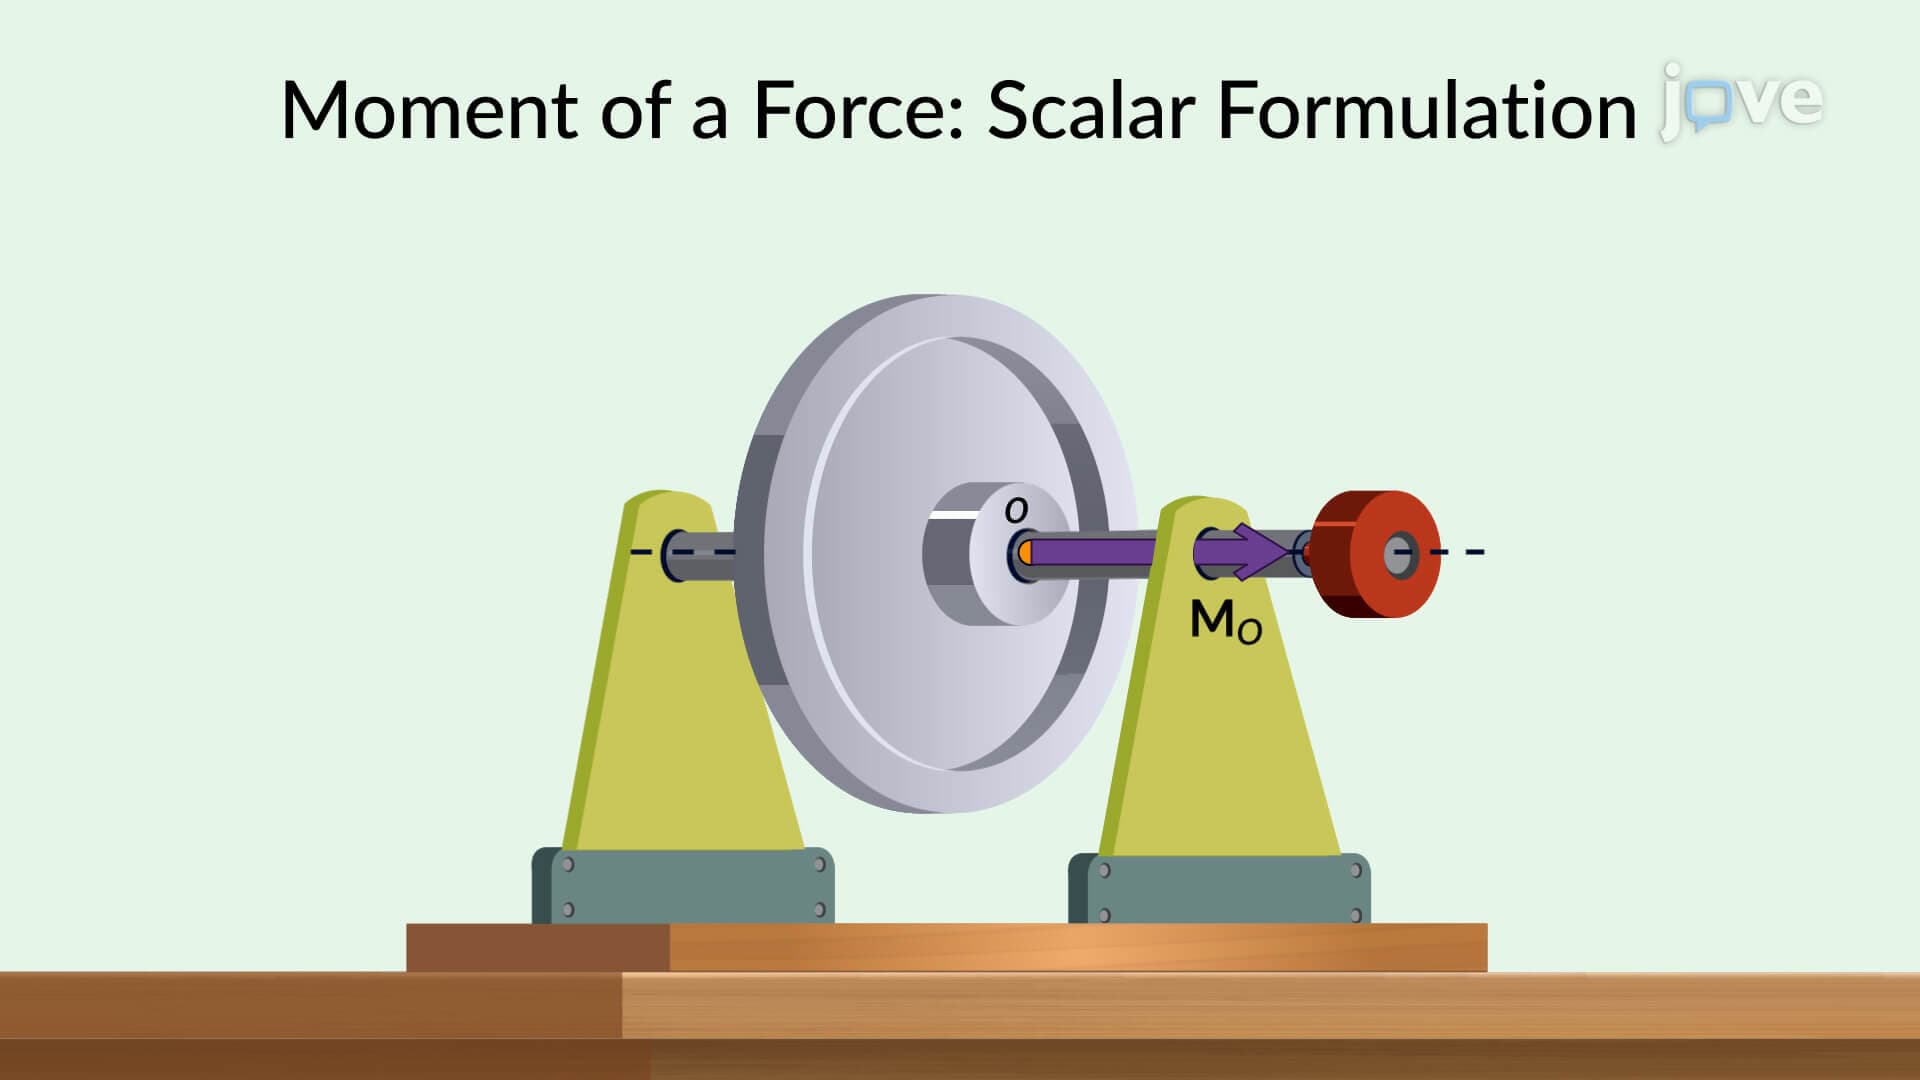
Moment of a Force: Scalar Formulation
Consider a simple example of a flywheel being rotated about a point, O, by applying a force to it. In this case, the moment arm is the perpendicular distance between the point O and the line of action of the force. The...
 01:29
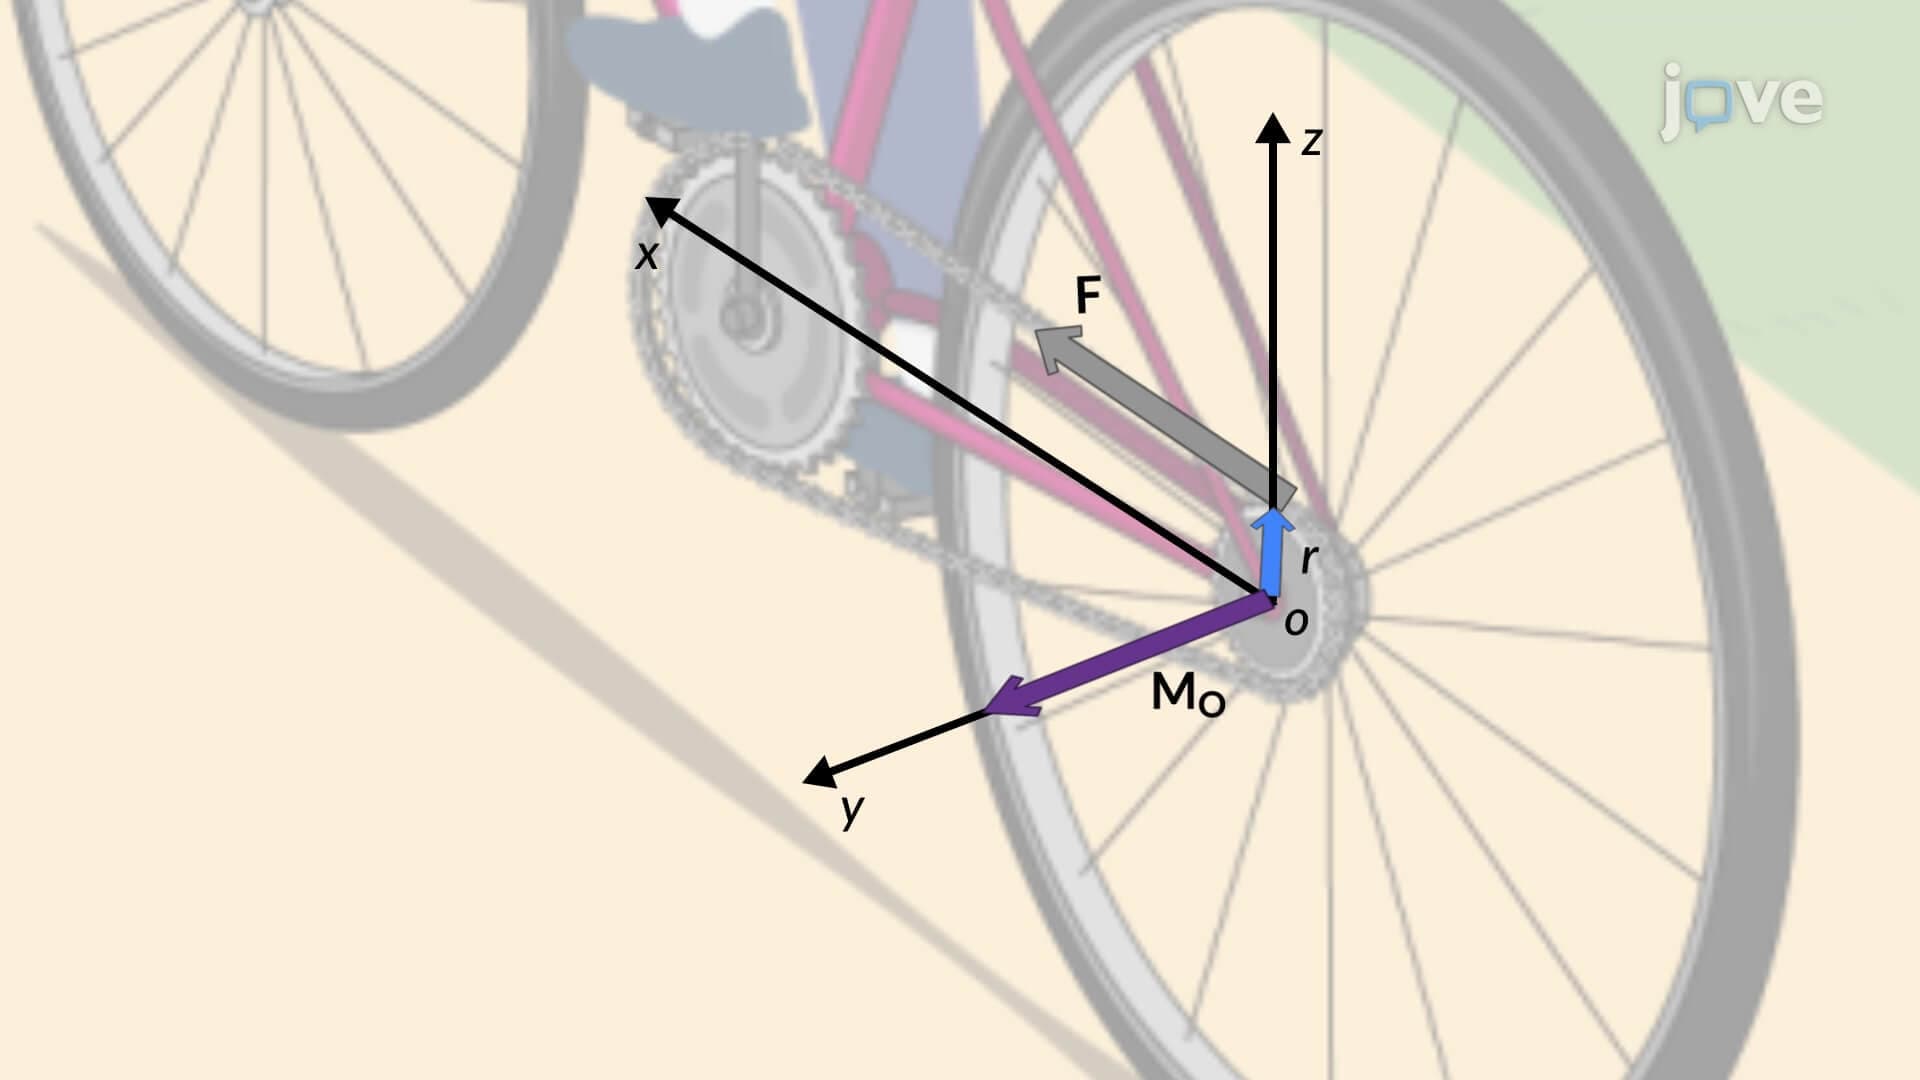
Moment of a Force About an Axis: Vector
First, establish a coordinate system to understand how the moment of a force works.