Related Experiment Video
Updated: May 16, 2026
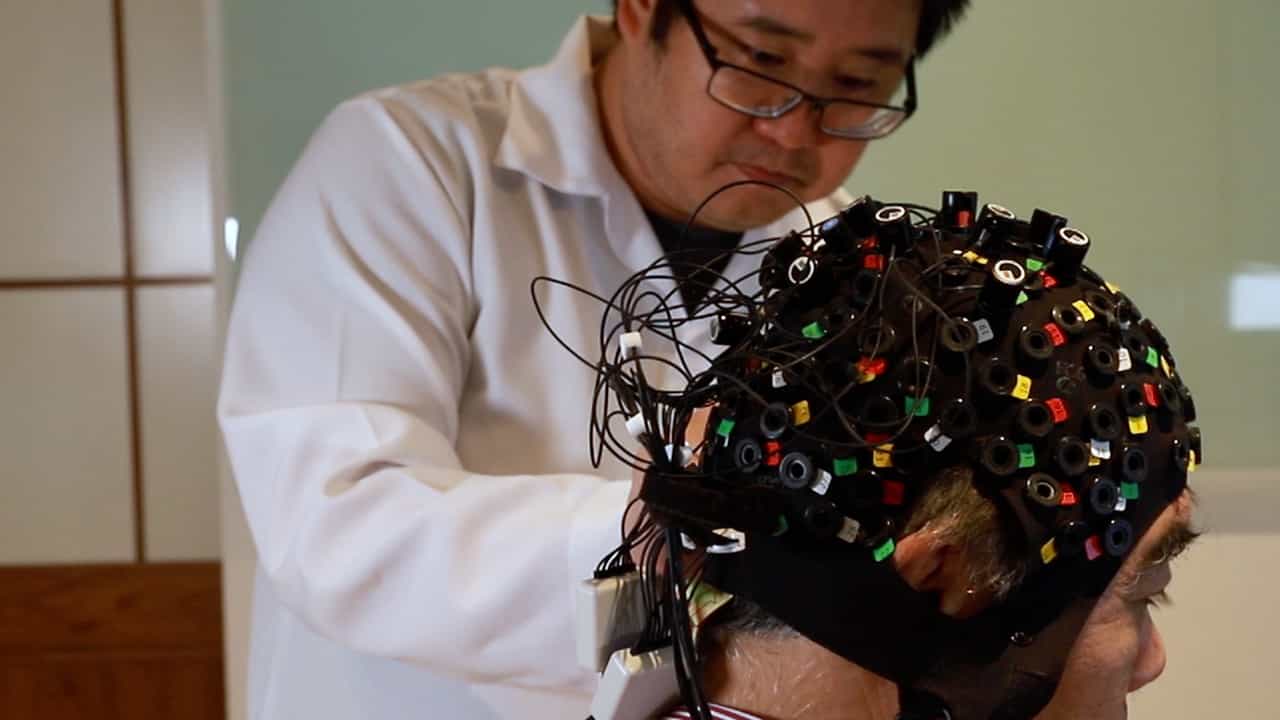

An Experiment Using Functional Near-Infrared Spectroscopy and Robot-Assisted Multi-Joint Pointing Movements of the Lower Limb
Published on: June 7, 2024
Adaptive impedance control of a robotic orthosis for gait rehabilitation
Shahid Hussain1, Sheng Q Xie, Prashant K Jamwal
1Department of Mechanical Engineering, The University of Auckland, Auckland 1142, New Zealand. shus045@aucklanduni.ac.nz

Abstract:
Intervention of robotic devices in the field of physical gait therapy can help in providing repetitive, systematic, and economically viable training sessions. Interactive or assist-as-needed (AAN) gait training encourages patient voluntary participation in the robotic gait training process which may aid in rapid motor function recovery. In this paper, a lightweight robotic gait training orthosis with two actuated and four passive degrees of freedom (DOFs) is proposed. The actuated DOFs were powered by pneumatic muscle actuators. An AAN gait training paradigm based on adaptive impedance control was developed to provide interactive robotic gait training. The proposed adaptive impedance control scheme adapts the robotic assistance according to the disability level and voluntary participation of human subjects. The robotic orthosis was operated in two gait training modes, namely, inactive mode and active mode, to evaluate the performance of the proposed control scheme. The adaptive impedance control scheme was evaluated on ten neurologically intact subjects. The experimental results demonstrate that an increase in voluntary participation of human subjects resulted in a decrease of the robotic assistance and vice versa. Further clinical evaluations with neurologically impaired subjects are required to establish the therapeutic efficacy of the adaptive-impedance-control-based AAN gait training strategy.
More Related Videos
 08:55
Use of a Foot-Induced Digitally Controlled Resistance Device for Functional Magnetic Resonance Imaging Evaluation in Patients with Foot Paresis
Published on: July 7, 2023
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015