Effectiveness and driver acceptance of a semi-autonomous forward obstacle collision avoidance system
Related Experiment Video
Updated: May 13, 2026
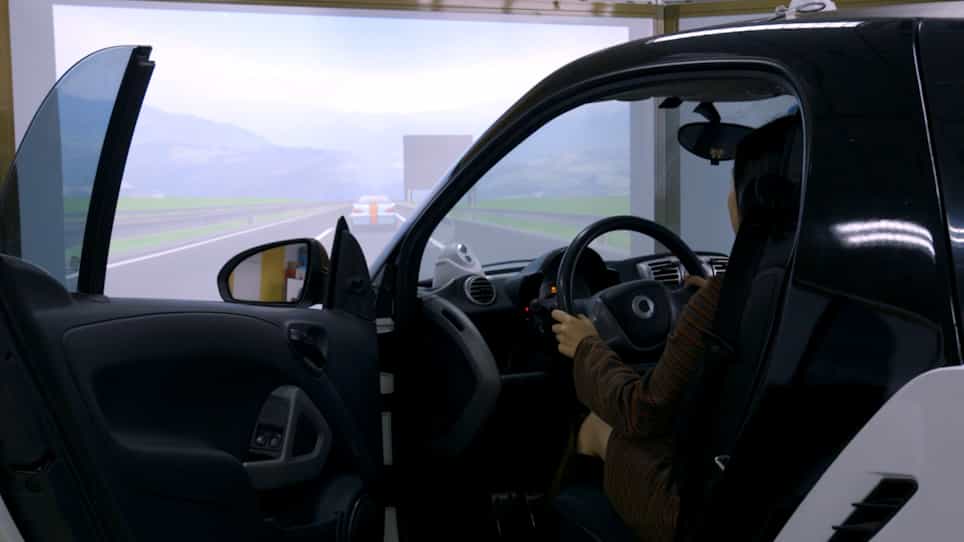
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Makoto Itoh1, Tatsuya Horikome, Toshiyuki Inagaki
1Faculty of Engineering, Information and Systems, University of Tsukuba, 1-1-1 Tennodai, Tsukuba, Ibaraki 305-8573, Japan. itoh@risk.tsukuba.ac.jp

Abstract:
This paper proposes a semi-autonomous collision avoidance system for the prevention of collisions between vehicles and pedestrians and objects on a road. The system is designed to be compatible with the human-centered automation principle, i.e., the decision to perform a maneuver to avoid a collision is made by the driver. However, the system is partly autonomous in that it turns the steering wheel independently when the driver only applies the brake, indicating his or her intent to avoid the obstacle. With a medium-fidelity driving simulator, we conducted an experiment to investigate the effectiveness of this system for improving safety in emergency situations, as well as its acceptance by drivers. The results indicate that the system effectively improves safety in emergency situations, and the semi-autonomous characteristic of the system was found to be acceptable to drivers.
Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:10
Control Systems
At the heart...
 01:22
Multi-input and Multi-variable systems
In the absence of...