Beyond habit: how perceived risk and personalised adaptation influence autonomous vehicle acceptance in the near-elderly group
Related Experiment Video
Updated: Oct 31, 2026
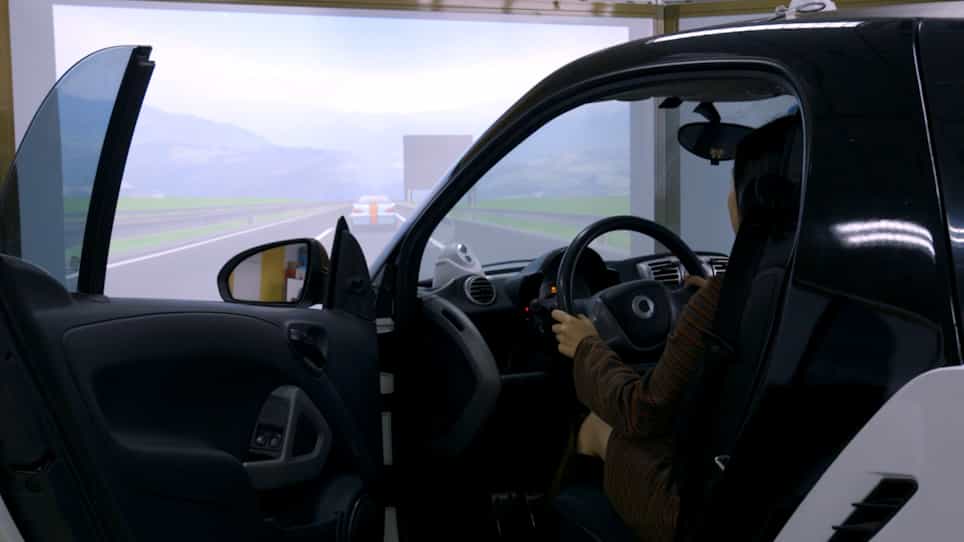
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Xin Chen1, Nengmin Guo1, Qingchuan Li2
1College of Art and Design, Division of Arts, Shenzhen University, Shenzhen, China.

Abstract:
With the ageing population's growing demand for mobility, this study examines acceptance of automated vehicles (AVs) among the near-elderly. By integrating perceived risk, behavioural inertia, and personalised adaptation into the Unified Technology Acceptance and Use Theory (UTAUT) framework, a new model was estimated using Partial Least Squares Structural Equation Modelling (PLS-SEM). Data were collected from 352 licenced drivers aged 55-64 in mainland China through a national online survey. Findings reveal that behavioural inertia is not critical, whereas perceived risk is the strongest negative driver of acceptance intention. Conversely, personalised adaptation and performance expectancy are the primary positive drivers. Mediation analysis shows that personalised adaptation significantly influences intention through effort expectancy, though not through behavioural inertia. Results suggest that AV design should minimise perceived risk and provide adaptive functions, such as frequent-route memory, driving-habit adaptation, and clearer system communication, to enhance adoption among this demographic.
Related Concept Videos
 01:42
Schemas
 01:25
The Anchoring-and-Adjustment Heuristic
 02:55
Stereotypes, Prejudice, and Discrimination