Learning enhanced game theoretic decision-making for interaction-aware autonomous driving in urban traffic scenarios
Related Experiment Videos
Shen Li1, Haojie Gui2, Kai Yang3
1School of Civil Engineering, Tsinghua University, Beijing, 100084, China.

Abstract:
Autonomous vehicles (AVs) are expected to significantly improve road safety and traffic efficiency. However, ensuring safe decision-making in complex urban traffic scenarios remains a critical challenge due to complex interactions between AVs and surrounding vehicles. In this context, the behaviors of nearby vehicles influence the AV's actions, and vice versa, forming highly coupled bidirectional interactions. Improper handling of such interactions may lead to unsafe decisions or even traffic accidents. To this end, a game theoretic decision-making framework for interaction-aware autonomous driving is proposed in this paper, where the inter-vehicle interactions are transformed to pairwise leader-follower Stackelberg games. Specifically, a driving context-aware strategy proposal network is first developed to generate adaptive strategy spaces for surrounding vehicles by incorporating historical trajectories, road structures, and interaction features. Subsequently, a convex hull-based scanning technique is introduced to identify the most influential vehicles based on future spatiotemporal occupancy. Furthermore, a learning enhanced game-theoretic decision-making framework is formulated that incorporates predicted trajectories of vehicles into the payoff function with safety-related metrics. Finally, the effectiveness of the proposed method is validated through both qualitative and quantitative experiments in multiple highly interactive urban traffic scenarios using the CARLA simulator. Experimental results demonstrate that the proposed method could improve interaction safety while maintaining travel efficiency compared with baselines.
Related Concept Videos
 01:20
Decision Making
Automatic decision-making is fast, intuitive, and relies on gut feelings...
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:09
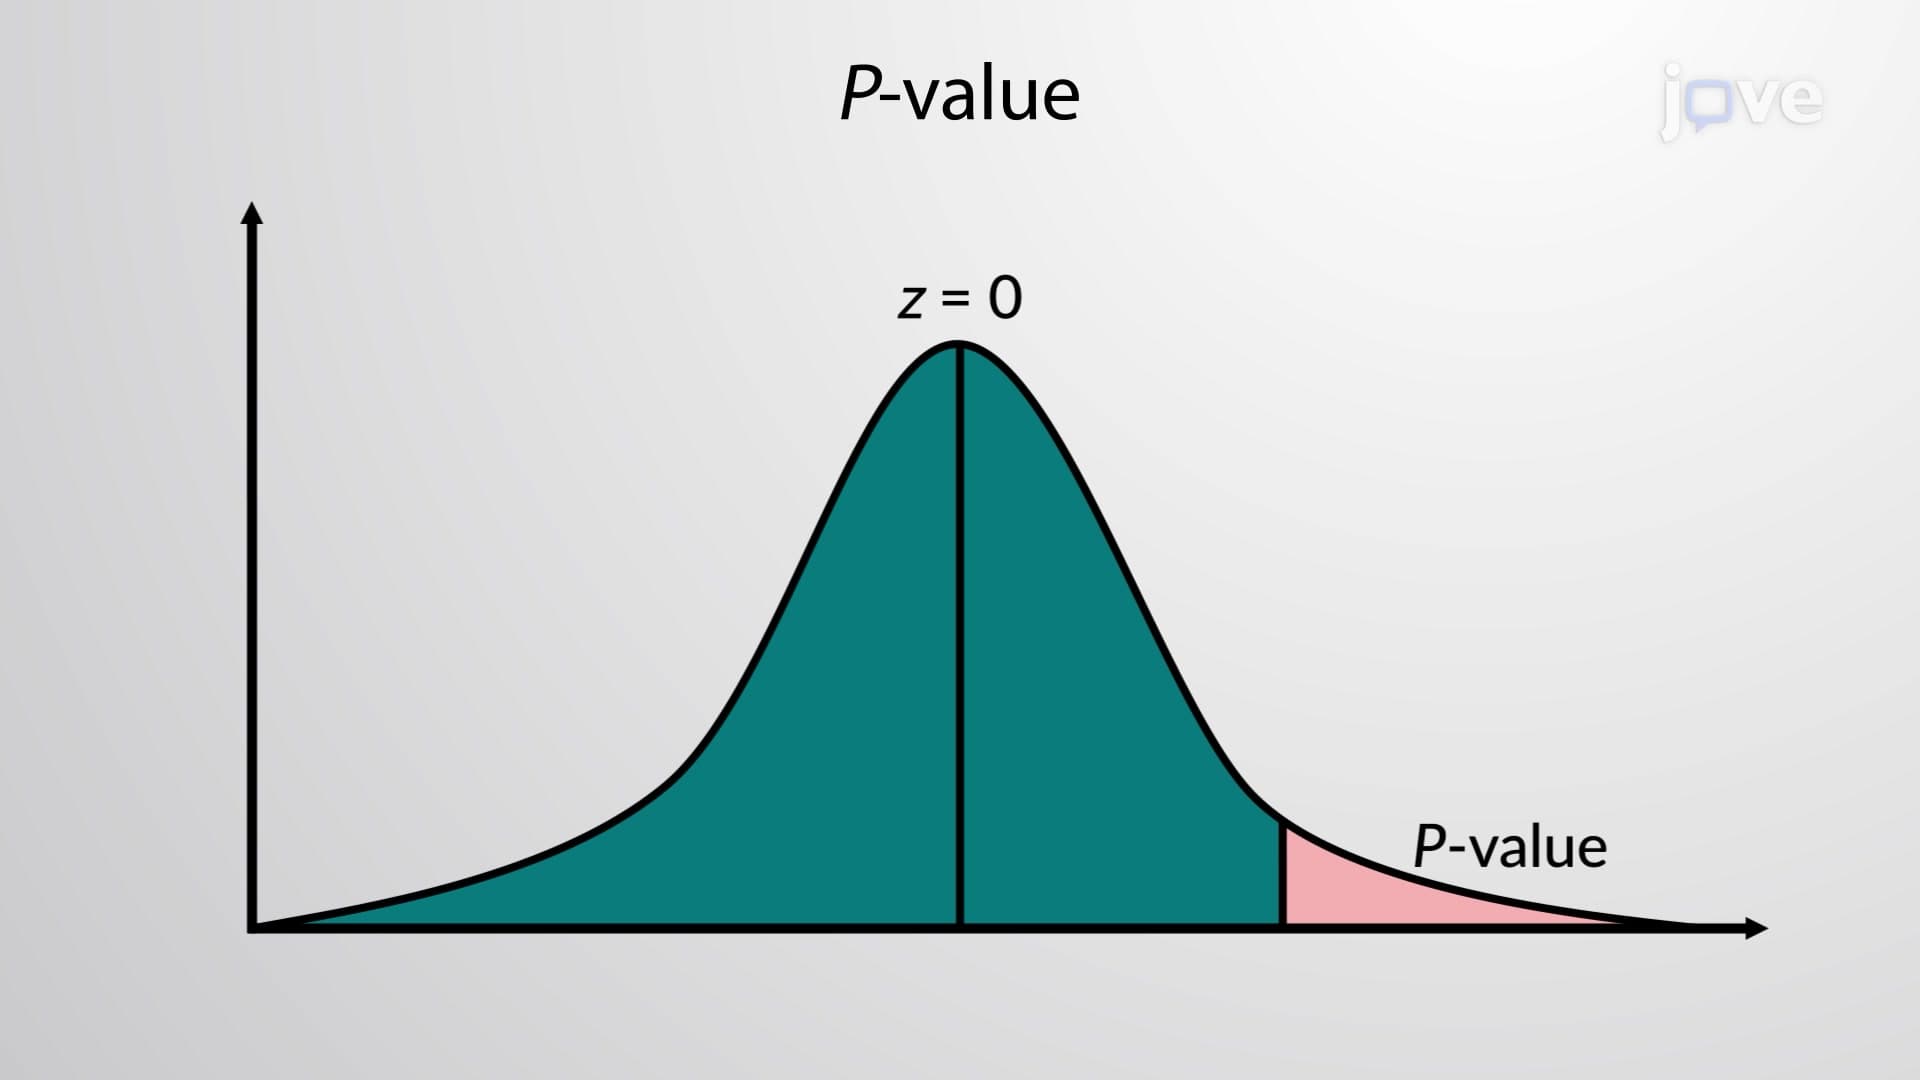
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can have a...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...