Optimal controller design using discrete linear model for a four tank benchmark process
Related Experiment Video
Updated: May 9, 2026

Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Yousef Alipouri1, Javad Poshtan
1Department of Faculty of Electrical Engineering, Iran University of Science and Technology, Tehran, Iran.

Abstract:
This paper deals with implementation of an optimal linear controller for a laboratory liquid four-tank system. A discrete linear model is used for modeling a class of MIMO nonlinear systems. It is shown that this model can identify these nonlinear systems with any desired accuracy, as a result the designed controller is accurate. The global stability condition is studied. The advantage of the proposed method against other controllers is its simplicity in design, there is no need for physical equations of the nonlinear system, and it is more accurate than other proposed linear methods. We present a step-by-step description of all steps leading towards the derivation and implementation of such a controller. The proposed method is tested on an experimental four tank benchmark process.


Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:24
PI Controller: Design
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:13
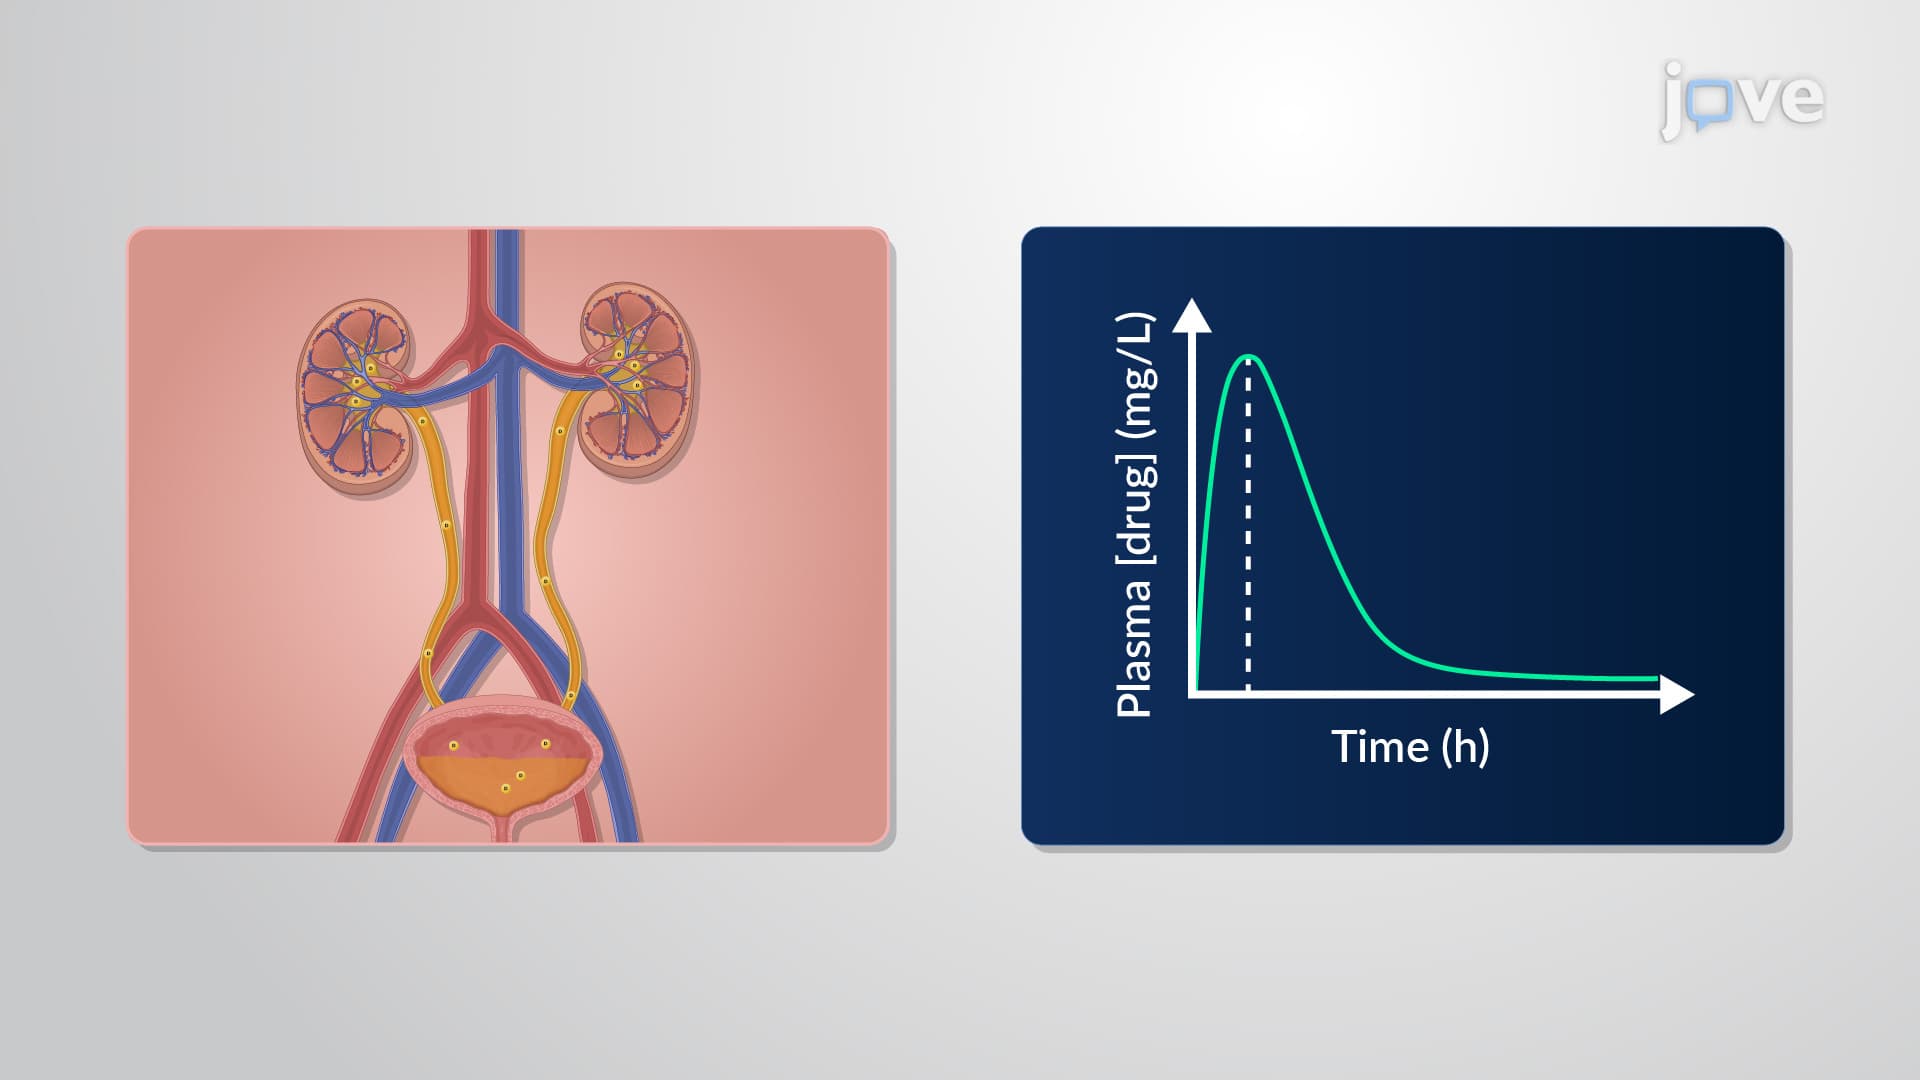
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...