Related Experiment Video
Updated: May 9, 2026

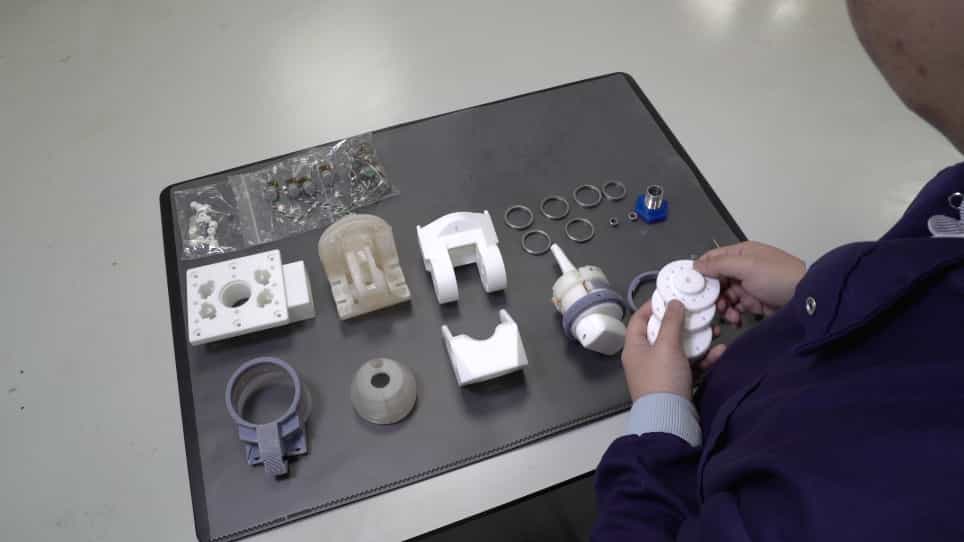
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Design, modeling and control of a pneumatically actuated manipulator inspired by biological continuum structures
Rongjie Kang1, David T Branson, Tianjiang Zheng
1Department of Advanced Robotics, Istituto Italiano di Tecnologia, Via Morego 30, 16163 Genova, Italy. rongjie.kang@gmail.com

Abstract:
Biological tentacles, such as octopus arms, have entirely flexible structures and virtually infinite degrees of freedom (DOF) that allow for elongation, shortening and bending at any point along the arm length. The amazing dexterity of biological tentacles has driven the growing implementation of continuum manipulators in robotic systems. This paper presents a pneumatic manipulator inspired by biological continuum structures in some of their key features and functions, such as continuum morphology, intrinsic compliance and stereotyped motions with hyper redundant DOF. The kinematics and dynamics of the manipulator are formulated and identified, and a hierarchical controller taking inspiration from the structure of an octopus nervous system is used to relate desired stereotyped motions to individual actuator inputs. Simulations and experiments are carried out to validate the model and prototype where good agreement was found between the two.

Related Concept Videos
 01:22
Mechanical Systems
 01:23
Simplification of a Force and Couple System: II
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...