Discrete state space modeling and control of nonlinear unknown systems
Related Experiment Video
Updated: May 8, 2026

Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
1Department of Electrical and Electronics Engineering, Ege University, 35100 Bornova, Izmir, Turkey.

Abstract:
A novel procedure for integrating neural networks (NNs) with conventional techniques is proposed to design industrial modeling and control systems for nonlinear unknown systems. In the proposed approach, a new recurrent NN with a special architecture is constructed to obtain discrete-time state-space representations of nonlinear dynamical systems. It is referred as the discrete state-space neural network (DSSNN). In the DSSNN, the outputs of the hidden layer neurons of the DSSNN represent the system's (pseudo) state. The inputs are fed to output neurons and the delayed outputs of the hidden layer neurons are fed to their inputs via adjustable weights. The discrete state space model of the actual system is directly obtained by training the DSSNN with the input-output data. A training procedure based on the back-propagation through time (BPTT) algorithm is developed. The Levenberg-Marquardt (LM) method with a trust region approach is used to update the DSSNN weights. Linear state space models enable to use well developed conventional analysis and design techniques. Thus, building a linear model of a system has primary importance in industrial applications. Thus, a suitable linearization procedure is proposed to derive the linear state space model from the nonlinear DSSNN representation. The controllability, observability and stability properties are examined. The state feedback controllers are designed with both the linear quadratic regulator (LQR) and the pole placement techniques. The regulator and servo control problems are both addressed. A full order observer is also designed to estimate the state variables. The performance of the proposed procedure is demonstrated by applying for both single-input single-output (SISO) and multiple-input multiple-output (MIMO) nonlinear control problems.
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:23
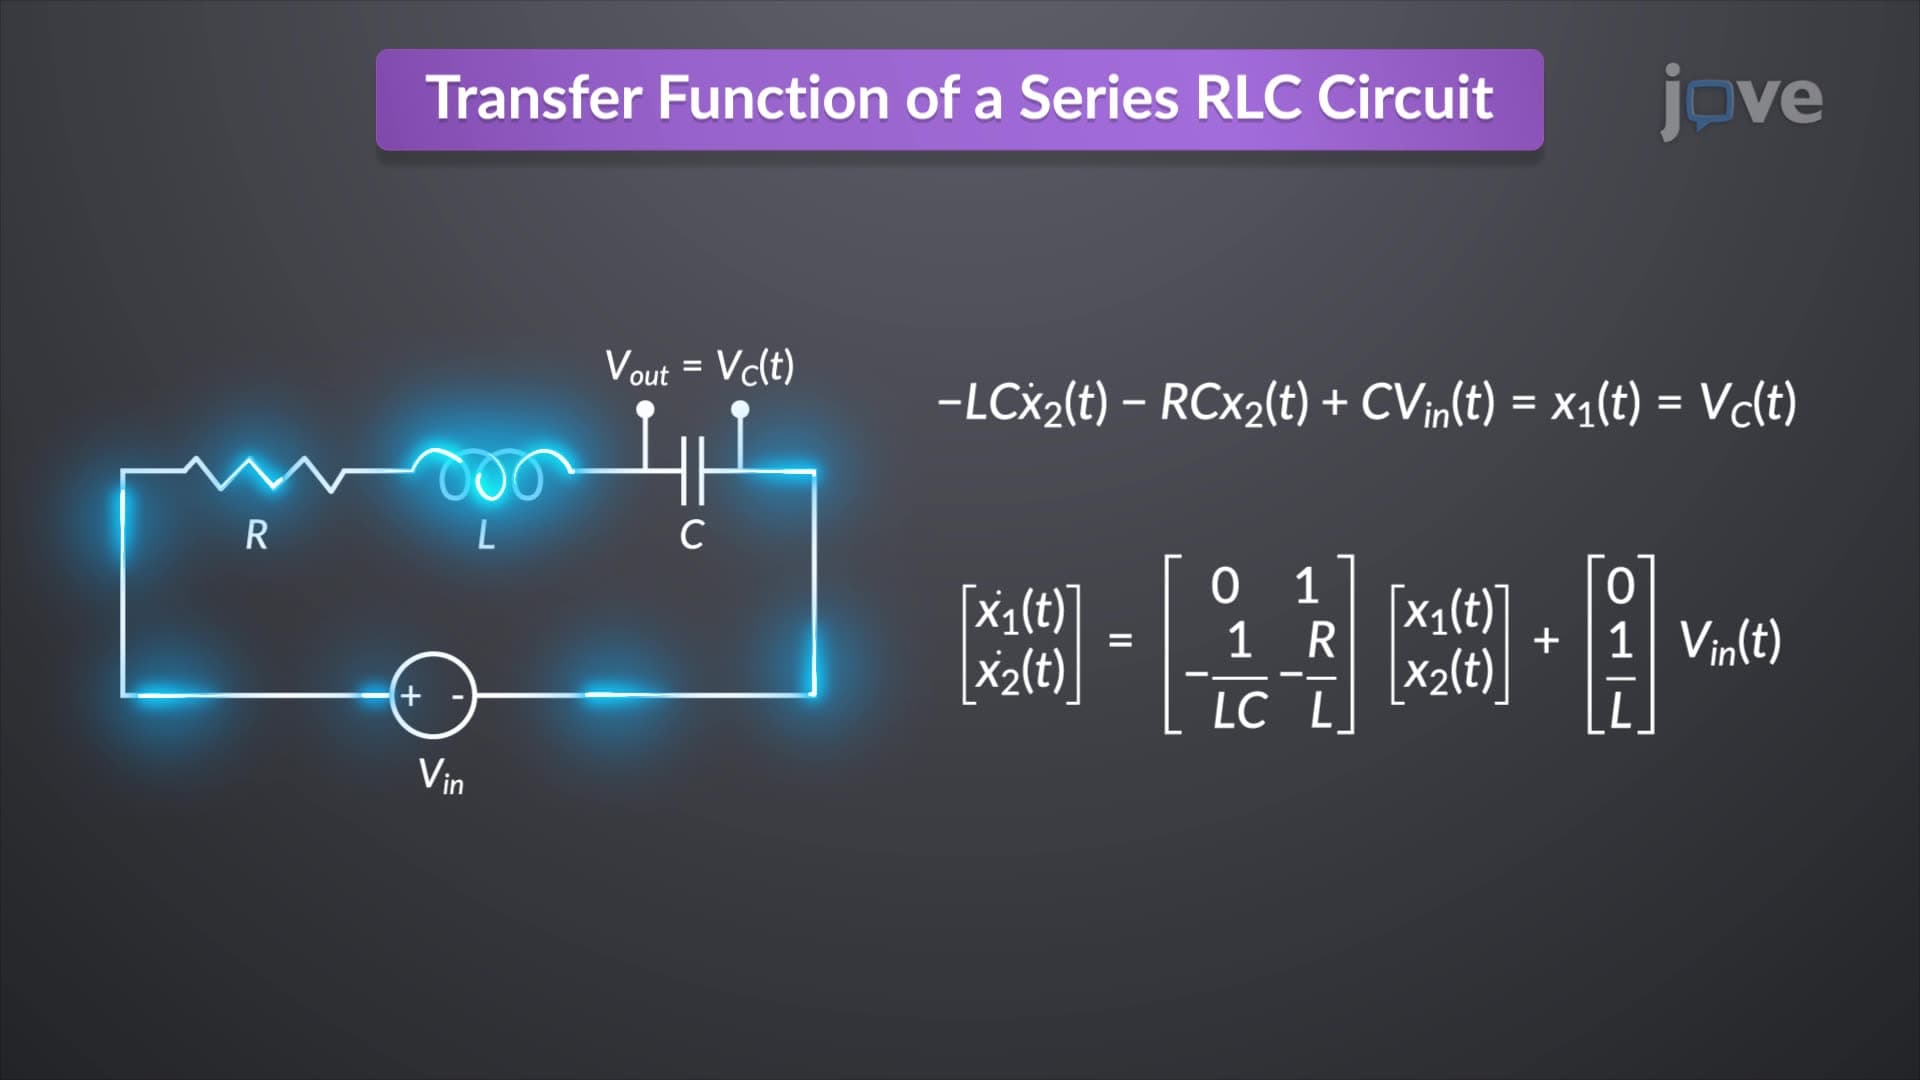
Transfer Function to State Space
In an RLC...
 01:21
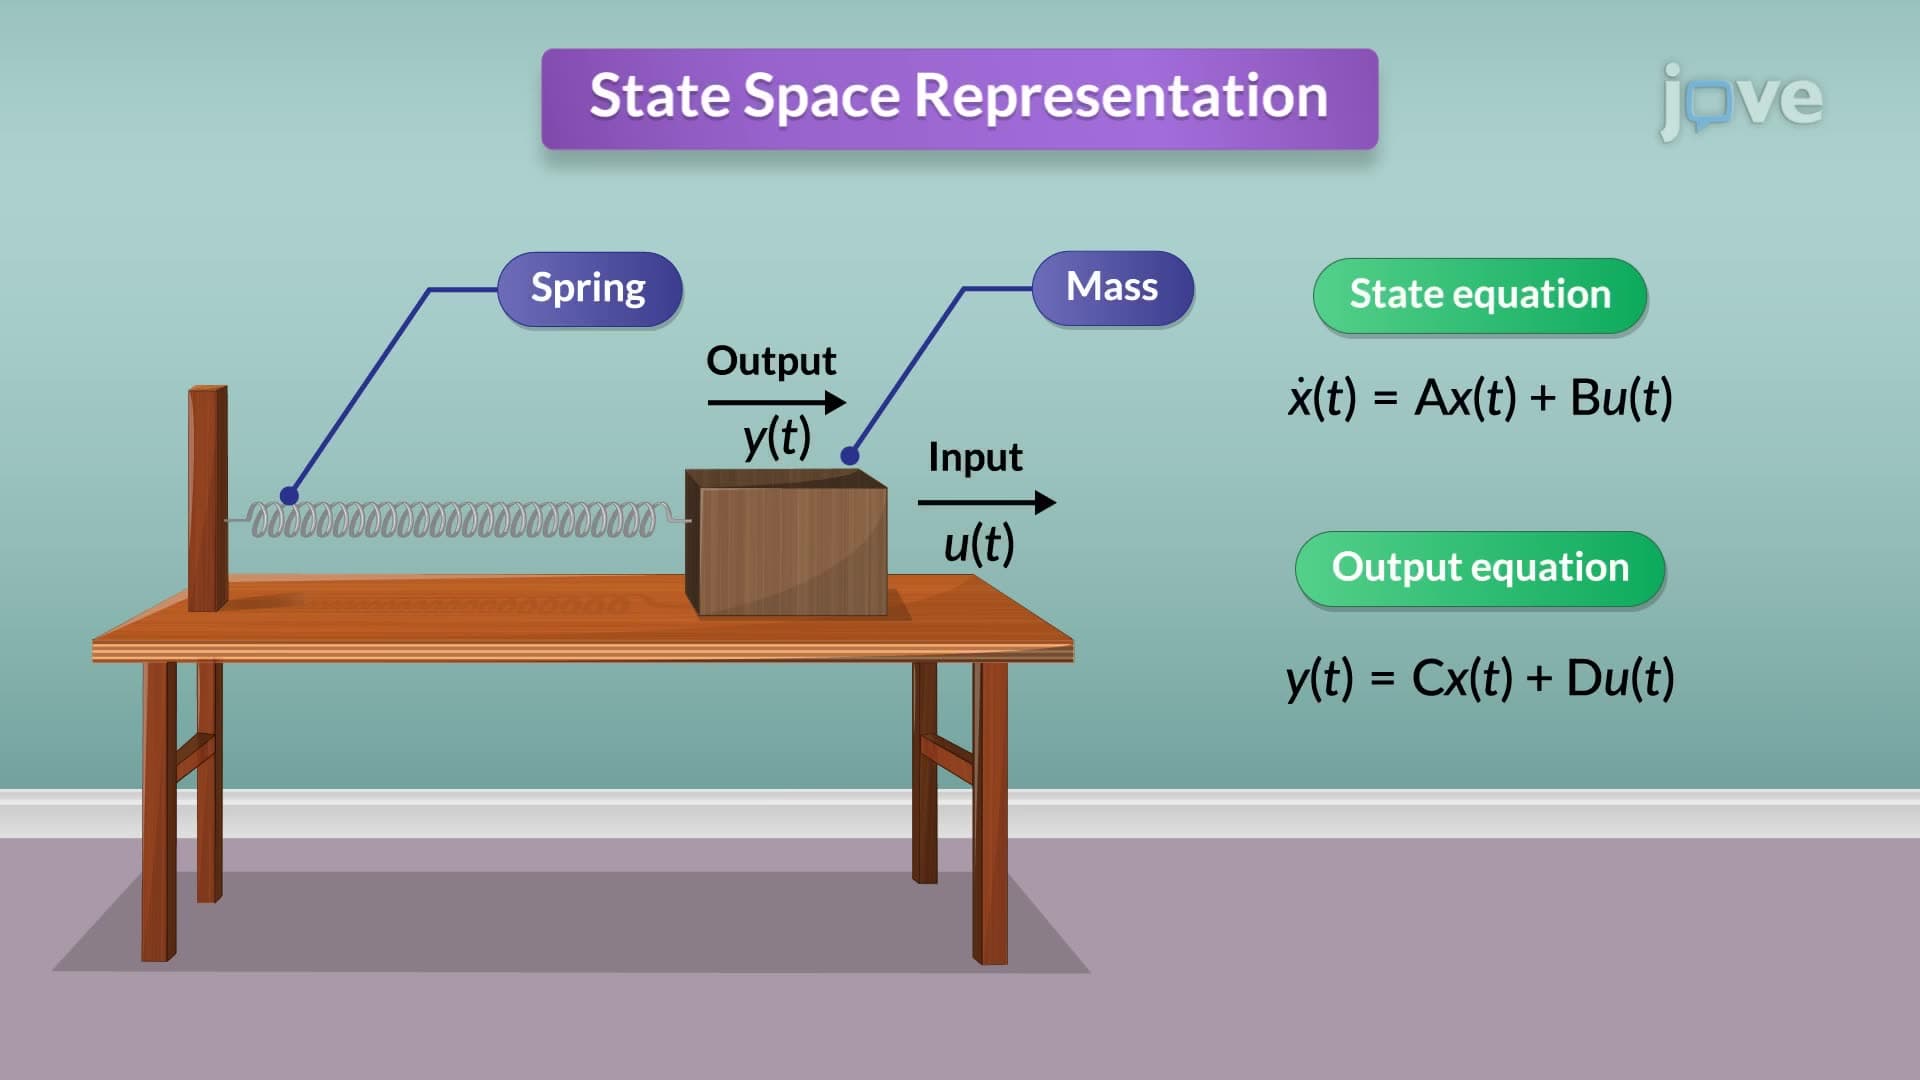
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:31
Classification of Systems-II