Robust object tracking via sparse collaborative appearance model
Related Experiment Video
Updated: May 1, 2026
Utilizing vmTracking to Improve the Accuracy of Multi-Animal Pose Estimation in Rodent Social Behavior Studies
Published on: November 7, 2025

Abstract:
In this paper, we propose a robust object tracking algorithm based on a sparse collaborative model that exploits both holistic templates and local representations to account for drastic appearance changes. Within the proposed collaborative appearance model, we develop a sparse discriminative classifier (SDC) and sparse generative model (SGM) for object tracking. In the SDC module, we present a classifier that separates the foreground object from the background based on holistic templates. In the SGM module, we propose a histogram-based method that takes the spatial information of each local patch into consideration. The update scheme considers both the most recent observations and original templates, thereby enabling the proposed algorithm to deal with appearance changes effectively and alleviate the tracking drift problem. Numerous experiments on various challenging videos demonstrate that the proposed tracker performs favorably against several state-of-the-art algorithms.
Related Concept Videos
 01:12
Modeling and Similitude
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:26
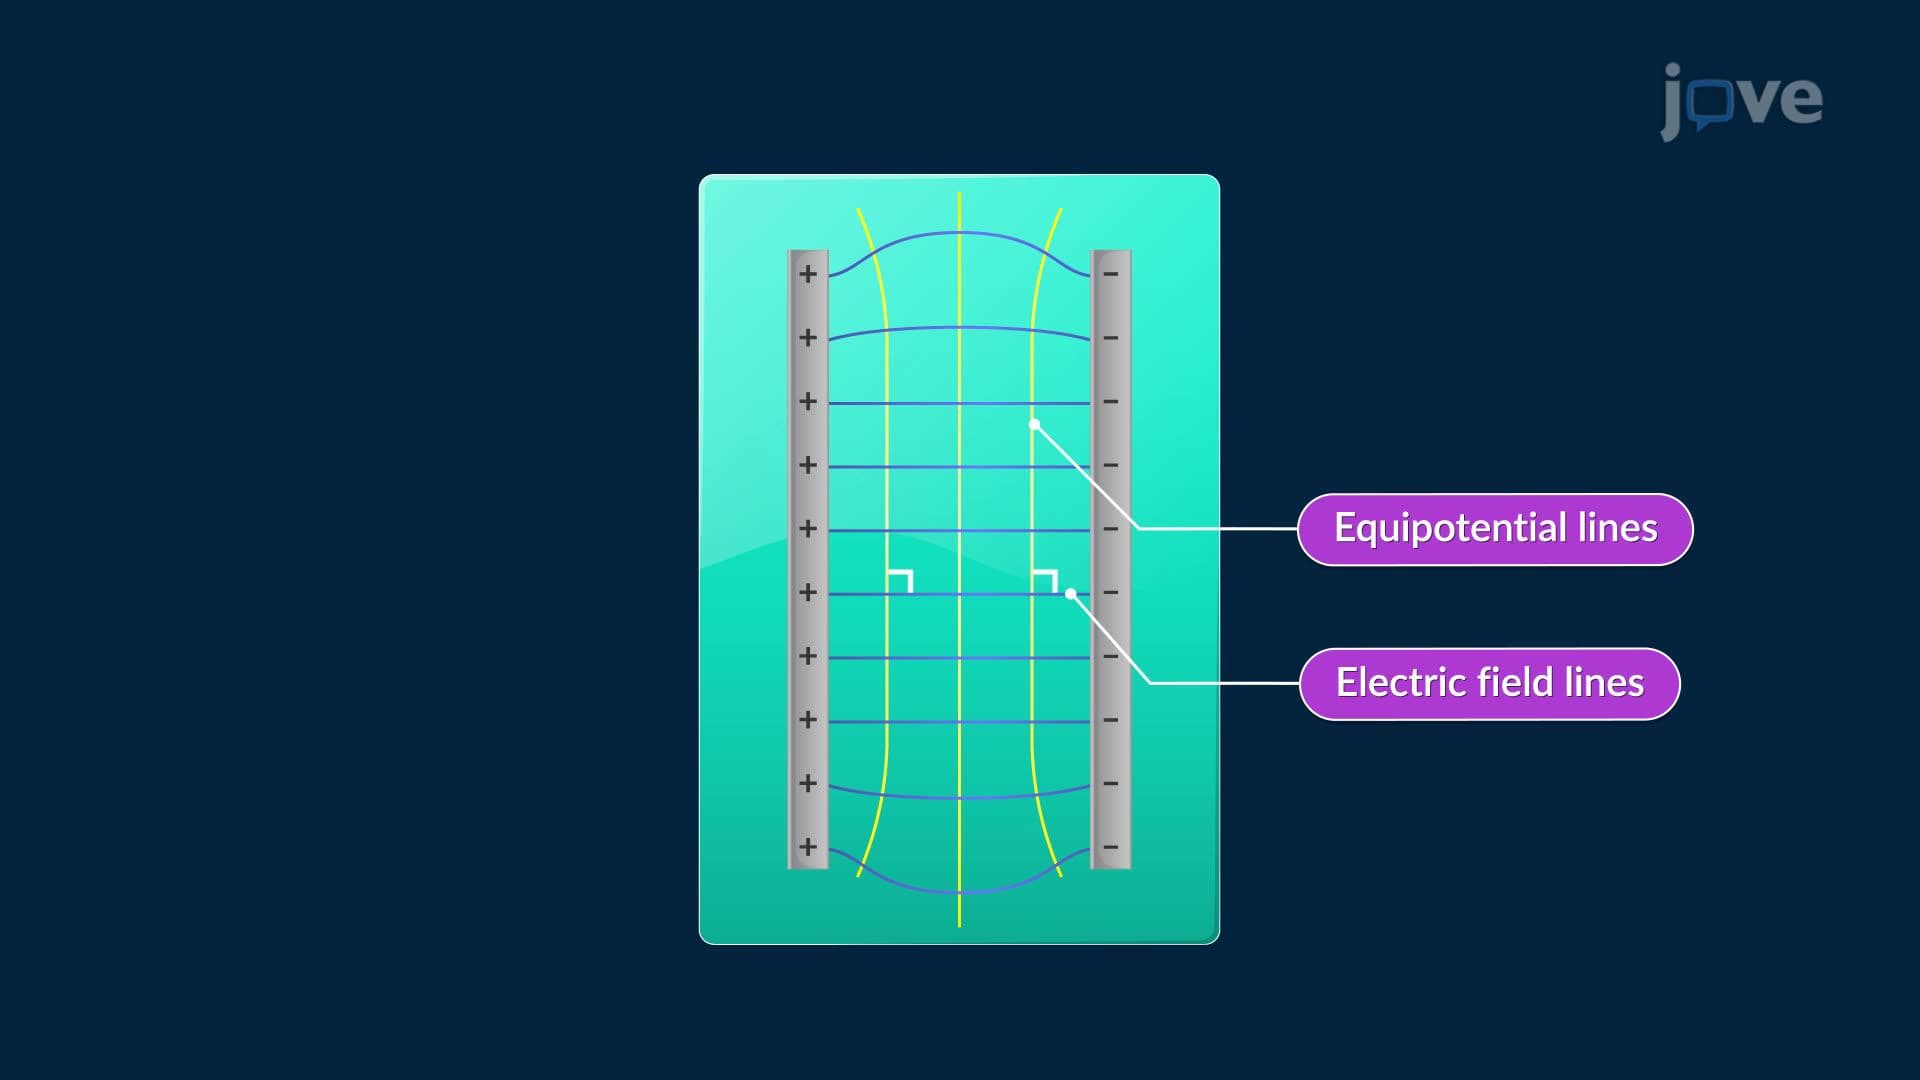
Orthogonal Trajectories
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...