Related Experiment Video
Updated: May 1, 2026
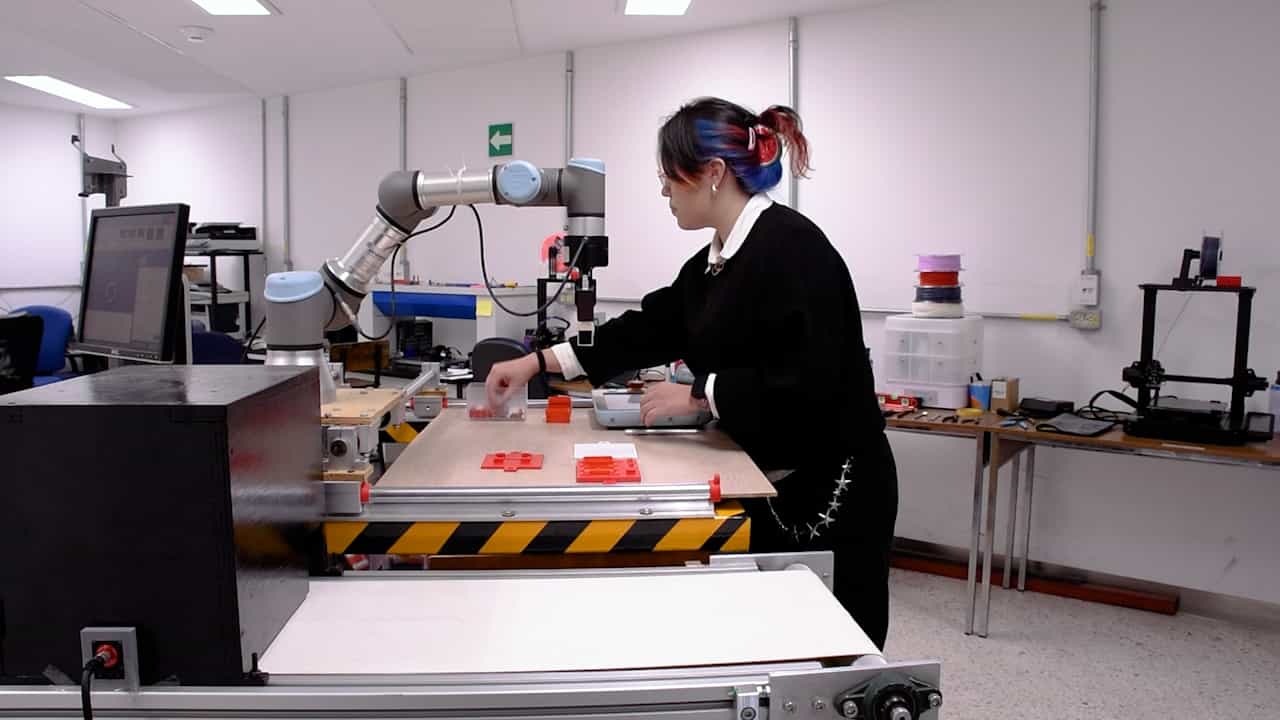
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Task partitioning in a robot swarm: object retrieval as a sequence of subtasks with direct object transfer
Giovanni Pini1, Arne Brutschy, Alexander Scheidler
1Université Libre de Bruxelles.

Abstract:
We study task partitioning in the context of swarm robotics. Task partitioning is the decomposition of a task into subtasks that can be tackled by different workers. We focus on the case in which a task is partitioned into a sequence of subtasks that must be executed in a certain order. This implies that the subtasks must interface with each other, and that the output of a subtask is used as input for the subtask that follows. A distinction can be made between task partitioning with direct transfer and with indirect transfer. We focus our study on the first case: The output of a subtask is directly transferred from an individual working on that subtask to an individual working on the subtask that follows. As a test bed for our study, we use a swarm of robots performing foraging. The robots have to harvest objects from a source, situated in an unknown location, and transport them to a home location. When a robot finds the source, it memorizes its position and uses dead reckoning to return there. Dead reckoning is appealing in robotics, since it is a cheap localization method and it does not require any additional external infrastructure. However, dead reckoning leads to errors that grow in time if not corrected periodically. We compare a foraging strategy that does not make use of task partitioning with one that does. We show that cooperation through task partitioning can be used to limit the effect of dead reckoning errors. This results in improved capability of locating the object source and in increased performance of the swarm. We use the implemented system as a test bed to study benefits and costs of task partitioning with direct transfer. We implement the system with real robots, demonstrating the feasibility of our approach in a foraging scenario.
Related Concept Videos
 01:30
Machines: Problem Solving II
 01:21
Distributed Loads: Problem Solving
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...