Related Experiment Video
Updated: Apr 30, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Development of a biomimetic hand exotendon device (BiomHED) for restoration of functional hand movement post-stroke

Abstract:
Significant functional impairment of the hand is common among stroke survivors and restoration of hand function should be prioritized during post-stroke rehabilitation. The goal of this study was to develop a novel biomimetic device to assist patients in producing complex hand movements with a limited number of actuators. The Biomimetic Hand Exoskeleton Device (BiomHED) is actuated by exotendons that mimic the geometry of the major tendons of the hand. Ten unimpaired subjects and four chronic stroke survivors participated in experiments that tested the efficacy of the system. The exotendons reproduced distinct spatial joint coordination patterns similar to their target muscle-tendon units for both subject groups. In stroke survivors, the exotendon-produced joint angular displacements were smaller, but not significantly different, than those of unimpaired subjects [Formula: see text]. Even with limited use of the BiomHED, the kinematic workspace of the index finger increased by 63%-1014% in stroke survivors. The device improved the kinematics of the tip-pinch task in stroke survivors and resulted in a significant reduction in the fingertip-thumb tip distance ( 17.9 ±15.3 mm). This device is expected to enable effective "task-oriented" training of the hand post-stroke.
More Related Videos
 03:55
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
 07:34
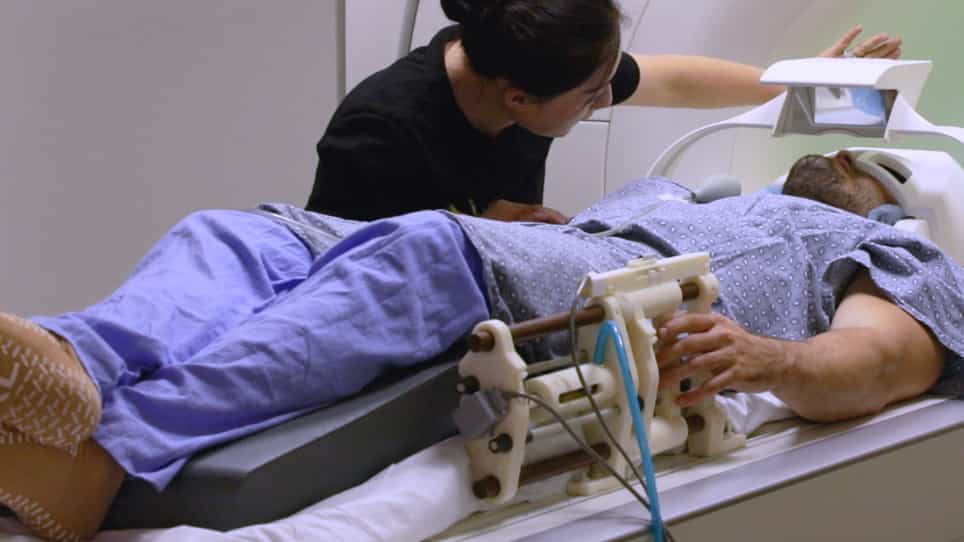
Functional MRI in Conjunction with a Novel MRI-compatible Hand-induced Robotic Device to Evaluate Rehabilitation of Individuals Recovering from Hand Grip Deficits
Published on: November 23, 2019