Adaptive NN controller design for a class of nonlinear MIMO discrete-time systems
Related Experiment Video
Updated: Aug 3, 2026

Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021

Abstract:
An adaptive neural network tracking control is studied for a class of multiple-input multiple-output (MIMO) nonlinear systems. The studied systems are in discrete-time form and the discretized dead-zone inputs are considered. In addition, the studied MIMO systems are composed of N subsystems, and each subsystem contains unknown functions and external disturbance. Due to the complicated framework of the discrete-time systems, the existence of the dead zone and the noncausal problem in discrete-time, it brings about difficulties for controlling such a class of systems. To overcome the noncausal problem, by defining the coordinate transformations, the studied systems are transformed into a special form, which is suitable for the backstepping design. The radial basis functions NNs are utilized to approximate the unknown functions of the systems. The adaptation laws and the controllers are designed based on the transformed systems. By using the Lyapunov method, it is proved that the closed-loop system is stable in the sense that the semiglobally uniformly ultimately bounded of all the signals and the tracking errors converge to a bounded compact set. The simulation examples and the comparisons with previous approaches are provided to illustrate the effectiveness of the proposed control algorithm.

Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Transfer Function in Control Systems
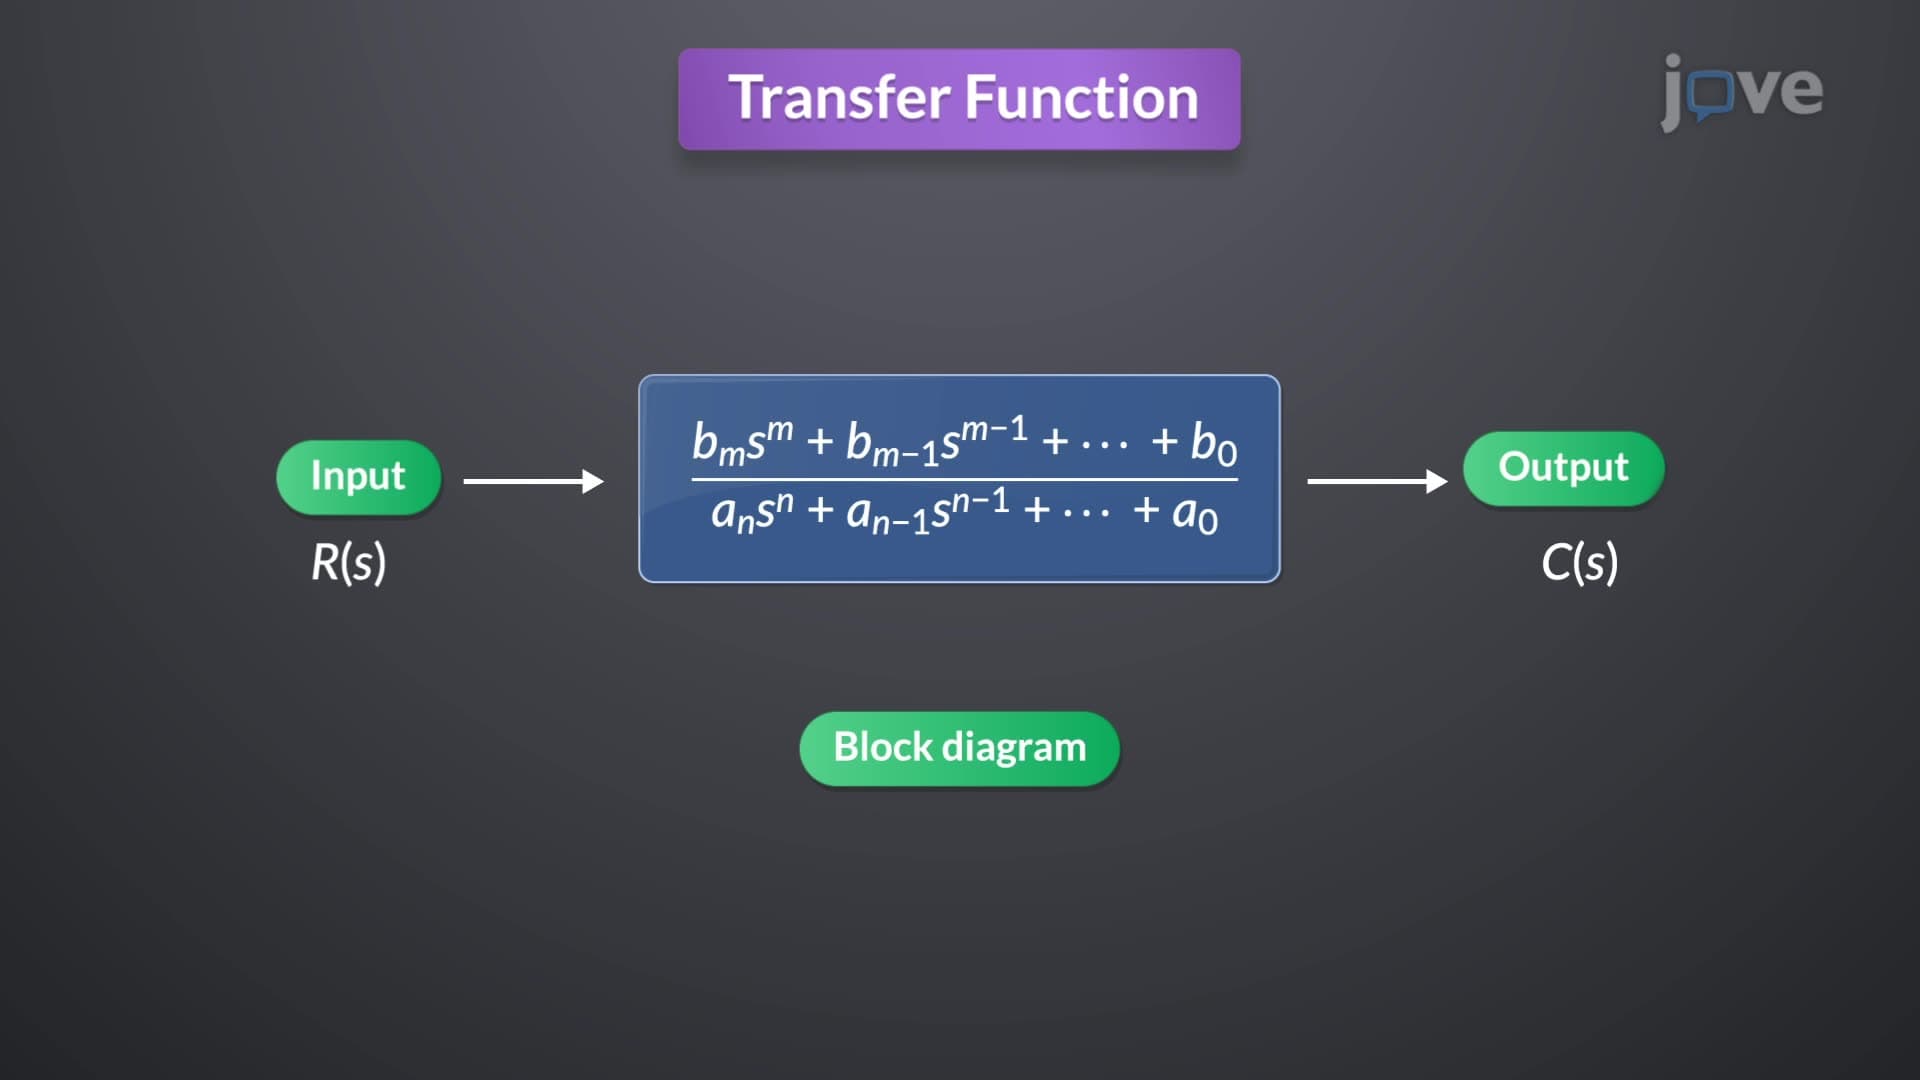
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:24
PI Controller: Design