Robust evolutionary particle filter
Related Experiment Video
Updated: Apr 17, 2026
Using Insect Electroantennogram Sensors on Autonomous Robots for Olfactory Searches
Published on: August 4, 2014
1Faculty of Electrical and Computer Engineering, Birjand University, Iran.

Abstract:
The particle filter (PF) has been widely applied for non-linear filtering owing to its ability to carry multiple hypotheses relaxing the linearity and Gaussian assumptions. However, PF is inconsistent over time due to the loss of particle diversity caused mainly by the particle depletion in resampling step and incorrect a priori knowledge of process and measurement noise. To overcome these problems, in this paper, robust evolutionary particle filter is proposed. The proposed method can work in unknown statistical noise and does not require a prior knowledge about the system. In addition, to increase diversity, a resampling process is done based on the differential evolution (DE). The effectiveness of the proposed algorithm is demonstrated through Monte Carlo simulations. The simulation results demonstrate the effectiveness of the proposed method.
More Related Videos
 08:13
SwarmSight: Real-time Tracking of Insect Antenna Movements and Proboscis Extension Reflex Using a Common Preparation and Conventional Hardware
Published on: December 25, 2017
 07:38
Open-source Single-particle Analysis for Super-resolution Microscopy with VirusMapper
Published on: April 9, 2017
Related Concept Videos
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 03:33
Genetic Drift
 01:09
Mutation, Gene Flow, and Genetic Drift
 01:25
Active Filters
 01:21
Frequency-dependent Selection
 01:23
Equilibrium Conditions for a Particle
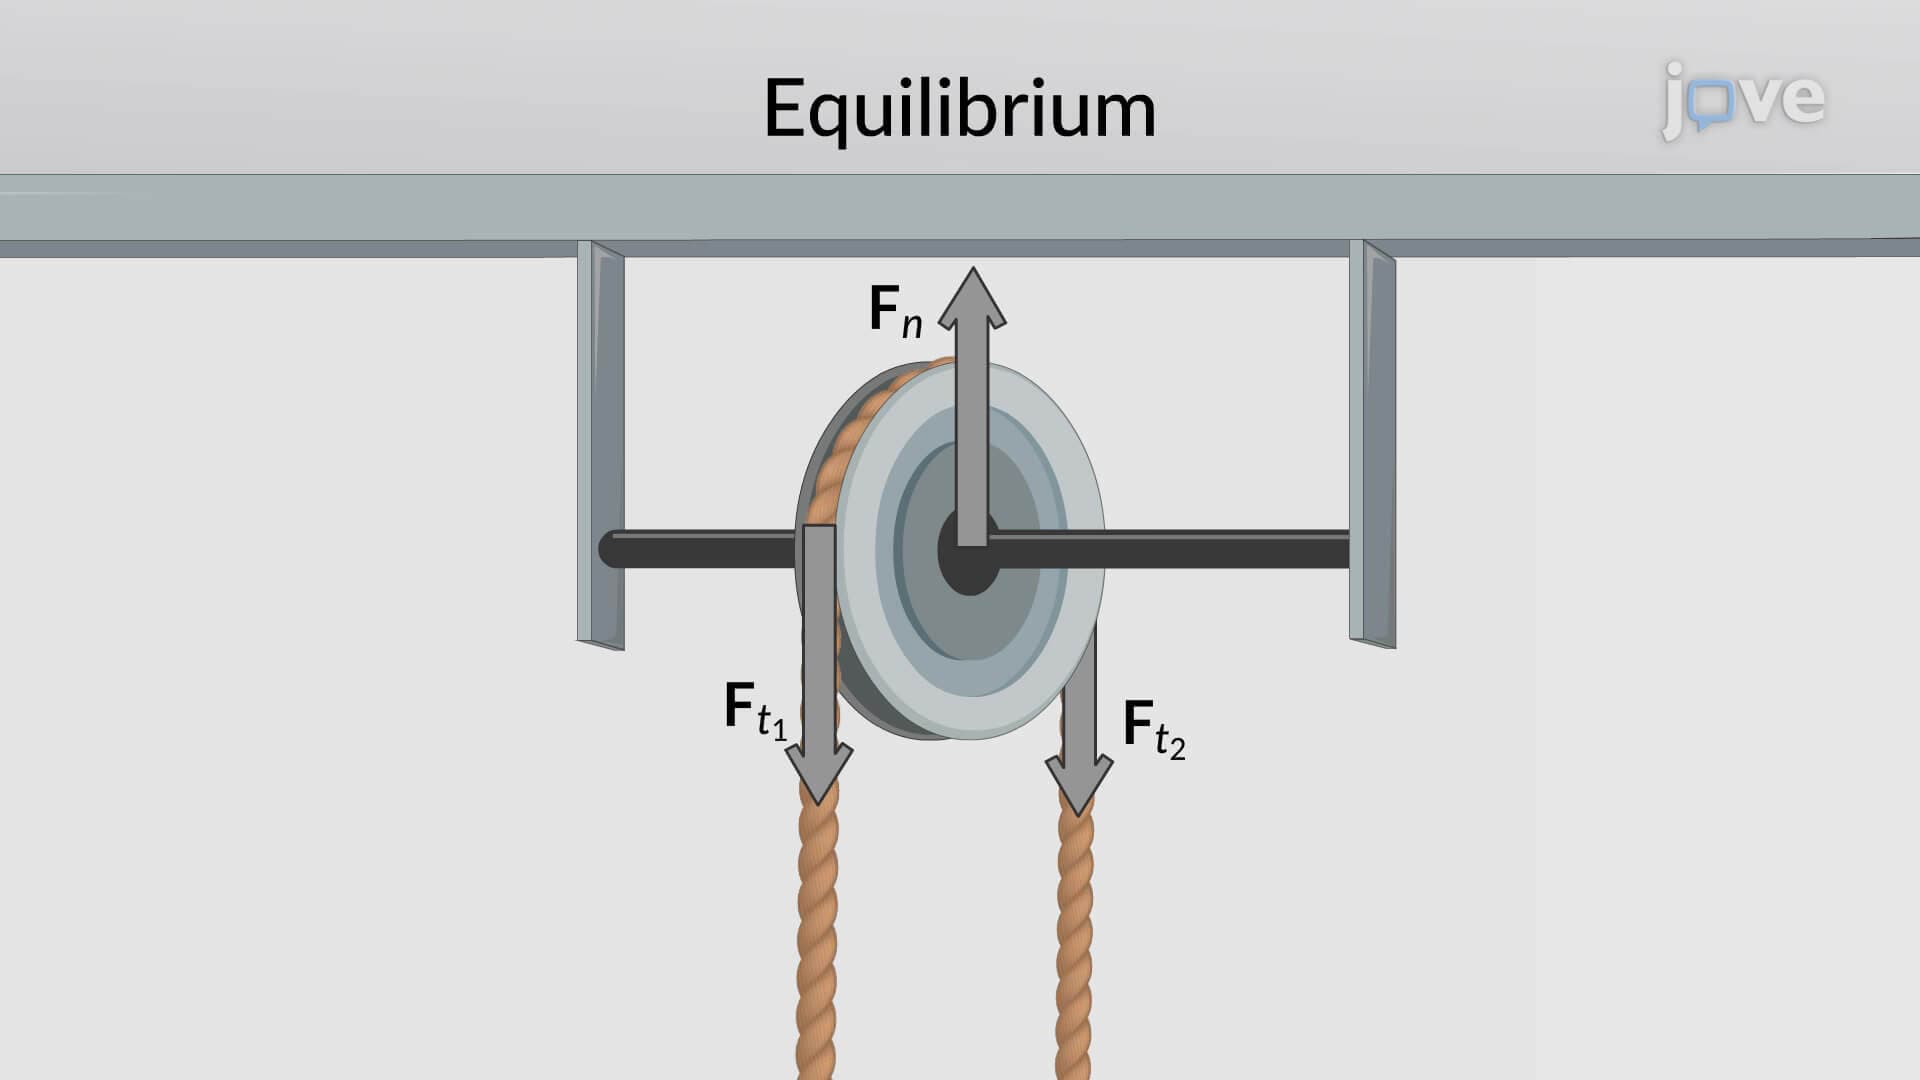
To understand the concept of equilibrium, let us first consider the forces acting on an object. When different forces act on an object, they can...