Multibody system dynamics for bio-inspired locomotion: from geometric structures to computational aspects
Related Experiment Video
Updated: Apr 15, 2026
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Frédéric Boyer1, Mathieu Porez
1IRCCyN, Ecole des Mines de Nantes, La Chantrerie - 4, rue Alfred Kastler, B.P. 20722, 44307 NANTES Cedex 3, France.

Abstract:
This article presents a set of generic tools for multibody system dynamics devoted to the study of bio-inspired locomotion in robotics. First, archetypal examples from the field of bio-inspired robot locomotion are presented to prepare the ground for further discussion. The general problem of locomotion is then stated. In considering this problem, we progressively draw a unified geometric picture of locomotion dynamics. For that purpose, we start from the model of discrete mobile multibody systems (MMSs) that we progressively extend to the case of continuous and finally soft systems. Beyond these theoretical aspects, we address the practical problem of the efficient computation of these models by proposing a Newton-Euler-based approach to efficient locomotion dynamics with a few illustrations of creeping, swimming, and flying.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
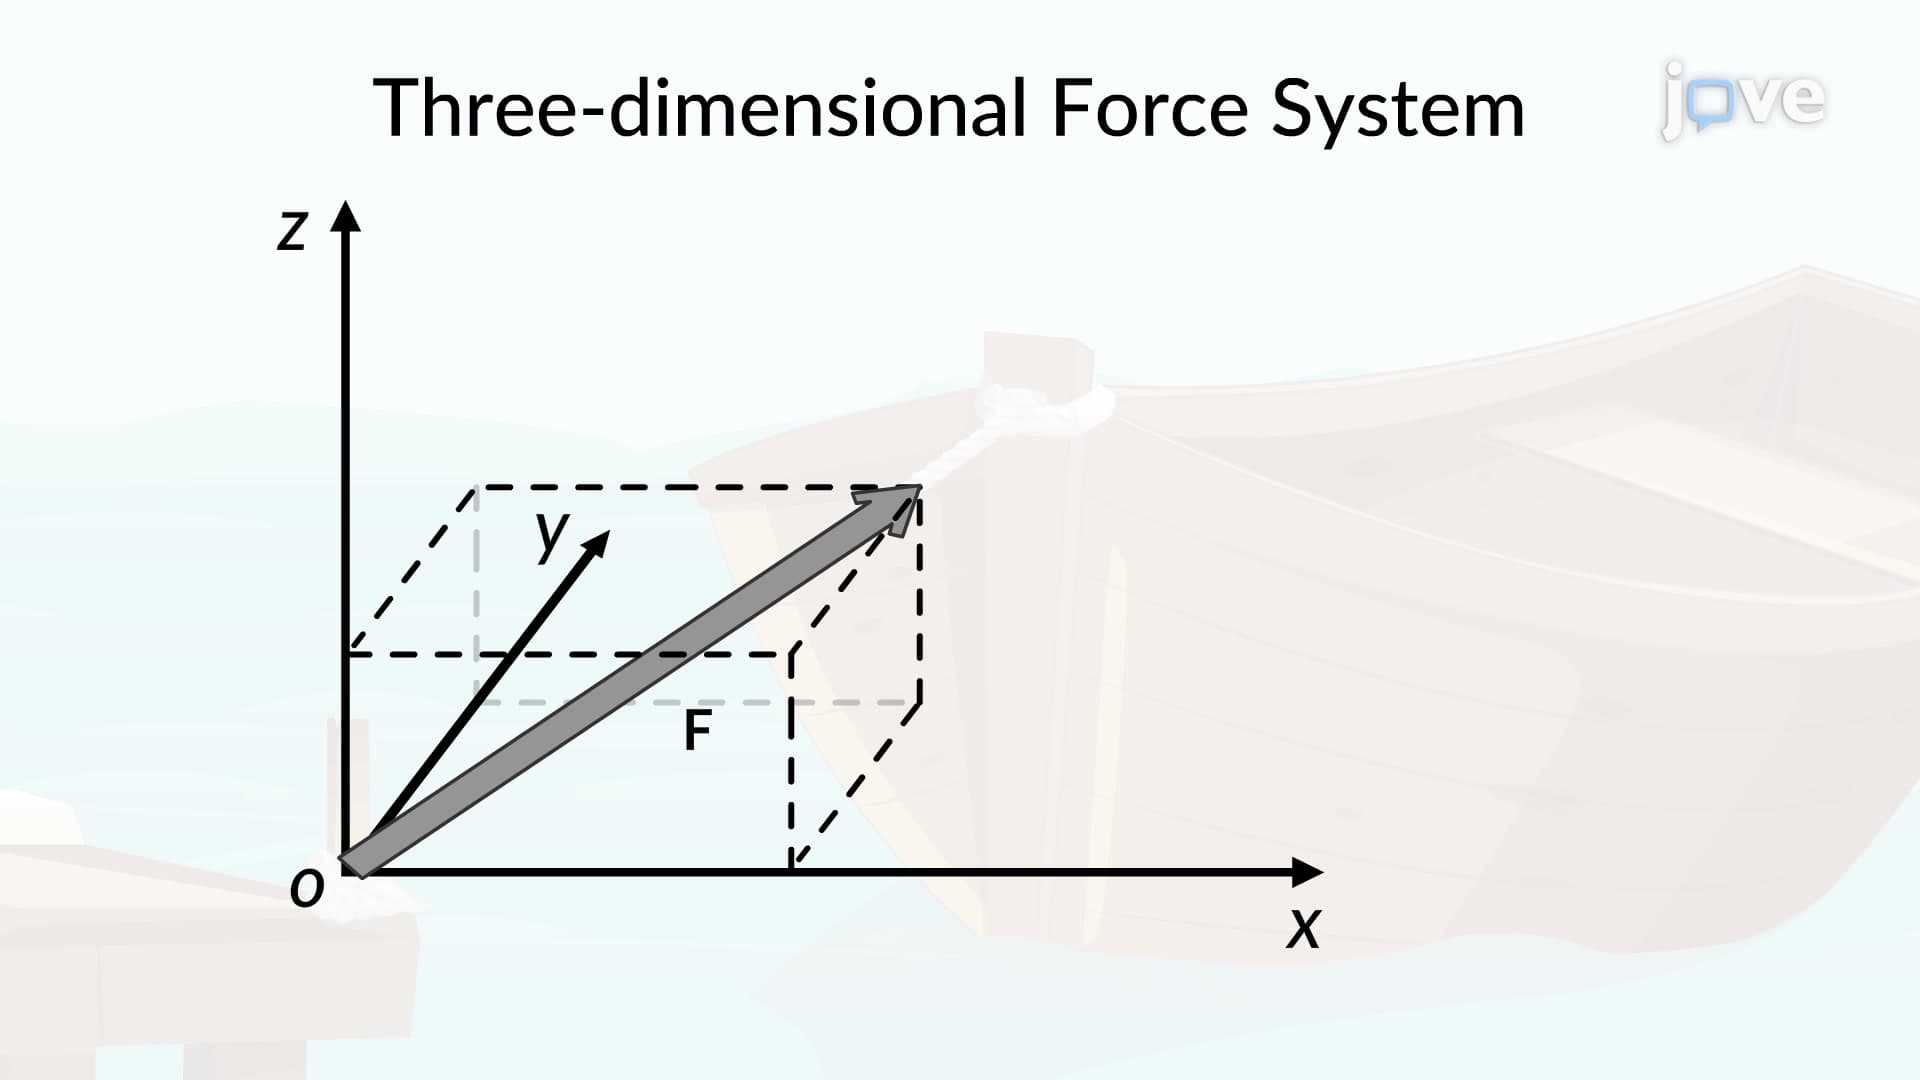 01:30
Three-Dimensional Force System
 00:58
Introduction to Joints
 01:15
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
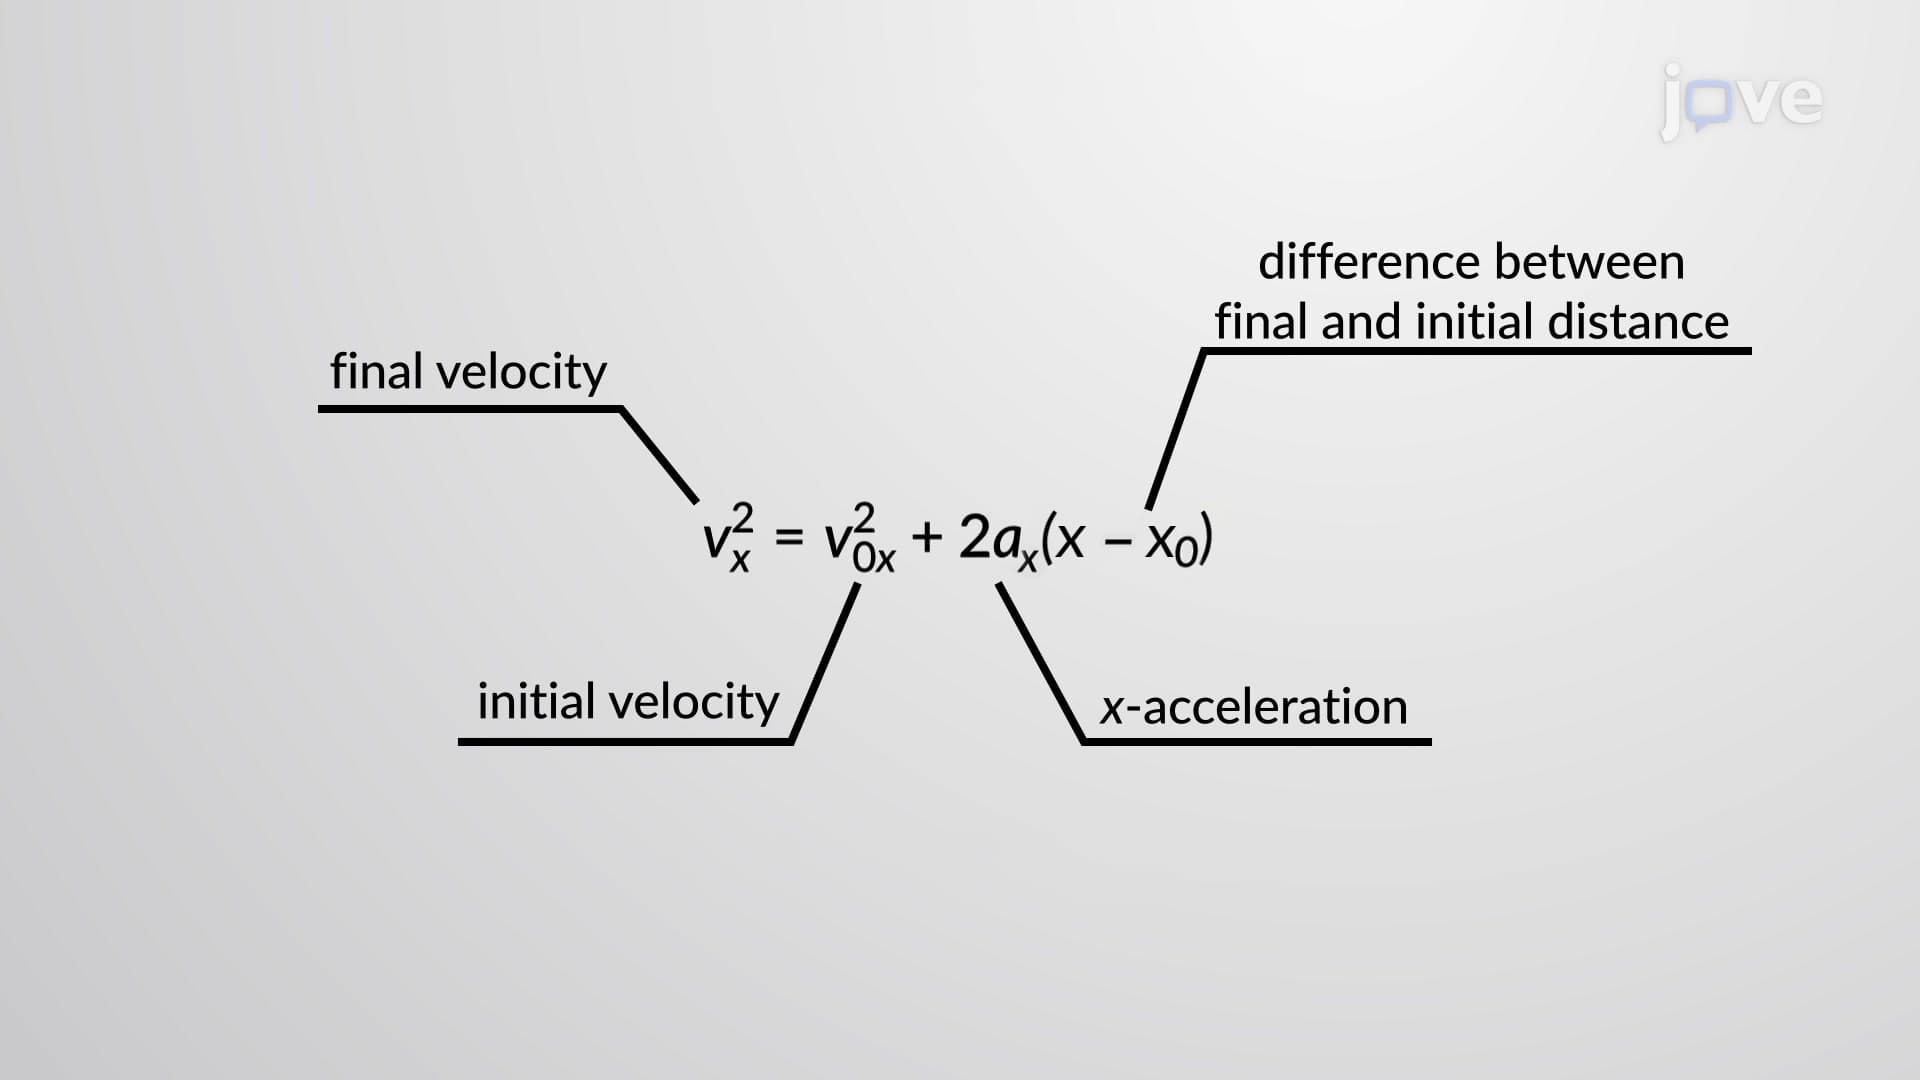
Using the kinematic equations,...