
Modeling and control of non-square MIMO system using relay feedback
D Kalpana1, T Thyagarajan1, N Gokulraj1
1Department of Instrumentation Engineering, Madras Institute of Technology Campus, Anna University, Chennai 44, India.

Abstract:
This paper proposes a systematic approach for the modeling and control of non-square MIMO systems in time domain using relay feedback. Conventionally, modeling, selection of the control configuration and controller design of non-square MIMO systems are performed using input/output information of direct loop, while the output of undesired responses that bears valuable information on interaction among the loops are not considered. However, in this paper, the undesired response obtained from relay feedback test is also taken into consideration to extract the information about the interaction between the loops. The studies are performed on an Air Path Scheme of Turbocharged Diesel Engine (APSTDE) model, which is a typical non-square MIMO system, with input and output variables being 3 and 2 respectively. From the relay test response, the generalized analytical expressions are derived and these analytical expressions are used to estimate unknown system parameters and also to evaluate interaction measures. The interaction is analyzed by using Block Relative Gain (BRG) method. The model thus identified is later used to design appropriate controller to carry out closed loop studies. Closed loop simulation studies were performed for both servo and regulatory operations. Integral of Squared Error (ISE) performance criterion is employed to quantitatively evaluate performance of the proposed scheme. The usefulness of the proposed method is demonstrated on a lab-scale Two-Tank Cylindrical Interacting System (TTCIS), which is configured as a non-square system.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
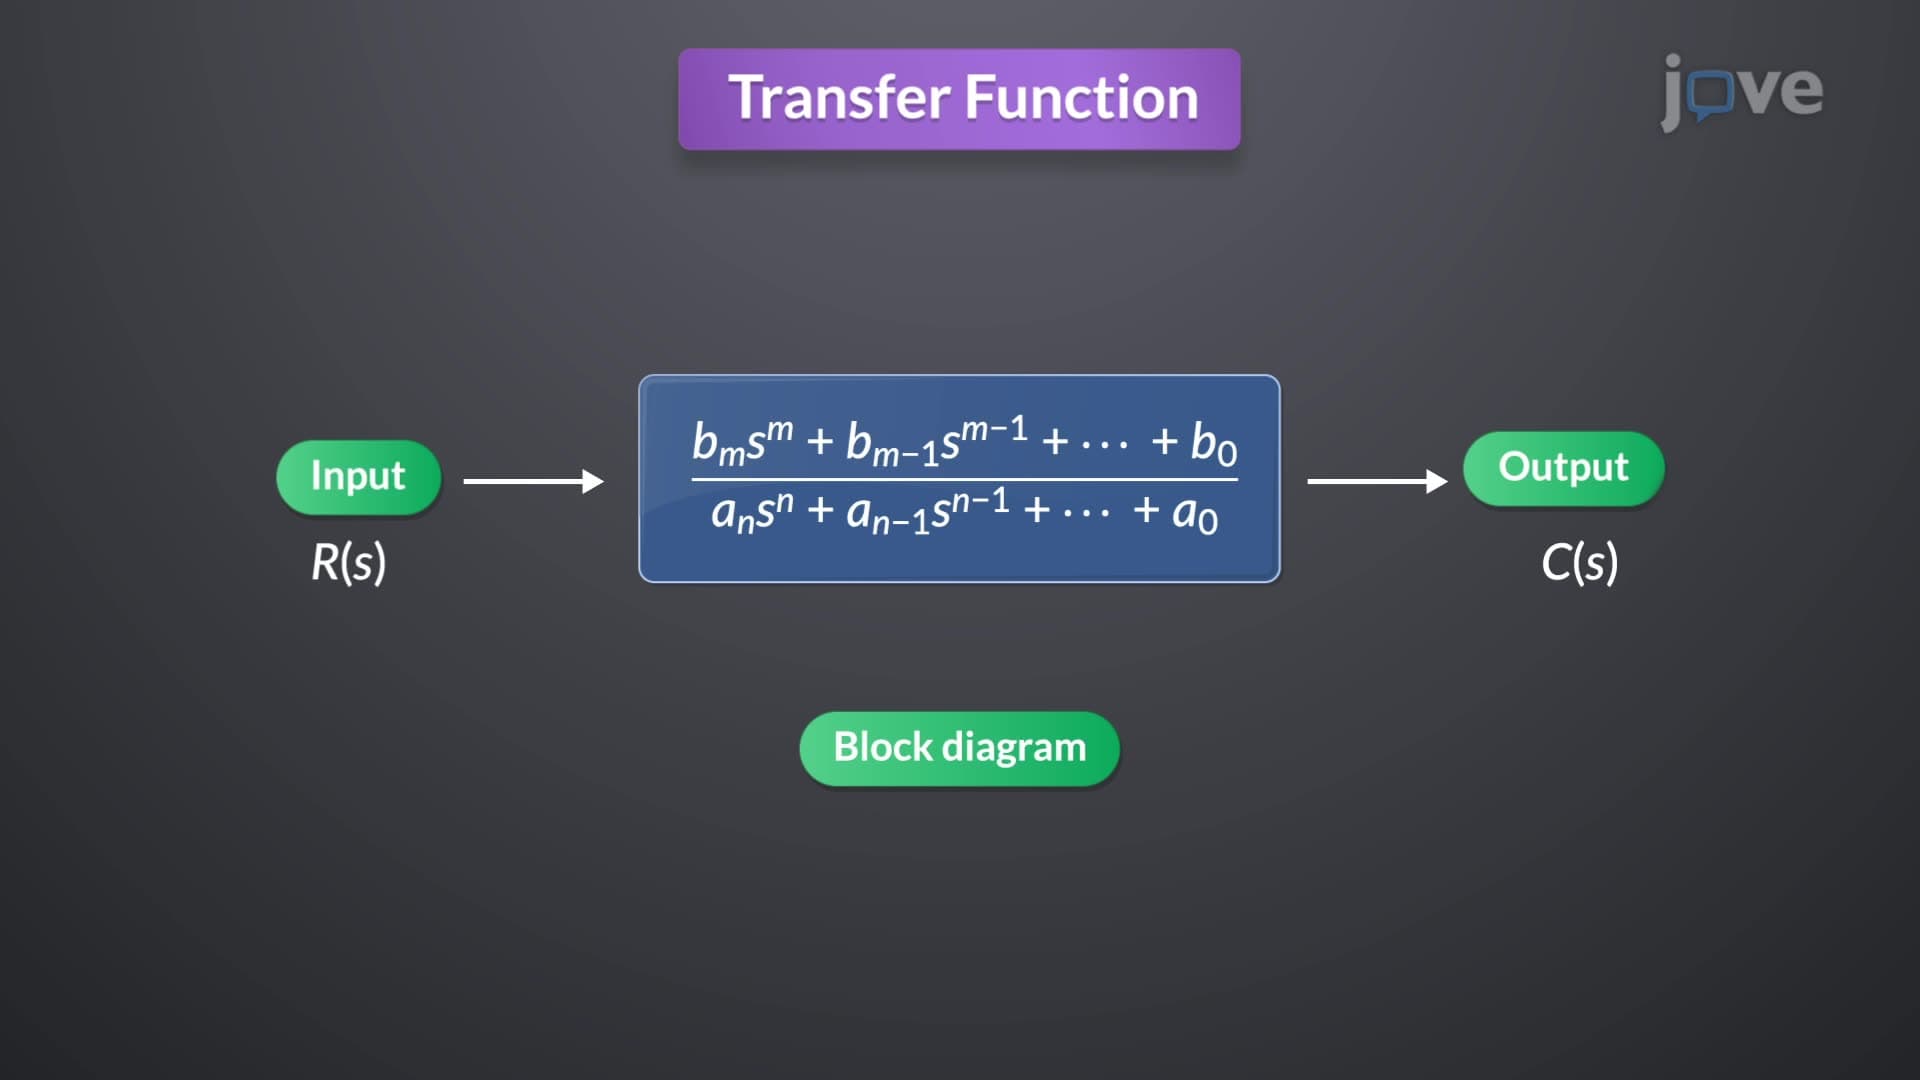
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:25
Directional Relays
 01:20
Differential Relays