

Adaptive fuzzy predictive sliding control of uncertain nonlinear systems with bound-known input delay
Mostafa Khazaee1, Amir H D Markazi1, Ehsan Omidi2
1Digital Control Laboratory, School of Mechanical Engineering, Iran University of Science and Technology, Narmak, 16844 Tehran, Iran.

Abstract:
In this paper, a new Adaptive Fuzzy Predictive Sliding Mode Control (AFP-SMC) is presented for nonlinear systems with uncertain dynamics and unknown input delay. The control unit consists of a fuzzy inference system to approximate the ideal linearization control, together with a switching strategy to compensate for the estimation errors. Also, an adaptive fuzzy predictor is used to estimate the future values of the system states to compensate for the time delay. The adaptation laws are used to tune the controller and predictor parameters, which guarantee the stability based on a Lyapunov-Krasovskii functional. To evaluate the method effectiveness, the simulation and experiment on an overhead crane system are presented. According to the obtained results, AFP-SMC can effectively control the uncertain nonlinear systems, subject to input delays of known bound.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
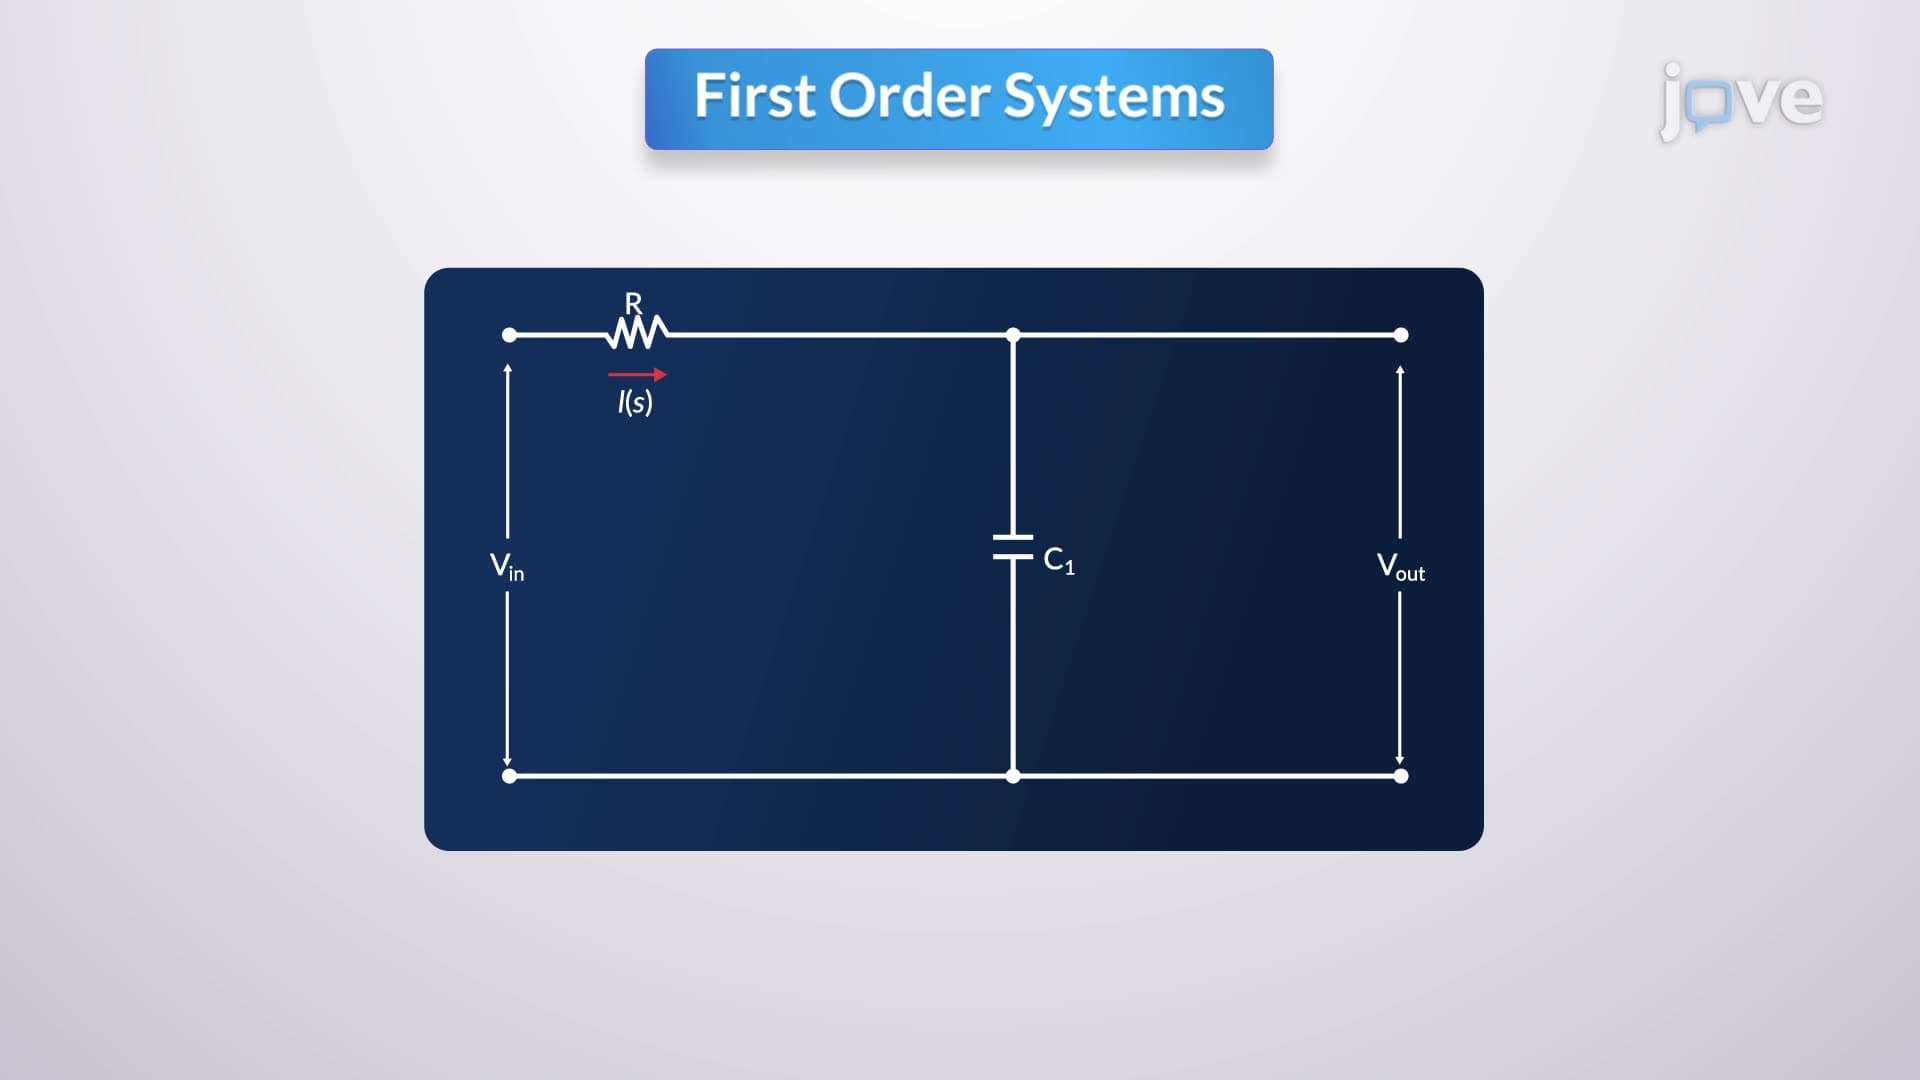
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:22
Multi-input and Multi-variable systems
In the absence of...