Reaching is Better When You Get What You Want: Realtime Feedback of Intended Reaching Trajectory Despite an Unstable Environment
Related Experiment Video
Updated: Mar 26, 2026
Movement Retraining using Real-time Feedback of Performance
Published on: January 17, 2013
Justin Horowitz1, Tejas Madhavan1, Christine Massie1
1Neuro-Machine Interaction Laboratory, Bionengineering, University of Illinois at ChicagoChicago, IL, USA; Robotics Lab, Rehabilitation Institute of Chicago, Sensory Motor Performance ProgramChicago, IL, USA.

Abstract:
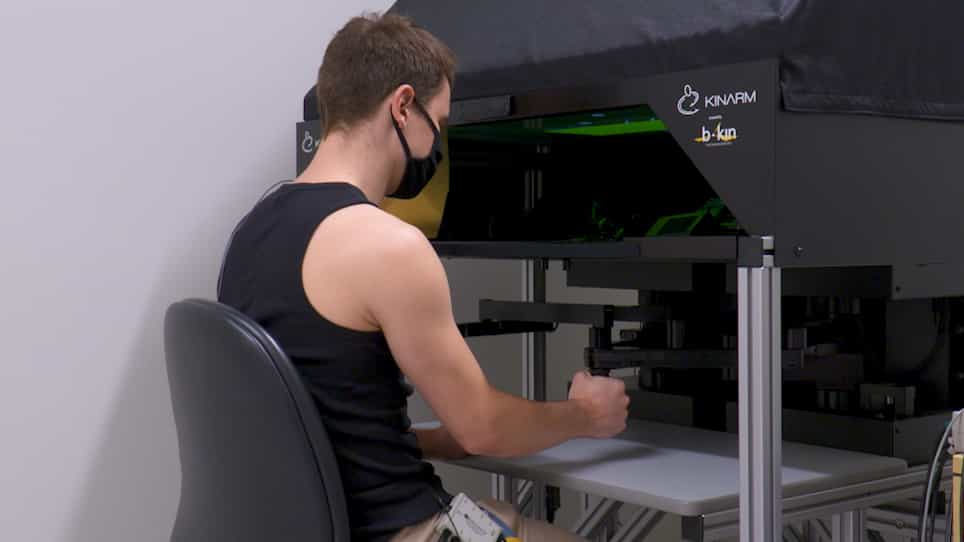
Improvements in human-machine interaction may help overcome the unstable and uncertain environments that cause problems in everyday living. Here we experimentally evaluated intent feedback (IF), which estimates and displays the human operator's underlying intended trajectory in real-time. IF is a filter that combines a model of the arm with position and force data to determine the intended position. Subjects performed targeted reaching motions while seeing either their actual hand position or their estimated intent as a cursor while they experienced white noise forces rendered by a robotic handle. We found significantly better reaching performance during force exposure using the estimated intent. Additionally, in a second set of subjects with a reduced modeled stiffness, IF reduced estimated arm stiffness to about half that without IF, indicating a more relaxed state of operation. While visual distortions typically degrade performance and require an adaptation period to overcome, this particular distortion immediately enhanced performance. In the future, this method could provide novel insights into the nature of control. IF might also be applied in driving and piloting applications to best follow a person's desire in unpredictable or turbulent conditions.
Related Concept Videos
 01:26
Orthogonal Trajectories
 01:26
Impact: Problem Solving
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Errors in Global Positioning System
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...