Motion Capture With Ellipsoidal Skeleton Using Multiple Depth Cameras
Related Experiment Video
Updated: Mar 26, 2026

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023

Abstract:
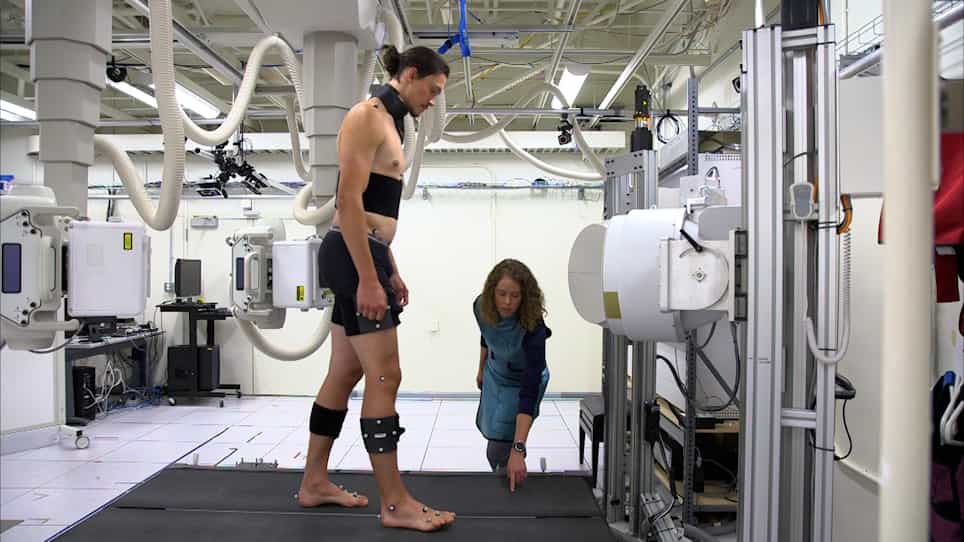
This paper introduces a novel motion capturing framework which works by minimizing the fitting error between an ellipsoid based skeleton and the input point cloud data captured by multiple depth cameras. The novelty of this method comes from that it uses the ellipsoids equipped with the spherical harmonics encoded displacement and normal functions to capture the geometry details of the tracked object. This method is also integrated with a mechanism to avoid collisions of bones during the motion capturing process. The method is implemented parallelly with CUDA on GPU and has a fast running speed without dedicated code optimization. The errors of the proposed method on the data from Berkeley Multimodal Human Action Database (MHAD) are within a reasonable range compared with the ground truth results. Our experiment shows that this method succeeds on many challenging motions which are failed to be reported by Microsoft Kinect SDK and not tested by existing works. In the comparison with the state-of-art marker-less depth camera based motion tracking work our method shows advantages in both robustness and input data modality.

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...