Deformable Model-Based Methods for Shape Control of a Haptic Jamming Surface
Related Experiment Video
Updated: Mar 26, 2026

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023

Abstract:
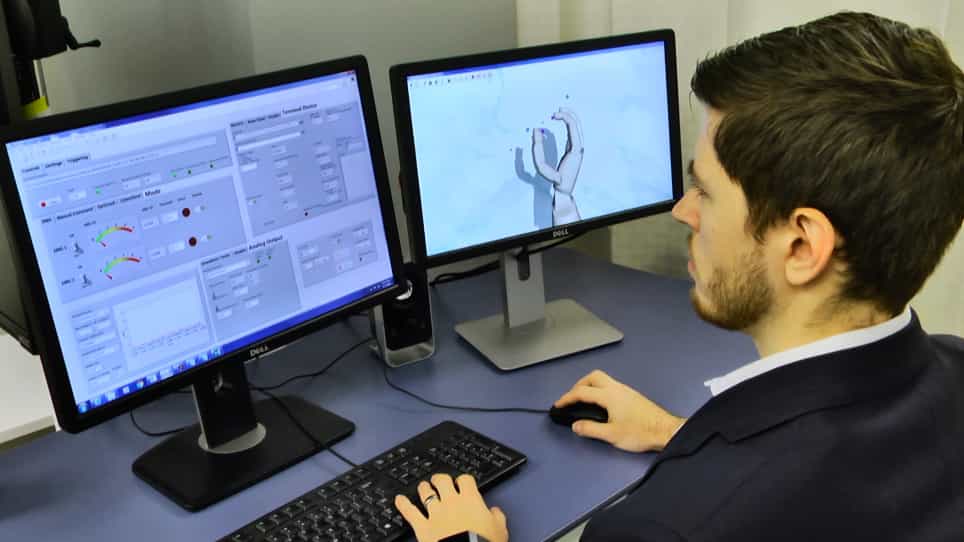
Haptic Jamming, the approach of simultaneously controlling mechanical properties and surface deformation of a tactile display via particle jamming and pneumatics, shows promise as a tangible, shape-changing human-computer interface. Previous research introduced device design and described the force-displacement interactions for individual jamming cells. The work in this article analyzes the shape output capabilities of a multi-cell array. A spring-mass deformable body simulation combines models of the three actuation inputs of a Haptic Jamming surface: node pinning, chamber pressurization, and cell jamming. Surface measurements of a 12-cell prototype from a depth camera fit the mass and stiffness parameters to the device during pressurization tests and validate the accuracy of the model for various actuation sequences. The simulator is used to develop an algorithm that generates a sequence of actuation inputs for a Haptic Jamming array of any size in order to match a desired surface output shape. Data extracted from topographical maps and three-dimensional solid object models are used to evaluate the shape-matching algorithm and assess the utility of increasing array size and resolution. Results show that a discrete Laplace operator applied to the input is a suitable predictor of the correlation coefficient between the desired shape and the device output.

Related Concept Videos
 01:20
Plastic Deformation in Circular Shafts
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:10
Deformation in a Circular Shaft
 01:04
Hydrostatic Pressure Force on a Curved Surface
 01:12
Temperature Dependent Deformation
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...