Composite disturbance rejection control based on generalized extended state observer

Yanjun Zhang1, Jun Zhang1, Lu Wang1
1Department of Automation; Key Laboratory of System Control and Information Processing, Ministry of Education, Shanghai Jiao Tong University, Shanghai 200240, PR China.

Abstract:
Traditional extended state observer (ESO) design method does not focus on analysis of system reconstruction strategy. The prior information of the controlled system cannot be used for ESO implementation to improve the control accuracy. In this paper, composite disturbance rejection control strategy is proposed based on generalized ESO. First, the disturbance rejection performance of traditional ESO is analyzed to show the essence of the reconstruction strategy. Then, the system is reconstructed based on the equivalent disturbance model. The generalized ESO is proposed based on the reconstructed model, while convergence of the proposed ESO is analyzed along with the outer loop feedback controller. Simulation results on a second order mechanical system show that the proposed generalized ESO can deal with the external disturbance with known model successfully. Experiment of attitude tracking task on an aircraft is also carried out to show the effectiveness of the proposed method.
More Related Videos
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
State Space to Transfer Function
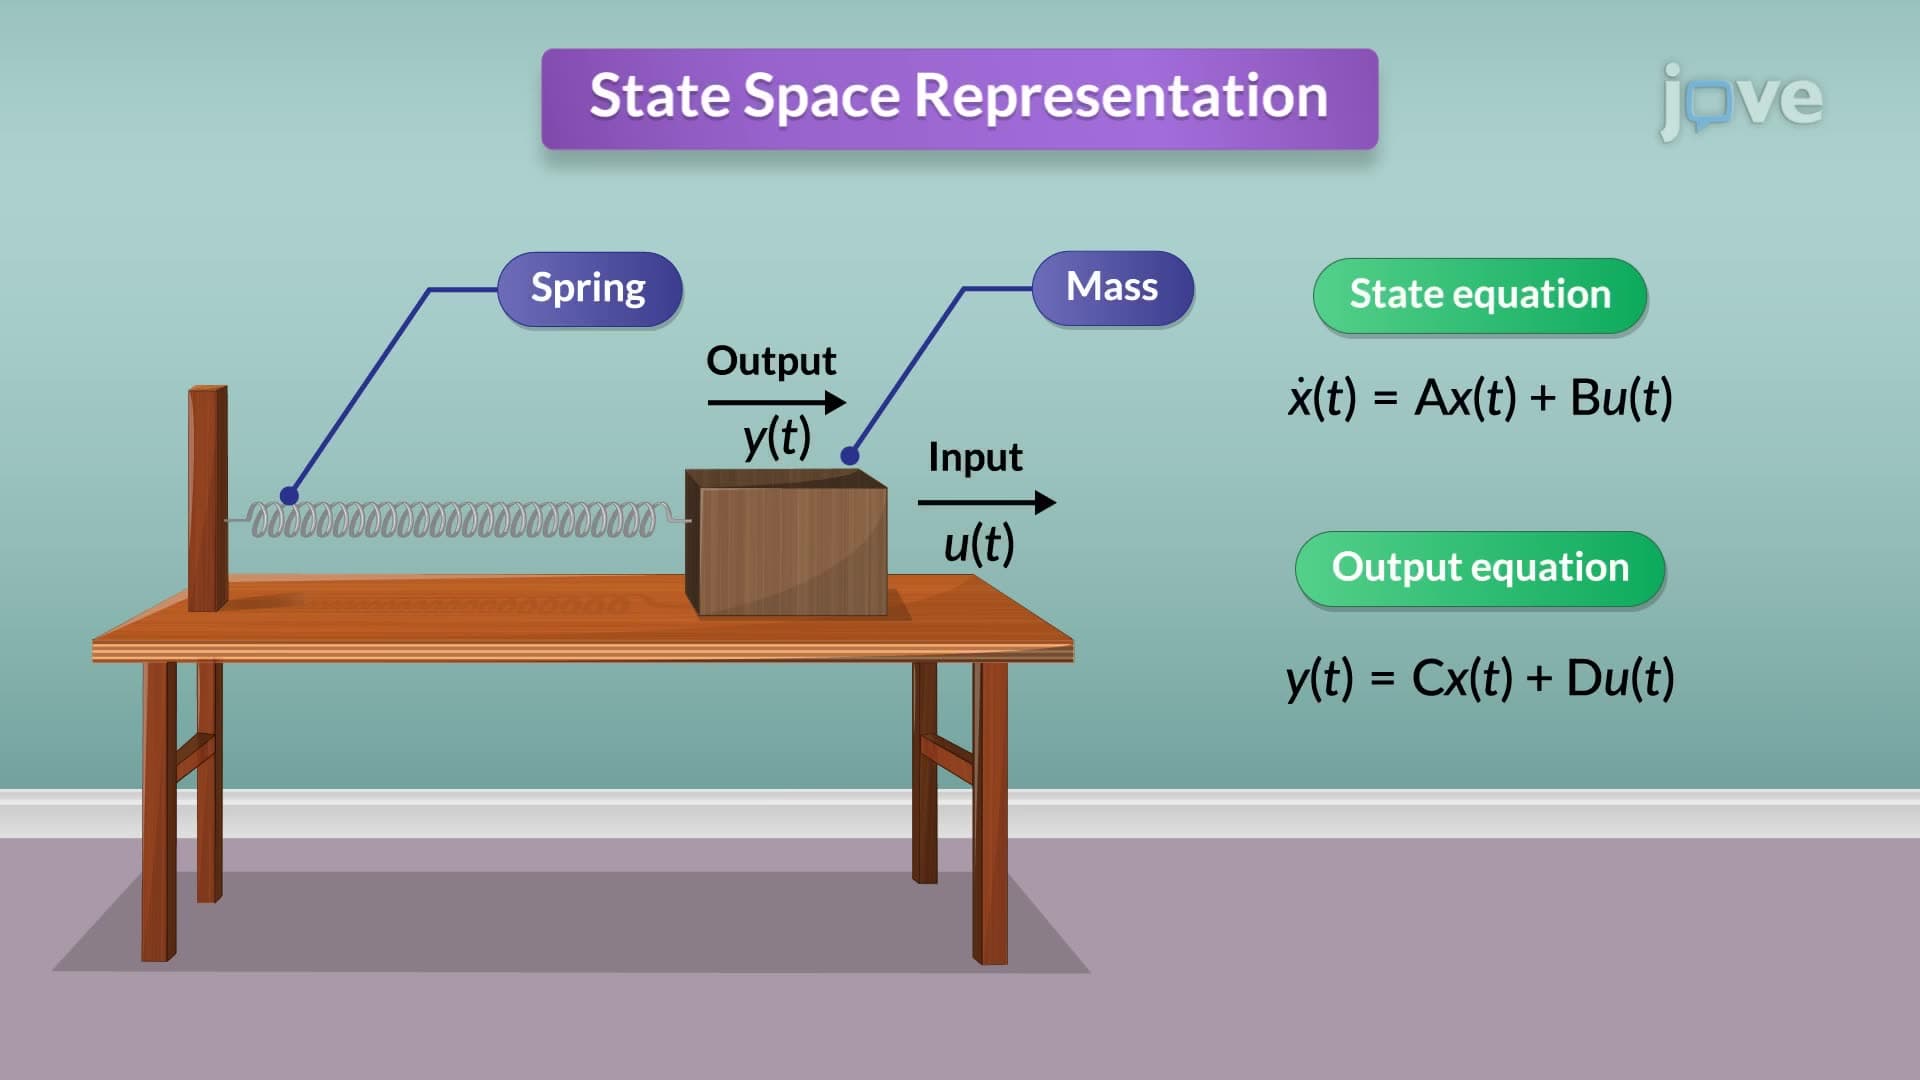
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:18
Second Order systems II
 01:23
Transfer Function to State Space
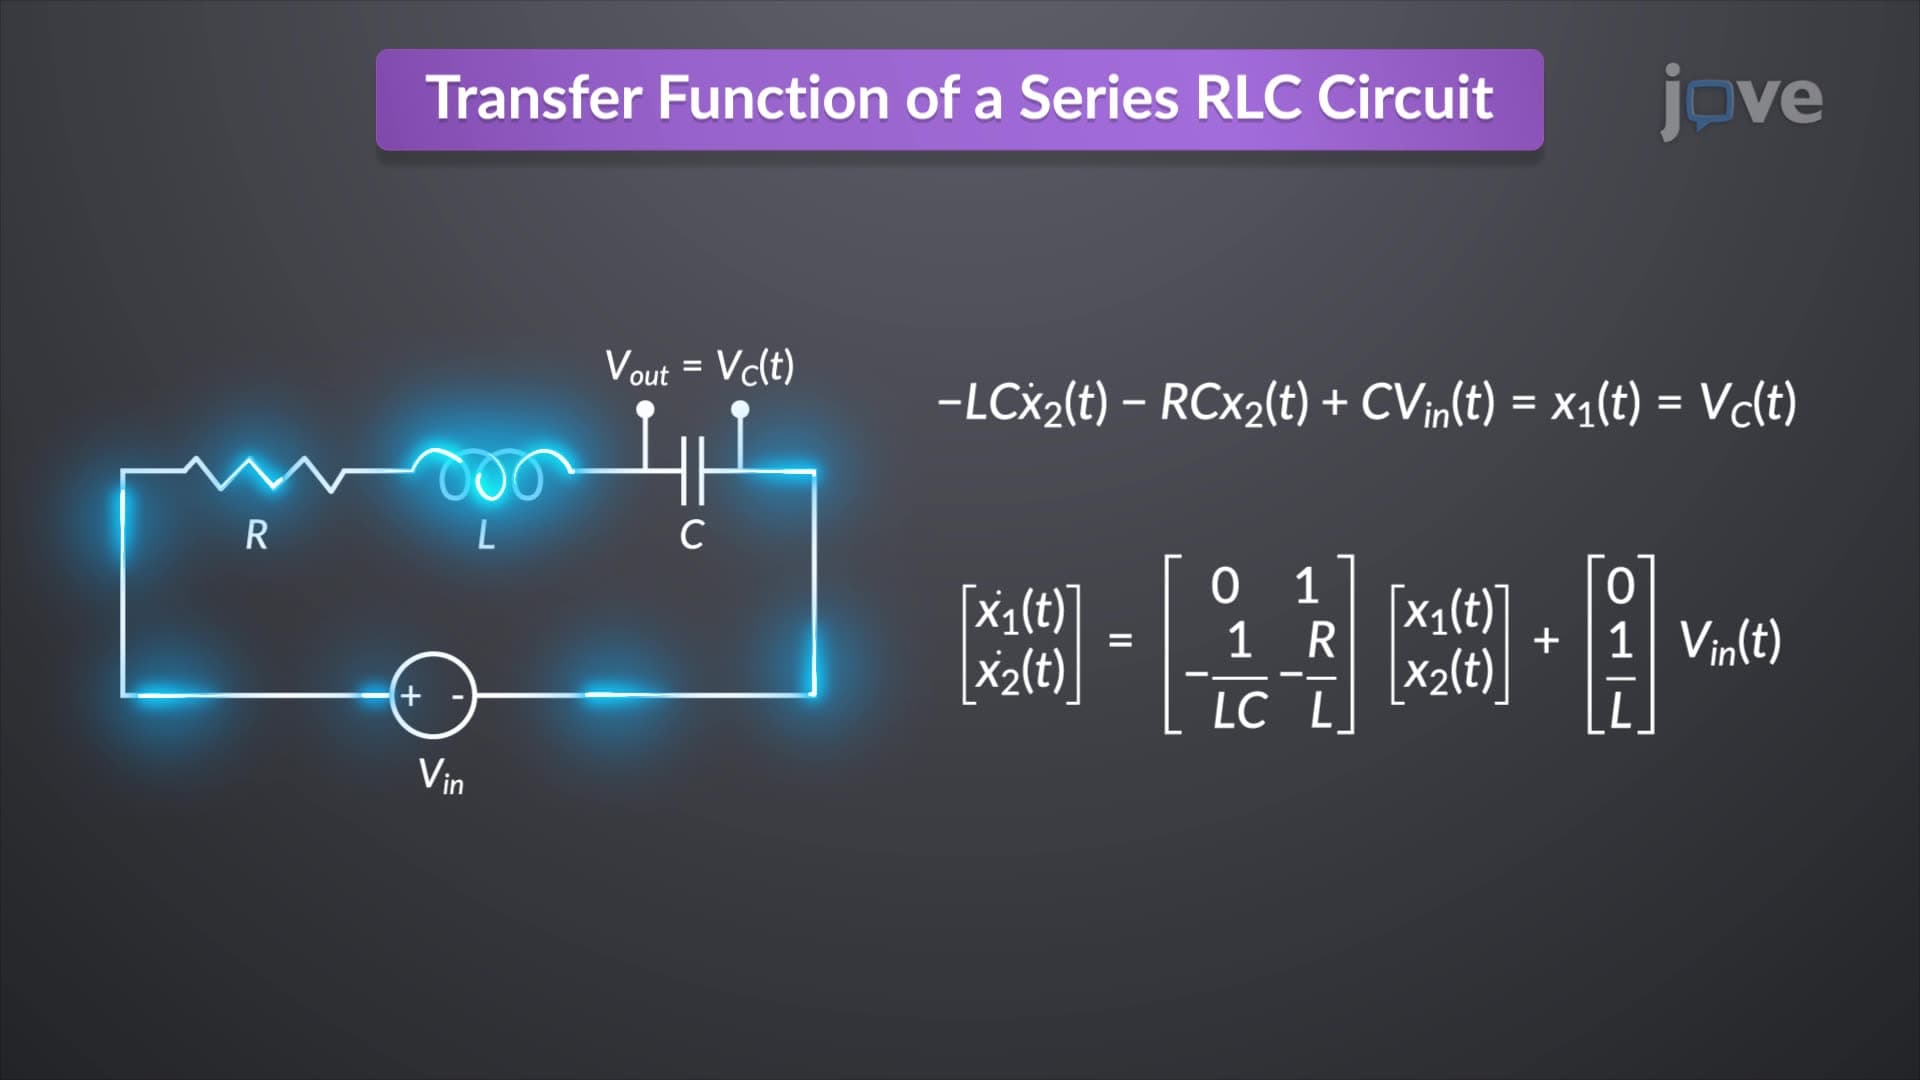
In an RLC...