Related Experiment Video
Updated: Mar 21, 2026


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
A biologically-inspired multi-joint soft exosuit that can reduce the energy cost of loaded walking
Fausto A Panizzolo1,2, Ignacio Galiana1,2, Alan T Asbeck1,2
1John A. Paulson School of Engineering and Applied Sciences, Harvard University, 29 Oxford Street, Cambridge, MA, 02138, USA.

Background:
Carrying load alters normal walking, imposes additional stress to the musculoskeletal system, and results in an increase in energy consumption and a consequent earlier onset of fatigue. This phenomenon is largely due to increased work requirements in lower extremity joints, in turn requiring higher muscle activation. The aim of this work was to assess the biomechanical and physiological effects of a multi-joint soft exosuit that applies assistive torques to the biological hip and ankle joints during loaded walking.
Methods:
The exosuit was evaluated under three conditions: powered (EXO_ON), unpowered (EXO_OFF) and unpowered removing the equivalent mass of the device (EXO_OFF_EMR). Seven participants walked on an instrumented split-belt treadmill and carried a load equivalent to 30 % their body mass. We assessed their metabolic cost of walking, kinetics, kinematics, and lower limb muscle activation using a portable gas analysis system, motion capture system, and surface electromyography.
Results:
Our results showed that the exosuit could deliver controlled forces to a wearer. Net metabolic power in the EXO_ON condition (7.5 ± 0.6 W kg(-1)) was 7.3 ± 5.0 % and 14.2 ± 6.1 % lower than in the EXO_OFF_EMR condition (7.9 ± 0.8 W kg(-1); p = 0.027) and in the EXO_OFF condition (8.5 ± 0.9 W kg(-1); p = 0.005), respectively. The exosuit also reduced the total joint positive biological work (sum of hip, knee and ankle) when comparing the EXO_ON condition (1.06 ± 0.16 J kg(-1)) with respect to the EXO_OFF condition (1.28 ± 0.26 J kg(-1); p = 0.020) and to the EXO_OFF_EMR condition (1.22 ± 0.21 J kg(-1); p = 0.007).
Conclusions:
The results of the present work demonstrate for the first time that a soft wearable robot can improve walking economy. These findings pave the way for future assistive devices that may enhance or restore gait in other applications.
More Related Videos
 06:00
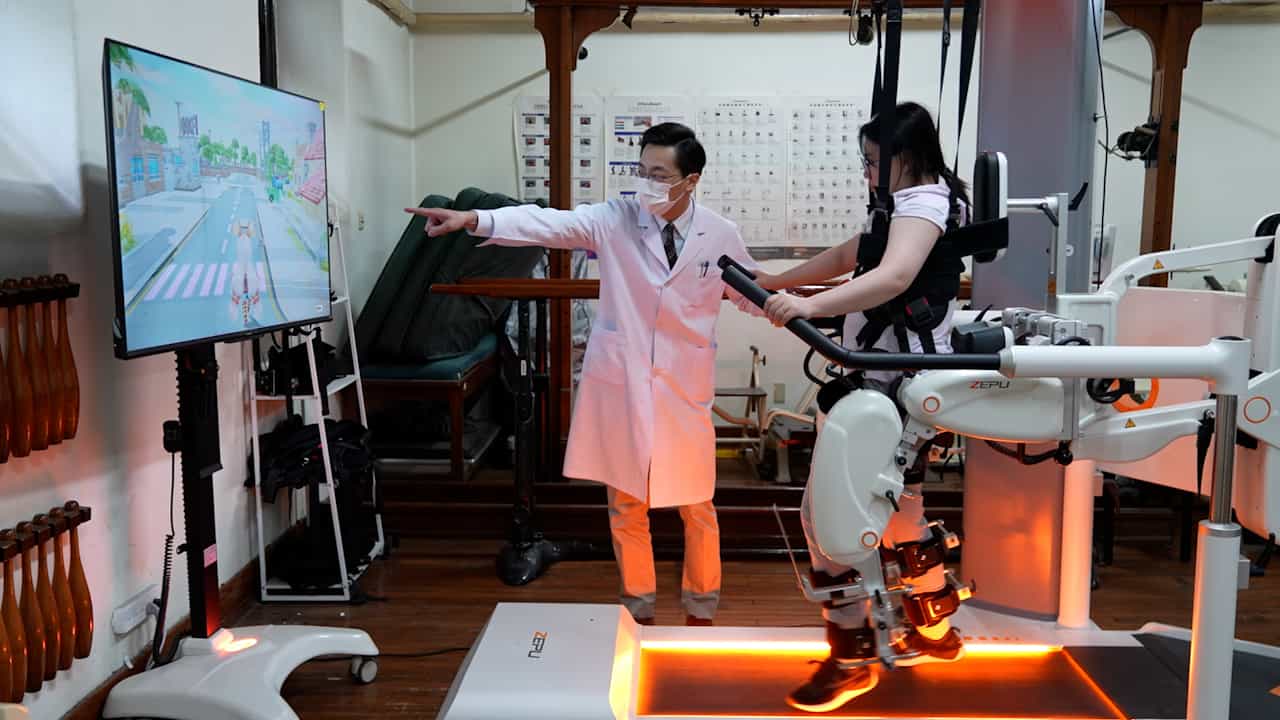
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
 03:55
Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
Related Concept Videos
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:10
Ankle Joint
 00:58
Introduction to Joints
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
 01:10
Bones of the Lower Limb: Tibia and Fibula