Related Experiment Video
Updated: Mar 17, 2026

Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
On the use of a Euclidean norm function for the estimation of local dynamic stability from 3D kinematics using
Shawn M Beaudette1, Samuel J Howarth2, Ryan B Graham3
1Department of Human Health and Nutritional Sciences, University of Guelph, Guelph, ON, Canada.

Abstract:
Several different state-space reconstruction methods have been employed to assess the local dynamic stability (LDS) of a 3D kinematic system. One common method is to use a Euclidean norm (N) transformation of three orthogonal x, y, and z time-series' followed by the calculation of the maximum finite-time Lyapunov exponent (λmax) from the resultant N waveform (using a time-delayed state space reconstruction technique). By essentially acting as a weighted average, N has been suggested to account for simultaneous expansion and contraction along separate degrees of freedom within a 3D system (e.g. the coupling of dynamic movements between orthogonal planes). However, when estimating LDS using N, non-linear transformations inherent within the calculation of N should be accounted for. Results demonstrate that the use of N on 3D time-series data with arbitrary magnitudes of relative bias and zero-crossings cause the introduction of error in estimates of λmax obtained through N. To develop a standard for the analysis of 3D dynamic kinematic waveforms, we suggest that all dimensions of a 3D signal be independently shifted to avoid the incidence of zero-crossings prior to the calculation of N and subsequent estimation of LDS through the use of λmax.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:10
Equations of Motion: Normal and Tangetial Components
Newton's second law of motion is employed to articulate the...
 01:19
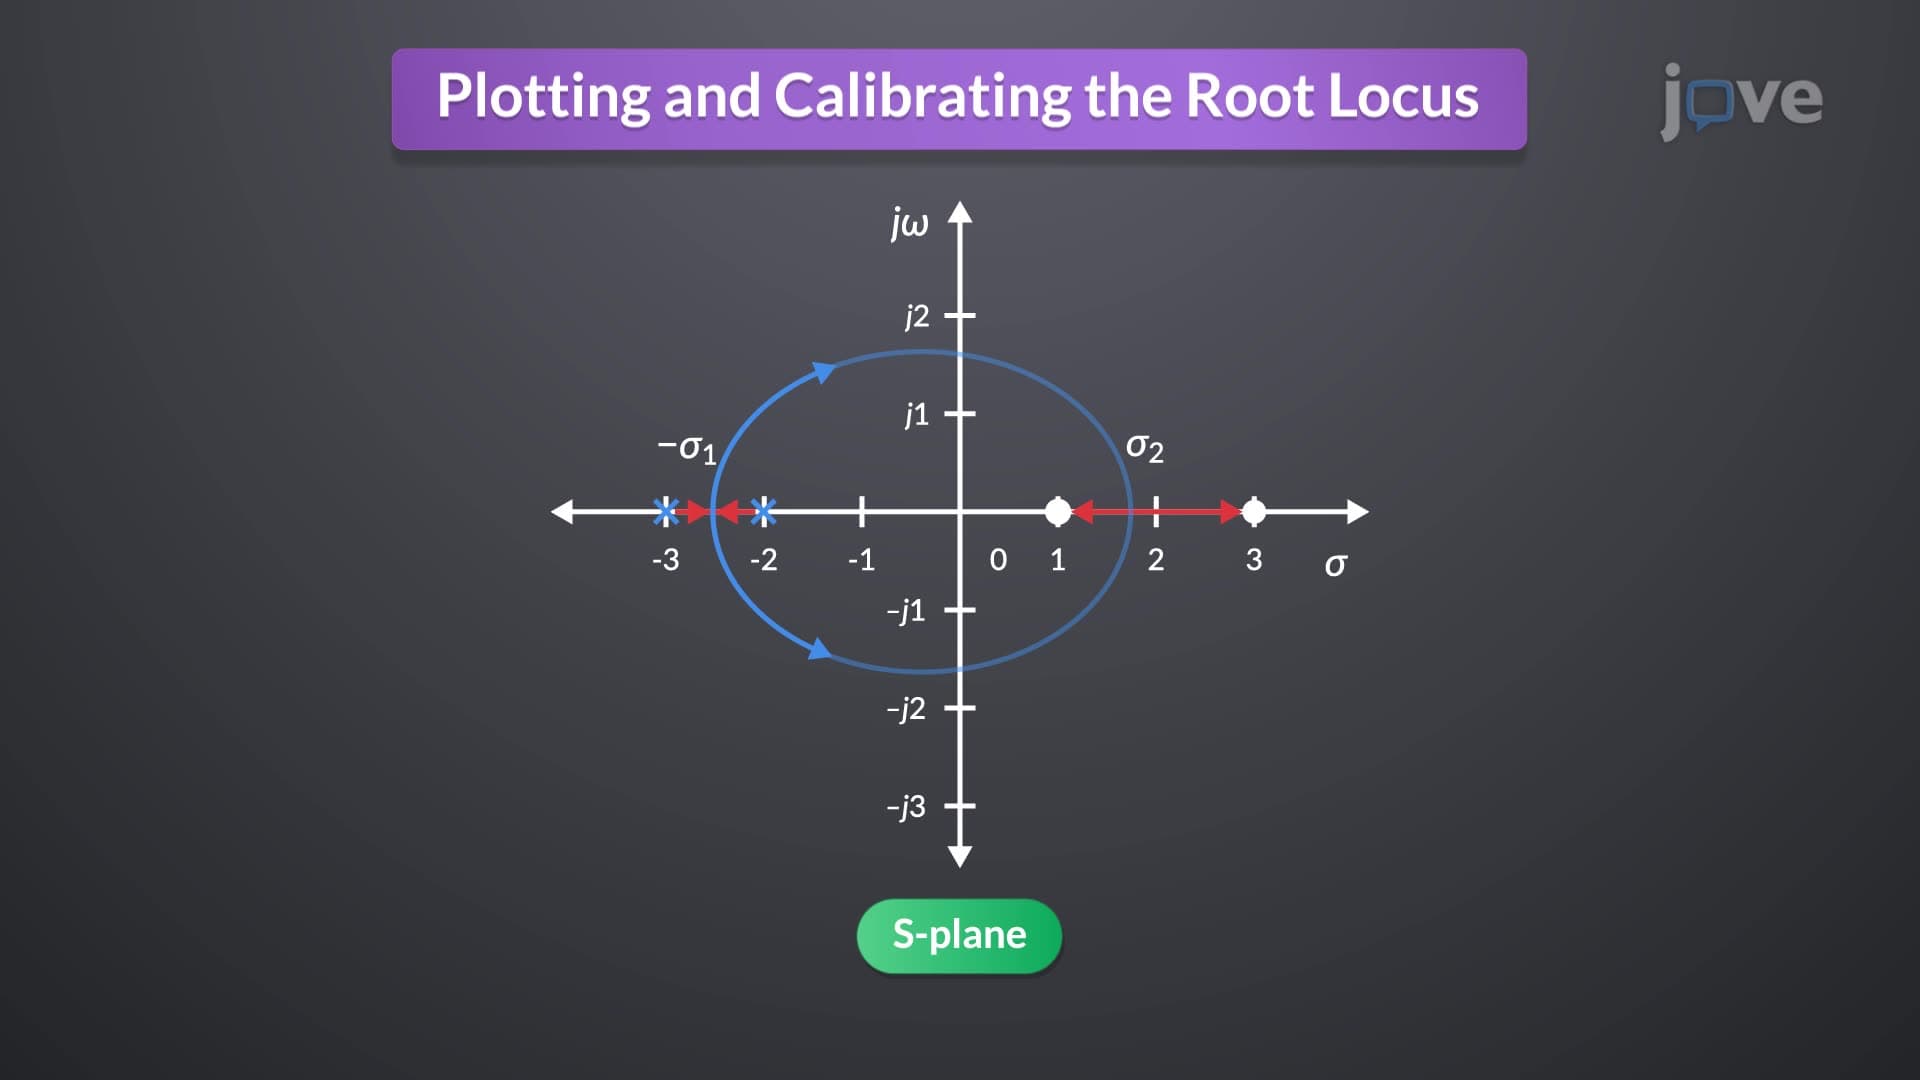
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:26
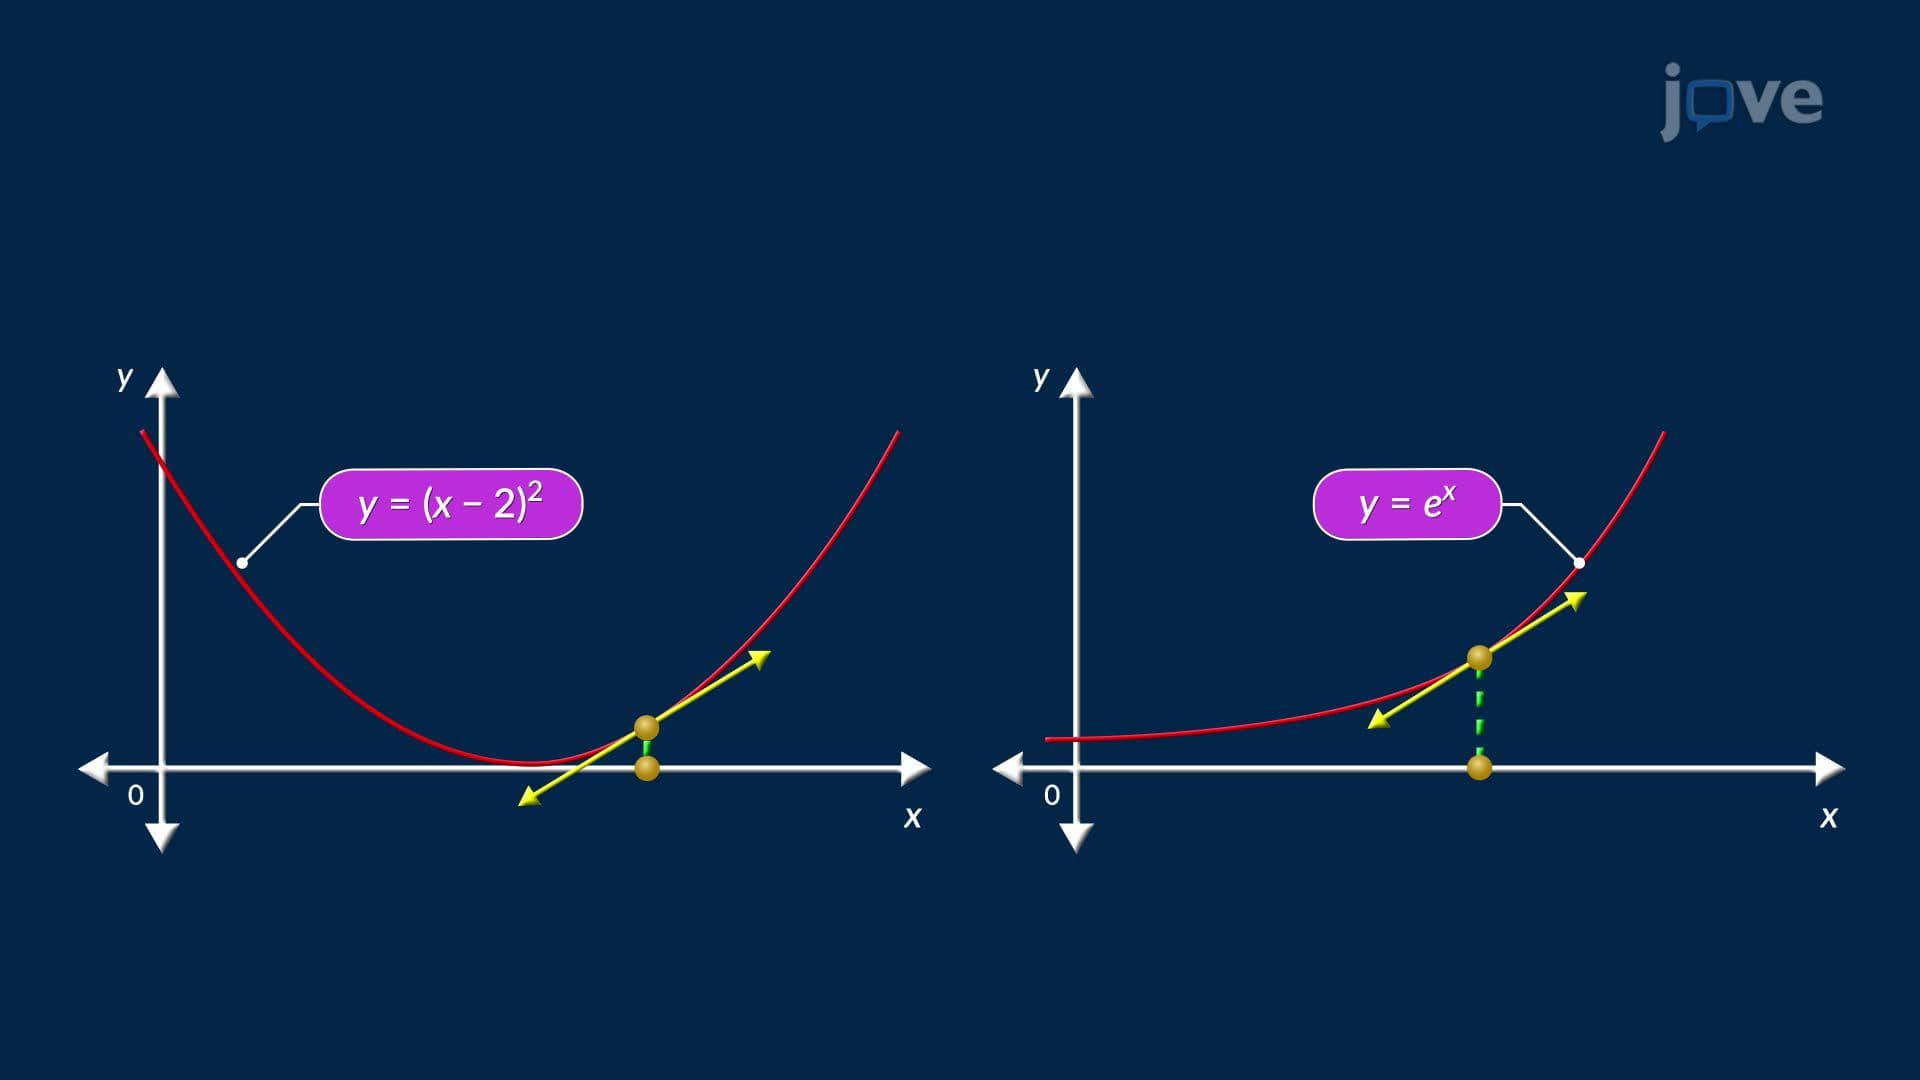
Linearization and Approximation