Related Experiment Video
Updated: Jul 17, 2026

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Comment on "Further improvement on delay-range-dependent robust absolute stability for Lur׳e uncertain systems with
Wenyong Duan1, Xiaorong Fu1, Zhengfan Liu2
1School of Electrical Engineering, YanCheng Institute of Technology, YanCheng, JiangSu 224051, China.

Abstract:
In a recent paper (ISA Transactions (2015)58: 58-66), an integral inequality has been proposed to reduce the conservativeness of stability conditions for Lur׳e uncertain systems. We point out that there exist some errors in Theorems 1-8, and the correct theorems are presented. Finally, the allowable maximum admissible upper bound (MAUB) listed in Tables 1-5 have been recalculated by using the correct results.
More Related Videos
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:10
Propagation of Uncertainty from Systematic Error
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:28
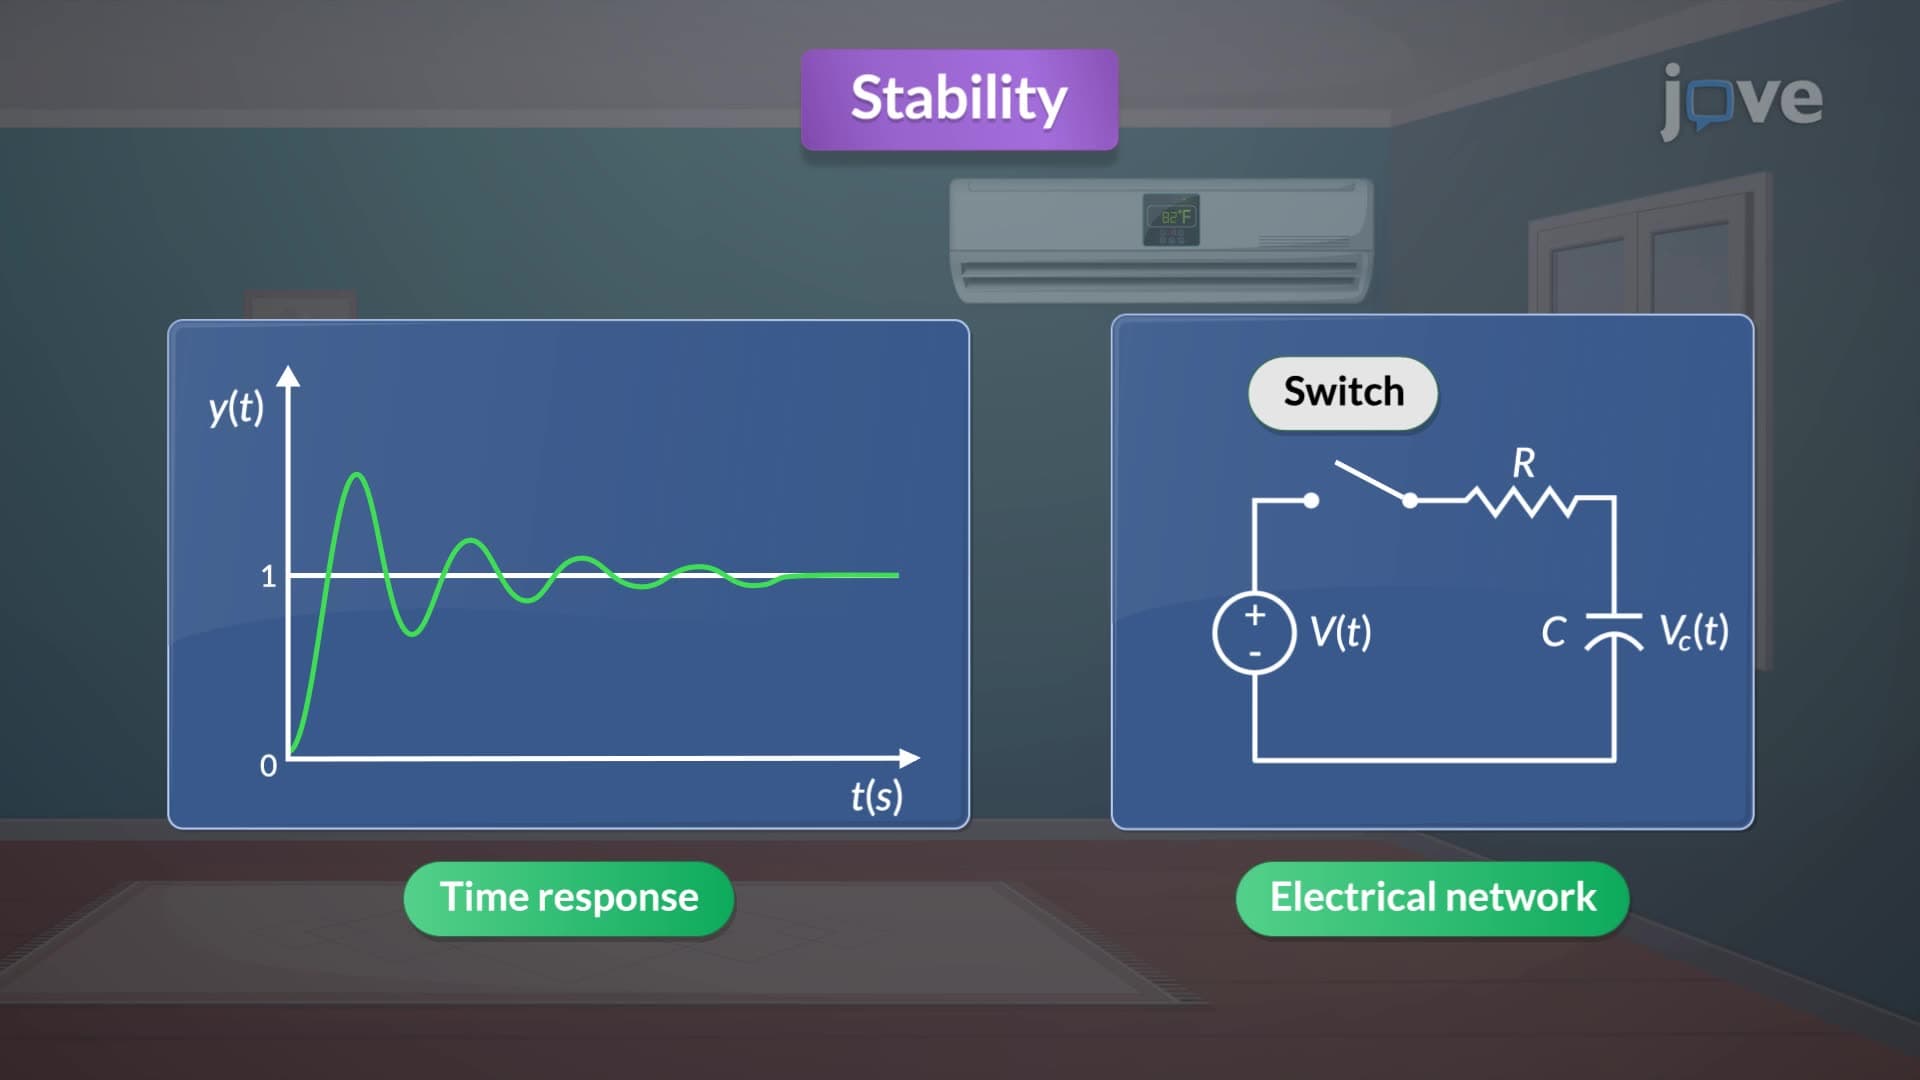
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...