Related Experiment Video
Updated: Mar 14, 2026


An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Neuro-adaptive backstepping control of SISO non-affine systems with unknown gain sign
Zahra Ramezani1, Mohammad Mehdi Arefi2, Hassan Zargarzadeh3
1Electrical Engineering Department, Iran University of Science and Technology, Tehran 16846-13114, Iran.

Abstract:
This paper presents two neuro-adaptive controllers for a class of uncertain single-input, single-output (SISO) nonlinear non-affine systems with unknown gain sign. The first approach is state feedback controller, so that a neuro-adaptive state-feedback controller is constructed based on the backstepping technique. The second approach is an observer-based controller and K-filters are designed to estimate the system states. The proposed method relaxes a priori knowledge of control gain sign and therefore by utilizing the Nussbaum-type functions this problem is addressed. In these methods, neural networks are employed to approximate the unknown nonlinear functions. The proposed adaptive control schemes guarantee that all the closed-loop signals are semi-globally uniformly ultimately bounded (SGUUB). Finally, the theoretical results are numerically verified through simulation examples. Simulation results show the effectiveness of the proposed methods.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:24
PI Controller: Design
 01:19
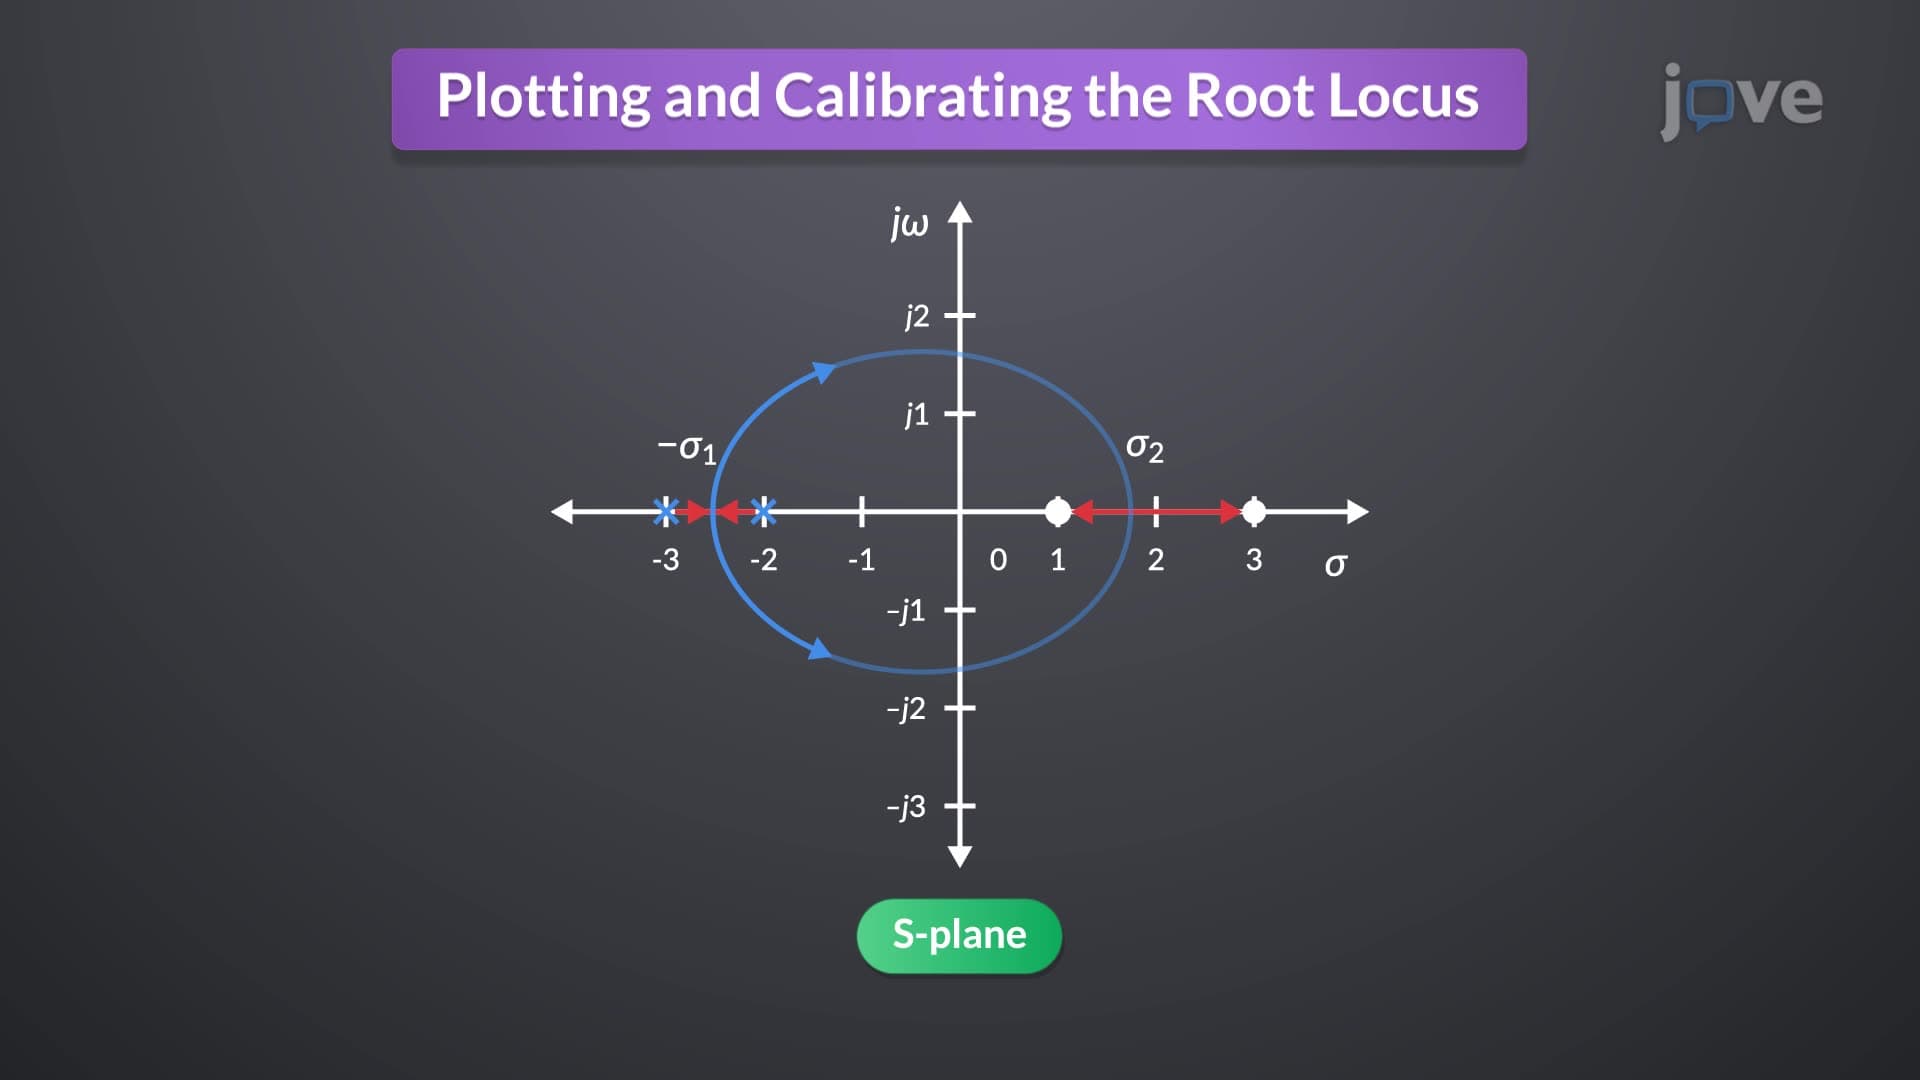
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...