Related Experiment Video
Updated: Mar 9, 2026

Home-Based Monitor for Gait and Activity Analysis
Published on: August 8, 2019
Ambulatory Assessment of Instantaneous Velocity during Walking Using Inertial Sensor Measurements
Angelo Maria Sabatini1, Andrea Mannini2
1The BioRobotics Institute, Scuola Superiore Sant'Anna, 56127 Pisa, Italy. angelo.sabatini@santannapisa.it.

Abstract:
A novel approach for estimating the instantaneous velocity of the pelvis during walking was developed based on Inertial Measurement Units (IMUs). The instantaneous velocity was modeled by the sum of a cyclical component, decomposed in the Medio-Lateral (ML), VerTical (VT) and Antero-Posterior (AP) directions, and the Average Progression Velocity (APV) over each gait cycle. The proposed method required the availability of two IMUs, attached to the pelvis and one shank. Gait cycles were identified from the shank angular velocity; for each cycle, the Fourier series coefficients of the pelvis and shank acceleration signals were computed. The cyclical component was estimated by Fourier-based time-integration of the pelvis acceleration. A Bayesian Linear Regression (BLR) with Automatic Relevance Determination (ARD) predicted the APV from the stride time, the stance duration, and the Fourier series coefficients of the shank acceleration. Healthy subjects performed tasks of Treadmill Walking (TW) and Overground Walking (OW), and an optical motion capture system (OMCS) was used as reference for algorithm performance assessment. The widths of the limits of agreements (±1.96 standard deviation) were computed between the proposed method and the reference OMCS, yielding, for the cyclical component in the different directions: ML: ±0.07 m/s (±0.10 m/s); VT: ±0.03 m/s (±0.05 m/s); AP: ±0.06 m/s (±0.10 m/s), in TW (OW) conditions. The ARD-BLR achieved an APV root mean square error of 0.06 m/s (0.07 m/s) in the same conditions.
More Related Videos


Related Concept Videos
 01:10
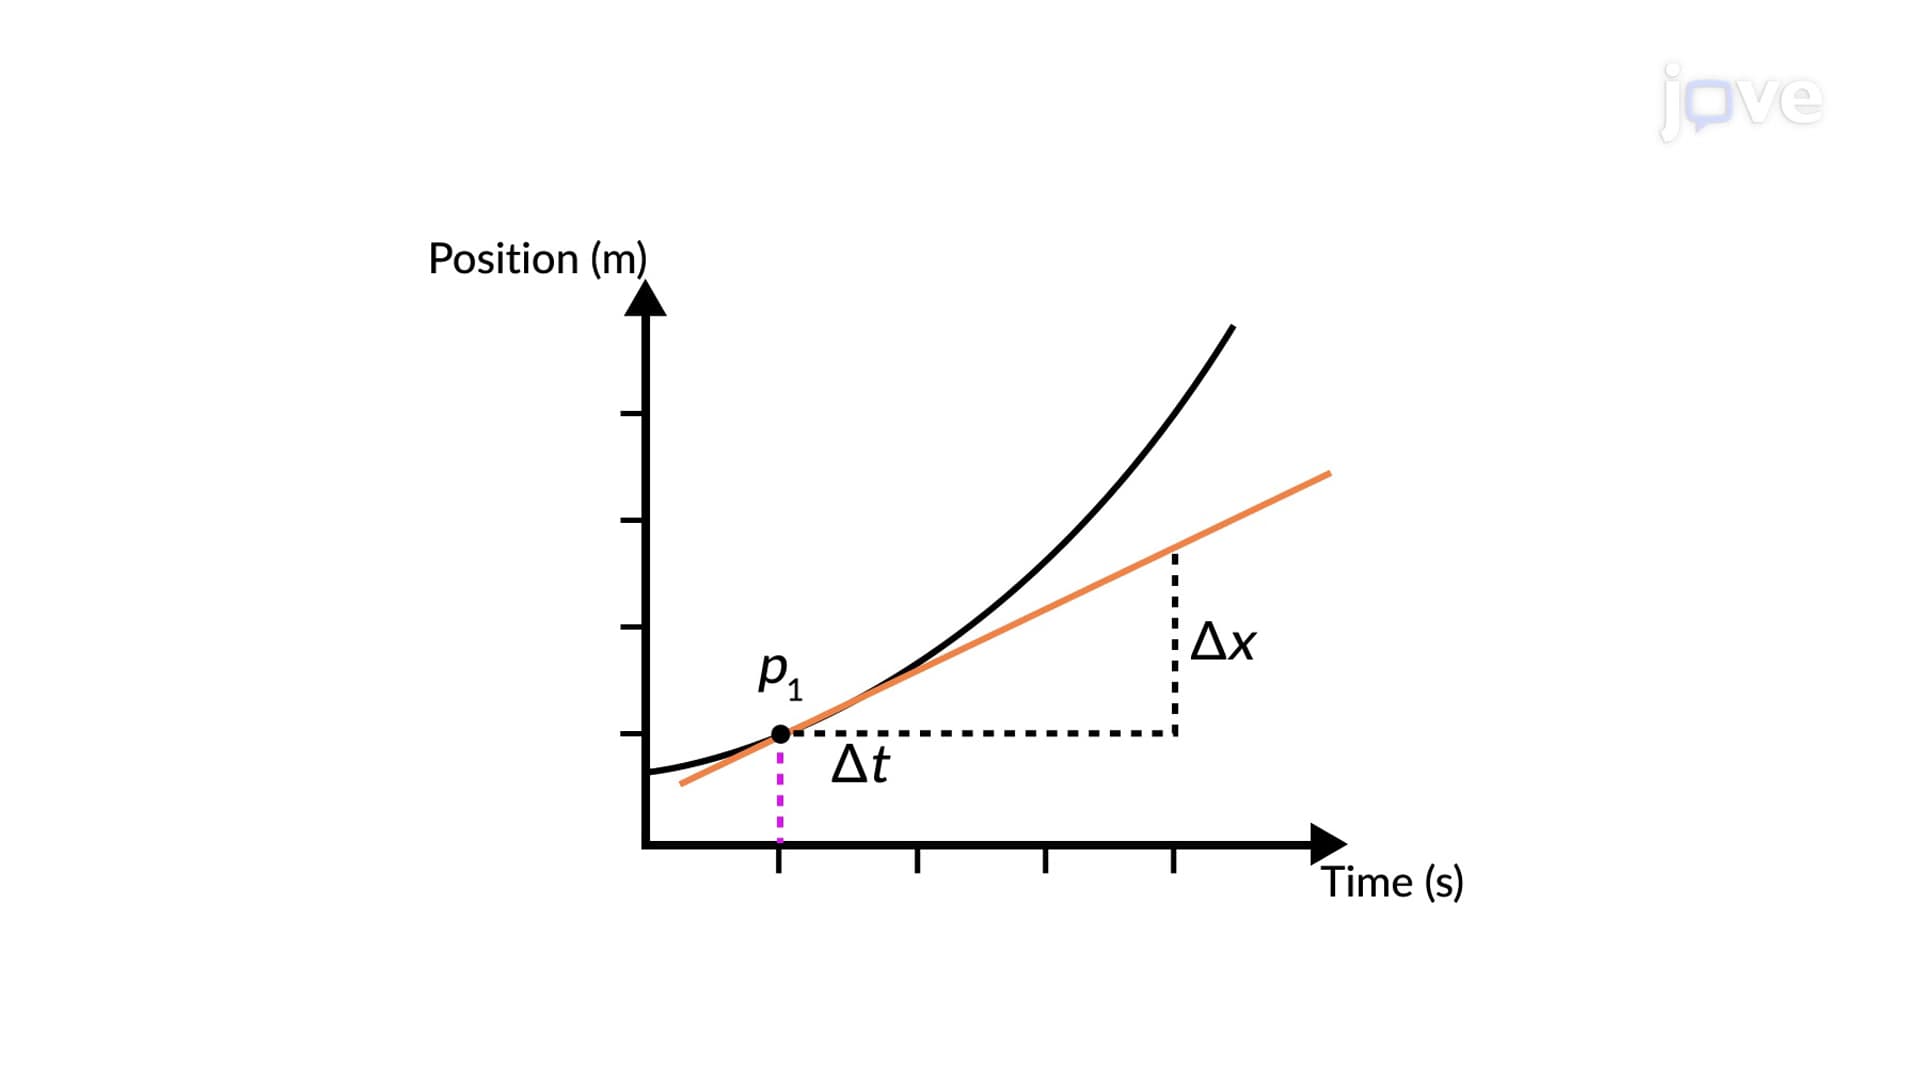
Instantaneous Velocity - II
 01:15
Instantaneous Velocity - I
 01:12
Average and Instantaneous Velocity Vectors
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
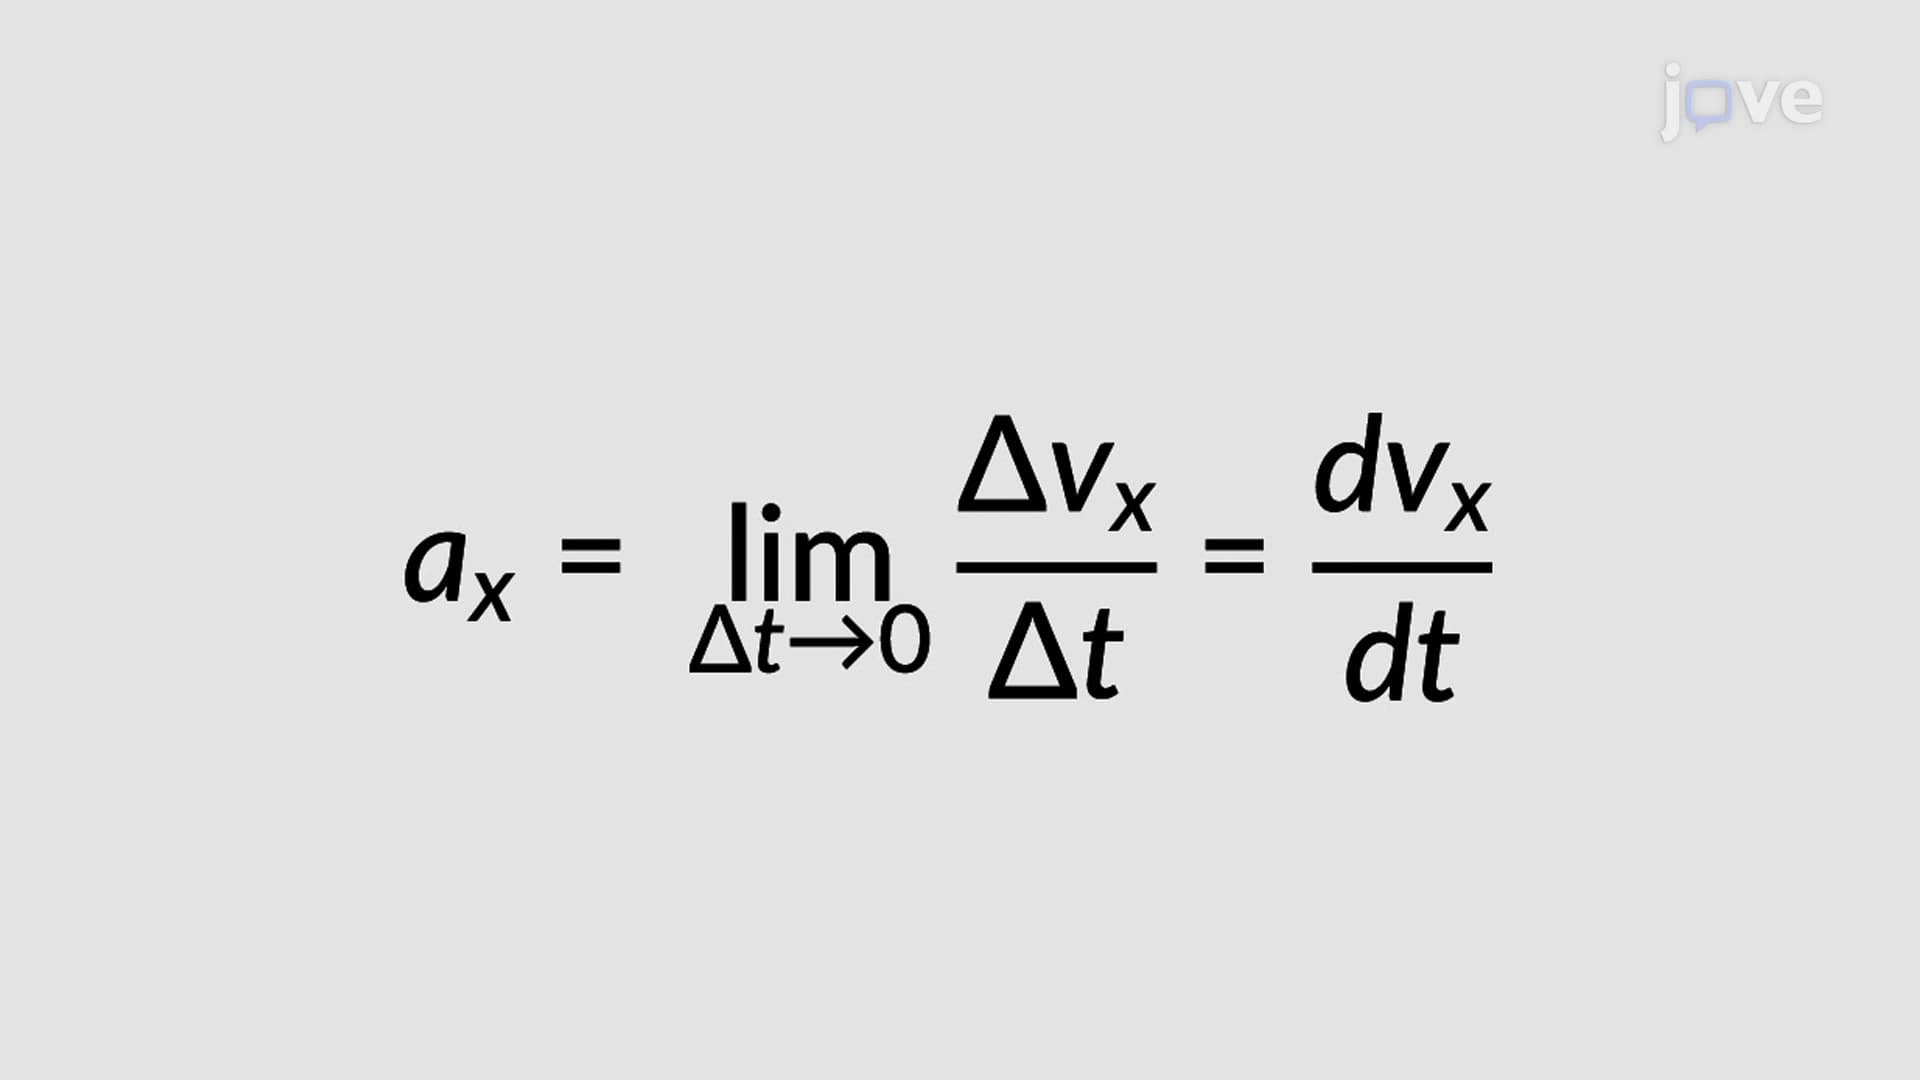 01:16
Instantaneous Acceleration
 01:10
Relative Velocity in One Dimension