Related Experiment Video
Updated: Mar 9, 2026

Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
OBSERVING LYAPUNOV EXPONENTS OF INFINITE-DIMENSIONAL DYNAMICAL SYSTEMS
William Ott1, Mauricio A Rivas2, James West3
1Department of Mathematics, University of Houston, URL : http://www.math.uh.edu/~ott/.

Abstract:
Can Lyapunov exponents of infinite-dimensional dynamical systems be observed by projecting the dynamics into ℝ using a 'typical' nonlinear projection map? We answer this question affirmatively by developing embedding theorems for compact invariant sets associated with C1 maps on Hilbert spaces. Examples of such discrete-time dynamical systems include time-T maps and Poincaré return maps generated by the solution semigroups of evolution partial differential equations. We make every effort to place hypotheses on the projected dynamics rather than on the underlying infinite-dimensional dynamical system. In so doing, we adopt an empirical approach and formulate checkable conditions under which a Lyapunov exponent computed from experimental data will be a Lyapunov exponent of the infinite-dimensional dynamical system under study (provided the nonlinear projection map producing the data is typical in the sense of prevalence).
More Related Videos
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:23
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:19
Limits with Oscillating Discontinuities
 01:22
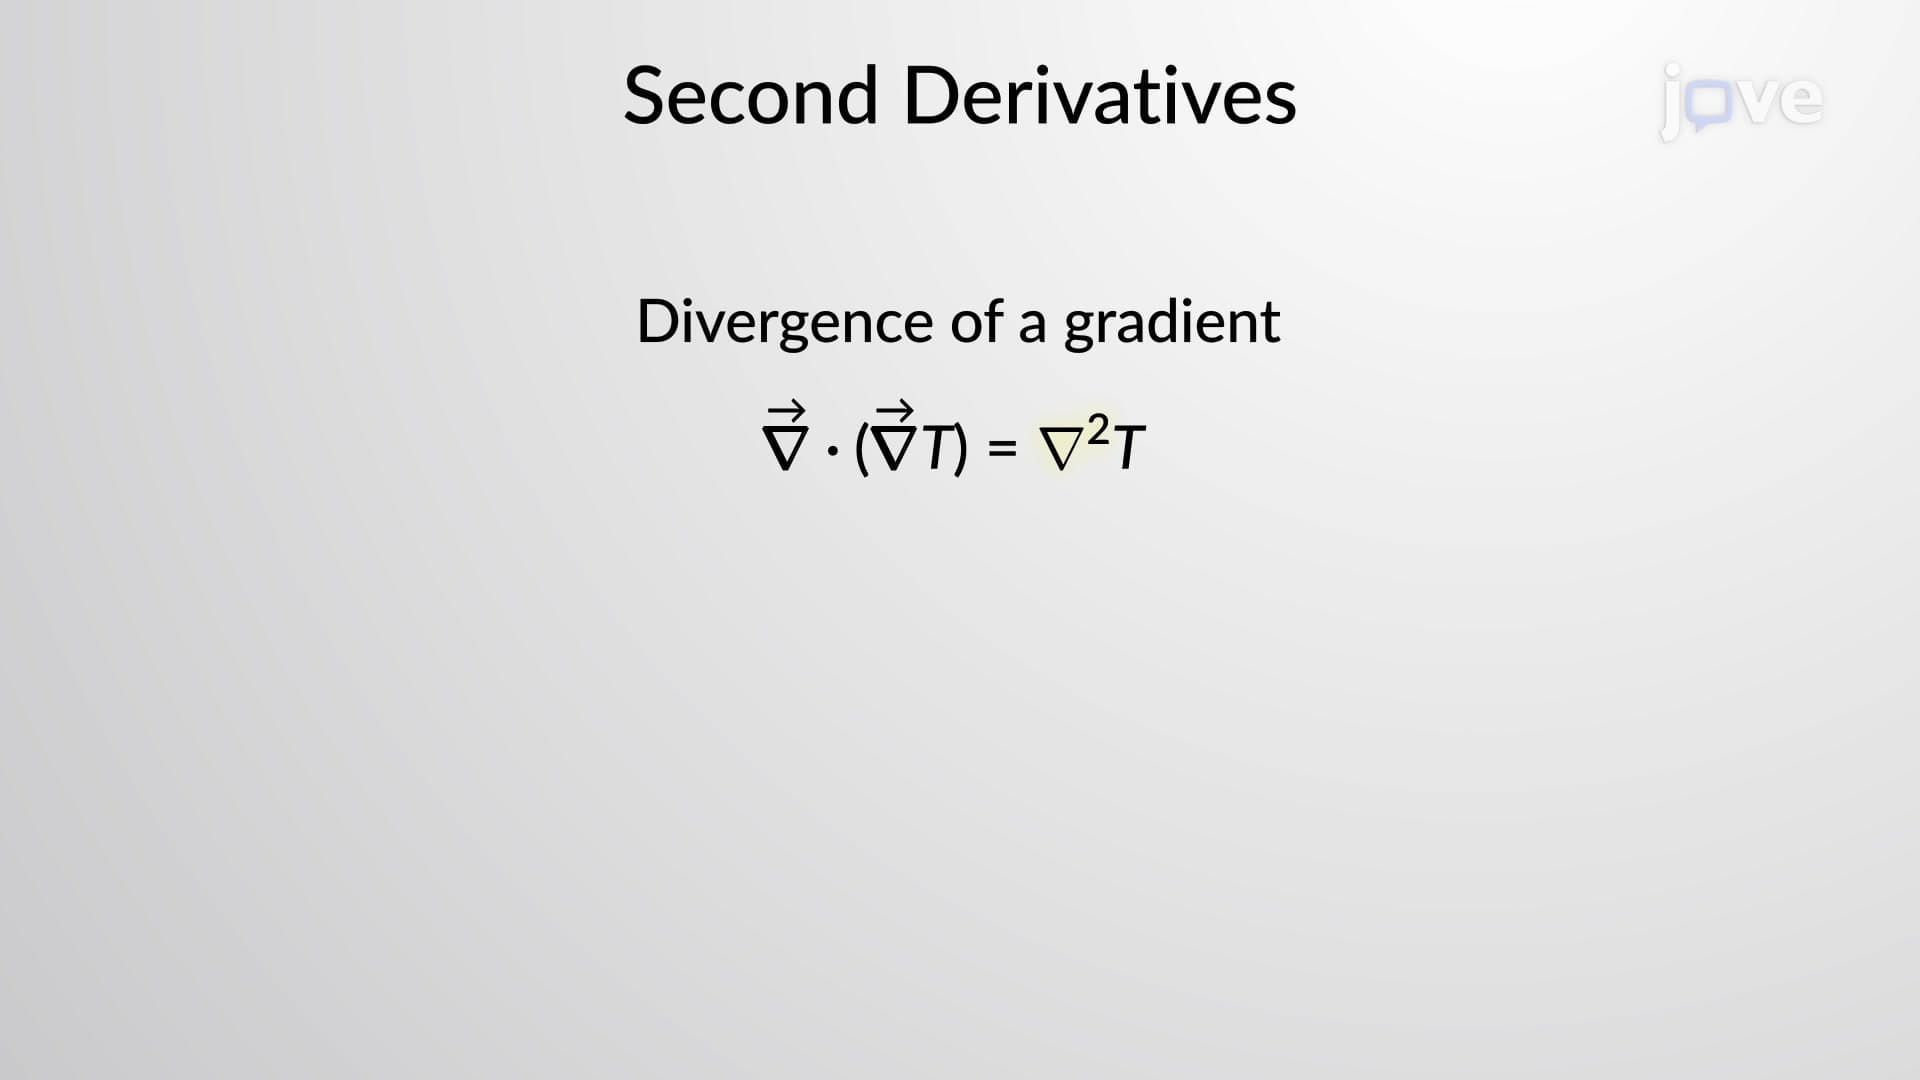
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...
 01:19
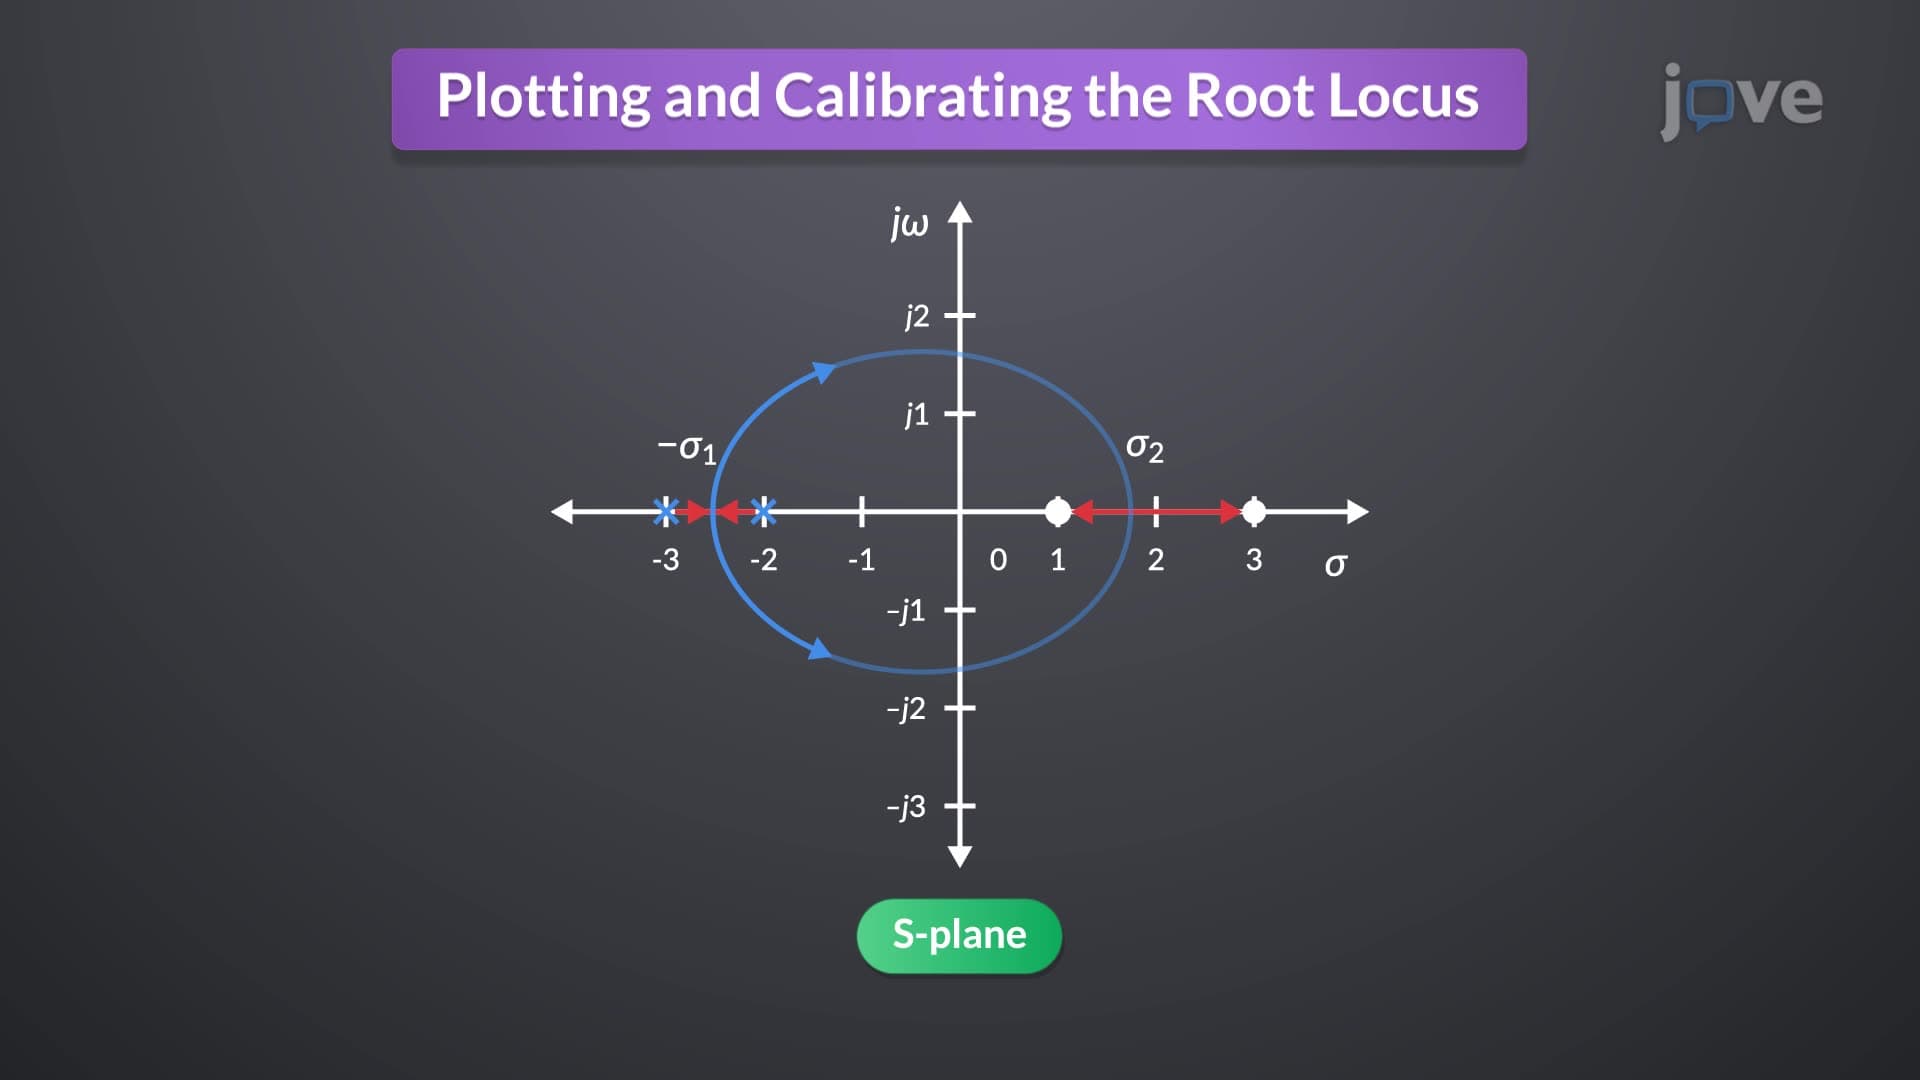
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...