Neural Approximation-Based Adaptive Control for a Class of Nonlinear Nonstrict Feedback Discrete-Time Systems


Abstract:
In this paper, an adaptive control approach-based neural approximation is developed for a class of uncertain nonlinear discrete-time (DT) systems. The main characteristic of the considered systems is that they can be viewed as a class of multi-input multioutput systems in the nonstrict feedback structure. The similar control problem of this class of systems has been addressed in the past, but it focused on the continuous-time systems. Due to the complicacies of the system structure, it will become more difficult for the controller design and the stability analysis. To stabilize this class of systems, a new recursive procedure is developed, and the effect caused by the noncausal problem in the nonstrict feedback DT structure can be solved using a semirecurrent neural approximation. Based on the Lyapunov difference approach, it is proved that all the signals of the closed-loop system are semiglobal, ultimately uniformly bounded, and a good tracking performance can be guaranteed. The feasibility of the proposed controllers can be validated by setting a simulation example.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Linear Approximation in Frequency Domain
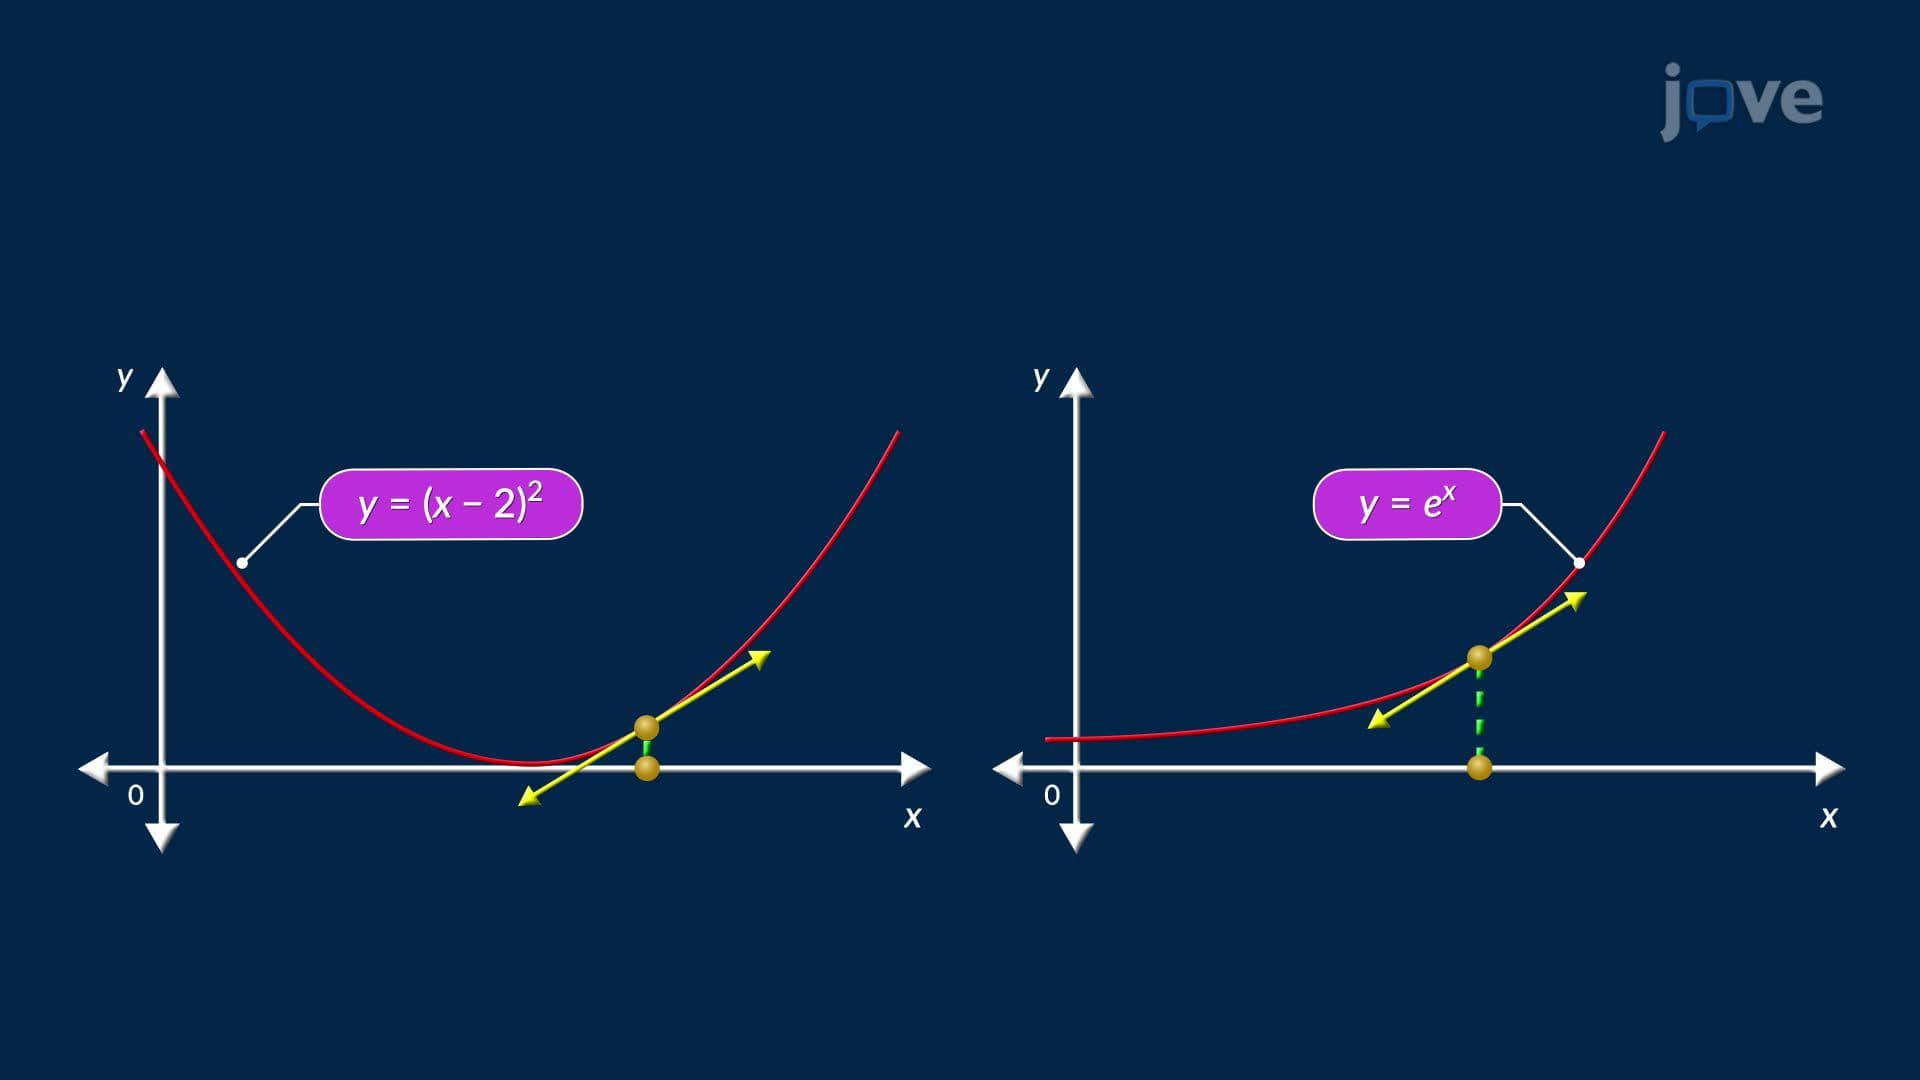
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Linearization and Approximation
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...