Related Experiment Video
Updated: Mar 8, 2026
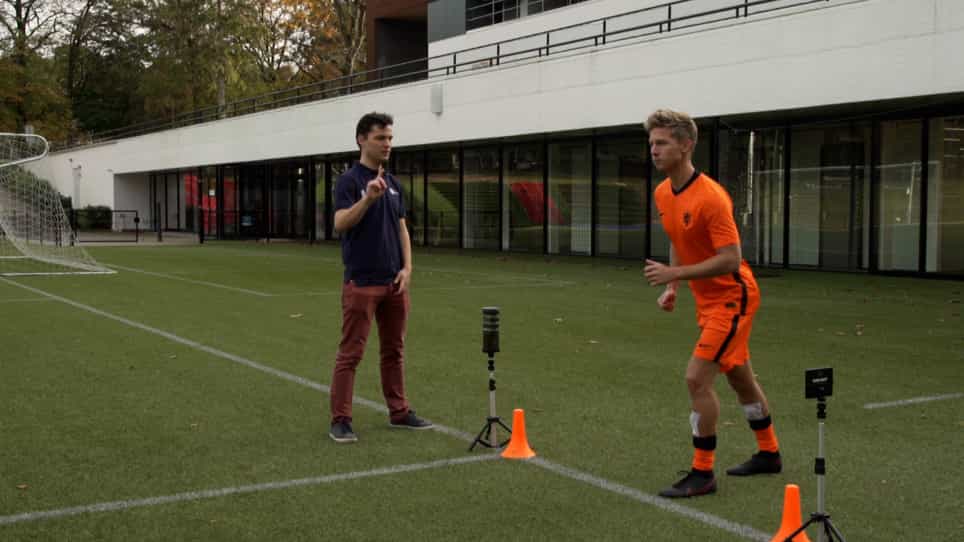
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Joint Inertial Sensor Orientation Drift Reduction for Highly Dynamic Movements

Abstract:
Inertial sensor drift is usually corrected on a single-sensor unit level. When multiple sensor units are used, mutual information from different units can be exploited for drift correction. This study introduces a method for a drift-reduced estimation of three dimensional (3-D) segment orientations and joint angles for motion capture of highly dynamic movements as present in many sports. 3-D acceleration measured on two adjacent segments is mapped to the connecting joint. Drift is estimated and reduced based on the mapped accelerations' vector orientation differences in the global frame. Algorithm validity is assessed on the example of alpine ski racing. Shank, thigh, and trunk inclination as well as knee and hip flexion were compared to a multicamera-based reference system. For specific leg angles and trunk segment inclination mean accuracy and precision were below 3.9° and 6.0°, respectively. The errors were similar to errors reported in other studies for lower dynamic movements. Drift increased axis misalignment and mainly affected joint and segment angles of highly flexed joints such as the knee or hip during a ski turn.
More Related Videos
Related Concept Videos
 01:24
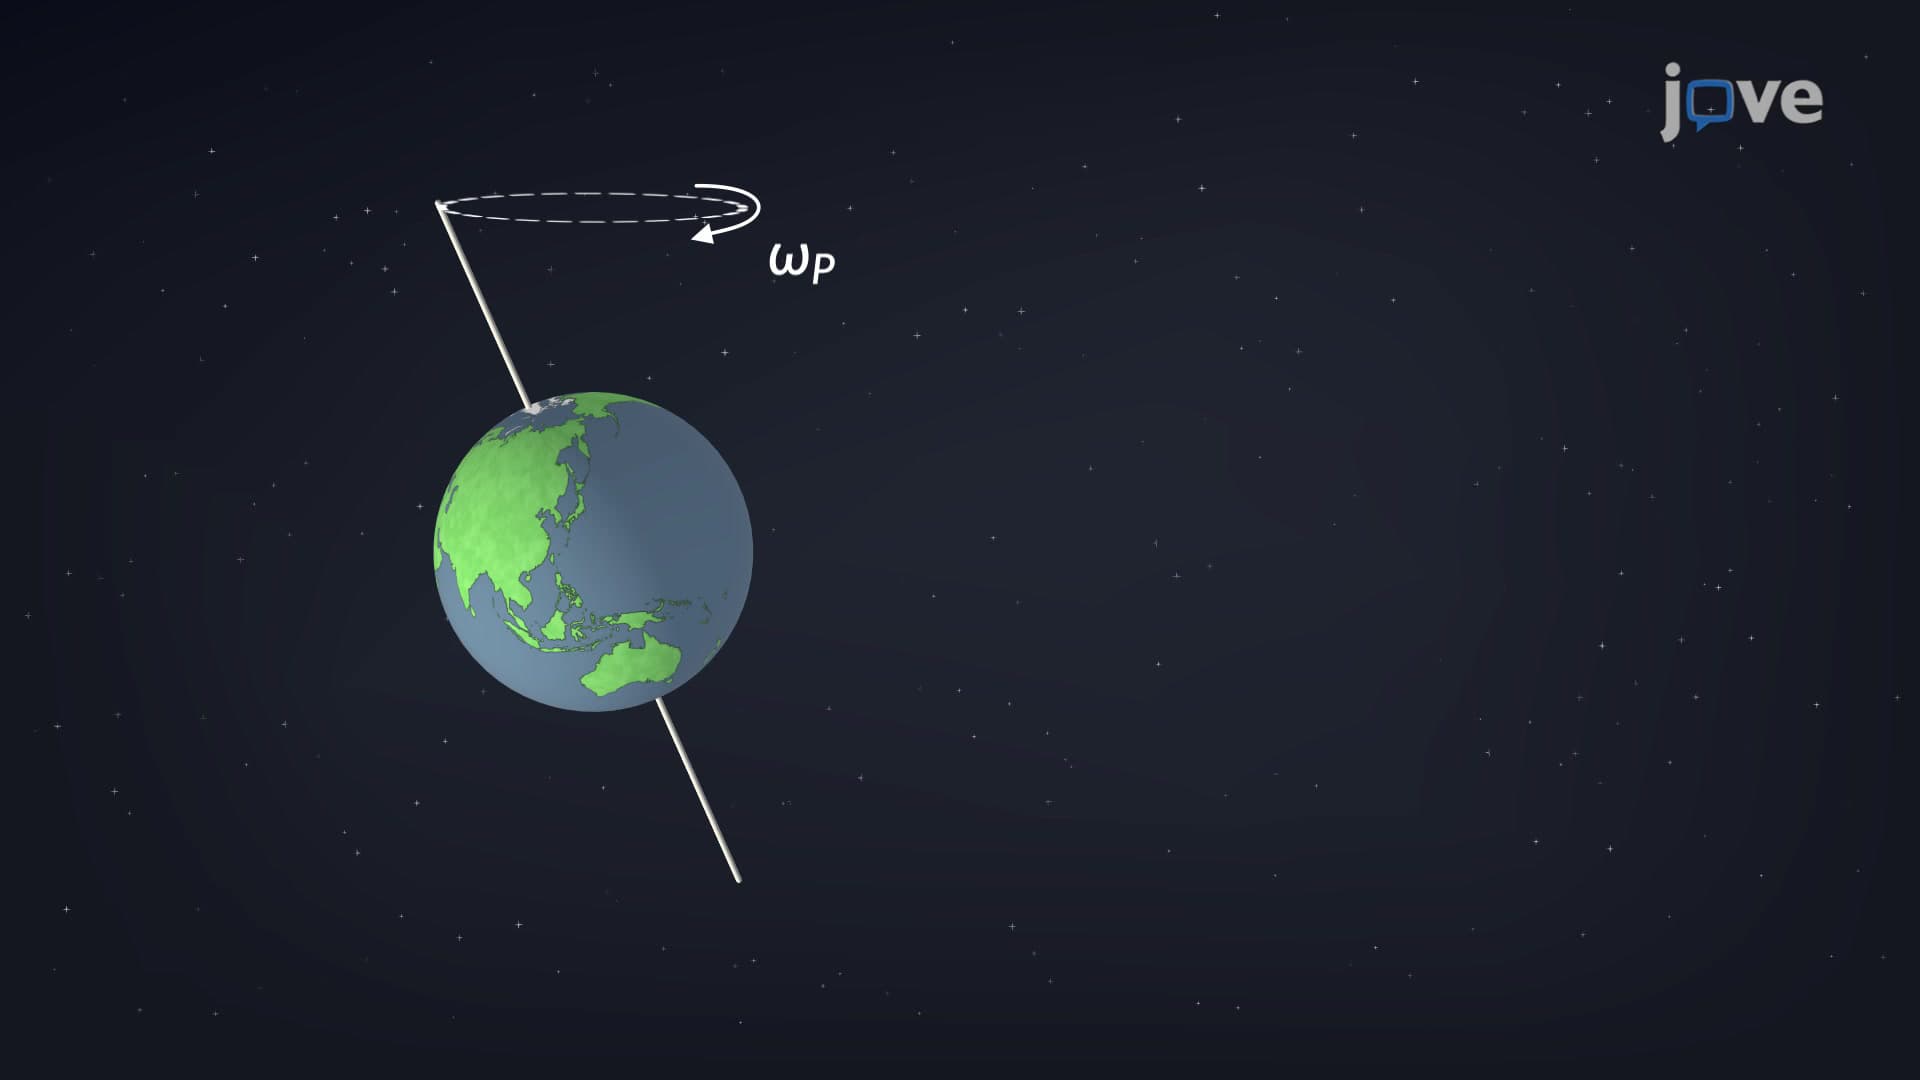
Gyroscope: Precession
 01:03
Inertial Frames of Reference
 01:02
Gyroscope
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...