Related Experiment Video
Updated: Mar 8, 2026
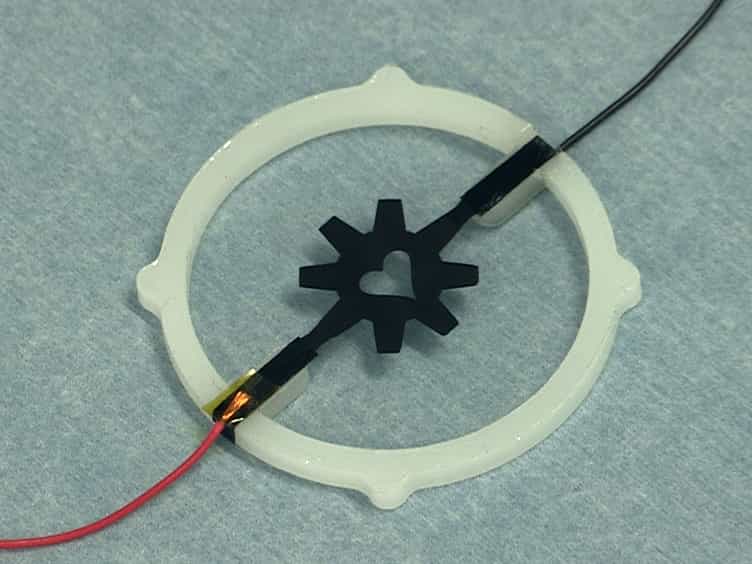
Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Bio-inspired annelid robot: a dielectric elastomer actuated soft robot
Liang Xu1, Han-Qing Chen, Jiang Zou
1State Key Laboratory of Mechanical System and Vibration, School of Mechanical Engineering, Shanghai Jiao Tong University, Shanghai 200240, People's Republic of China. University of Michigan-Shanghai Jiao Tong University Joint Institute, Shanghai Jiao Tong University, Shanghai 200240, People's Republic of China. These authors contributed equally to this work.

Abstract:
Biologically inspired robots with inherent softness and body compliance increasingly attract attention in the field of robotics. Aimed at solving existing problems with soft robots, regarding actuation technology and biological principles, this paper presents a soft bio-inspired annelid robot driven by dielectric elastomer actuators (DEAs) that can advance on flat rigid surfaces. The DEA, a kind of soft functional actuator, is designed and fabricated to mimic the axial elongation and differential friction of a single annelid body segment. Several (at least three) DEAs are connected together into a movable multi-segment robot. Bristles are attached at the bottom of some DEAs to achieve differential friction for imitating the setae of annelids. The annelid robot is controlled by periodic square waves, propagating from the posterior to the anterior, which imitate the peristaltic waves of annelids. Controlled by these waves, each DEA, one-by-one from tail to head, anchors to the ground by circumferential distention and pushes the front DEAs forward by axial elongation, enabling the robot to advance. Preliminary tests demonstrate that a 3-segment robot can reach an average speed of 5.3 mm s-1 (1.871 body lengths min-1) on flat rigid surfaces and can functionally mimic the locomotion of annelids. Compared to the existing robots that imitate terrestrial annelids our annelid robot shows advantages in terms of speed and bionics.