Generalized characteristic ratios assignment for commensurate fractional order systems with one zero
Related Experiment Video
Updated: Mar 3, 2026
Generation and Coherent Control of Pulsed Quantum Frequency Combs
Published on: June 8, 2018
1Department of Electrical Engineering, Khomeinishahr Branch, Islamic Azad University, Isfahan, Iran.

Abstract:
In this paper, a new method for determination of the desired characteristic equation and zero location of commensurate fractional order systems is presented. The concept of the characteristic ratio is extended for zero-including commensurate fractional order systems. The generalized version of characteristic ratios is defined such that the time-scaling property of characteristic ratios is also preserved. The monotonicity of the magnitude frequency response is employed to assign the generalized characteristic ratios for commensurate fractional order transfer functions with one zero. A simple pattern for characteristic ratios is proposed to reach a non-overshooting step response. Then, the proposed pattern is revisited to reach a low overshoot (say for example 2%) step response. Finally, zero-including controllers such as fractional order PI or lag (lead) controllers are designed using generalized characteristic ratios assignment method. Numerical simulations are provided to show the efficiency of the so designed controllers.
Related Concept Videos
 01:21
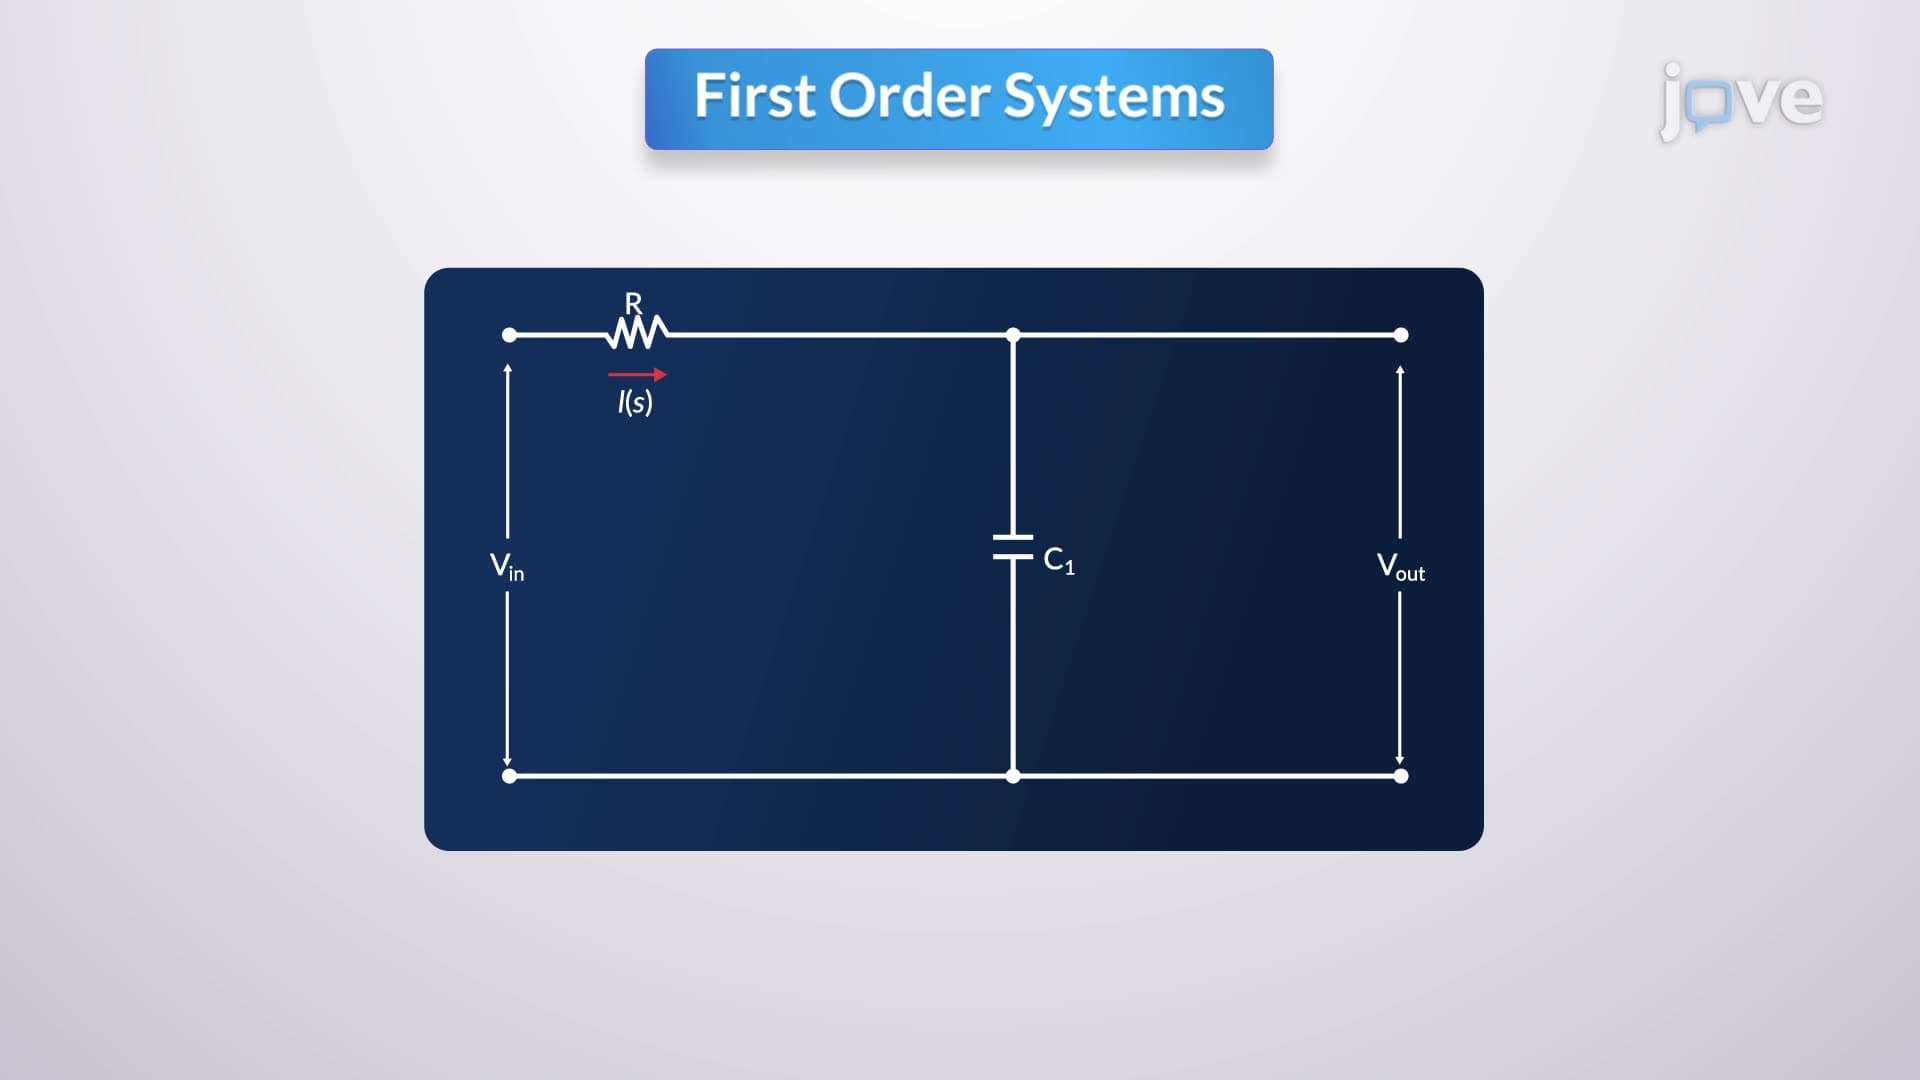
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:19
Routh-Hurwitz Criterion II
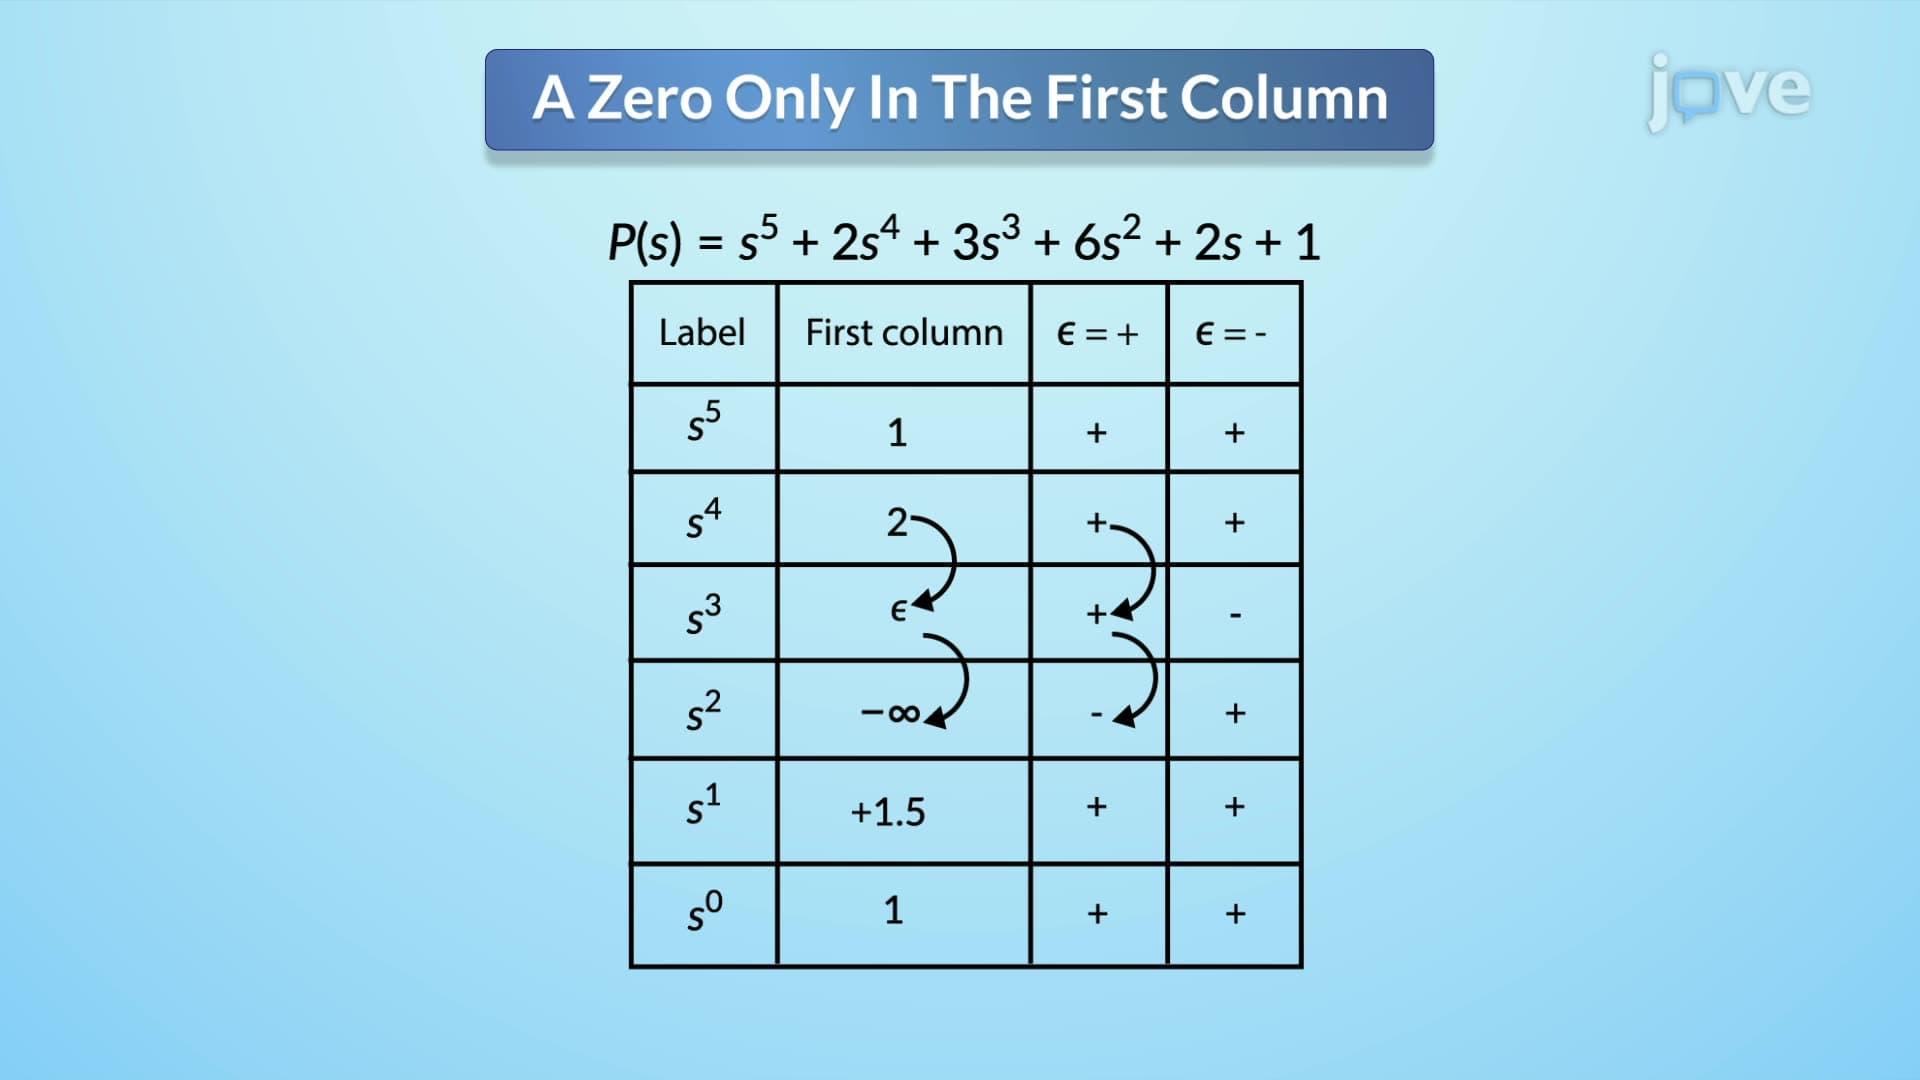
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:28
Partial Fractions
 01:24
Difference Equation Solution using z-Transform
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
 01:23
Transfer Function to State Space
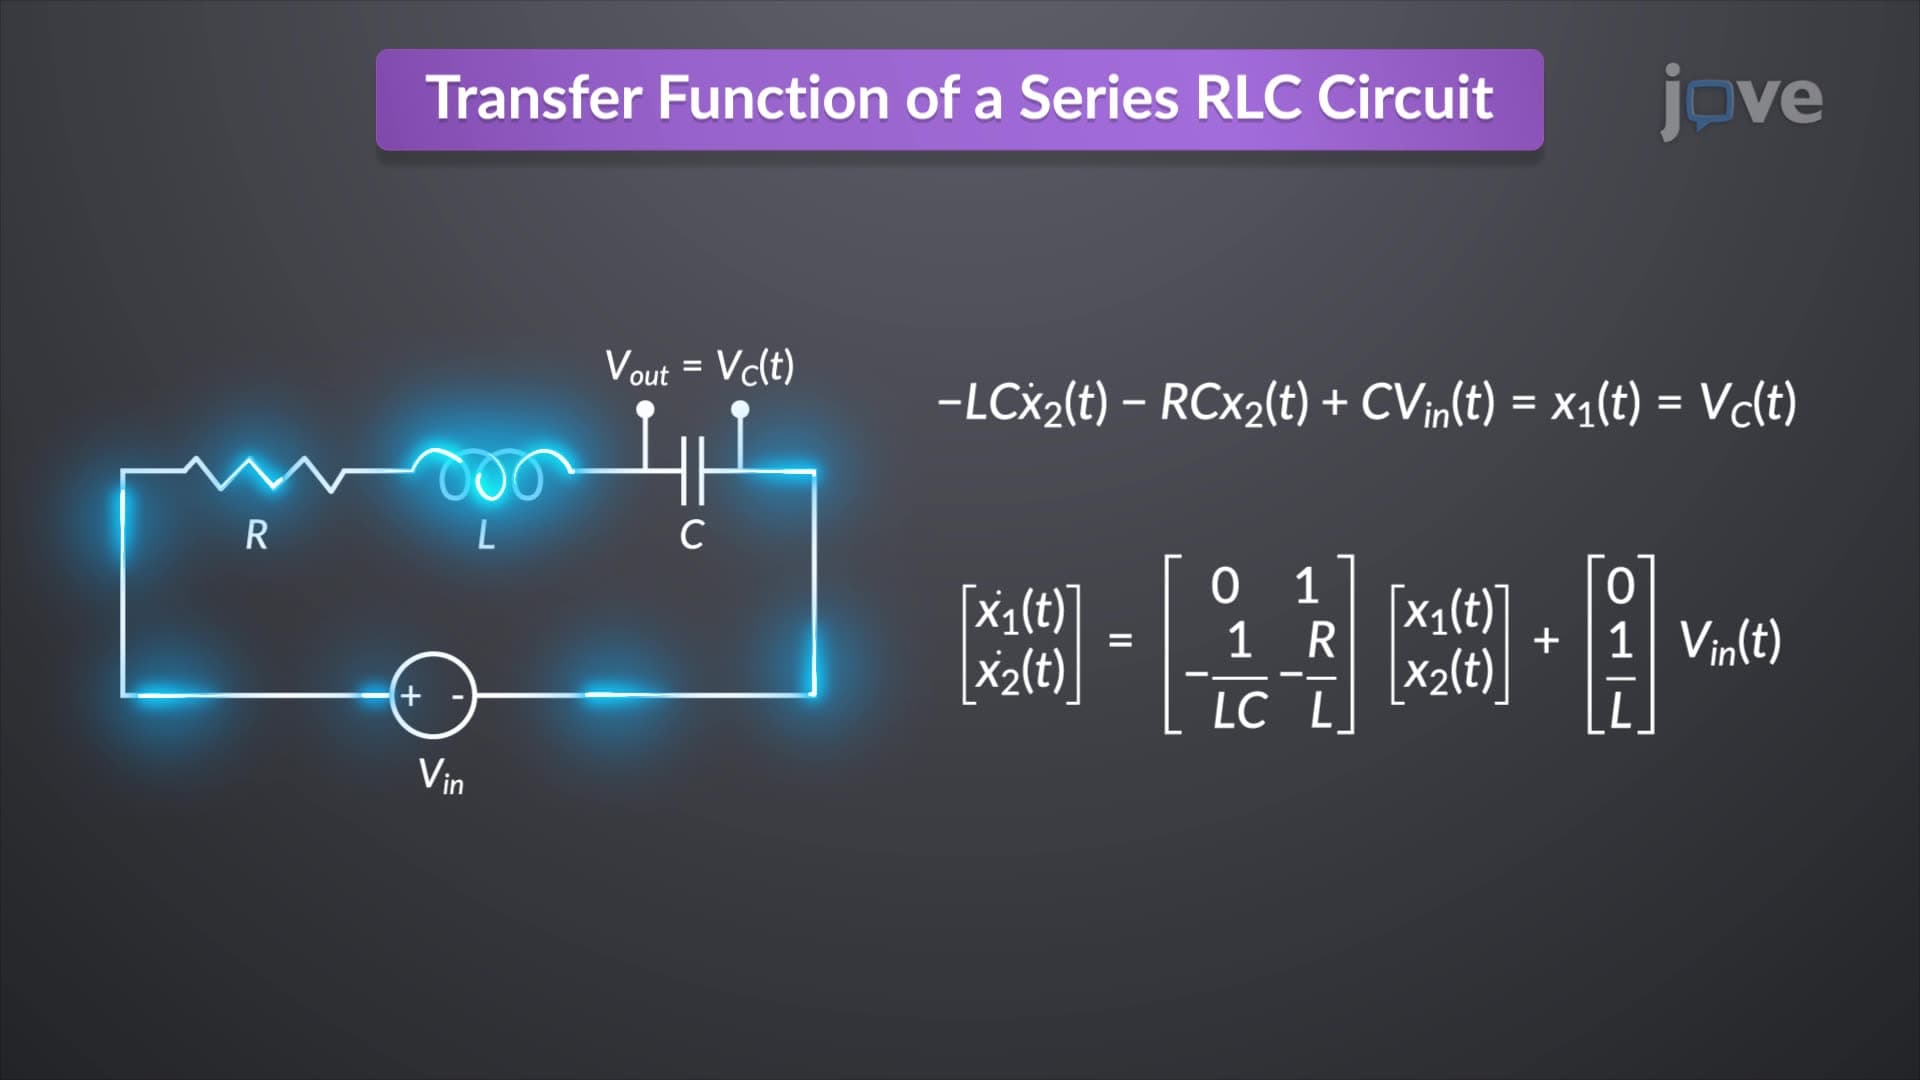
In an RLC...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....