Related Experiment Video
Updated: Mar 2, 2026


Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Modeling and control of operator functional state in a unified framework of fuzzy inference petri nets
Jian-Hua Zhang1, Jia-Jun Xia1, Jonathan M Garibaldi2
1School of Information Science and Engineering, East China University of Science and Technology, Shanghai 200237, PR China.

Background And Objective:
In human-machine (HM) hybrid control systems, human operator and machine cooperate to achieve the control objectives. To enhance the overall HM system performance, the discrete manual control task-load by the operator must be dynamically allocated in accordance with continuous-time fluctuation of psychophysiological functional status of the operator, so-called operator functional state (OFS). The behavior of the HM system is hybrid in nature due to the co-existence of discrete task-load (control) variable and continuous operator performance (system output) variable.
Methods:
Petri net is an effective tool for modeling discrete event systems, but for hybrid system involving discrete dynamics, generally Petri net model has to be extended. Instead of using different tools to represent continuous and discrete components of a hybrid system, this paper proposed a method of fuzzy inference Petri nets (FIPN) to represent the HM hybrid system comprising a Mamdani-type fuzzy model of OFS and a logical switching controller in a unified framework, in which the task-load level is dynamically reallocated between the operator and machine based on the model-predicted OFS. Furthermore, this paper used a multi-model approach to predict the operator performance based on three electroencephalographic (EEG) input variables (features) via the Wang-Mendel (WM) fuzzy modeling method. The membership function parameters of fuzzy OFS model for each experimental participant were optimized using artificial bee colony (ABC) evolutionary algorithm. Three performance indices, RMSE, MRE, and EPR, were computed to evaluate the overall modeling accuracy.
Results:
Experiment data from six participants are analyzed. The results show that the proposed method (FIPN with adaptive task allocation) yields lower breakdown rate (from 14.8% to 3.27%) and higher human performance (from 90.30% to 91.99%).
Conclusion:
The simulation results of the FIPN-based adaptive HM (AHM) system on six experimental participants demonstrate that the FIPN framework provides an effective way to model and regulate/optimize the OFS in HM hybrid systems composed of continuous-time OFS model and discrete-event switching controller.
Related Concept Videos
 01:27
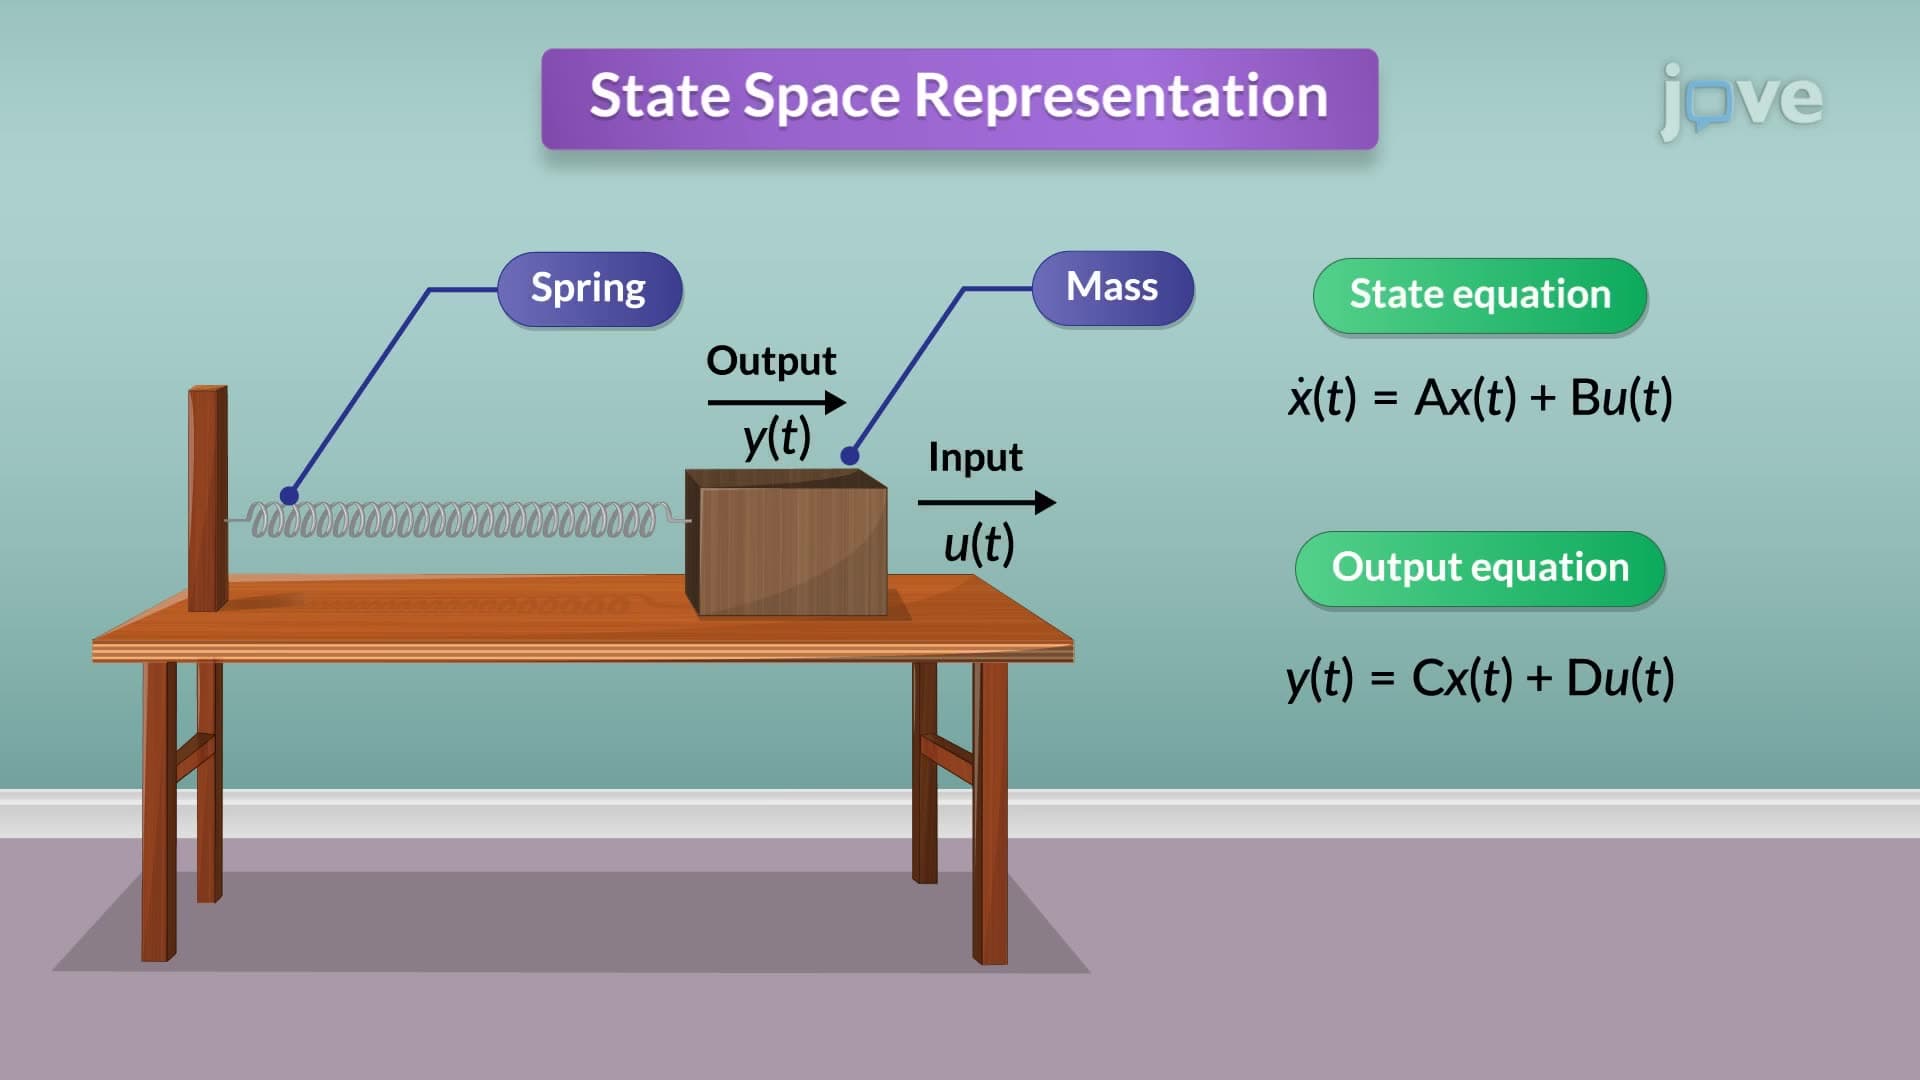
State Space Representation
Consider an RLC circuit, a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
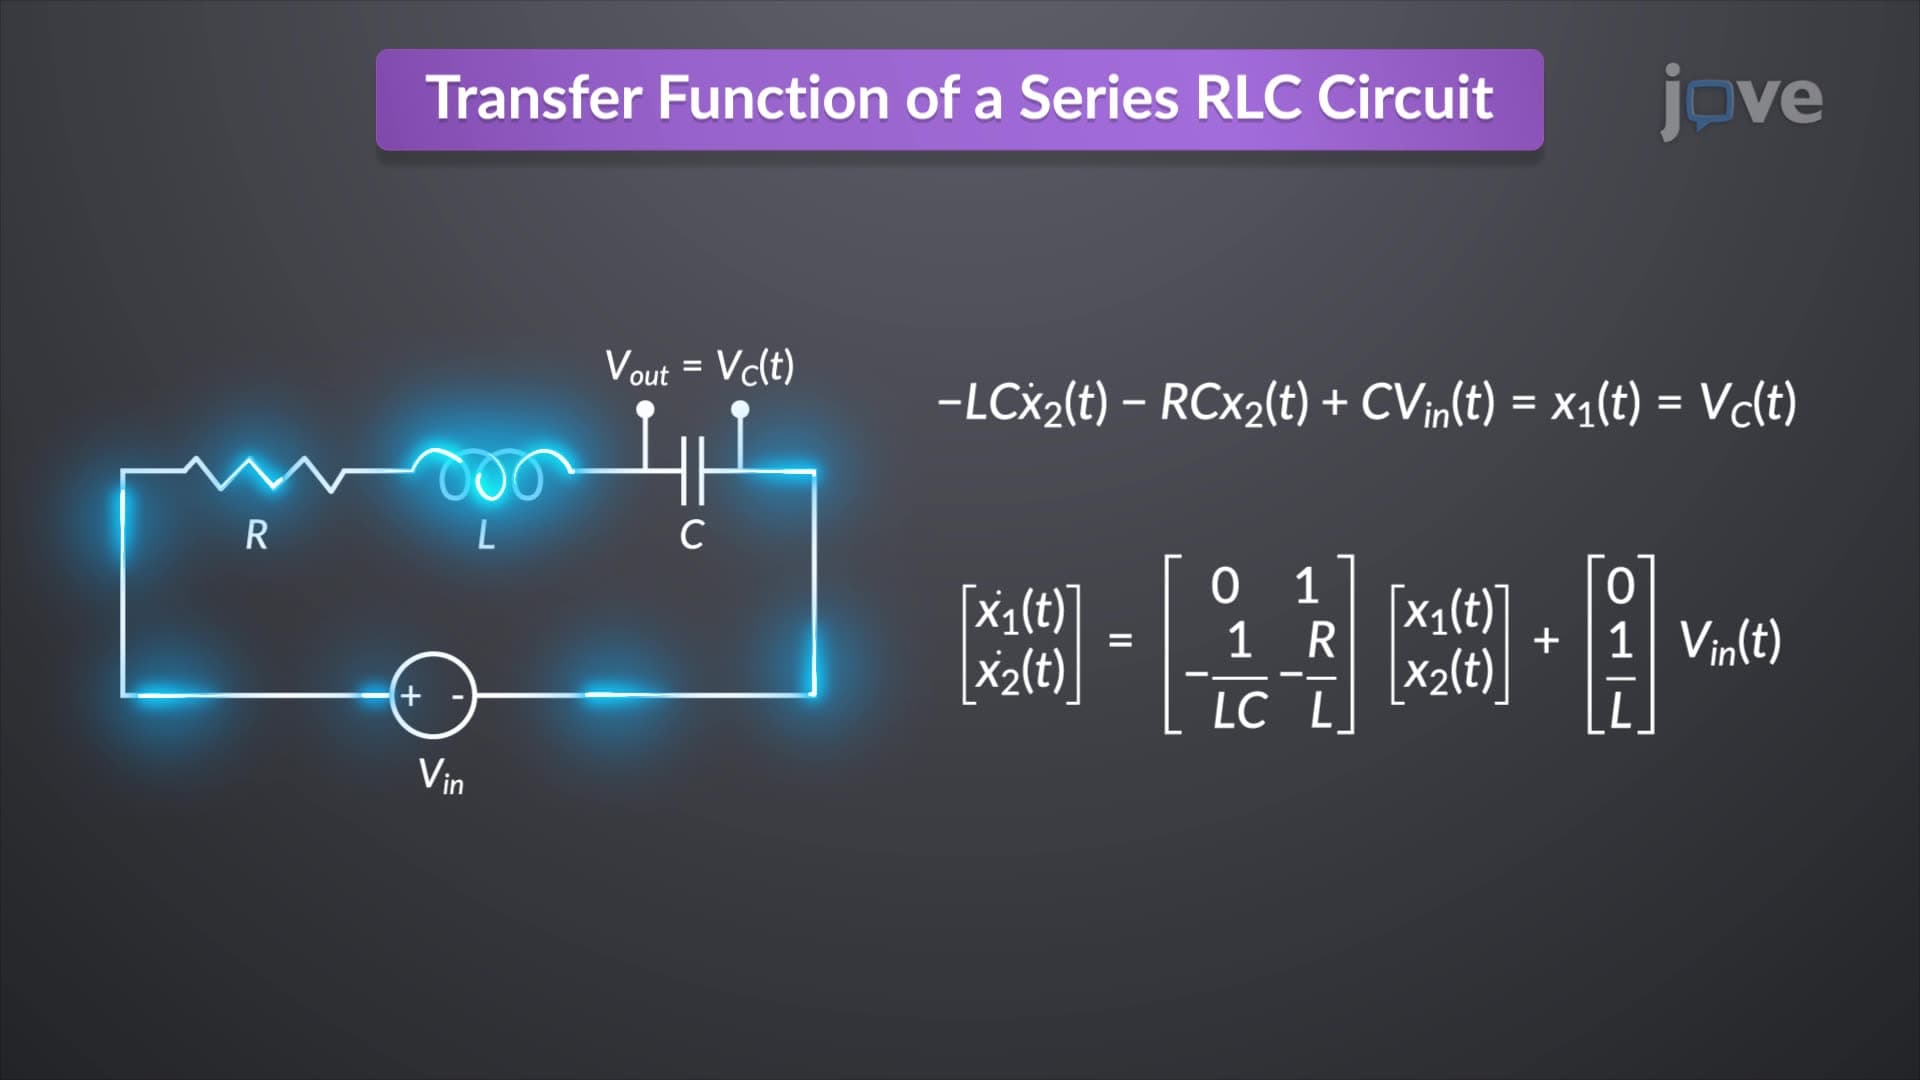
Transfer Function to State Space
In an RLC...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...