A novel body frame based approach to aerospacecraft attitude tracking
Related Experiment Video
Updated: Feb 28, 2026
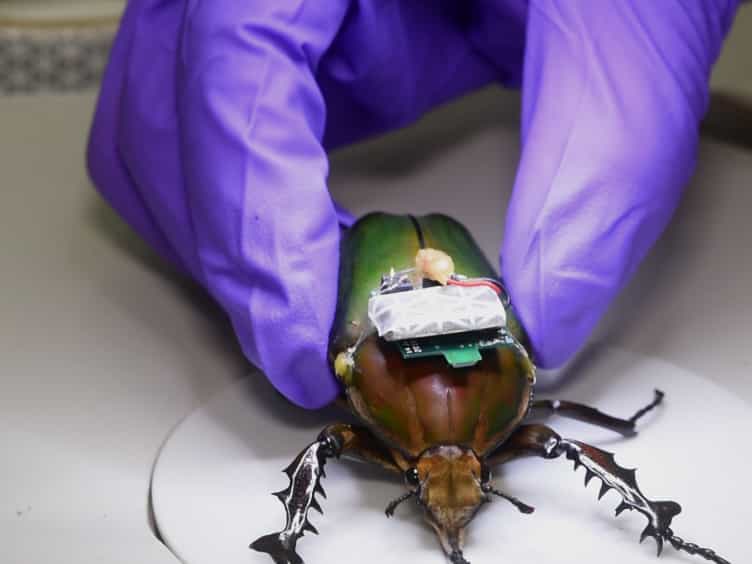
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Carlos Ma1, Michael Z Q Chen1, James Lam1
1Department of Mechanical Engineering, The University of Hong Kong, Pokfulam Road, Hong Kong.

Abstract:
In the common practice of designing an attitude tracker for an aerospacecraft, one transforms the Newton-Euler rotation equations to obtain the dynamic equations of some chosen inertial frame based attitude metrics, such as Euler angles and unit quaternions. A Lyapunov approach is then used to design a controller which ensures asymptotic convergence of the attitude to the desired orientation. Although this design methodology is pretty standard, it usually involves singularity-prone coordinate transformations which complicates the analysis process and controller design. A new, singularity free error feedback method is proposed in the paper to provide simple and intuitive stability analysis and controller synthesis. This new body frame based method utilizes the concept of Euleraxis and angles to generate the smallest error angles from a body frame perspective, without coordinate transformations. Global tracking convergence is illustrated with the use of a feedback linearizing PD tracker, a sliding mode controller, and a model reference adaptive controller. Experimental results are also obtained on a quadrotor platform with unknown system parameters and disturbances, using a boundary layer approximated sliding mode controller, a PIDD controller, and a unit sliding mode controller. Significant tracking quality is attained.

Related Concept Videos
 01:03
Inertial Frames of Reference
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:27
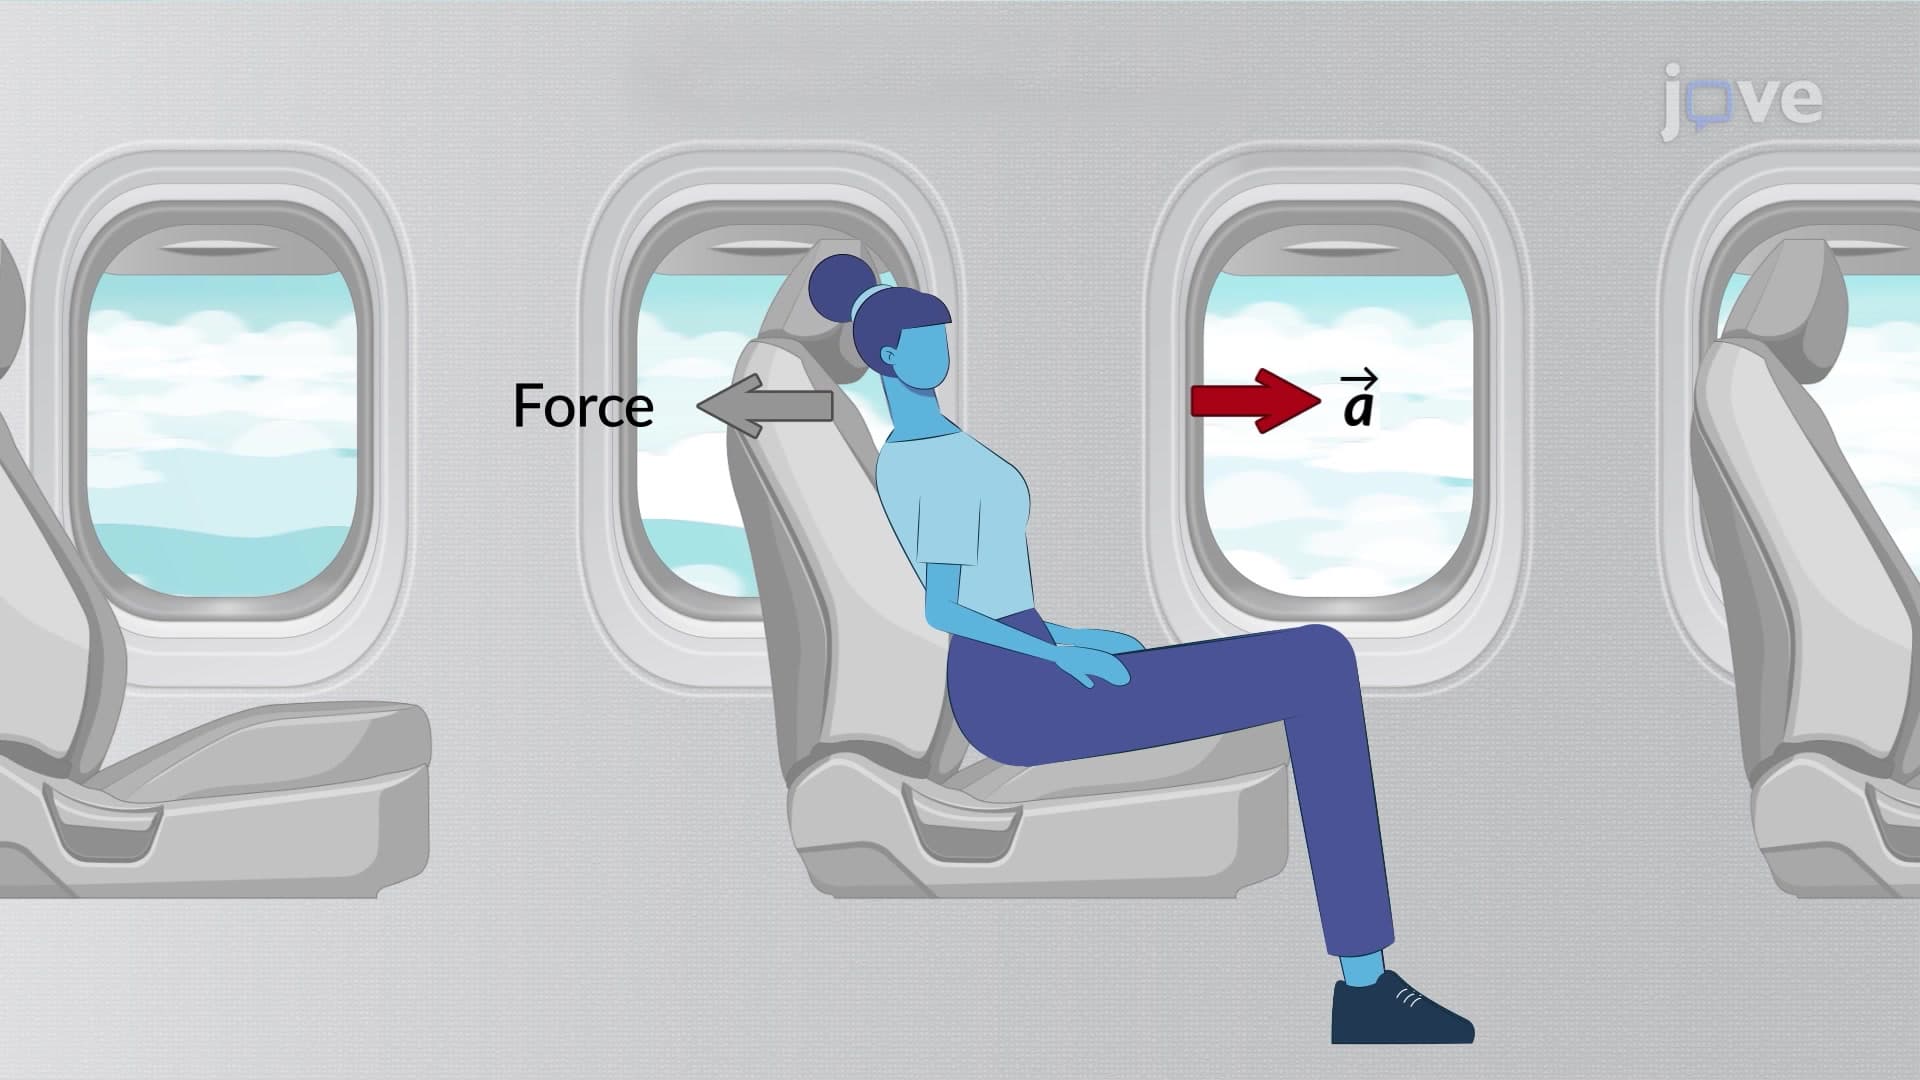
Non-inertial Frames of Reference
 01:09
Angular Momentum and Principle Axes of Inertia
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...