Related Experiment Video
Updated: Feb 28, 2026
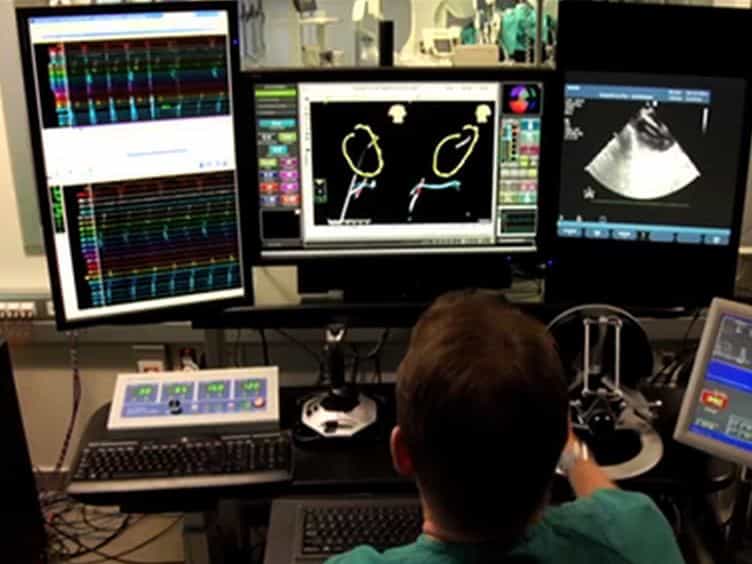

Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
CathROB: A Highly Compact and Versatile Remote Catheter Navigation System
Laura Cercenelli1, Barbara Bortolani1, Emanuela Marcelli1
1Laboratory of Bioengineering, Department of Experimental Diagnostic and Specialty Medicine, University of Bologna, Bologna, Italy.

Abstract:
Several remote catheter navigation systems have been developed and are now commercially available. However, these systems typically require specialized catheters or equipment, as well as time-consuming operations for the system set-up. In this paper, we present CathROB, a highly compact and versatile robotic system for remote navigation of standard tip-steerable electrophysiology (EP) catheters. Key features of CathROB include an extremely compact design that minimizes encumbrance and time for system set-up in a standard cath lab, a force-sensing mechanism, an intuitive command interface, and functions for automatic catheter navigation and repositioning. We report in vitro and in vivo animal evaluation of CathROB. In vitro results showed good accuracy in remote catheter navigation and automatic repositioning (1.5 ± 0.6 mm for the left-side targets, 1.7 ± 0.4 mm for the right-side targets). Adequate tissue contact was achieved with remote navigation in vivo. There were no adverse events, including absence of cardiac perforation or cardiac damage, indicative of the safety profile of CathROB. Although further preclinical and clinical studies are required, the presented CathROB system seems to be a promising solution for an affordable and easy-to-use remote catheter navigation.
Related Concept Videos
 01:21
Cardiac Catheterization II: Right Heart Catheterization
 01:24
Cardiac Catheterization III: Left Heart Catheterization
 01:26
Cardiac Catheterization IV: Nursing Management
 01:28
Cardiac Catheterization I: Pre-Procedure Overview