Related Experiment Video
Updated: Feb 27, 2026
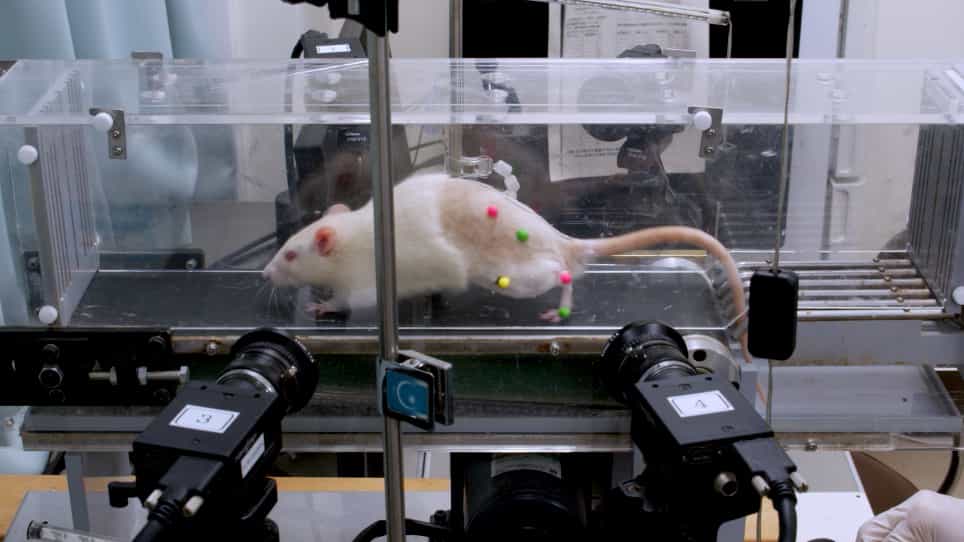

Comprehensive Understanding of Inactivity-Induced Gait Alteration in Rodents
Published on: July 6, 2022
Translational Motion Tracking of Leg Joints for Enhanced Prediction of Walking Tasks

Objective:
Walking task prediction in powered leg prostheses is an important problem in the development of biomimetic prosthesis controllers. This paper proposes a novel method to predict upcoming walking tasks by estimating the translational motion of leg joints using an integrated inertial measurement unit.
Methods:
We asked six subjects with unilateral transtibial amputations to traverse flat ground, ramps, and stairs using a powered prosthesis while inertial signals were collected. We then performed an offline analysis in which we simulated a real-time motion tracking algorithm on the inertial signals to estimate knee and ankle joint translations, and then used pattern recognition separately on the inertial and translational signal sets to predict the target walking tasks of individual strides.
Results:
Our analysis showed that using inertial signals to derive translational signals enabled a prediction error reduction of 6.8% compared to that attained using the original inertial signals. This result was similar to that seen by addition of surface electromyography sensors to integrated sensors in previous work, but was effected without adding any extra sensors. Finally, we reduced the size of the translational set to that of the inertial set and showed that the former still enabled a composite error reduction of 5.8%.
Conclusion And Significance:
These results indicate that translational motion tracking can be used to substantially enhance walking task prediction in leg prostheses without adding external sensing modalities. Our proposed algorithm can thus be used as a part of a task-adaptive and fully integrated prosthesis controller.
More Related Videos
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
 06:52
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 02:07
Improving Translational Accuracy
02:07Improving Translational Accuracy