Related Experiment Video
Updated: Feb 24, 2026


Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
The four-tank control problem: Comparison of two disturbance rejection control solutions
Congzhi Huang1, Enrico Canuto2, Carlo Novara2
1School of Control and Computer Engineering, North China Electric Power University, Beijing 102206, China.

Abstract:
The paper aims to compare and prove a pair of disturbance/uncertainty rejection control laws for the well-known four-tank control problem. The control requirements are expressed in terms of a set point sequence as usual in the literature. The uncertainty class is defined as the union of four sub-classes: unknown disturbance, parametric uncertainty, measurement errors and neglected dynamics. Modelling and design give insight on the dynamic properties of the problem. Two theorems, which fix the range of application, are presented. These theorems are confirmed by the simulated results, and indicate the correct way to further broaden the control design applicability. The disturbance rejection design is deployed using the Embedded Model Control methodology. Accordingly, only the unknown disturbance and parametric uncertainty can be rejected, whereas the effects of neglected dynamics must be filtered. As a result, simple performance and stability inequality can be formulated in the frequency domain: they guide the closed-loop pole placement. These inequalities reveal whether pole placement is feasible and how feasibility can be recovered. The latter is an issue, which at the authors' knowledge, is rarely encountered in the literature. Simulated runs prove the effectiveness of the design procedure.
More Related Videos
 05:40
Comparison of Scale in a Photosynthetic Reactor System for Algal Remediation of Wastewater
Published on: March 6, 2017
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:16
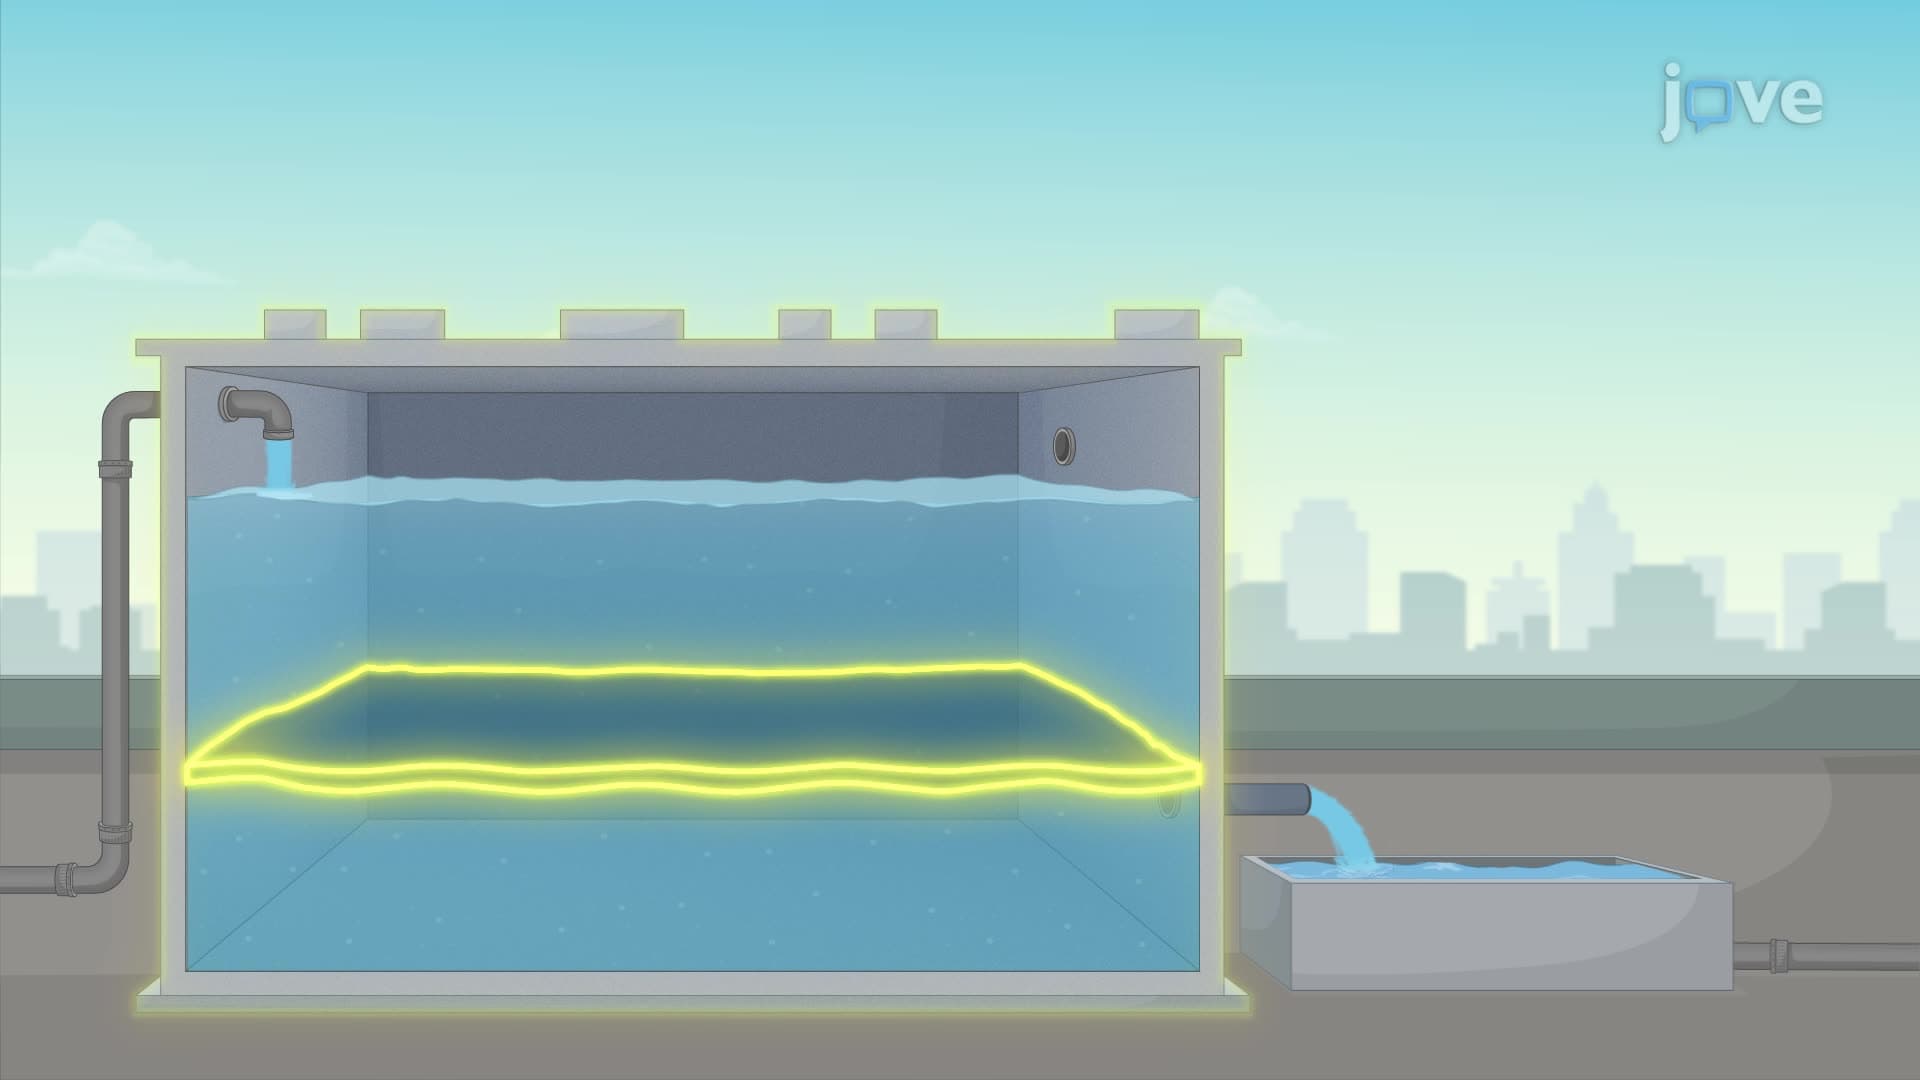
Control Volume and System Representations
The control volume approach considers a stationary region in space through which fluid flows. This region is bounded by a control surface. For instance, in the case of water...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...